Intelligent finite-time formation control for flapping wing micro aerial vehicles
Related Experiment Video
Updated: Jul 12, 2025
Low-Cost Automated Flight Intercept Trap for the Temporal Sub-Sampling of Flying Insects Attracted to Artificial Light at Night
Published on: December 29, 2021
Xiaoyan He1, Zhaojing Yang1, Linke Zhang1
1School of Statistics and Mathematics, Inner Mongolia University of Finance and Economics, Huhhot, 010070, China.

Abstract:
This paper investigates the intelligent finite time formation control for multiple Flapping wing micro aerial vehicles (FWMAVs) system. Firstly, the translational and the rotational attitude motion equations are proposed based on the Lagrangian equation for FWMAVs. The motion system is decouple into an internal and an external dual loop subsystems. An adaptive neural network estimation algorithm is proposed based on the internal and external double loop system of the coupled model to effectively estimate the uncertainties and the external disturbances of the model. In addition, two effective intelligent control protocols are presented for the translational and the rotational attitude motion subsystem, respectively, by utilizing potential energy function, generalized inverse matrix, and finite-time stability. The main contribution of this paper is the case that, four control objectives are achieved for multiple FWMAVs system, including the estimation of uncertainties, collision avoidance, connectivity preservation, and finite time convergence. Finally, a simulation example of formation tracking control is given by using matlab software in the numerical simulation part, and the effectiveness of the obtained results and the superiority of the control protocol are verified.
Related Concept Videos
 01:23
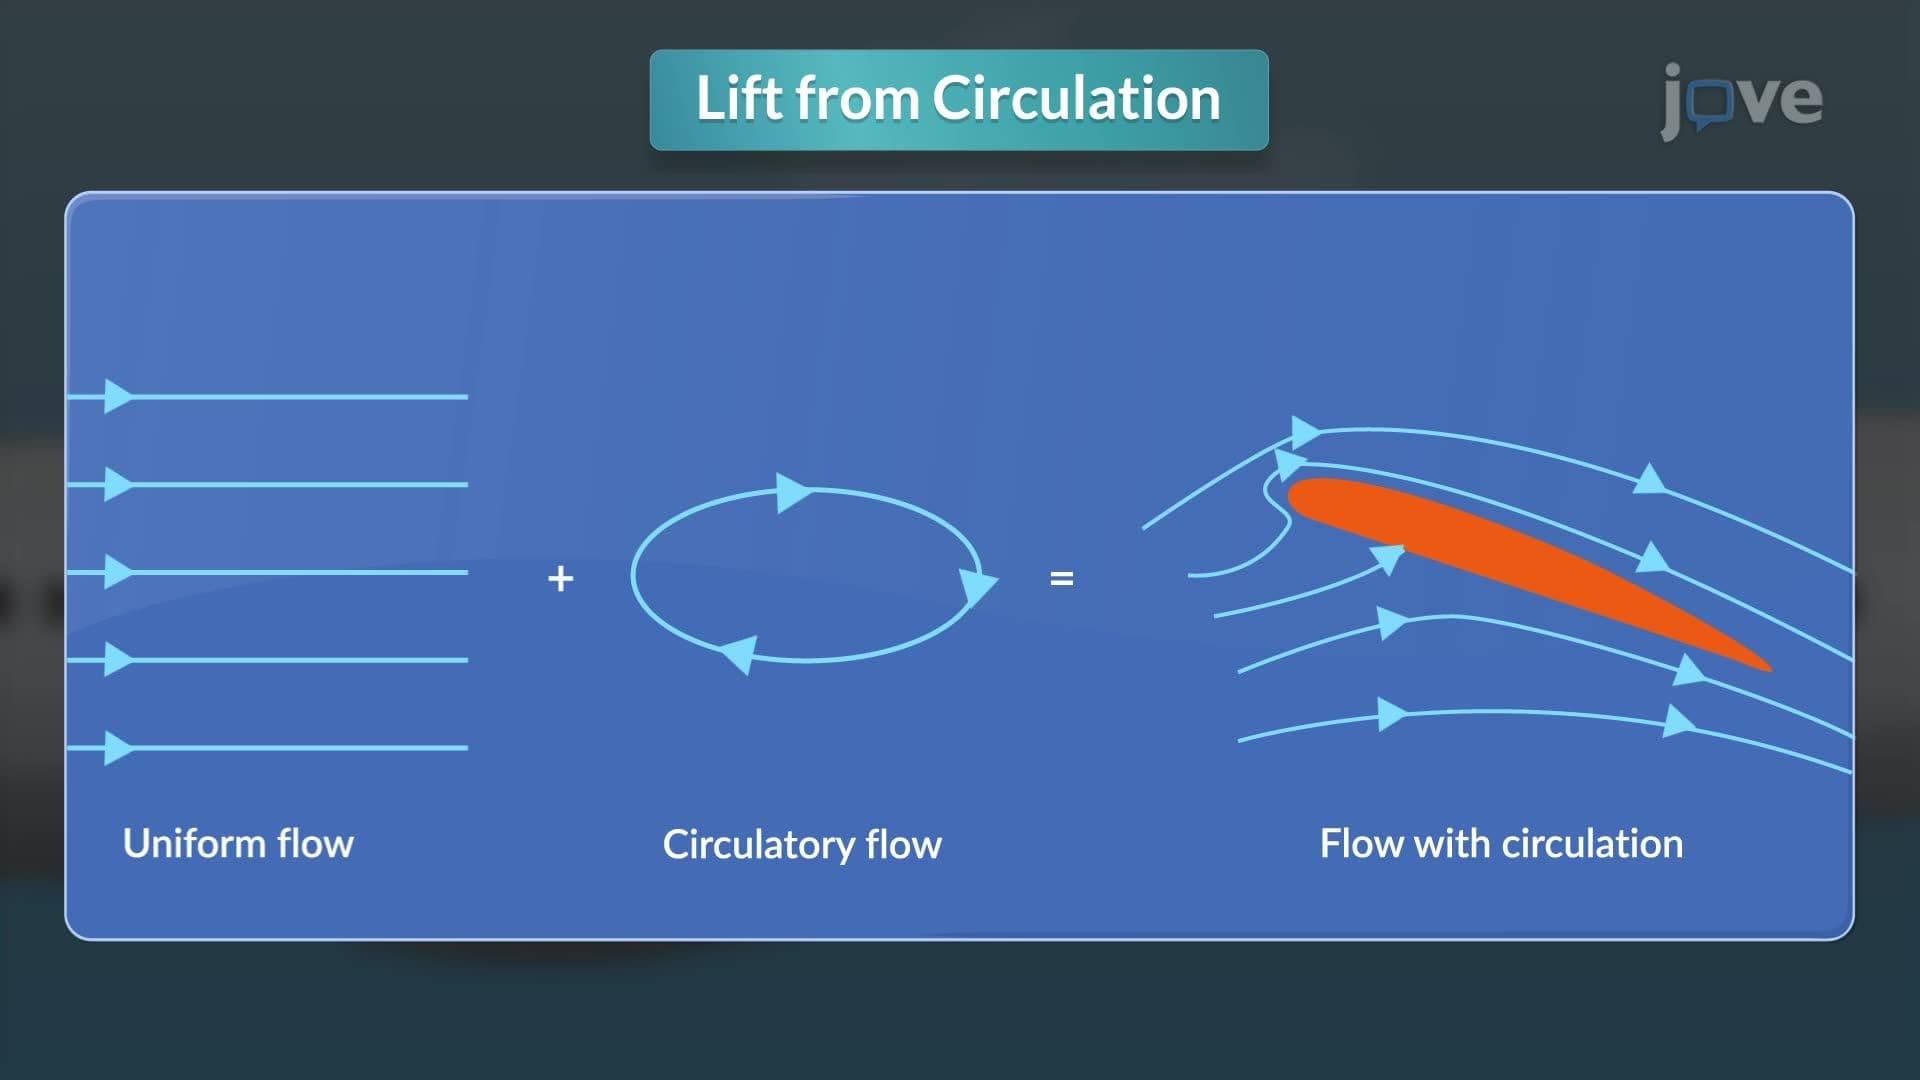
Lift
 01:28
Load-frequency control
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:15
Determination of Pi Terms
The theorem indicates that...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...