A Spatial-Temporal Variational Graph Attention Autoencoder Using Interactive Information for Fault Detection in Complex Industrial Processes


Abstract:
Modern industry processes are typically composed of multiple operating units with reaction interaction and energy-mass coupling, which result in a mixed time-varying and spatial-temporal coupling of process variables. It is challenging to develop a comprehensive and precise fault detection model for the multiple interconnected units by simple superposition of the individual unit models. In this study, the fault detection problem is formulated as a spatial-temporal fault detection problem utilizing process data of multiple interconnected unit processes. A spatial-temporal variational graph attention autoencoder (STVGATE) using interactive information is proposed for fault detection, which aims to effectively capture the spatial and temporal features of the interconnected unit processes. First, slow feature analysis (SFA) is implemented to extract temporal information that reveals the dynamic relevance of the process data. Then, an integration method of metric learning and prior knowledge is proposed to construct coupled spatial relationships based on temporal information. In addition, a variational graph attention autoencoder (VGATE) is suggested to extract temporal and spatial information for fault detection, which incorporates the dominances of variational inference and graph attention mechanisms. The proposed method can automatically extract and deeply mine spatial-temporal interactive feature information to boost detection performance. Finally, three industrial process experiments are performed to verify the feasibility and effectiveness of the proposed method. The results demonstrate that the proposed method dramatically increases the fault detection rate (FDR) and reduces the false alarm rate (FAR).
More Related Videos


Related Concept Videos
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:18
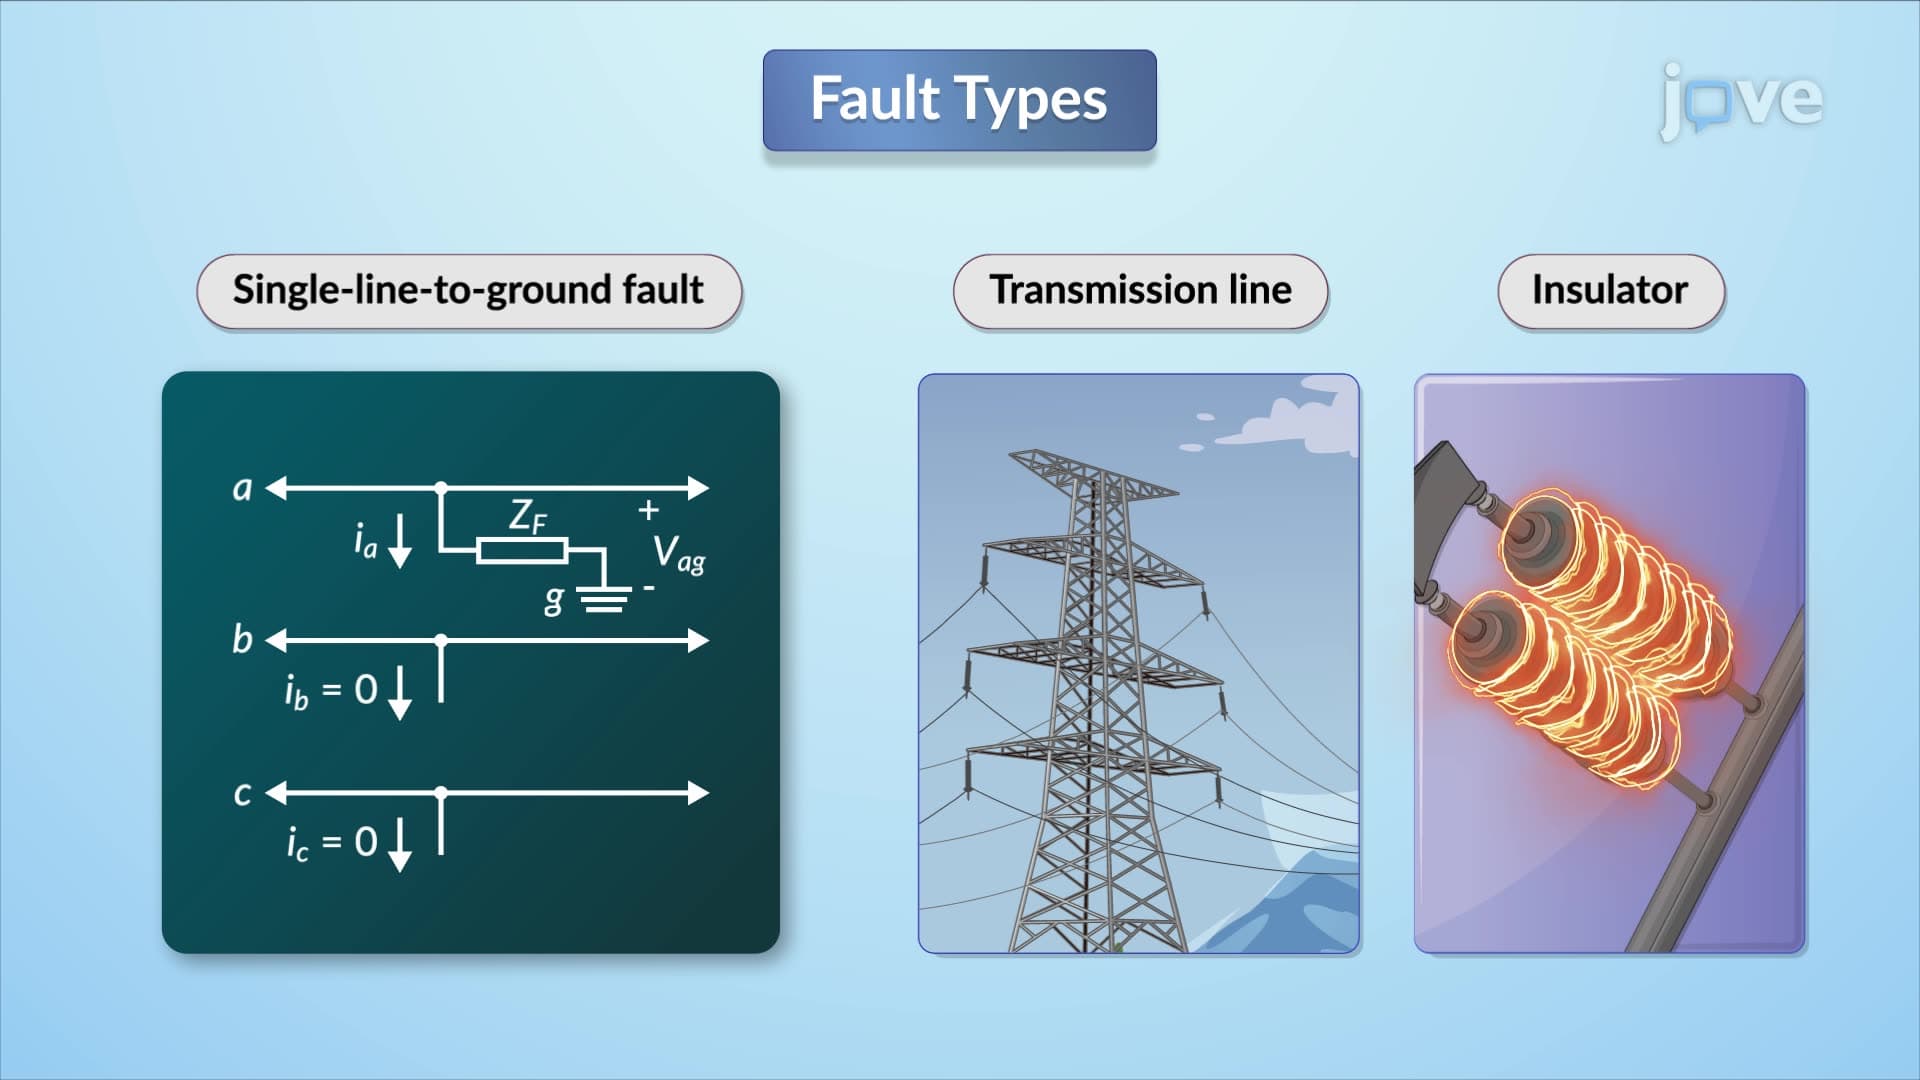
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:21
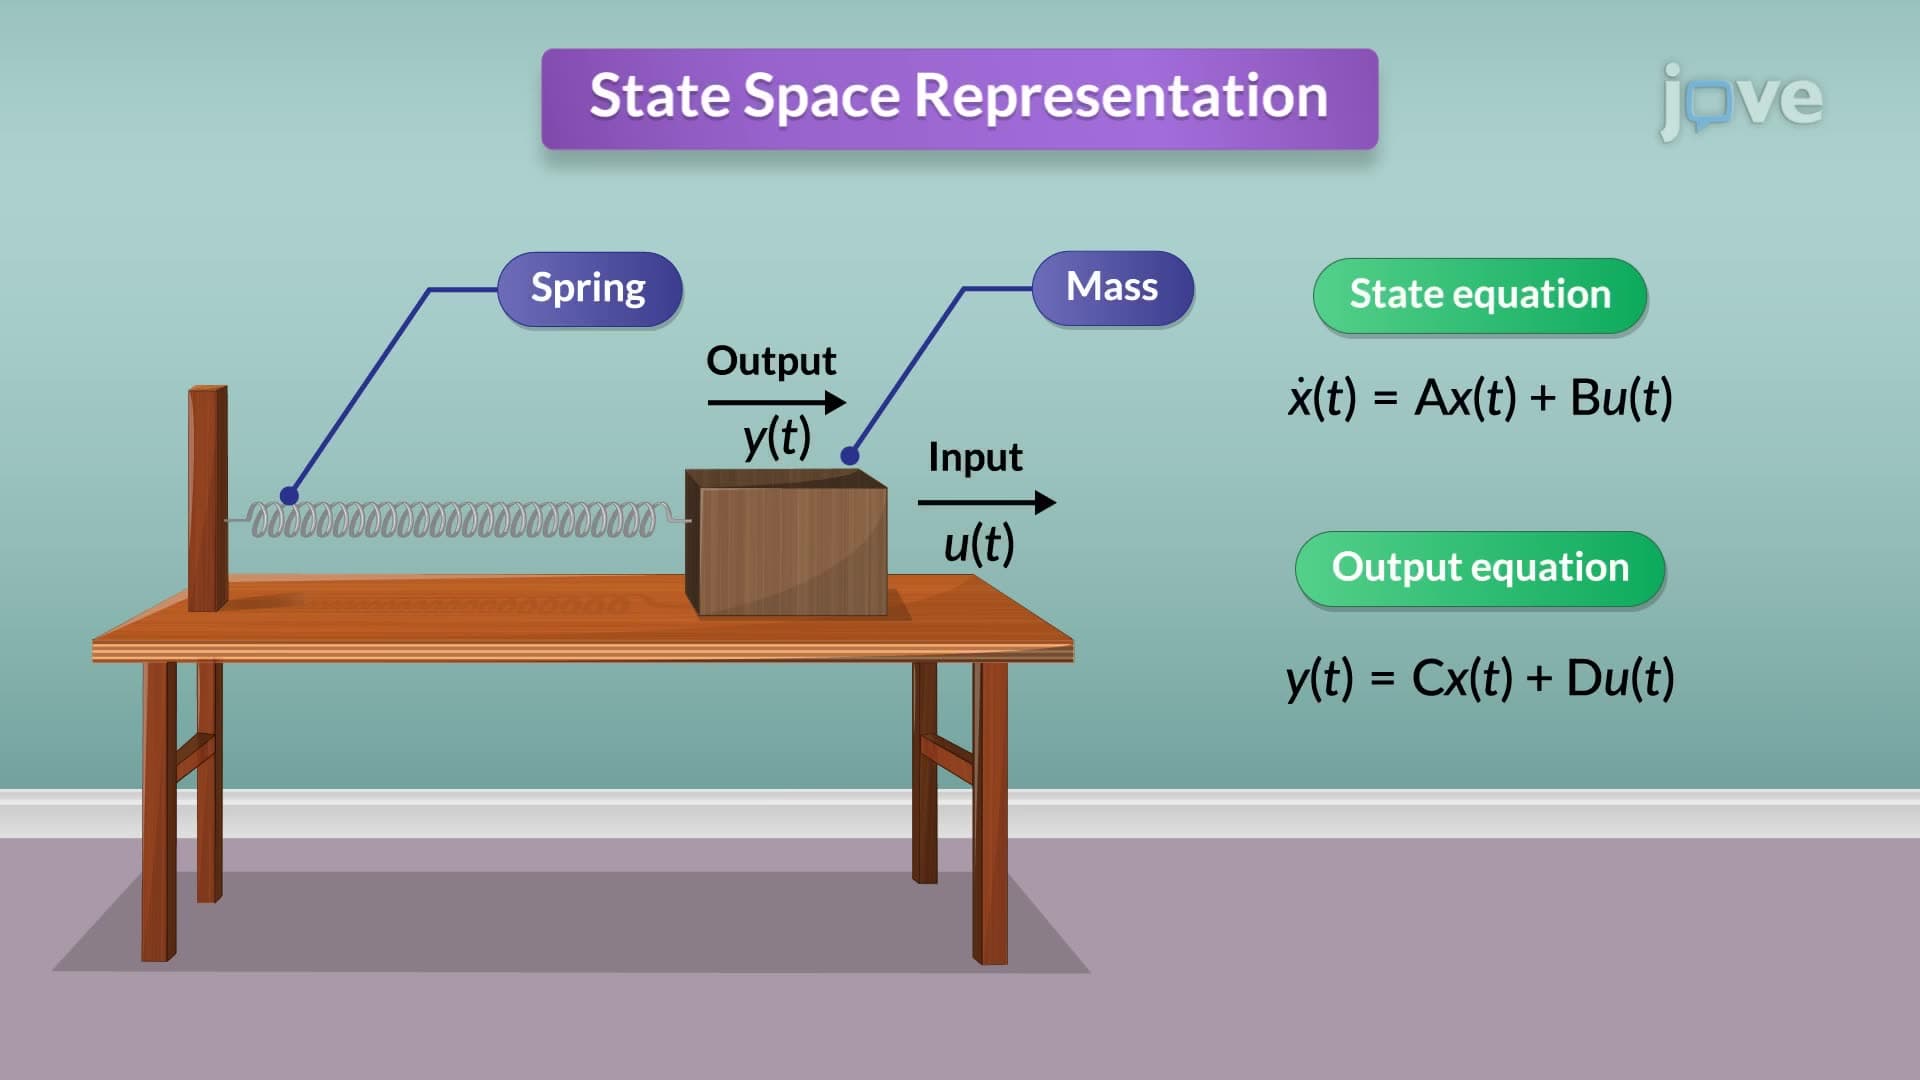
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:23
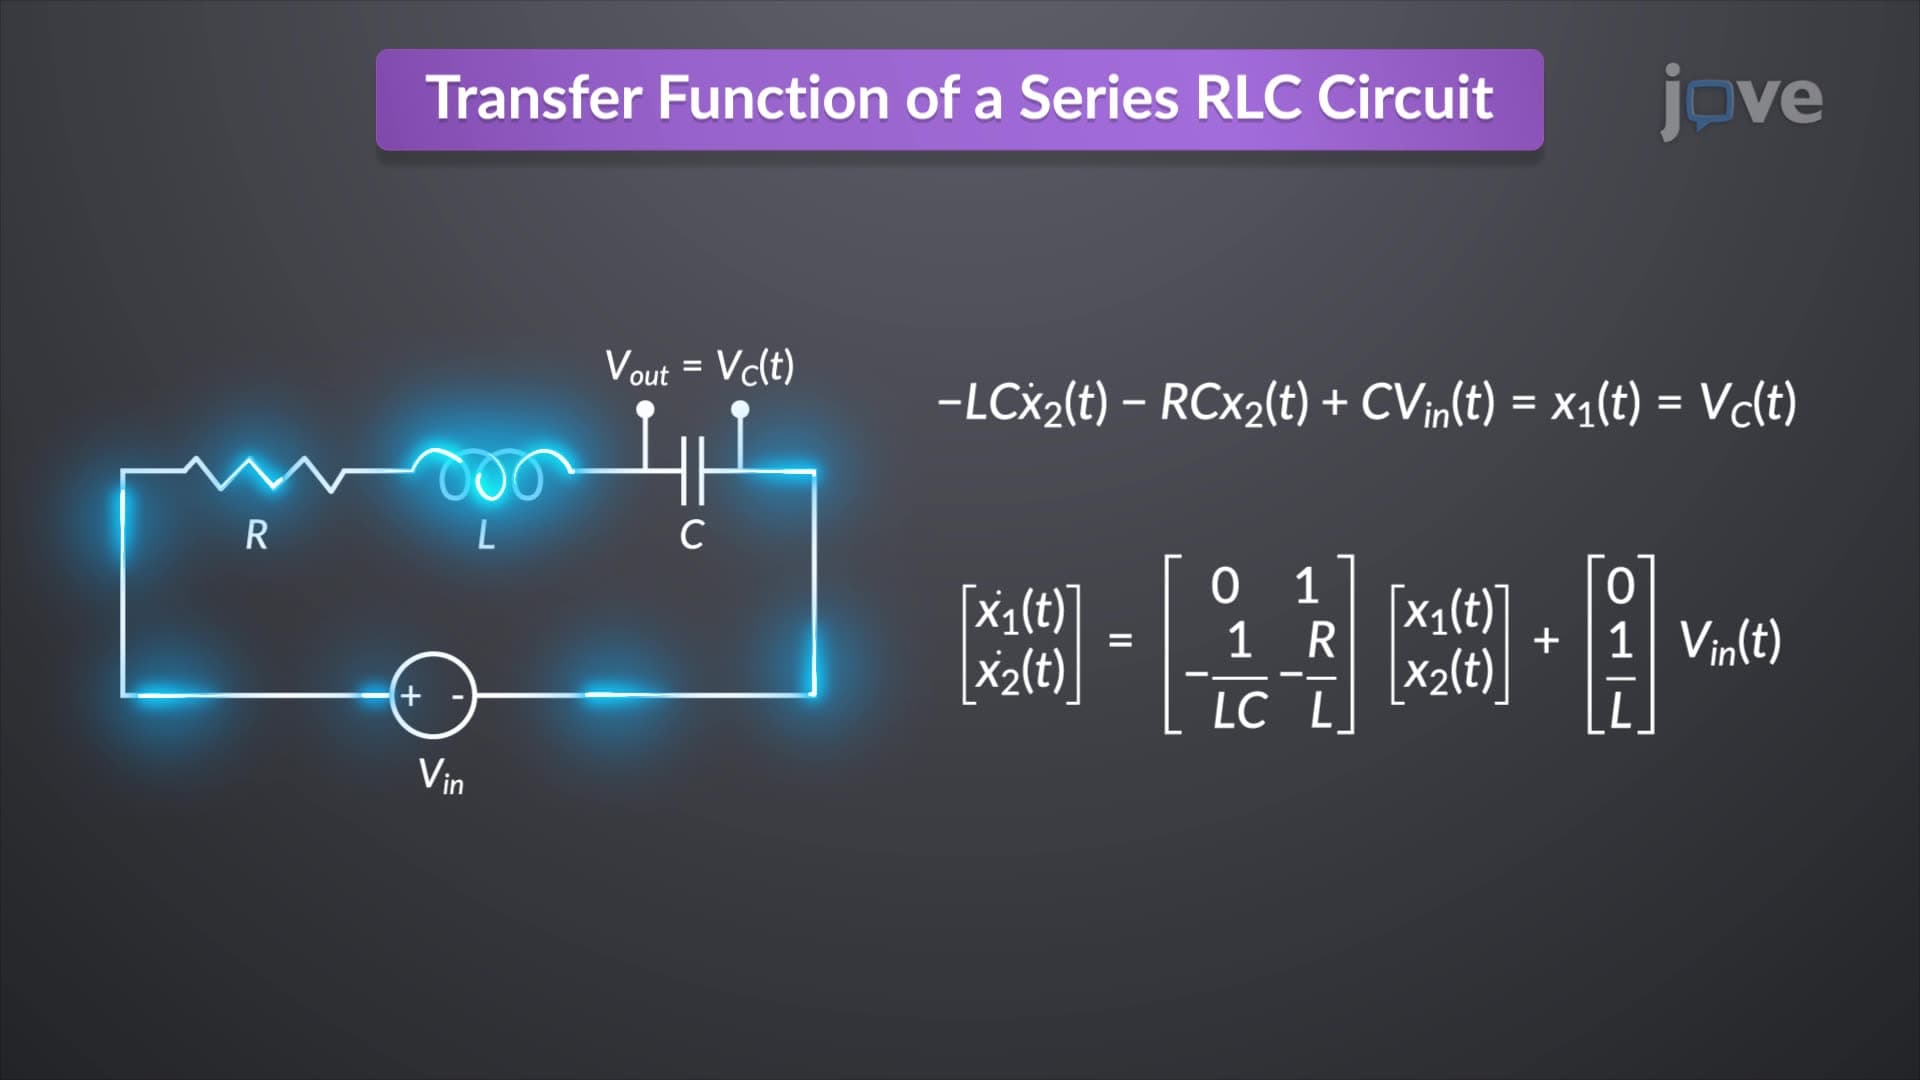
Transfer Function to State Space
In an...