A robust finite-time model reference adaptive controller for arbitrary order disturbed LTI systems
Related Experiment Video
Updated: Jul 11, 2025

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Héctor Ríos1, Roberto Franco2, Alejandra Ferreira de Loza3
1Tecnológico Nacional de México/I.T. La Laguna, C.P. 27000, Torreón, Coahuila, Mexico; CONAHCYT, Investigadoras e Investigadores por México, C.P. 03940, Ciudad de México, Mexico.

Abstract:
This manuscript deals with the trajectory-tracking problem for linear time-invariant systems with parameter uncertainties and time-dependent external perturbations. A robust finite-time model reference adaptive controller is proposed. In the absence of external perturbations, the proposed controller ensures finite-time convergence to zero of the tracking and parameter identification errors. In presence of time-dependent external perturbations, the tracking and parameter identification errors converge to a region around the origin in a finite time. The convergence proofs are developed based on Lyapunov and input-to-state stability theory. Finally, simulation results in an academic example and a flexible-joint robot manipulator show the feasibility of the proposed approach.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
First Order Systems
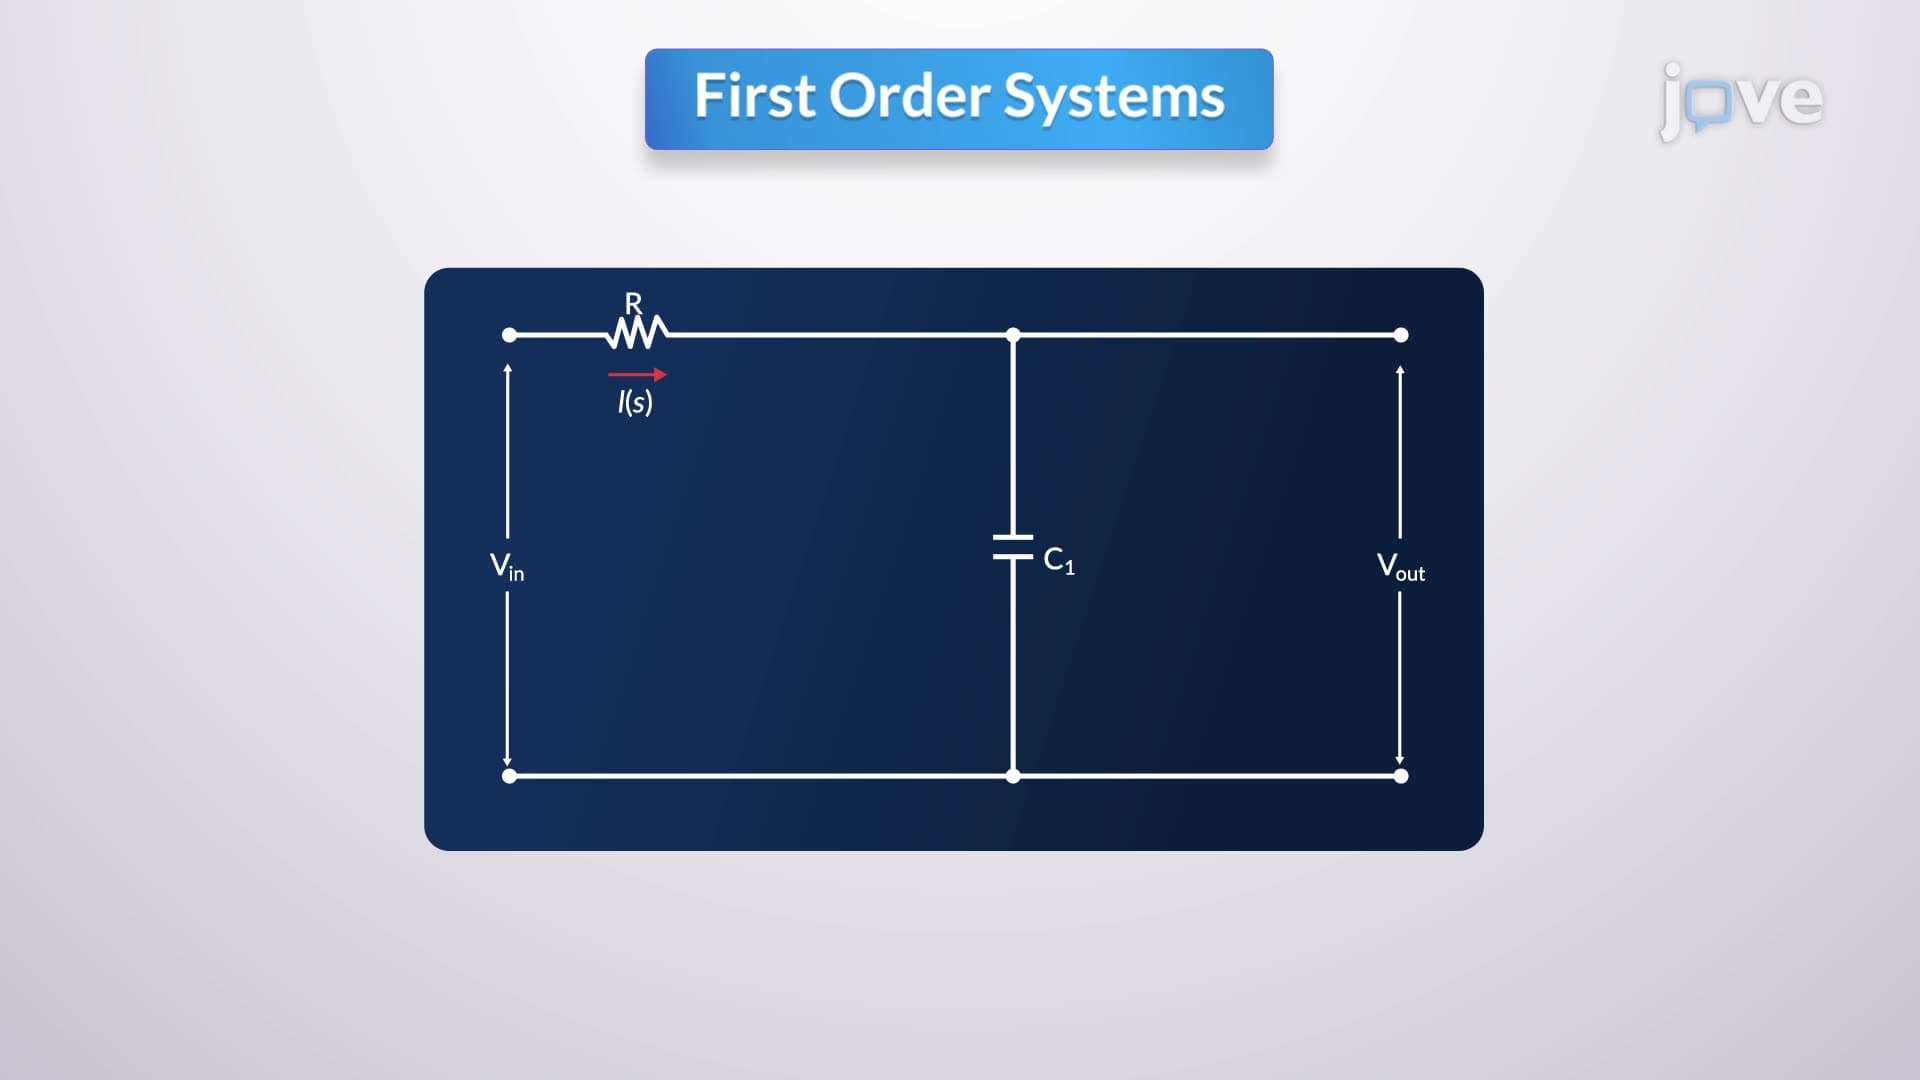
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
PI Controller: Design
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:28
Stability
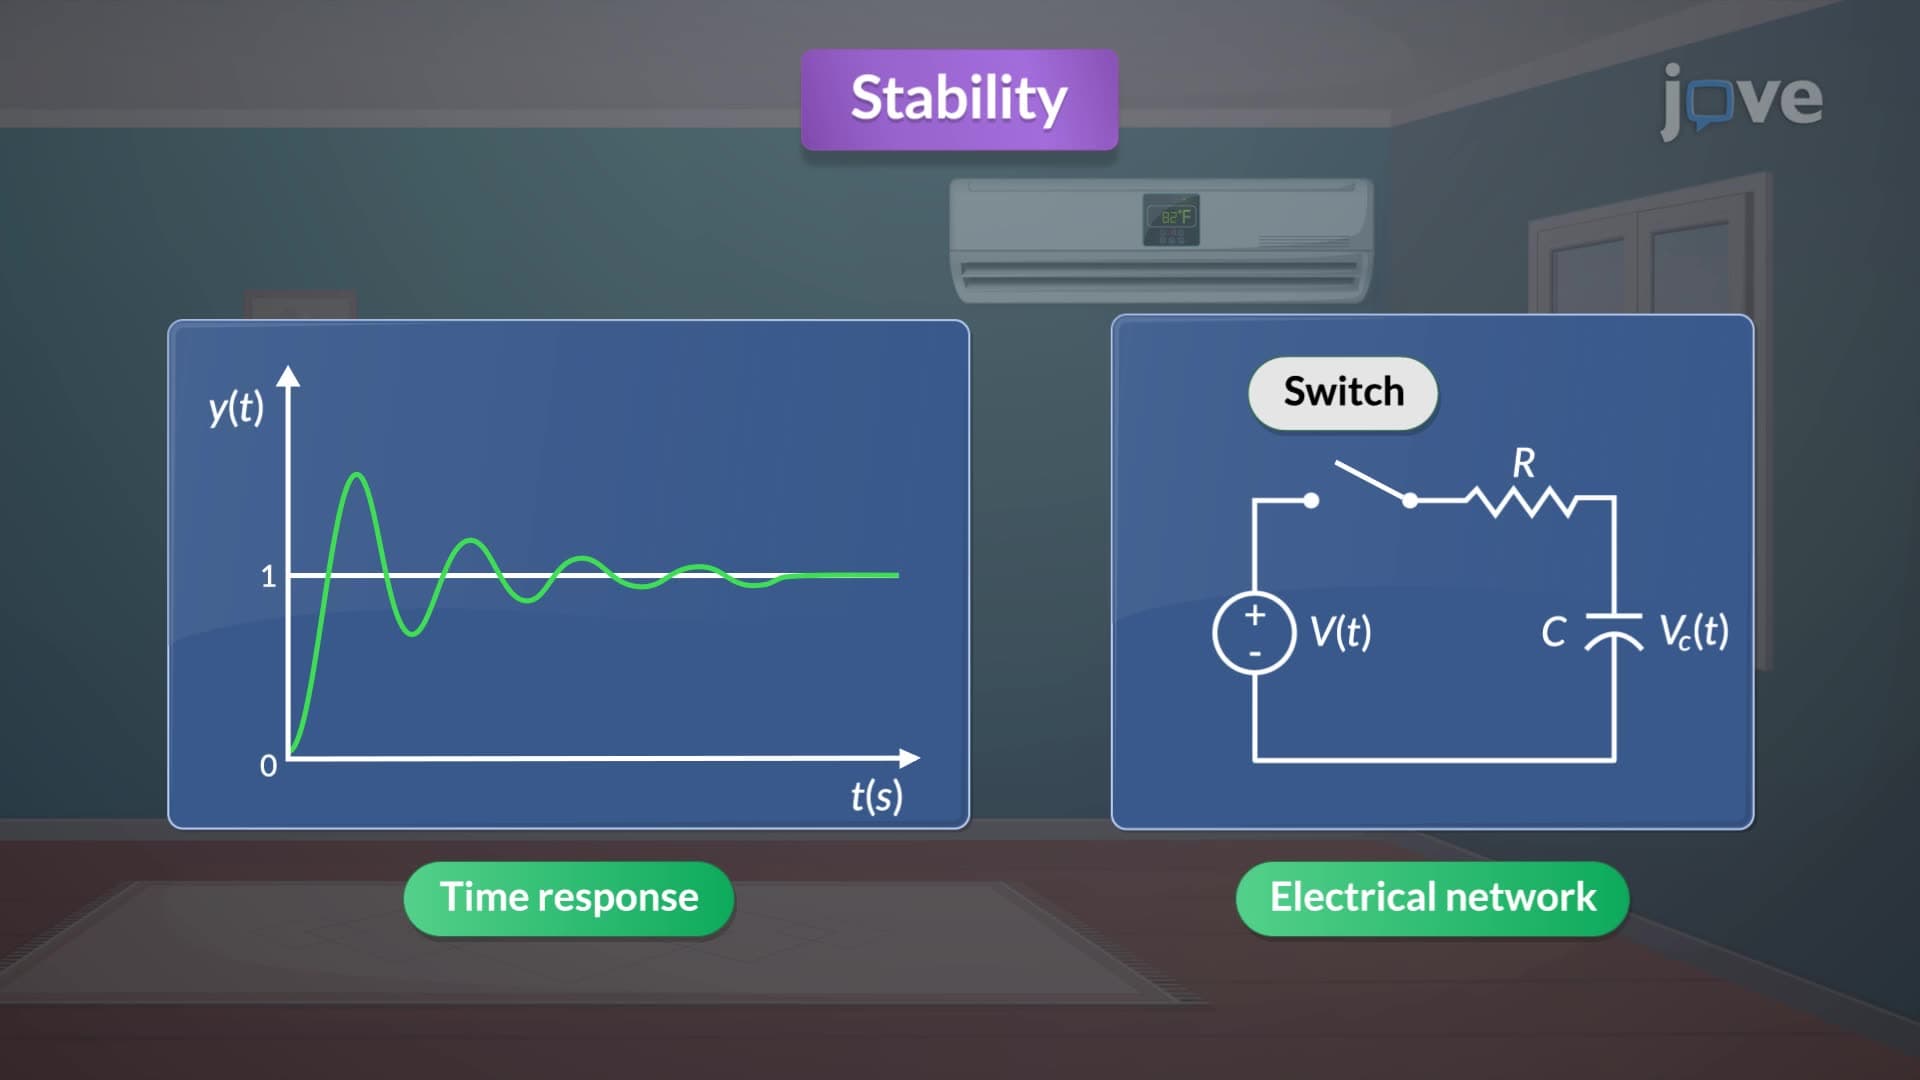
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...