Related Experiment Video
Updated: Jul 10, 2025


Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Phase transitions in an adaptive network with the global order parameter adaptation
M Manoranjani1, V R Saiprasad1, R Gopal1
1Department of Physics, Centre for Nonlinear Science and Engineering, School of Electrical and Electronics Engineering, SASTRA Deemed University, Thanjavur 613 401, India.

Abstract:
We consider an adaptive network of Kuramoto oscillators with purely dyadic coupling, where the adaption is proportional to the degree of the global order parameter. We find only the continuous transition to synchronization via the pitchfork bifurcation, an abrupt synchronization (desynchronization) transition via the pitchfork (saddle-node) bifurcation resulting in the bistable region R_{1}. This is a smooth continuous transition to a weakly synchronized state via the pitchfork bifurcation followed by a subsequent abrupt transition to a strongly synchronized state via a second saddle-node bifurcation along with an abrupt desynchronization transition via the first saddle-node bifurcation resulting in the bistable region R_{2} between the weak and strong synchronization. The transition goes from the bistable region R_{1} to the bistable region R_{2}, and transition from the incoherent state to the bistable region R_{2} as a function of the coupling strength for various ranges of the degree of the global order parameter and the adaptive coupling strength. We also find that the phase-lag parameter enlarges the spread of the weakly synchronized state and the bistable states R_{1} and R_{2} to a large region of the parameter space. We also derive the low-dimensional evolution equations for the global order parameters using the Ott-Antonsen ansatz. Further, we also deduce the pitchfork, first and second saddle-node bifurcation conditions, which is in agreement with the simulation results.

Related Concept Videos
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:18
Second Order systems II
 01:21
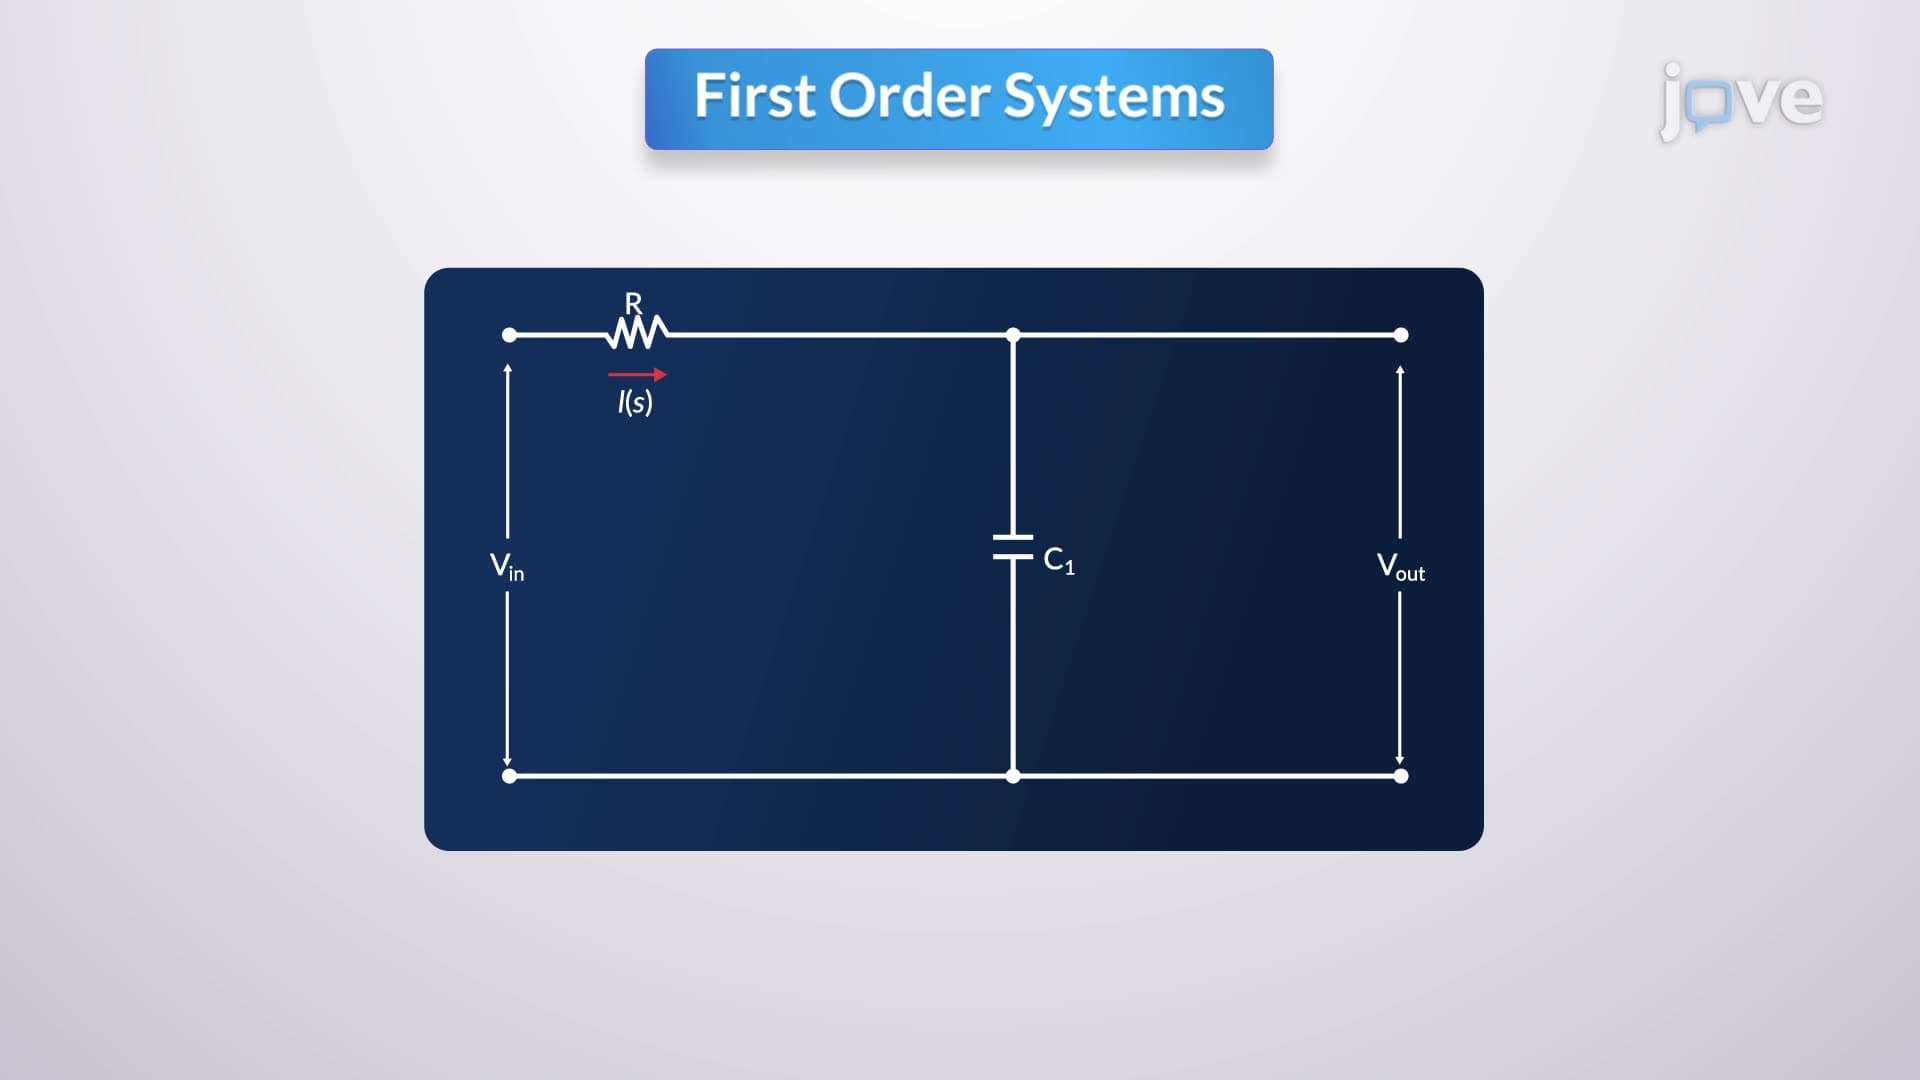
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Phase-lead and Phase-lag Controllers
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...