Related Experiment Video
Updated: Jul 10, 2025
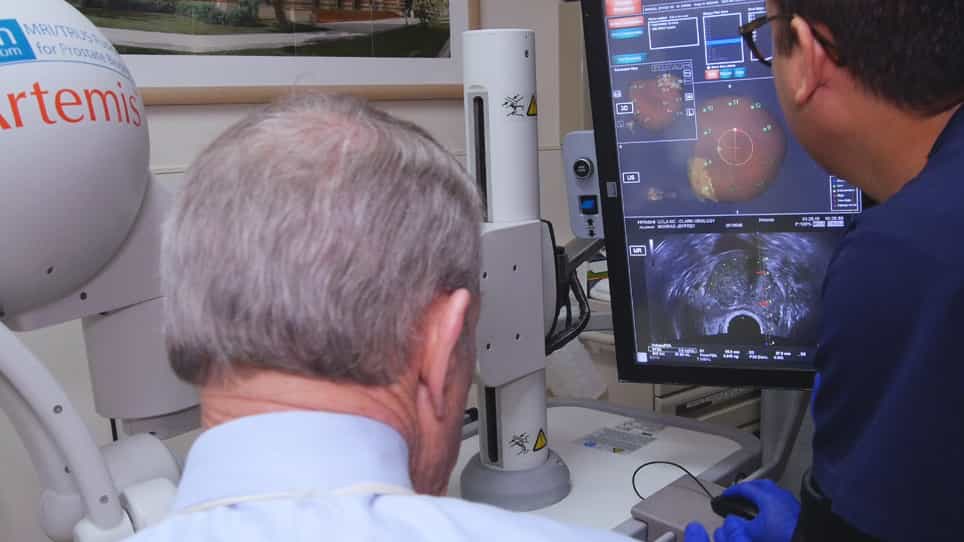

Use of MRI-ultrasound Fusion to Achieve Targeted Prostate Biopsy
Published on: April 9, 2019
Preliminary evaluation for ultrasound-guided targeted prostate biopsy using a portable surgical robot: Ex vivo
Wenhe Jiang1, Yongzhuo Gao1, Mingwei Wen2
1State Key Laboratory of Robotics and System, Harbin Institute of Technology, Harbin, China.

Background:
Robotic systems are increasingly used to enhance clinical outcomes in prostate intervention. To evaluate the clinical value of the proposed portable robot, the robot-assisted and robot-targeted punctures were validated experimentally.
Method:
The robot registration utilising the electromagnetic tracker achieves coordinate transformation from the ultrasound (US) image to the robot. Subsequently, Transrectal ultrasound (TRUS)-guided phantom trials were conducted for robot-assisted, free-hand, and robot-targeted punctures.
Results:
The accuracy of robot registration was 0.95 mm, and the accuracy of robot-assisted, free-hand, and robot-targeted punctures was 2.38 ± 0.64 mm, 3.11 ± 0.72 mm, and 3.29 ± 0.83 mm sequentially.
Conclusion:
The registration method has been successfully applied to robot-targeted puncture. Current results indicate that the accuracy of robot-targeted puncture is slightly inferior to that of manual operations. Moreover, in manual operation, robot-assisted puncture improves the accuracy of free-hand puncture. Accuracy superior to 3.5 mm demonstrates the clinical applicability of both robot-assisted and robot-targeted punctures.