Related Experiment Video
Updated: Jul 9, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Digital Optimal Robust Control
Meri Harutyunyan1, Frédéric Holweck2,3, Dominique Sugny1
1Laboratoire Interdisciplinaire Carnot de Bourgogne, UMR CNRS 6303, Université de Bourgogne, BP 47870, F-21078 Dijon, France.

Abstract:
The lack of ability to determine and implement accurately quantum optimal control is a strong limitation to the development of quantum technologies. We propose a digital procedure based on a series of pulses where their amplitudes and (static) phases are designed from an optimal continuous-time protocol for given type and degree of robustness, determined from a geometric analysis. This digitalization combines the ease of implementation of composite pulses with the potential to achieve global optimality, i.e., to operate at the ultimate speed limit, even for a moderate number of control parameters. We demonstrate the protocol on IBM's quantum computers for a single qubit, obtaining a robust transfer with a series of Gaussian or square pulses in a time T=382 ns for a moderate amplitude. We find that the digital solution is practically as fast as the continuous one for square subpulses with the same peak amplitudes.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
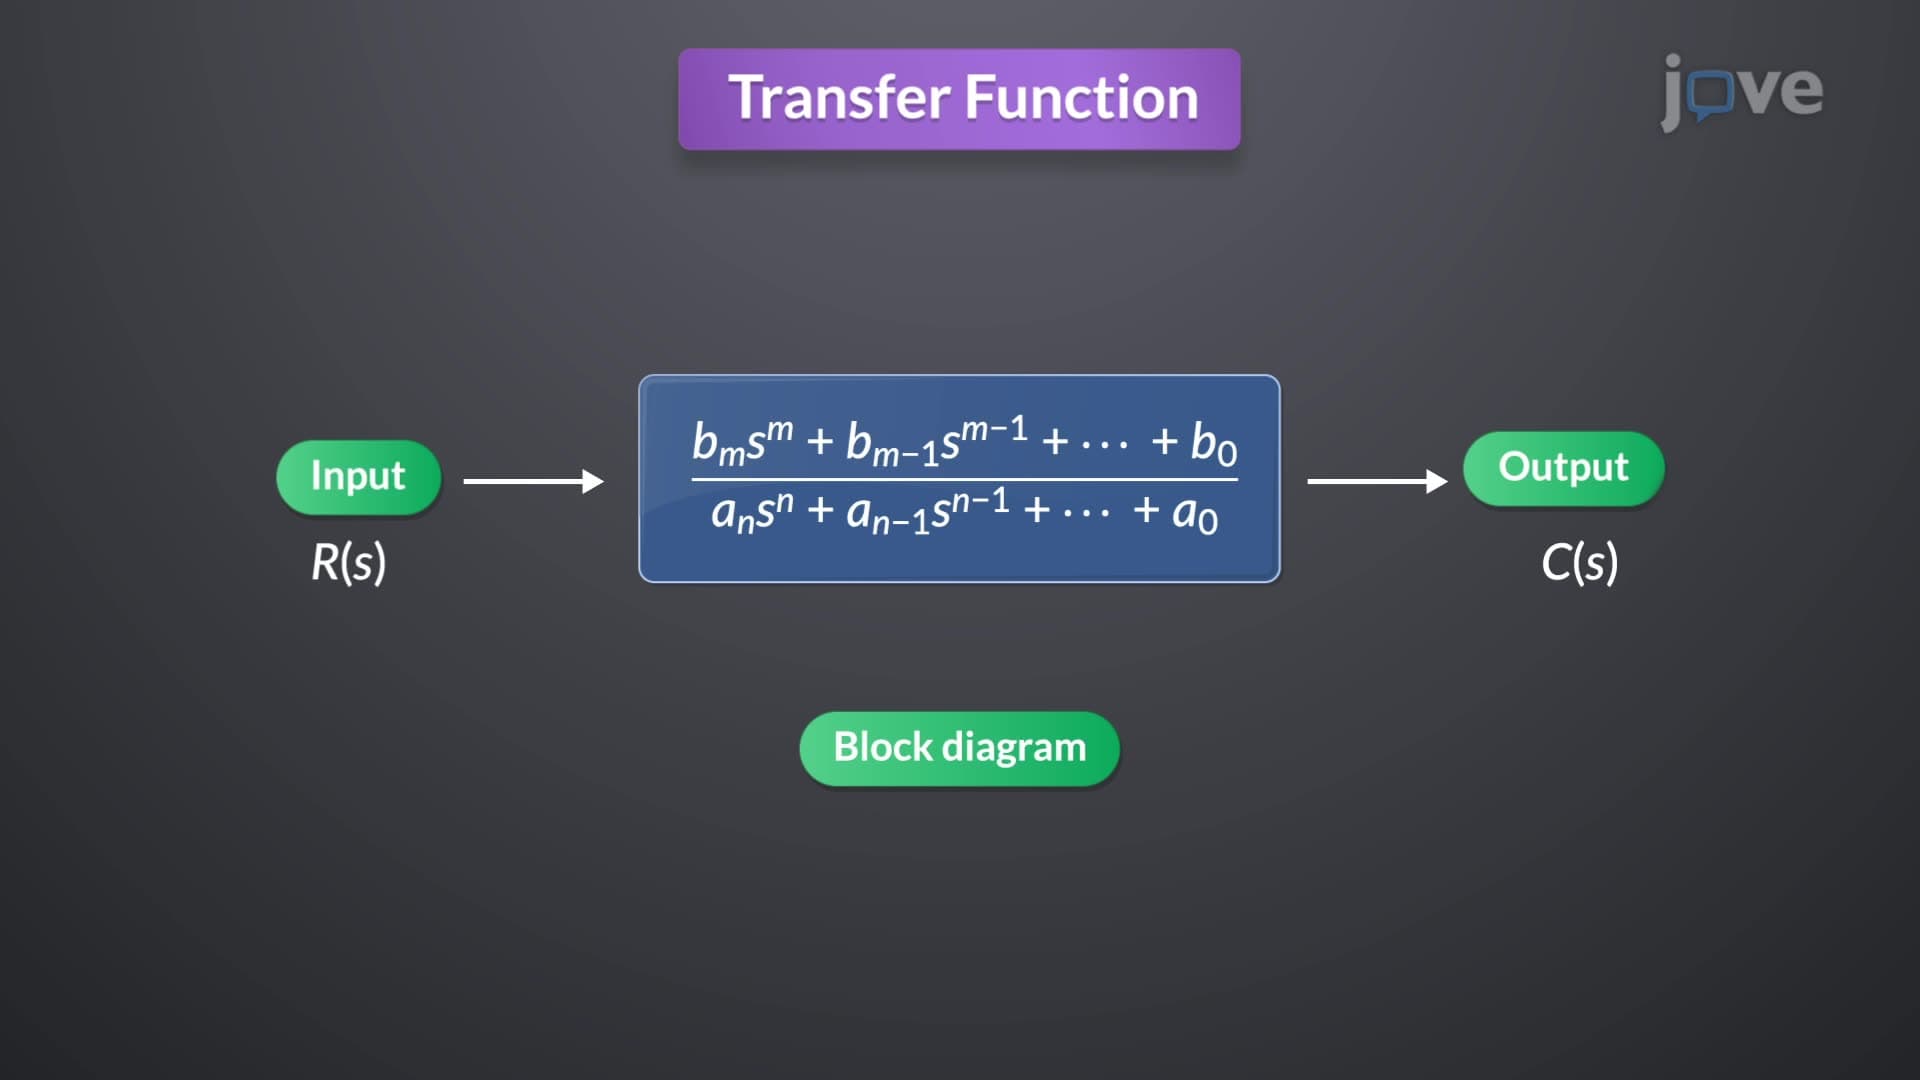
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...