Adaptive nonsingular terminal sliding mode controller for PMSM drive system using modified extended state observer
Related Experiment Video
Updated: Jul 9, 2025

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
1School of Electronic and Optical Engineering, Nanjing University of Science and Technology Zijin College, Nanjing 210023, China.

Abstract:
In this study, a novel adaptive nonsingular terminal sliding mode (ANTSM) control frame combined with a modified extended state observer (MESO) is presented to enhance the anti-interference performance of the permanent magnet synchronous motor (PMSM) system. In the face of time-varying disturbances with unknown upper bounds, traditional nonsingular terminal sliding mode (NTSM) controllers typically utilize the large control gain to counteract the total disturbance, which will cause unsatisfactory control performances. To address this tough issue, an ANTSM control technique was constructed for the PMSM system by tuning the control gain automatically without overestimation. On this basis, the MESO was adopted to estimate the unknown total disturbance, whose estimation was offset to the ANTSM control input. By applying finite-time techniques, the estimation error will finite-time converge to zero. The proposed MESO has a more rapid estimation speed than the traditional extended state observer (ESO). Finally, the validity of the ANTSM + ESO composite control algorithm is confirmed by comprehensive experiments.


Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
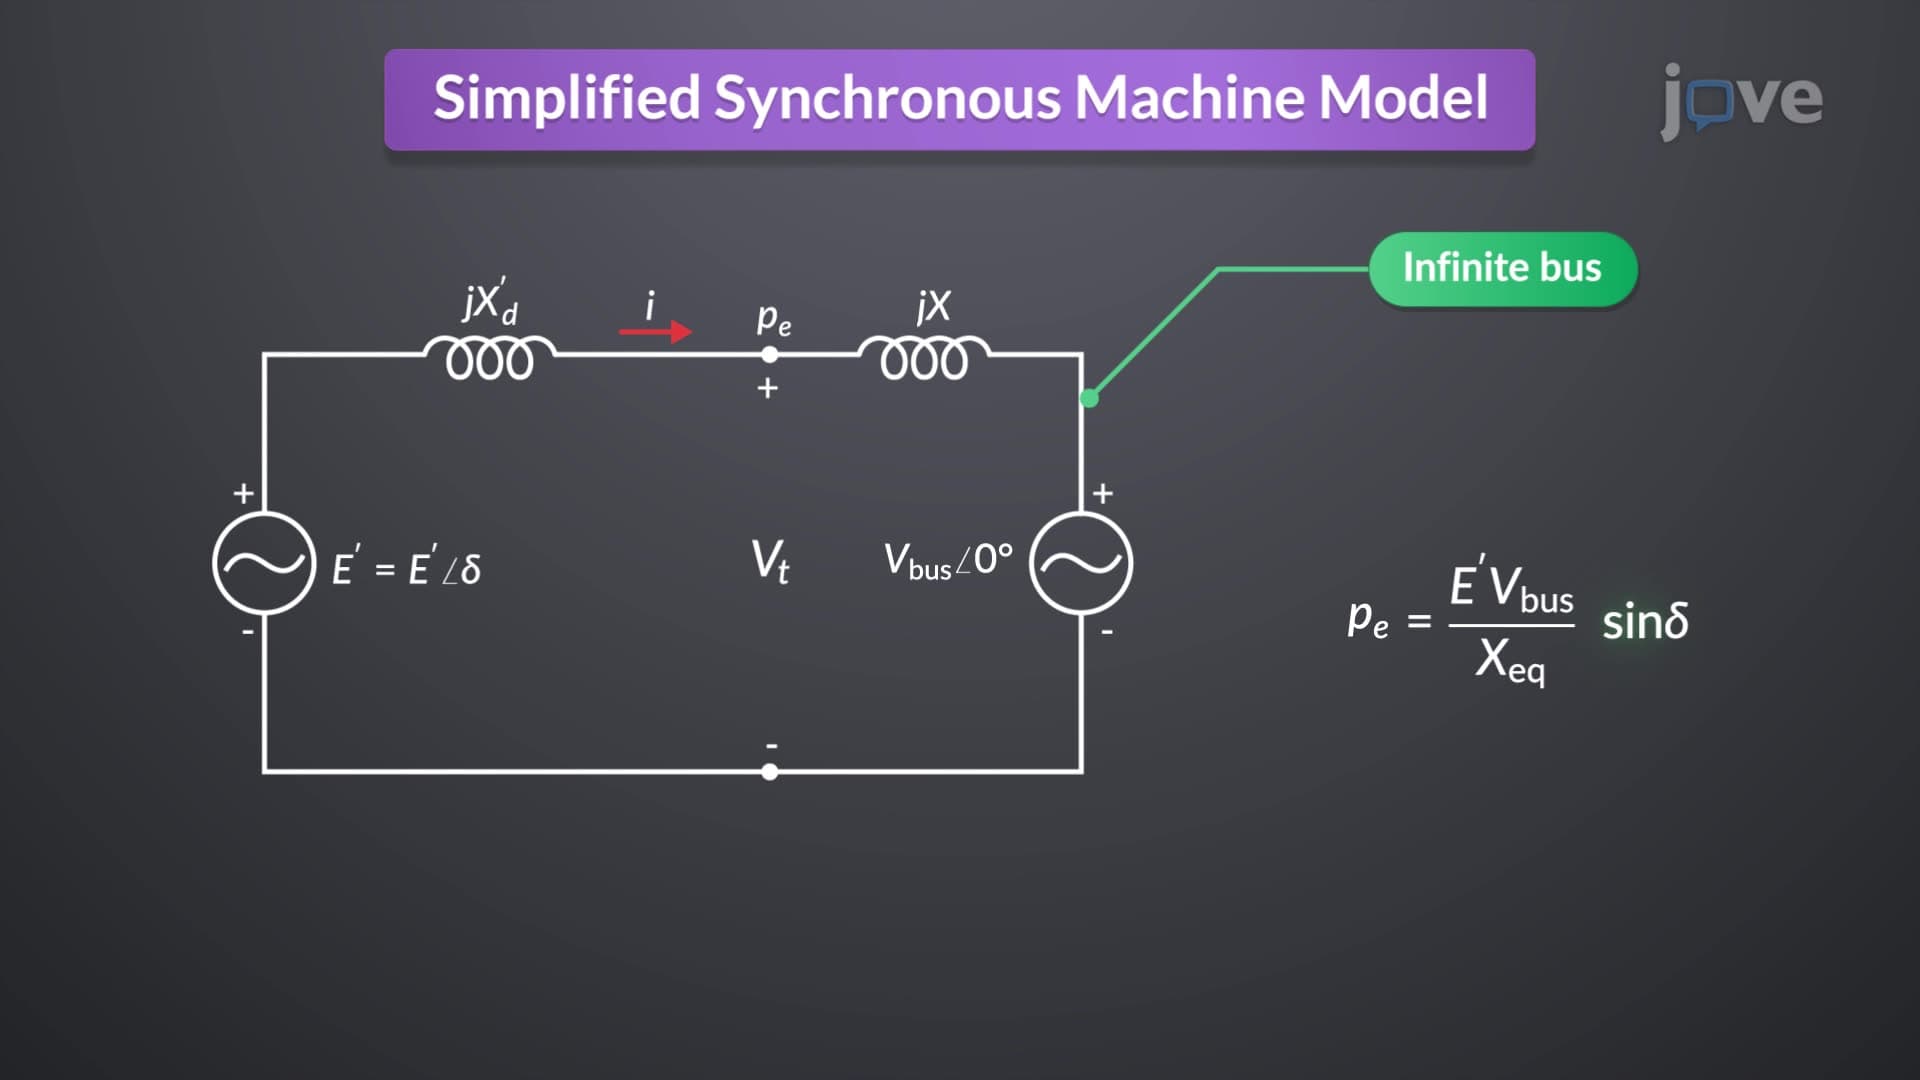 01:30
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:24
PI Controller: Design
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:19
PID Controller