Why You Cannot Rank First: Modifications for Benchmarking Six-Degree-of-Freedom Visual Localization Algorithms
Related Experiment Video
Updated: Jul 17, 2026
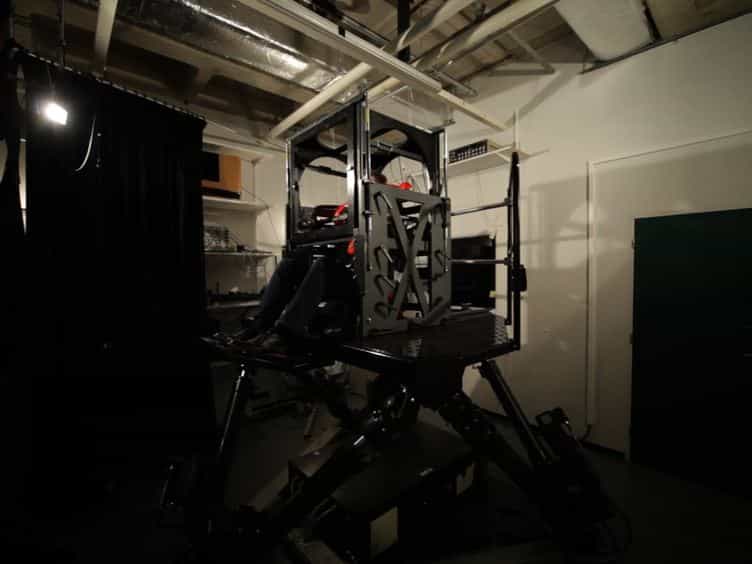
Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
Sheng Han1,2, Wei Gao1,2, Zhanyi Hu1,2
1School of Artificial Intelligence, University of Chinese Academy of Sciences, Beijing 100049, China.

Abstract:
Robust and precise visual localization over extended periods of time poses a formidable challenge in the current domain of spatial vision. The primary difficulty lies in effectively addressing significant variations in appearance caused by seasonal changes (summer, winter, spring, autumn) and diverse lighting conditions (dawn, day, sunset, night). With the rapid development of related technologies, more and more relevant datasets have emerged, which has also promoted the progress of 6-DOF visual localization in both directions of autonomous vehicles and handheld devices.This manuscript endeavors to rectify the existing limitations of the current public benchmark for long-term visual localization, especially in the part on the autonomous vehicle challenge. Taking into account that autonomous vehicle datasets are primarily captured by multi-camera rigs with fixed extrinsic camera calibration and consist of serialized image sequences, we present several proposed modifications designed to enhance the rationality and comprehensiveness of the evaluation algorithm. We advocate for standardized preprocessing procedures to minimize the possibility of human intervention influencing evaluation results. These procedures involve aligning the positions of multiple cameras on the vehicle with a predetermined canonical reference system, replacing the individual camera positions with uniform vehicle poses, and incorporating sequence information to compensate for any failed localized poses. These steps are crucial in ensuring a just and accurate evaluation of algorithmic performance. Lastly, we introduce a novel indicator to resolve potential ties in the Schulze ranking among submitted methods. The inadequacies highlighted in this study are substantiated through simulations and actual experiments, which unequivocally demonstrate the necessity and effectiveness of our proposed amendments.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...