Related Experiment Video
Updated: Aug 14, 2026
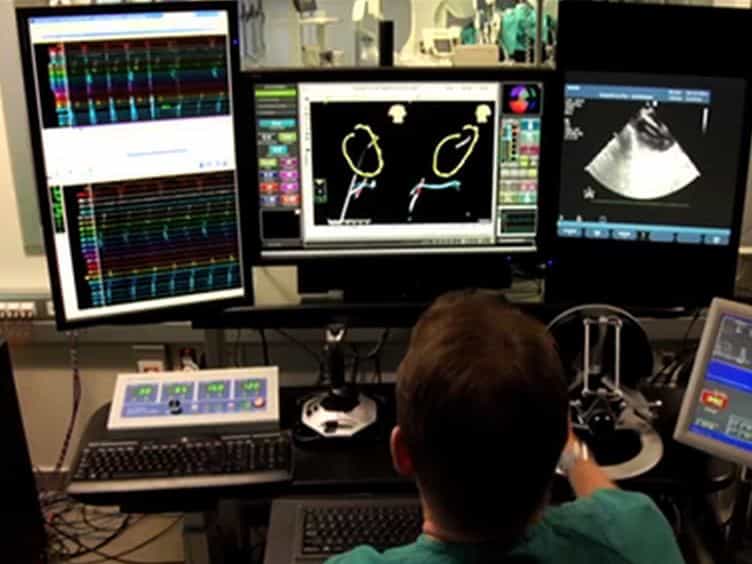
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
[Uncalibrated Positioning Method for Puncture Robots Based on Optical Navigation]
Qiwan Wang1, Ting Feng2, Rongqian Yang3
1School of Computer Science and Technology, Guangdong University of Technology, Guangzhou, 510006.

Abstract:
Robotic puncture system has been widely used in modern minimally invasive surgery, which usually uses hand-eye calibration to calculate the spatial relationship between the robot and the optical tracking system. However, the hand-eye calibration process is time-consuming and sensitive to environmental changes, which makes it difficult to guarantee the puncture accuracy of the robot. This study proposes an uncalibrated positioning method for puncture robot based on optical navigation. The method divides the target path positioning into two stages, angle positioning and position positioning, and designs angle image features and position image features respectively. The corresponding image Jacobian matrix is constructed based on the image features and updated by online estimation with a cubature Kalman filter to drive the robot to perform target path localization. The target path positioning results show that the method is more accurate than the traditional hand-eye calibration method and saves significant preoperative preparation time by eliminating the need for calibration.
Related Concept Videos
 01:28
Field Application of Global Positioning System
 01:30
Types of Global Positioning System Surveys
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device