Fractional Tensor Recurrent Unit (fTRU): A Stable Forecasting Model With Long Memory
Related Experiment Video
Updated: Jul 8, 2025

A Method of Trigonometric Modelling of Seasonal Variation Demonstrated with Multiple Sclerosis Relapse Data
Published on: December 9, 2015

Abstract:
The tensor recurrent model is a family of nonlinear dynamical systems, of which the recurrence relation consists of a -fold (called degree- ) tensor product. Despite such models frequently appearing in advanced recurrent neural networks (RNNs), to this date, there are limited studies on their long memory properties and stability in sequence tasks. In this article, we propose a fractional tensor recurrent model, where the tensor degree is extended from the discrete domain to the continuous domain, so it is effectively learnable from various datasets. Theoretically, we prove that a large degree is essential to achieve the long memory effect in a tensor recurrent model, yet it could lead to unstable dynamical behaviors. Hence, our new model, named fractional tensor recurrent unit (fTRU), is expected to seek the saddle point between long memory property and model stability during the training. We experimentally show that the proposed model achieves competitive performance with a long memory and stable manners in several forecasting tasks compared to various advanced RNNs.

Related Concept Videos
 01:19
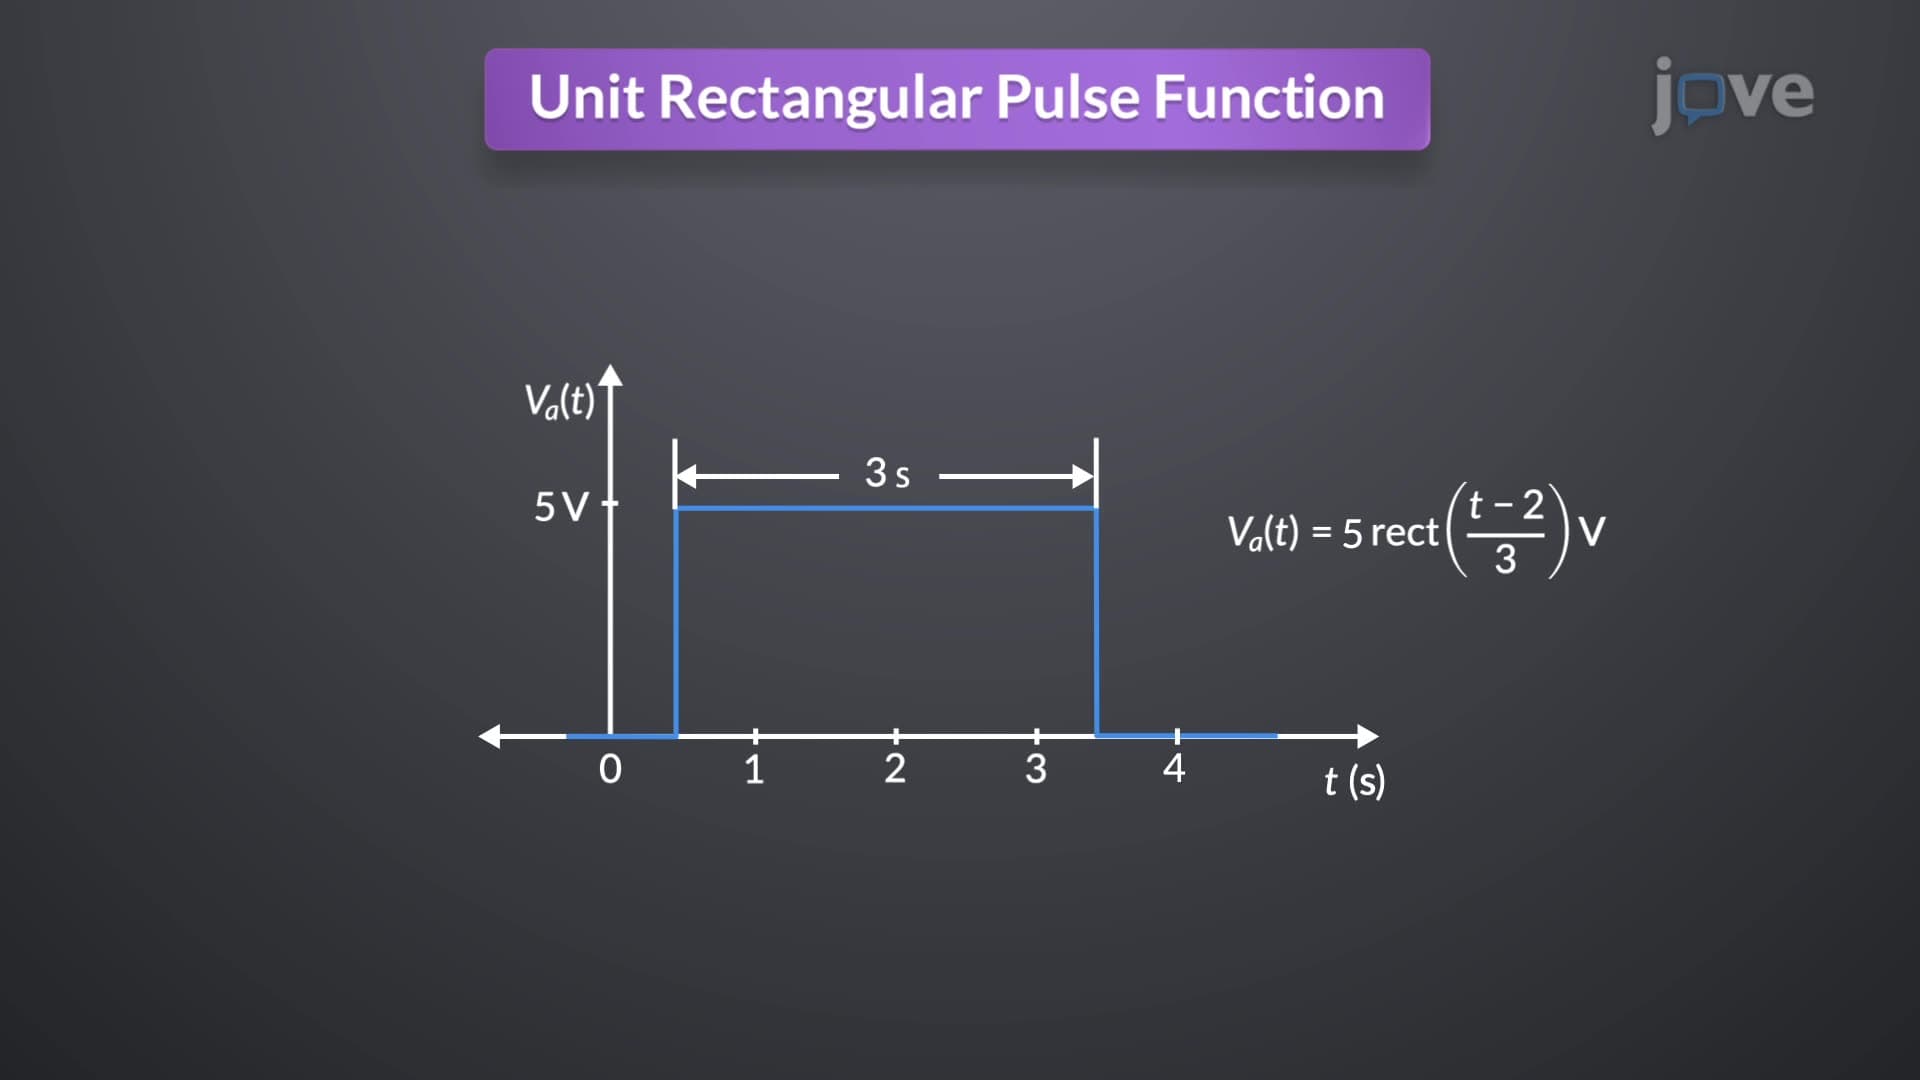
Rectangular and Triangular Pulse Function
For example, consider a rectangular pulse with a 5V amplitude, a 3-second duration, and centered at t=2 seconds. This pulse can be expressed using the rectangular function, written as,
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:11
Residuals and Least-Squares Property
If the observed data point lies above the line, the residual is positive, and the line underestimates the actual data value for y. If the observed data point lies below the line, the residual is negative, and the line overestimates the actual data value for y.
The process of fitting the best-fit...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....