Related Experiment Video
Updated: Jul 7, 2025
A Methodology for Capturing Joint Visual Attention Using Mobile Eye-Trackers
Published on: January 18, 2020
Convolutional Cross-View Pose Estimation

Abstract:
We propose a novel end-to-end method for cross-view pose estimation. Given a ground-level query image and an aerial image that covers the query's local neighborhood, the 3 Degrees-of-Freedom camera pose of the query is estimated by matching its image descriptor to descriptors of local regions within the aerial image. The orientation-aware descriptors are obtained by using a translationally equivariant convolutional ground image encoder and contrastive learning. The Localization Decoder produces a dense probability distribution in a coarse-to-fine manner with a novel Localization Matching Upsampling module. A smaller Orientation Decoder produces a vector field to condition the orientation estimate on the localization. Our method is validated on the VIGOR and KITTI datasets, where it surpasses the state-of-the-art baseline by 72% and 36% in median localization error for comparable orientation estimation accuracy. The predicted probability distribution can represent localization ambiguity, and enables rejecting possible erroneous predictions. Without re-training, the model can infer on ground images with different field of views and utilize orientation priors if available. On the Oxford RobotCar dataset, our method can reliably estimate the ego-vehicle's pose over time, achieving a median localization error under 1 m and a median orientation error of around 1 ° at 14 FPS.
More Related Videos
 06:32
Author Spotlight: Automated Deep Brain Stimulation for Parkinson's Disease - Exploring the Possibilities and Challenges of Home Monitoring
Published on: July 14, 2023
 05:49
Author Spotlight: Deciphering Electrical Networks Behind Complex Brain Activities and Disorders
Published on: November 1, 2024
Related Concept Videos
 01:25
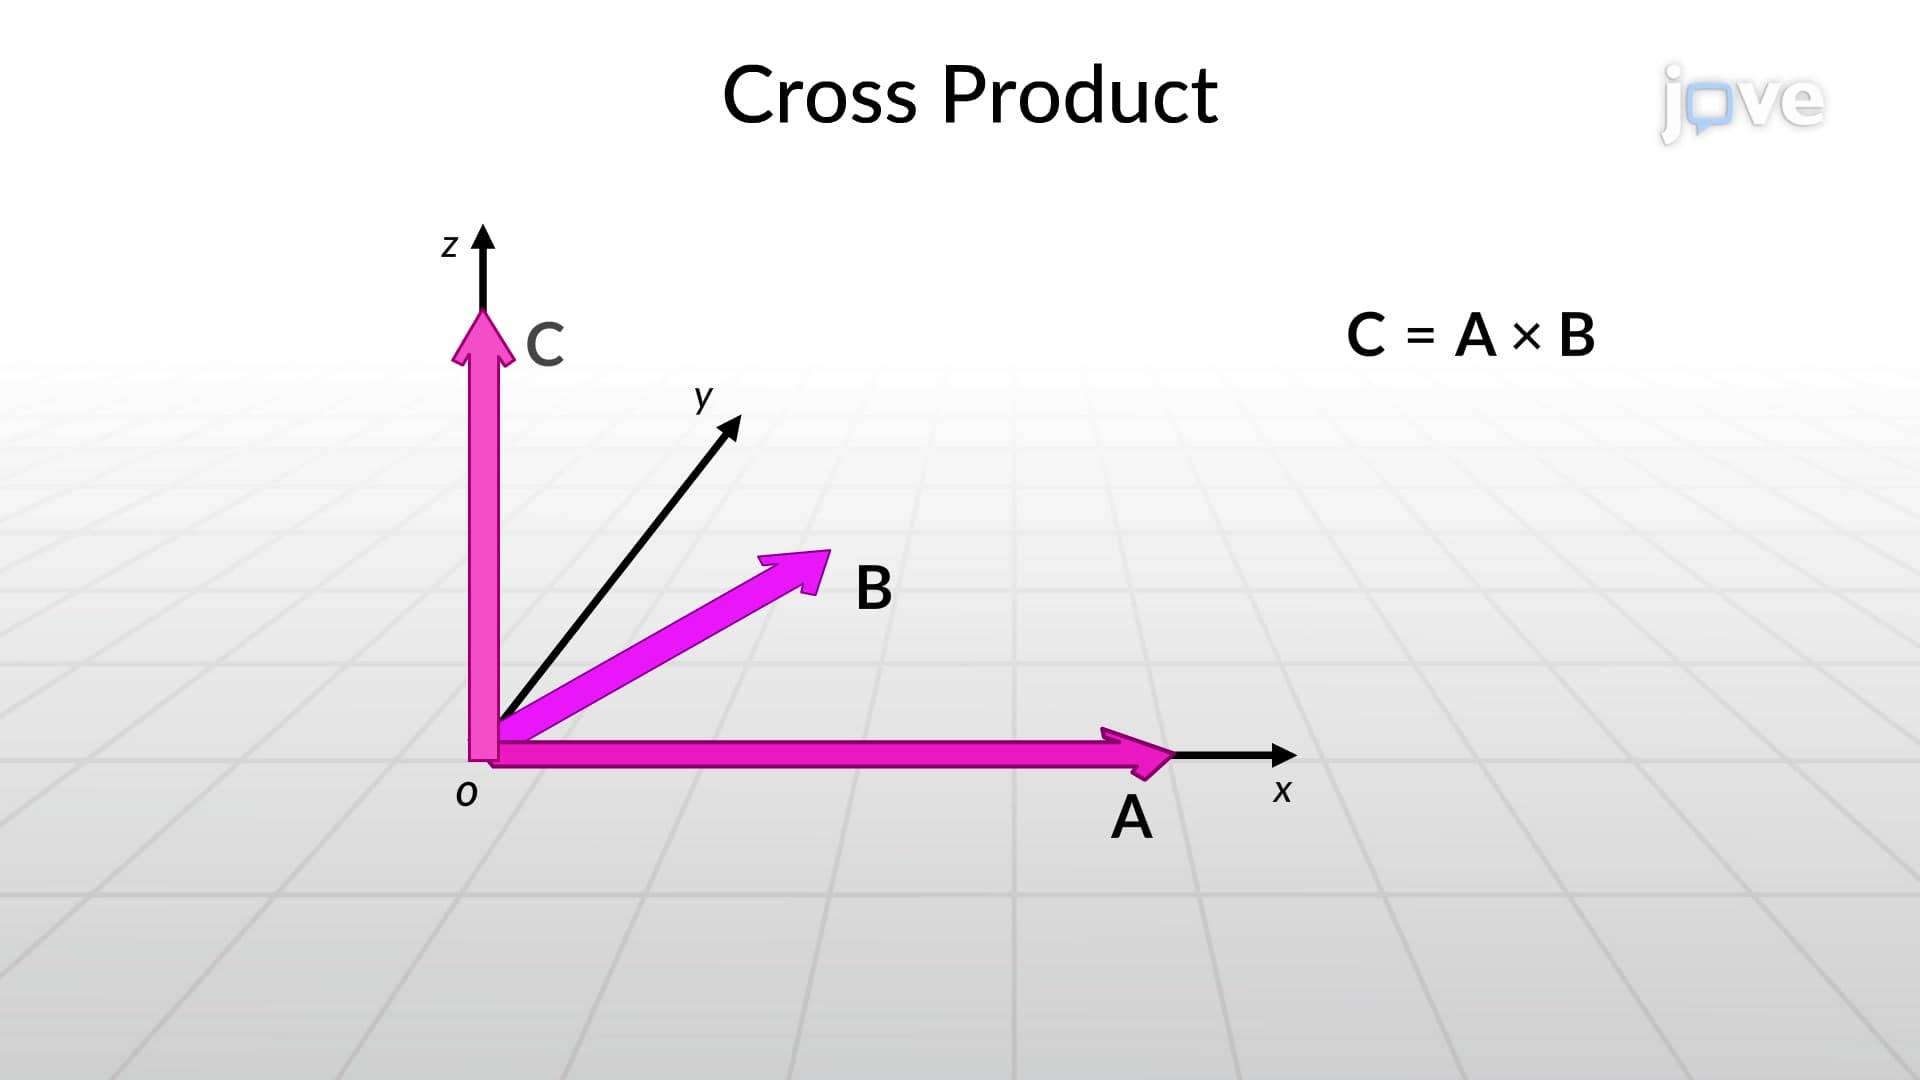
Cross Product
The magnitude of the cross product is obtained by multiplying the magnitude of both the vectors and the sine of the angle between them. This means that a larger angle between the vectors will lead to a greater magnitude of the cross product.
 01:20
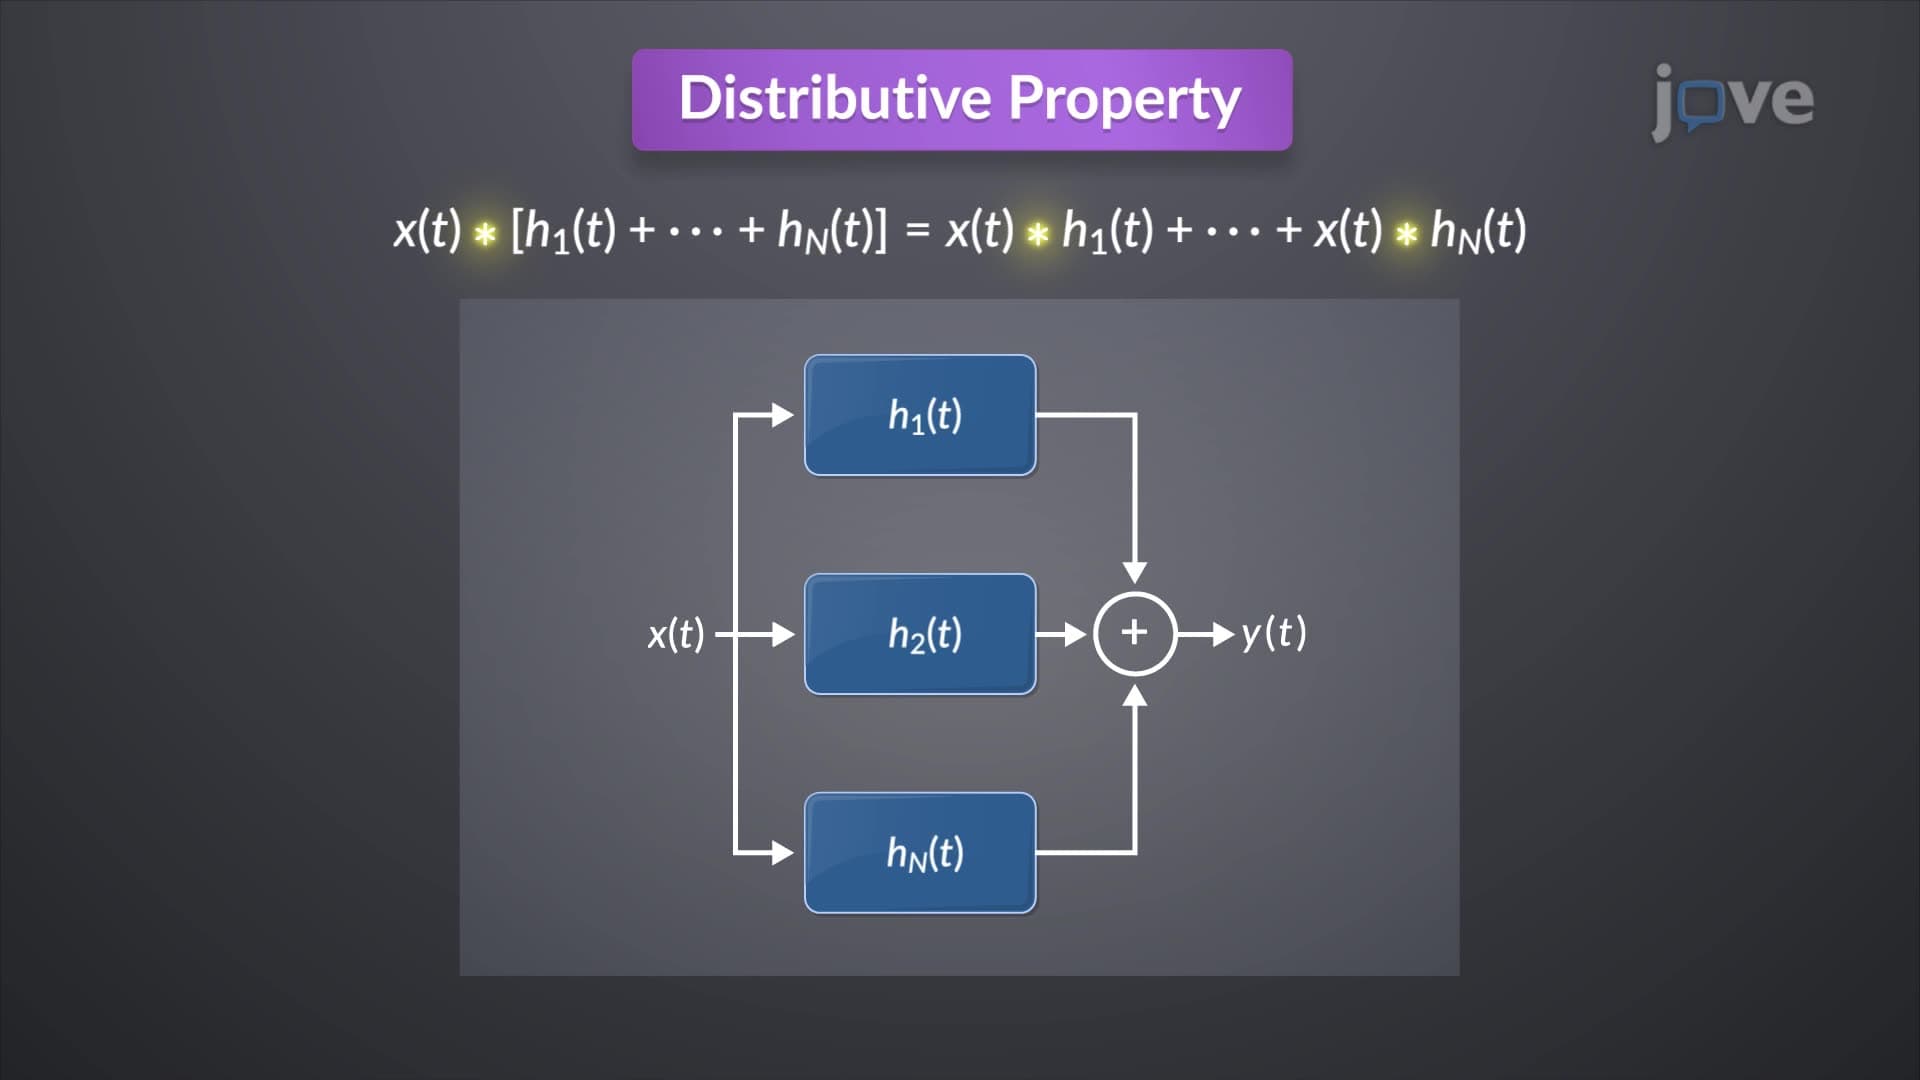
Convolution Properties I
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output:
 01:17
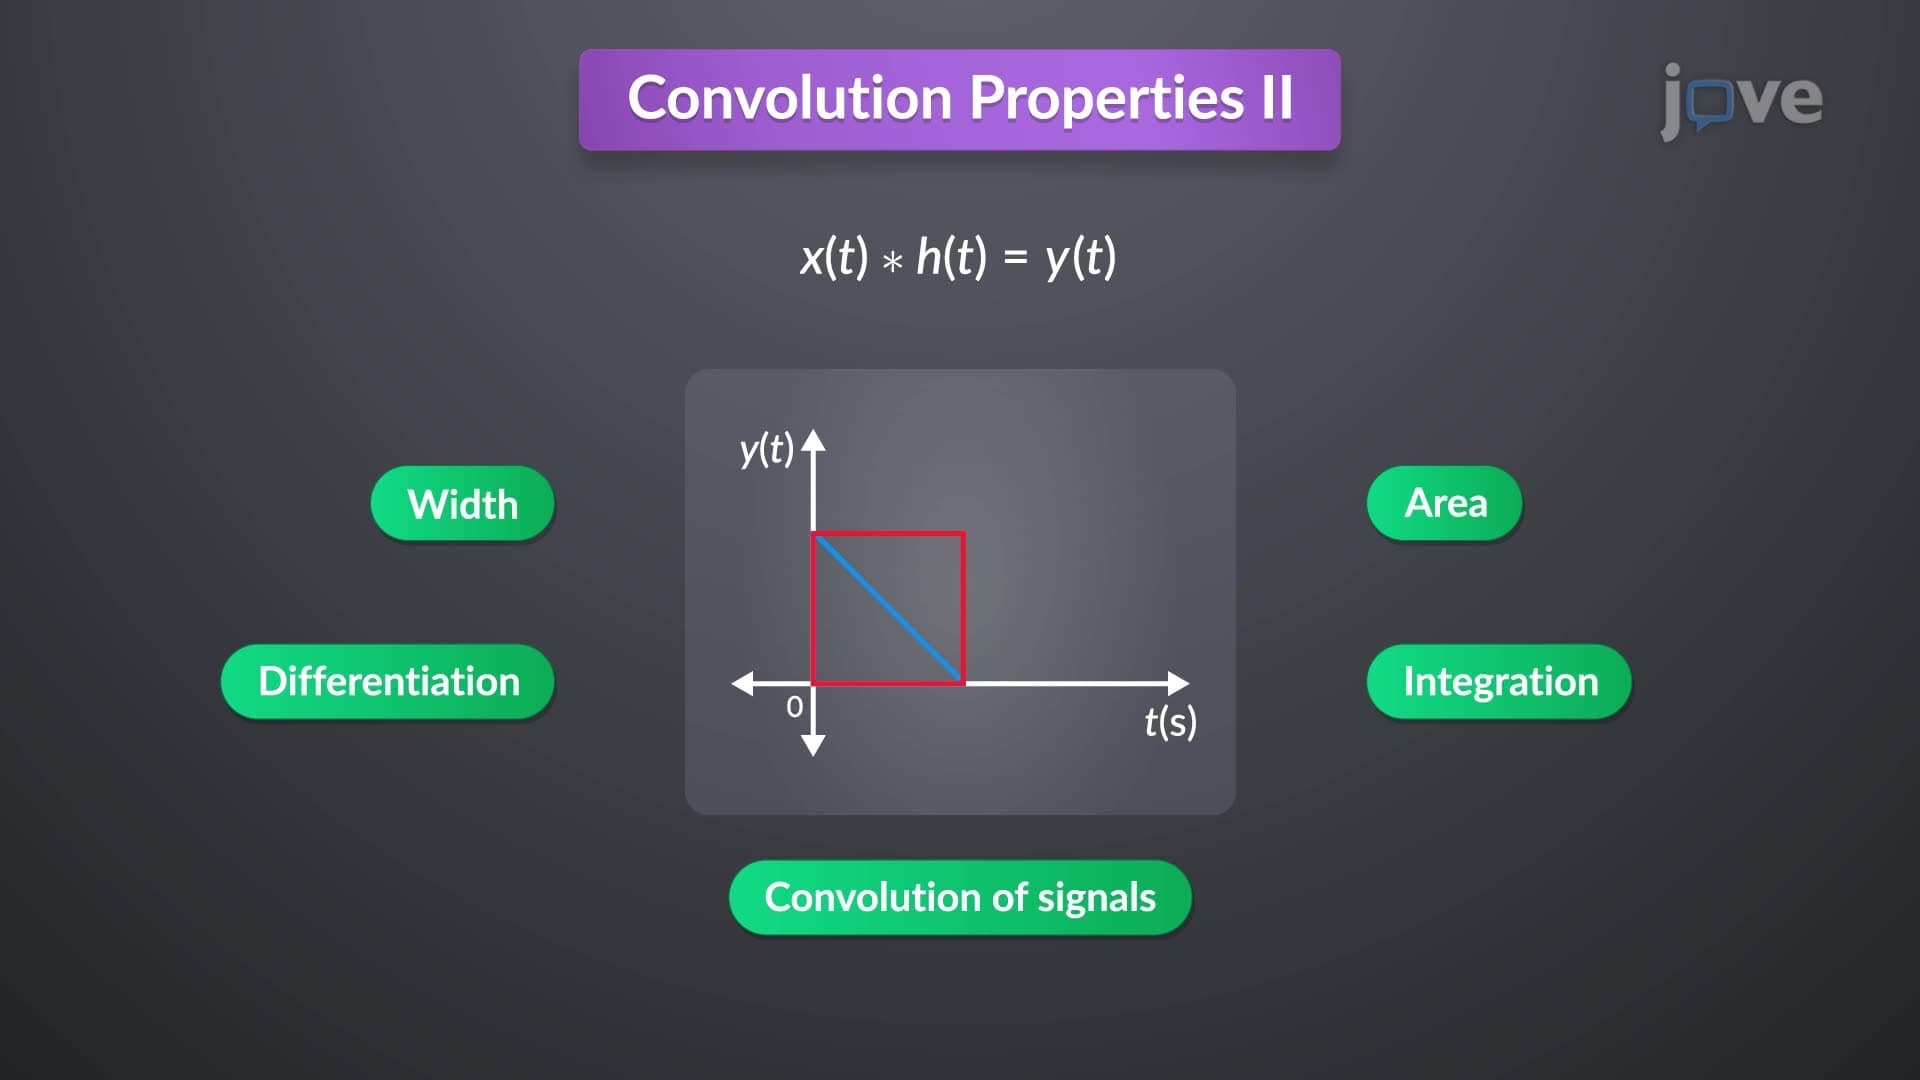
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...
 01:20
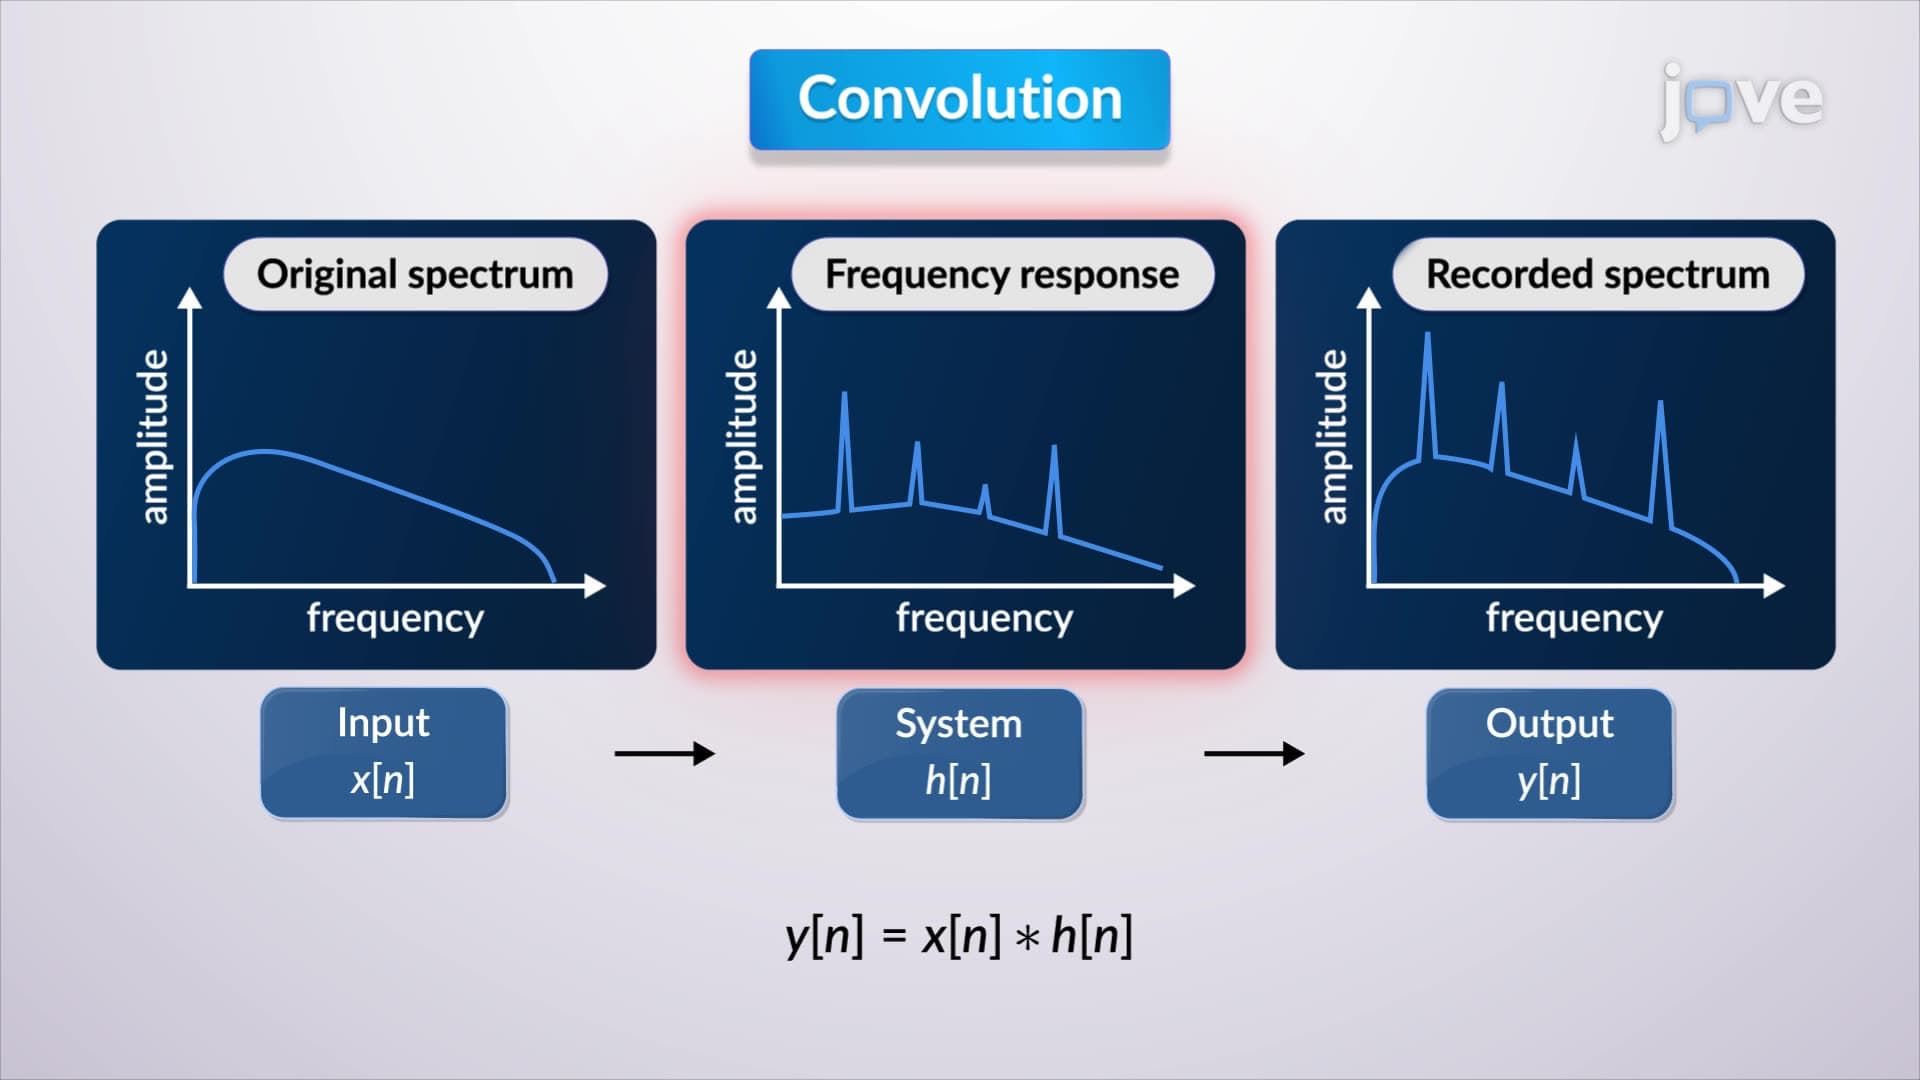
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...