Related Experiment Video
Updated: Sep 21, 2026

An in vivo Rodent Model of Contraction-induced Injury and Non-invasive Monitoring of Recovery
Published on: May 11, 2011
An Open-Source 3D-Printed Hindlimb Stabilization Apparatus for Reliable Measurement of Stimulation-Evoked Ankle
Danny V Lam1,2, Madeline Lindemann1, Kevin Yang1
1Department of Biomedical Engineering, Case Western Reserve University, Cleveland 44106, Ohio.

Abstract:
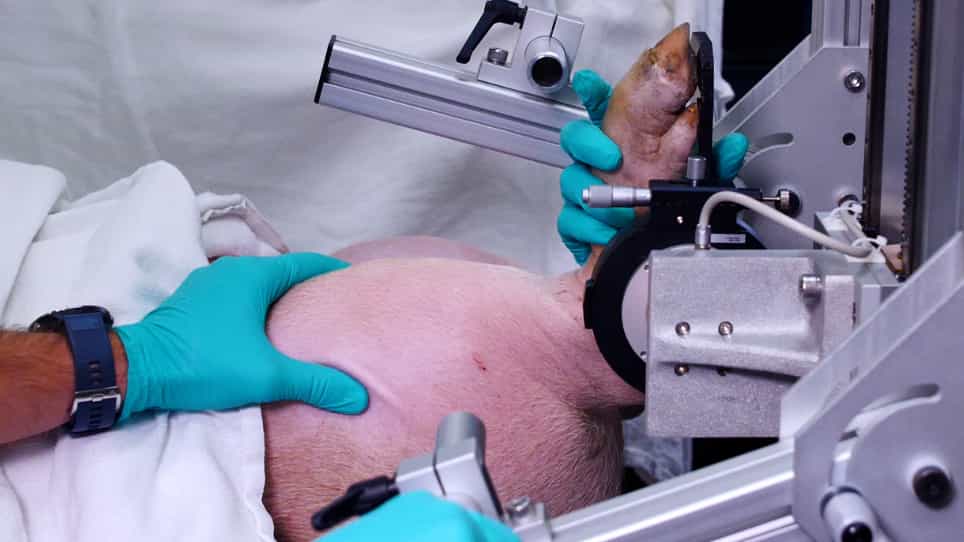
Currently there are numerous methods to evaluate peripheral nerve stimulation interfaces in rats, with stimulation-evoked ankle torque being one of the most prominent. Commercial rat ankle torque measurement systems and custom one-off solutions have been published in the literature. However, commercial systems are proprietary and costly and do not allow for customization. One-off lab-built systems have required specialized machining expertise, and building plans have previously not been made easily accessible. Here, detailed building plans are provided for a low-cost, open-source, and basic ankle torque measurement system from which additional customization can be made. A hindlimb stabilization apparatus was developed to secure and stabilize a rat's hindlimb, while allowing for simultaneous ankle-isometric torque and lower limb muscle electromyography (EMG). The design was composed mainly of adjustable 3D-printed components to accommodate anatomical differences between rat hindlimbs. Additionally, construction and calibration procedures of the rat hindlimb stabilization apparatus were demonstrated in this study. In vivo torque measurements were reliably acquired and corresponded to increasing stimulation amplitudes. Furthermore, implanted leads used for intramuscular EMG recordings complemented torque measurements and were used as an additional functional measurement in evaluating the performance of a peripheral nerve stimulation interface. In conclusion, an open-source and noninvasive platform, made primarily with 3D-printed components, was constructed for reliable data acquisition of evoked motor activity in rat models. The purpose of this apparatus is to provide researchers a versatile system with adjustable components that can be tailored to meet user-defined experimental requirements when evaluating motor function of the rat hindlimbs.