A Novel Gait Event Detection Algorithm Using a Thigh-Worn Inertial Measurement Unit and Joint Angle Information
Related Experiment Video
Updated: Jul 6, 2025
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Jacob A Strick1, Ryan J Farris2, Jerzy T Sawicki1
1Center for Rotating Machinery Dynamics and Control (RoMaDyC), Washkewicz College of Engineering, Cleveland State University, 2121 Euclid Avenue, Cleveland, OH 44115.

Abstract:
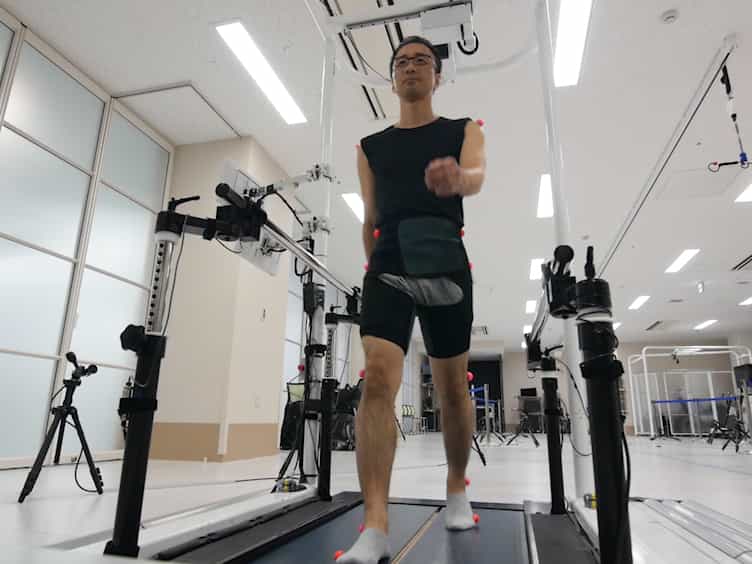
This paper describes the development and evaluation of a novel, threshold-based gait event detection algorithm utilizing only one thigh inertial measurement unit (IMU) and unilateral, sagittal plane hip and knee joint angles. The algorithm was designed to detect heel strike (HS) and toe off (TO) gait events, with the eventual goal of detection in a real-time exoskeletal control system. The data used in the development and evaluation of the algorithm were obtained from two gait databases, each containing synchronized IMU and ground reaction force (GRF) data. All database subjects were healthy individuals walking in either a level-ground, urban environment or a treadmill lab environment. Inertial measurements used were three-dimensional thigh accelerations and three-dimensional thigh angular velocities. Parameters for the TO algorithm were identified on a per-subject basis. The GRF data were utilized to validate the algorithm's timing accuracy and quantify the fidelity of the algorithm, measured by the F1-Score. Across all participants, the algorithm reported a mean timing error of -41±20 ms with an F1-Score of 0.988 for HS. For TO, the algorithm reported a mean timing error of -1.4±21 ms with an F1-Score of 0.991. The results of this evaluation suggest that this algorithm is a promising solution to inertial based gait event detection; however, further refinement and real-time evaluation are required for use in exoskeletal control.