CylinderTag: An Accurate and Flexible Marker for Cylinder-Shape Objects Pose Estimation Based on Projective Invariants
Related Experiment Video
Updated: Jul 6, 2025

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023

Abstract:
High-precision pose estimation based on visual markers has been a thriving research topic in the field of computer vision. However, the suitability of traditional flat markers on curved objects is limited due to the diverse shapes of curved surfaces, which hinders the development of high-precision pose estimation for curved objects. Therefore, this paper proposes a novel visual marker called CylinderTag, which is designed for developable curved surfaces such as cylindrical surfaces. CylinderTag is a cyclic marker that can be firmly attached to objects with a cylindrical shape. Leveraging the manifold assumption, the cross-ratio in projective invariance is utilized for encoding in the direction of zero curvature on the surface. Additionally, to facilitate the usage of CylinderTag, we propose a heuristic search-based marker generator and a high-performance recognizer as well. Moreover, an all-encompassing evaluation of CylinderTag properties is conducted by means of extensive experimentation, covering detection rate, detection speed, dictionary size, localization jitter, and pose estimation accuracy. CylinderTag showcases superior detection performance from varying view angles in comparison to traditional visual markers, accompanied by higher localization accuracy. Furthermore, CylinderTag boasts real-time detection capability and an extensive marker dictionary, offering enhanced versatility and practicality in a wide range of applications. Experimental results demonstrate that the CylinderTag is a highly promising visual marker for use on cylindrical-like surfaces, thus offering important guidance for future research on high-precision visual localization of cylinder-shaped objects.
More Related Videos
 10:07
Measurement of Dynamic Scapular Kinematics Using an Acromion Marker Cluster to Minimize Skin Movement Artifact
Published on: February 10, 2015
 05:57
Long-term Video Tracking of Cohoused Aquatic Animals: A Case Study of the Daily Locomotor Activity of the Norway Lobster Nephrops norvegicus
Published on: April 8, 2019
Related Concept Videos
 01:22
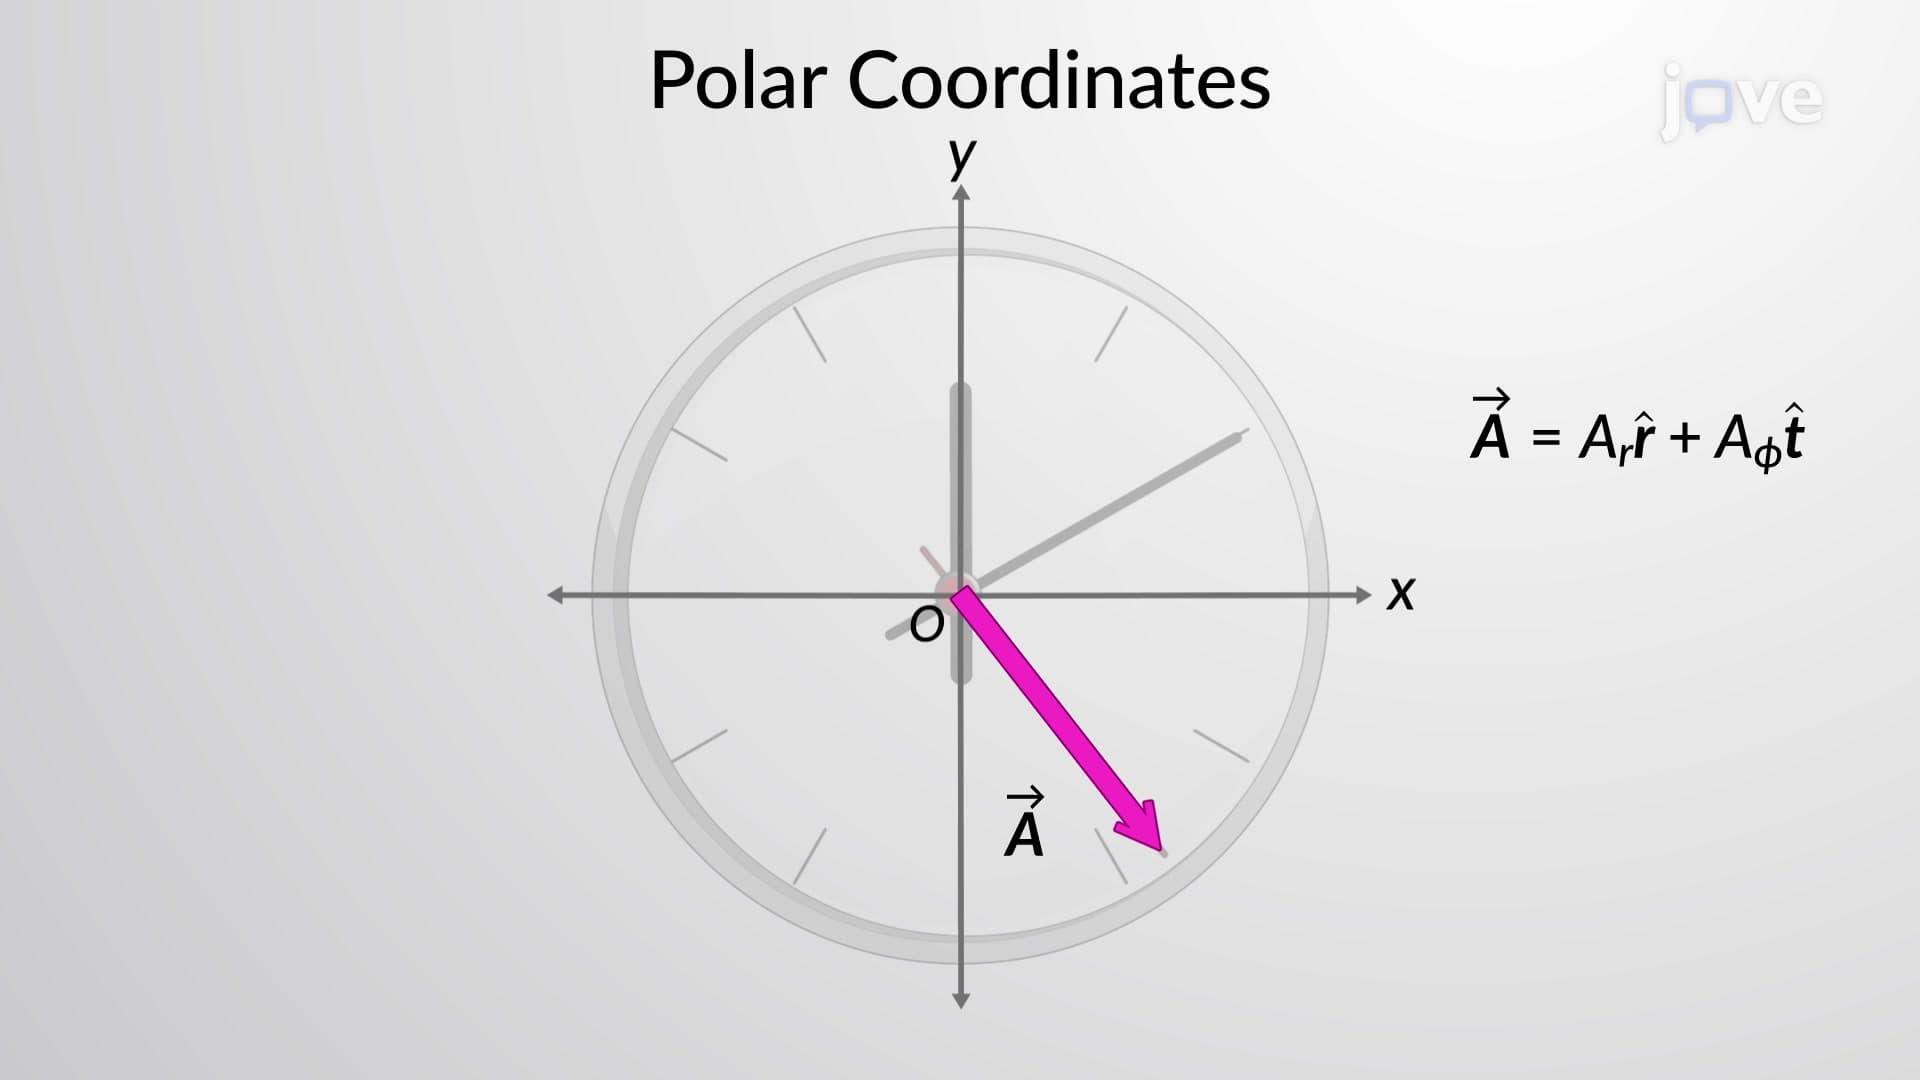
Polar and Cylindrical Coordinates
 02:06
Newman Projections
The organic molecules rotate across the single bonds leading to numerous temporary three-dimensional structures of varying energy known as...
 01:14
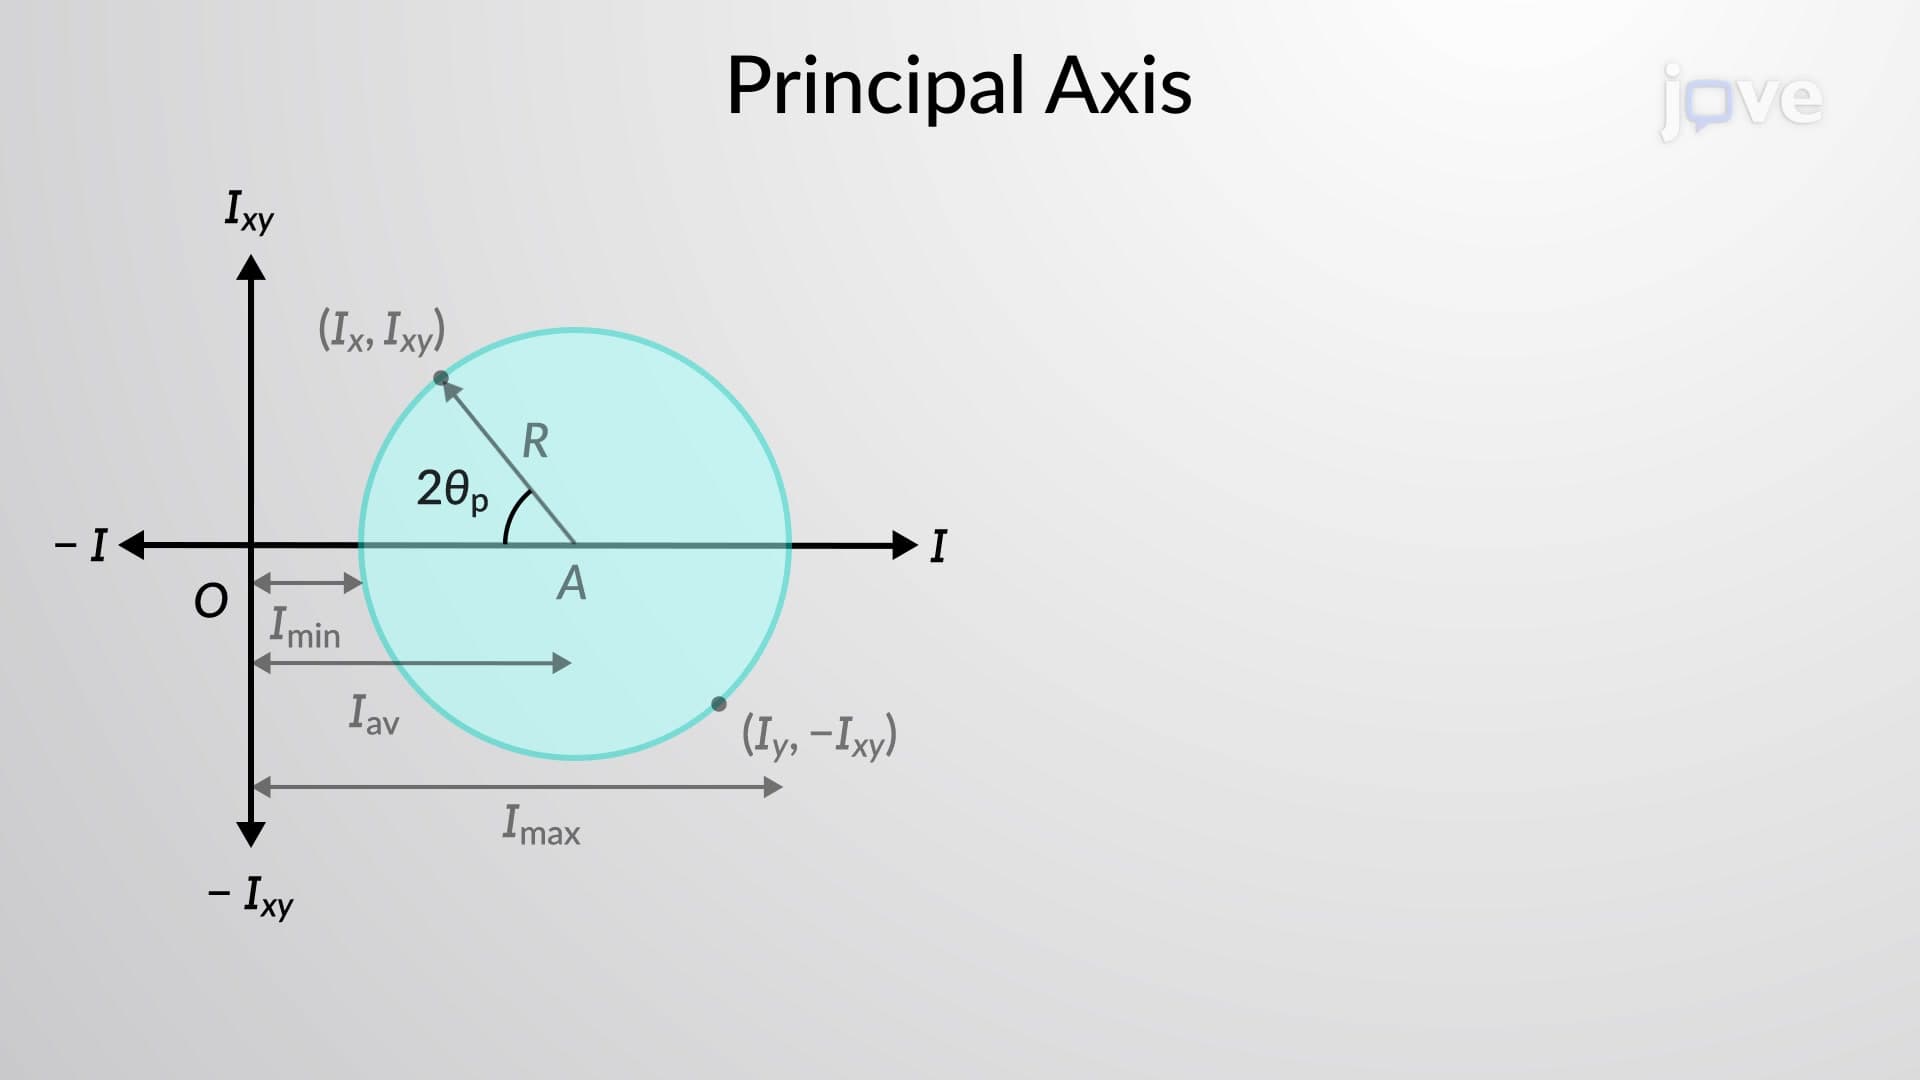
Mohr's Circle for Moments of Inertia: Problem Solving
Consider a rectangular beam. The moments of inertia of the beam about the x and y axis are 2.5(107) mm4 and 7.5(107) mm4, respectively. The product of inertia is 1.5(107) mm4. Determine the principal moments of inertia and the orientation of the major and...