Interpretable Rotation-Equivariant Quaternion Neural Networks for 3D Point Cloud Processing
Related Experiment Video
Updated: Jul 6, 2025

Author Spotlight: Insights into the Analysis of Human Interaction with 3D Virtual Objects
Published on: October 18, 2024

Abstract:
This study proposes a set of generic rules to revise existing neural networks for 3D point cloud processing to rotation-equivariant quaternion neural networks (REQNNs), in order to make feature representations of neural networks to be rotation-equivariant and permutation-invariant. Rotation equivariance of features means that the feature computed on a rotated input point cloud is the same as applying the same rotation transformation to the feature computed on the original input point cloud. We find that the rotation-equivariance of features is naturally satisfied, if a neural network uses quaternion features. Interestingly, we prove that such a network revision also makes gradients of features in the REQNN to be rotation-equivariant w.r.t. inputs, and the training of the REQNN to be rotation-invariant w.r.t. inputs. Besides, permutation-invariance examines whether the intermediate-layer features are invariant, when we reorder input points. We also evaluate the stability of knowledge representations of REQNNs, and the robustness of REQNNs to adversarial rotation attacks. Experiments have shown that REQNNs outperform traditional neural networks in both terms of classification accuracy and robustness on rotated testing samples.
Related Concept Videos
 01:16
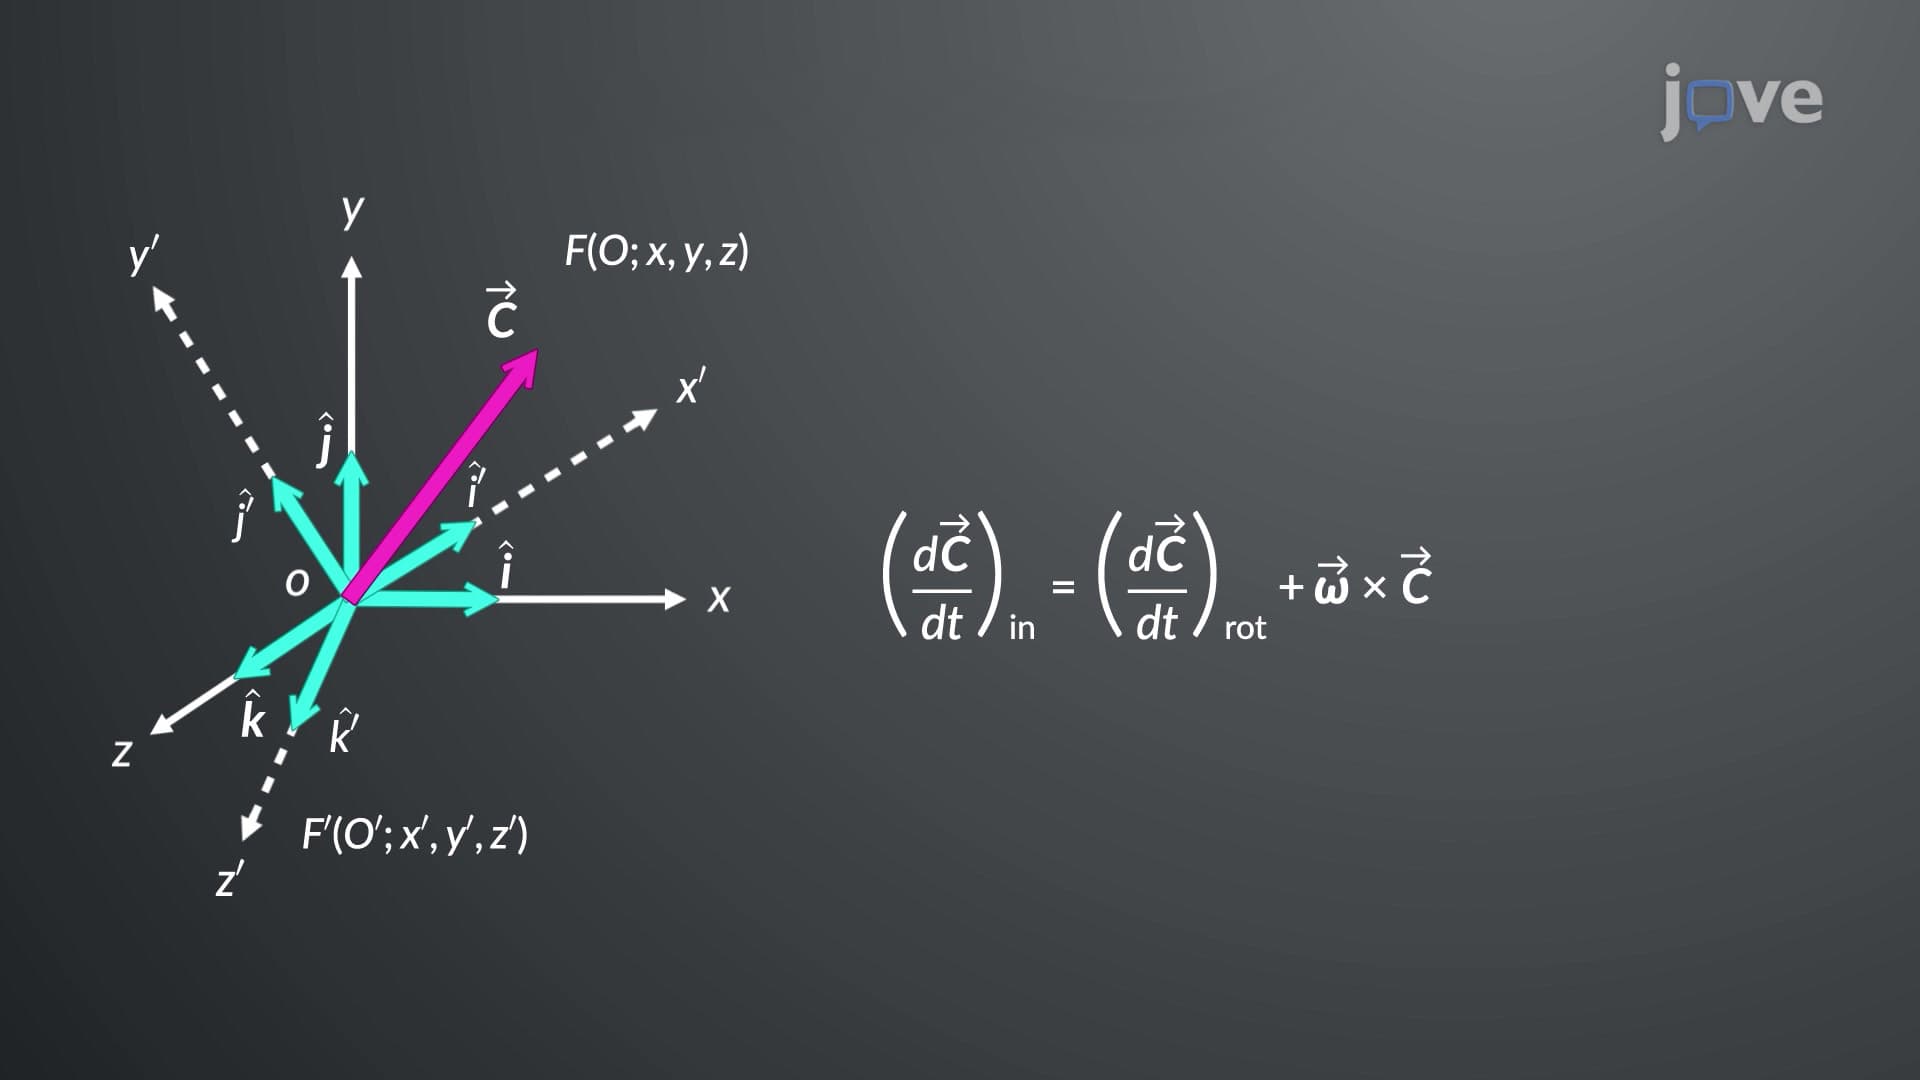
Vector Transformation in Rotating Coordinate Systems
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...