Related Experiment Video
Updated: Jul 5, 2025
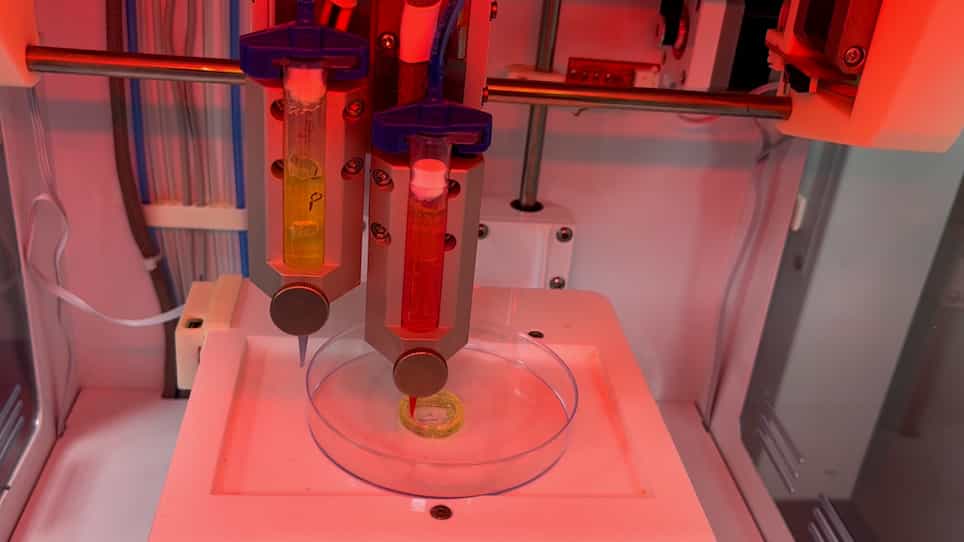

Four-Dimensional Printing of Stimuli-Responsive Hydrogel-Based Soft Robots
Published on: January 13, 2023
4D Printed Non-Euclidean-Plate Jellyfish Inspired Soft Robot in Diverse Organic Solvents
Yang Wang1, Huixia Xuan1, Luzhi Zhang1
1State Key Laboratory for Modification of Chemical Fibers and Polymer Materials, Institute of Functional Materials, College of Materials Science and Engineering, Research Base of Textile Materials for Flexible Electronics and Biomedical Applications (China Textile Engineering Society), Shanghai Engineering Research Center of Nano-Biomaterials and Regenerative Medicine, Donghua University, Shanghai, 201620, P. R. China.

Abstract:
Soft robots have the potential to assist and complement human exploration of extreme and harsh environments (i.e., organic solvents). However, soft robots with stable performance in diverse organic solvents are not developed yet. In the current research, a non-Euclidean-plate under-liquid soft robot inspired by jellyfish based on phototropic liquid crystal elastomers is fabricated via a 4D-programmable strategy. Specifically, the robot employs a 3D-printed non-Euclidean-plate, designed with Archimedean orientation, which undergoes autonomous deformation to release internal stress when immersed in organic solvents. With the assistance of near-infrared light illumination, the organic solvent inside the robot vaporizes and generates propulsion in the form of bubble streams. The developed NEP-Jelly-inspired soft robot can swim with a high degree of freedom in various organic solvents, for example, N, N-dimethylformamide, N, N-dimethylacetamide, tetrahydrofuran, dichloromethane, and trichloromethane, which is not reported before. Besides bionic jellyfish, various aquatic invertebrate-inspired soft robots can potentially be prepared via a similar 4D-programmable strategy.

