Related Experiment Video
Updated: Jul 5, 2025

Using a Split-belt Treadmill to Evaluate Generalization of Human Locomotor Adaptation
Published on: August 23, 2017
Sensorimotor adaptation of locomotor synergies to gravitational constraint
Etienne Guillaud1, Vincent Leconte2, Emilie Doat2
1Univ. Bordeaux, CNRS, INCIA, UMR 5287, F-33000, Bordeaux, France. etienne.guillaud@u-bordeaux.fr.

Abstract:
This study investigates the impact of gravity on lower limb muscle coordination during pedaling. It explores how pedaling behaviors, kinematics, and muscle activation patterns dynamically adapts to changes in gravity and resistance levels. The experiment was conducted in parabolic flights, simulating microgravity, hypergravity (1.8 g), and normogravity conditions. Participants pedaled on an ergometer with varying resistances. The goal was to identify potential changes in muscle synergies and activation strategies under different gravitational contexts. Results indicate that pedaling cadence adjusted naturally in response to both gravity and resistance changes. Cadence increased with higher gravity and decreased with higher resistance levels. Muscular activities were characterized by two synergies representing pull and push phases of pedaling. The timing of synergy activation was influenced by gravity, with a delay in activation observed in microgravity compared to other conditions. Despite these changes, the velocity profile of pedaling remained stable across gravity conditions. The findings strongly suggest that the CNS dynamically manages the shift in body weight by finely tuning muscular coordination, thereby ensuring the maintenance of a stable motor output. Furthermore, electromyography analysis suggest that neuromuscular discharge frequencies were not affected by gravity changes. This implies that the types of muscle fibers recruited during exercise in modified gravity are similar to those used in normogravity. This research has contributed to a better understanding of how the human locomotor system responds to varying gravitational conditions, shedding light on the potential mechanisms underlying astronauts' gait changes upon returning from space missions.

Related Concept Videos
 01:20
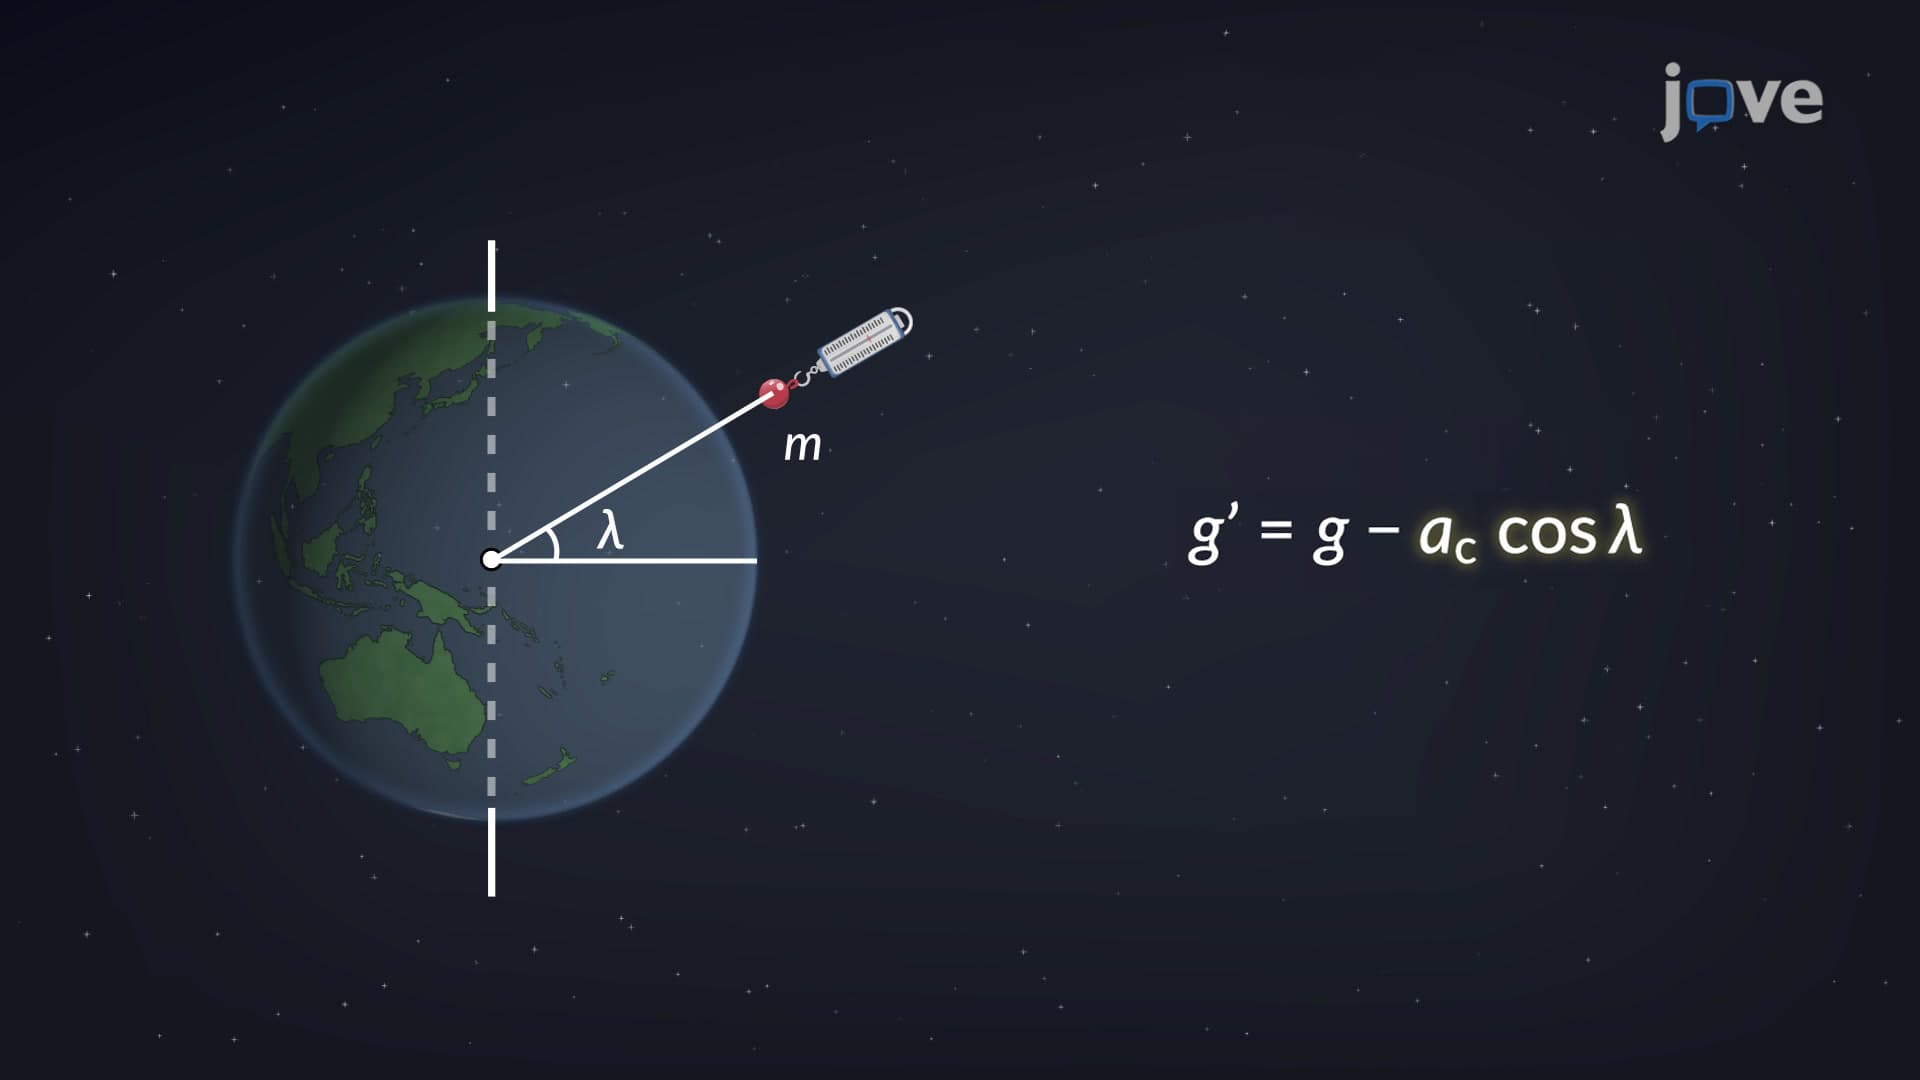
Variation in Acceleration due to Gravity near the Earth's Surface
The difference between the true and apparent weights is proportional to the square of the Earth's...
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 02:26
Responses to Gravity and Touch
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?