Related Experiment Video
Updated: Jul 5, 2025


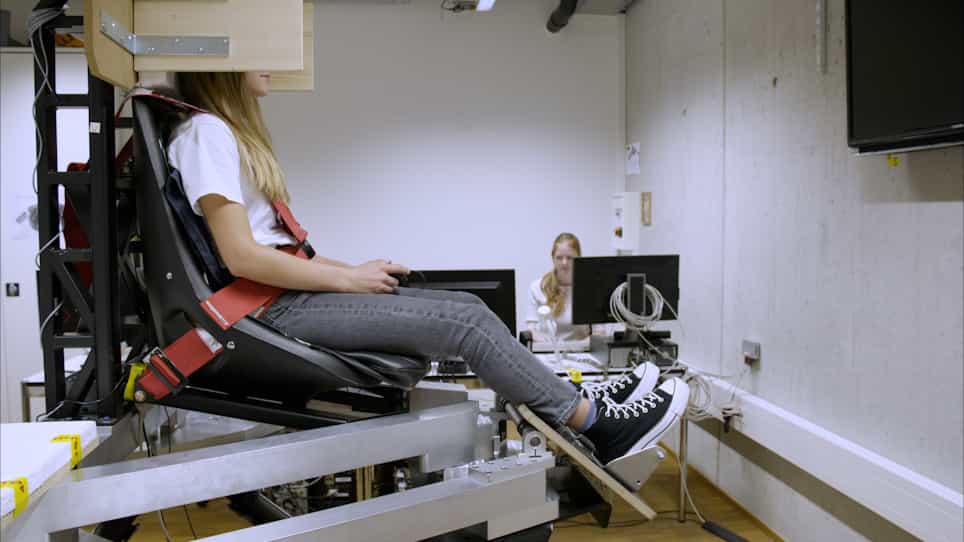
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Neural sensitivity to translational self- and object-motion velocities
Valentina Sulpizio1,2, Alessandro von Gal2, Gaspare Galati1,2
1Department of Cognitive and Motor Rehabilitation and Neuroimaging, Santa Lucia Foundation (IRCCS Fondazione Santa Lucia), Rome, Italy.

Abstract:
The ability to detect and assess world-relative object-motion is a critical computation performed by the visual system. This computation, however, is greatly complicated by the observer's movements, which generate a global pattern of motion on the observer's retina. How the visual system implements this computation is poorly understood. Since we are potentially able to detect a moving object if its motion differs in velocity (or direction) from the expected optic flow generated by our own motion, here we manipulated the relative motion velocity between the observer and the object within a stationary scene as a strategy to test how the brain accomplishes object-motion detection. Specifically, we tested the neural sensitivity of brain regions that are known to respond to egomotion-compatible visual motion (i.e., egomotion areas: cingulate sulcus visual area, posterior cingulate sulcus area, posterior insular cortex [PIC], V6+, V3A, IPSmot/VIP, and MT+) to a combination of different velocities of visually induced translational self- and object-motion within a virtual scene while participants were instructed to detect object-motion. To this aim, we combined individual surface-based brain mapping, task-evoked activity by functional magnetic resonance imaging, and parametric and representational similarity analyses. We found that all the egomotion regions (except area PIC) responded to all the possible combinations of self- and object-motion and were modulated by the self-motion velocity. Interestingly, we found that, among all the egomotion areas, only MT+, V6+, and V3A were further modulated by object-motion velocities, hence reflecting their possible role in discriminating between distinct velocities of self- and object-motion. We suggest that these egomotion regions may be involved in the complex computation required for detecting scene-relative object-motion during self-motion.

Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:15
Equilibrium and Balance
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...