Related Experiment Video
Updated: Jul 5, 2025


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Match Normalization: Learning-Based Point Cloud Registration for 6D Object Pose Estimation in the Real World

Abstract:
In this work, we tackle the task of estimating the 6D pose of an object from point cloud data. While recent learning-based approaches have shown remarkable success on synthetic datasets, we have observed them to fail in the presence of real-world data. We investigate the root causes of these failures and identify two main challenges: The sensitivity of the widely-used SVD-based loss function to the range of rotation between the two point clouds, and the difference in feature distributions between the source and target point clouds. We address the first challenge by introducing a directly supervised loss function that does not utilize the SVD operation. To tackle the second, we introduce a new normalization strategy, Match Normalization. Our two contributions are general and can be applied to many existing learning-based 3D object registration frameworks, which we illustrate by implementing them in two of them, DCP and IDAM. Our experiments on the real-scene TUD-L Hodan et al. 2018, LINEMOD Hinterstoisser et al. 2012 and Occluded-LINEMOD Brachmann et al. 2014 datasets evidence the benefits of our strategies. They allow for the first-time learning-based 3D object registration methods to achieve meaningful results on real-world data. We therefore expect them to be key to the future developments of point cloud registration methods.
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:12
Modeling and Similitude
 01:03
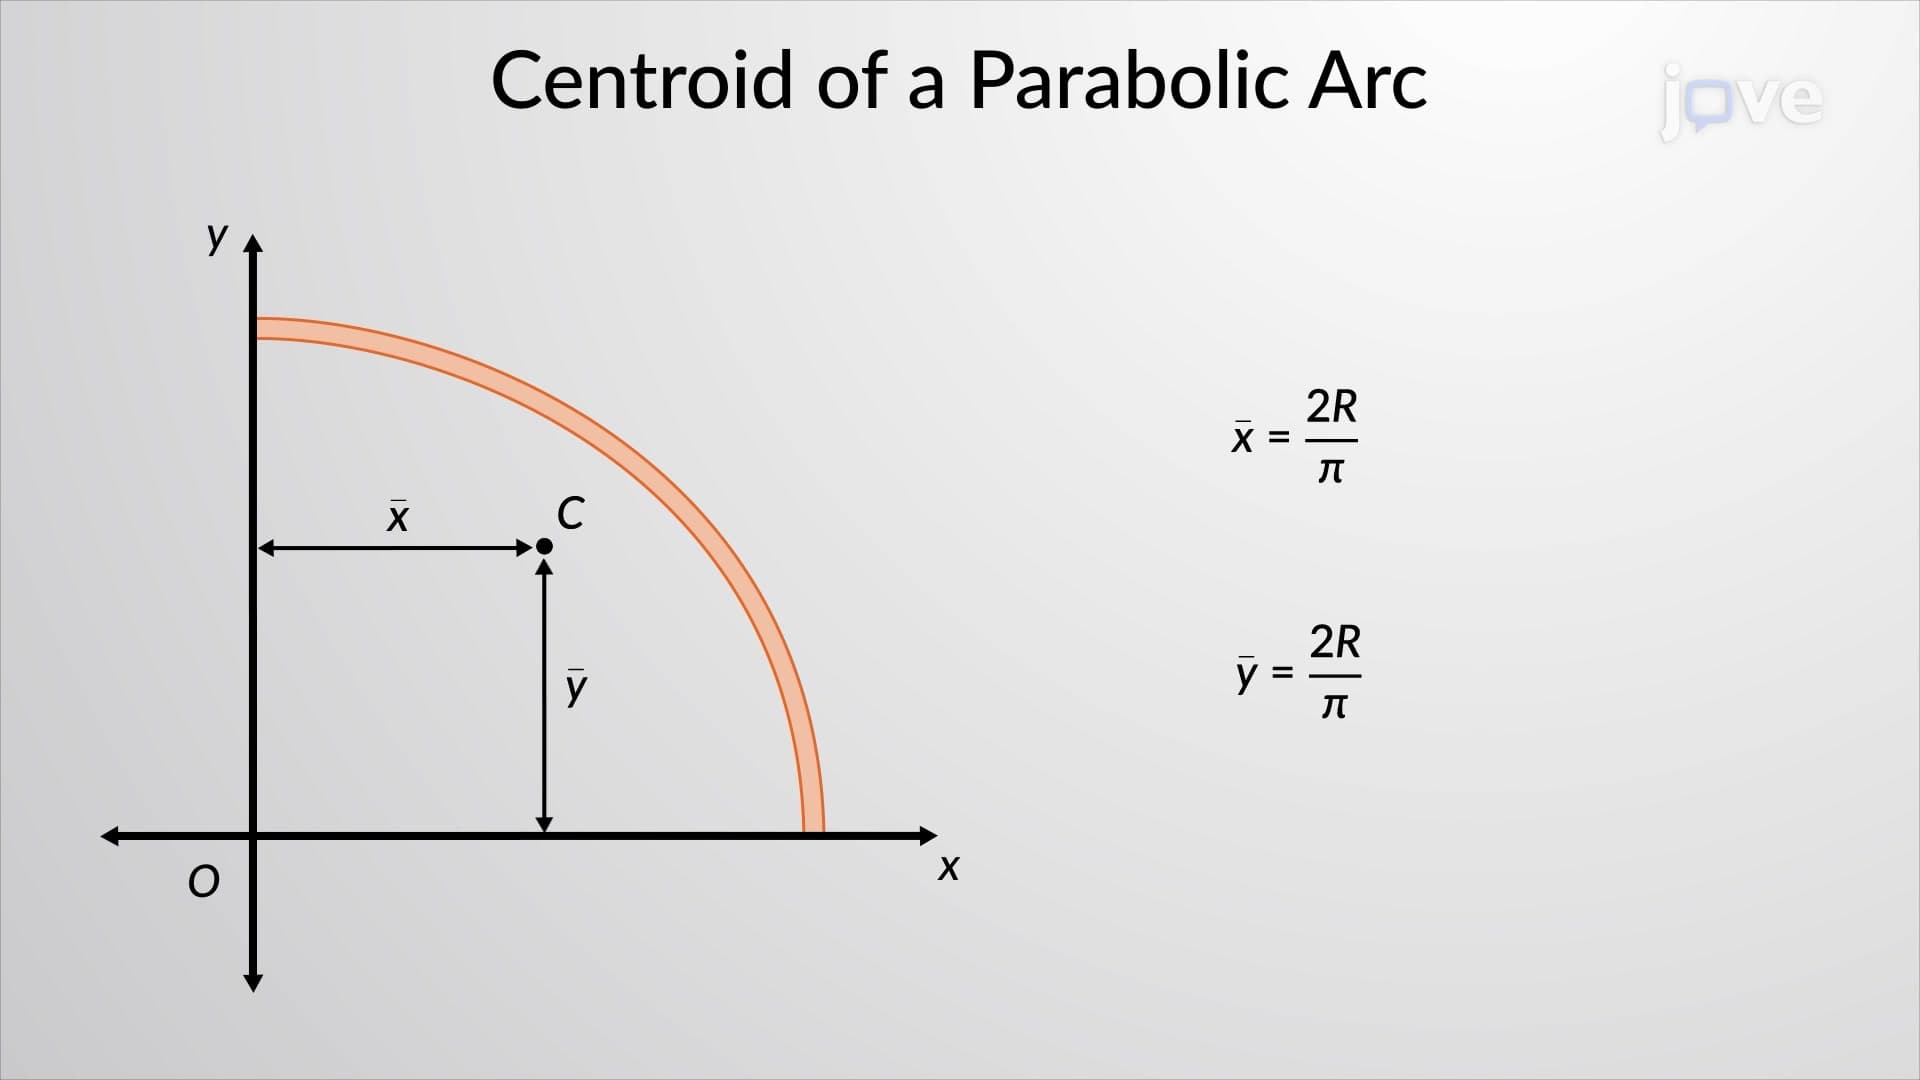
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...
 01:21
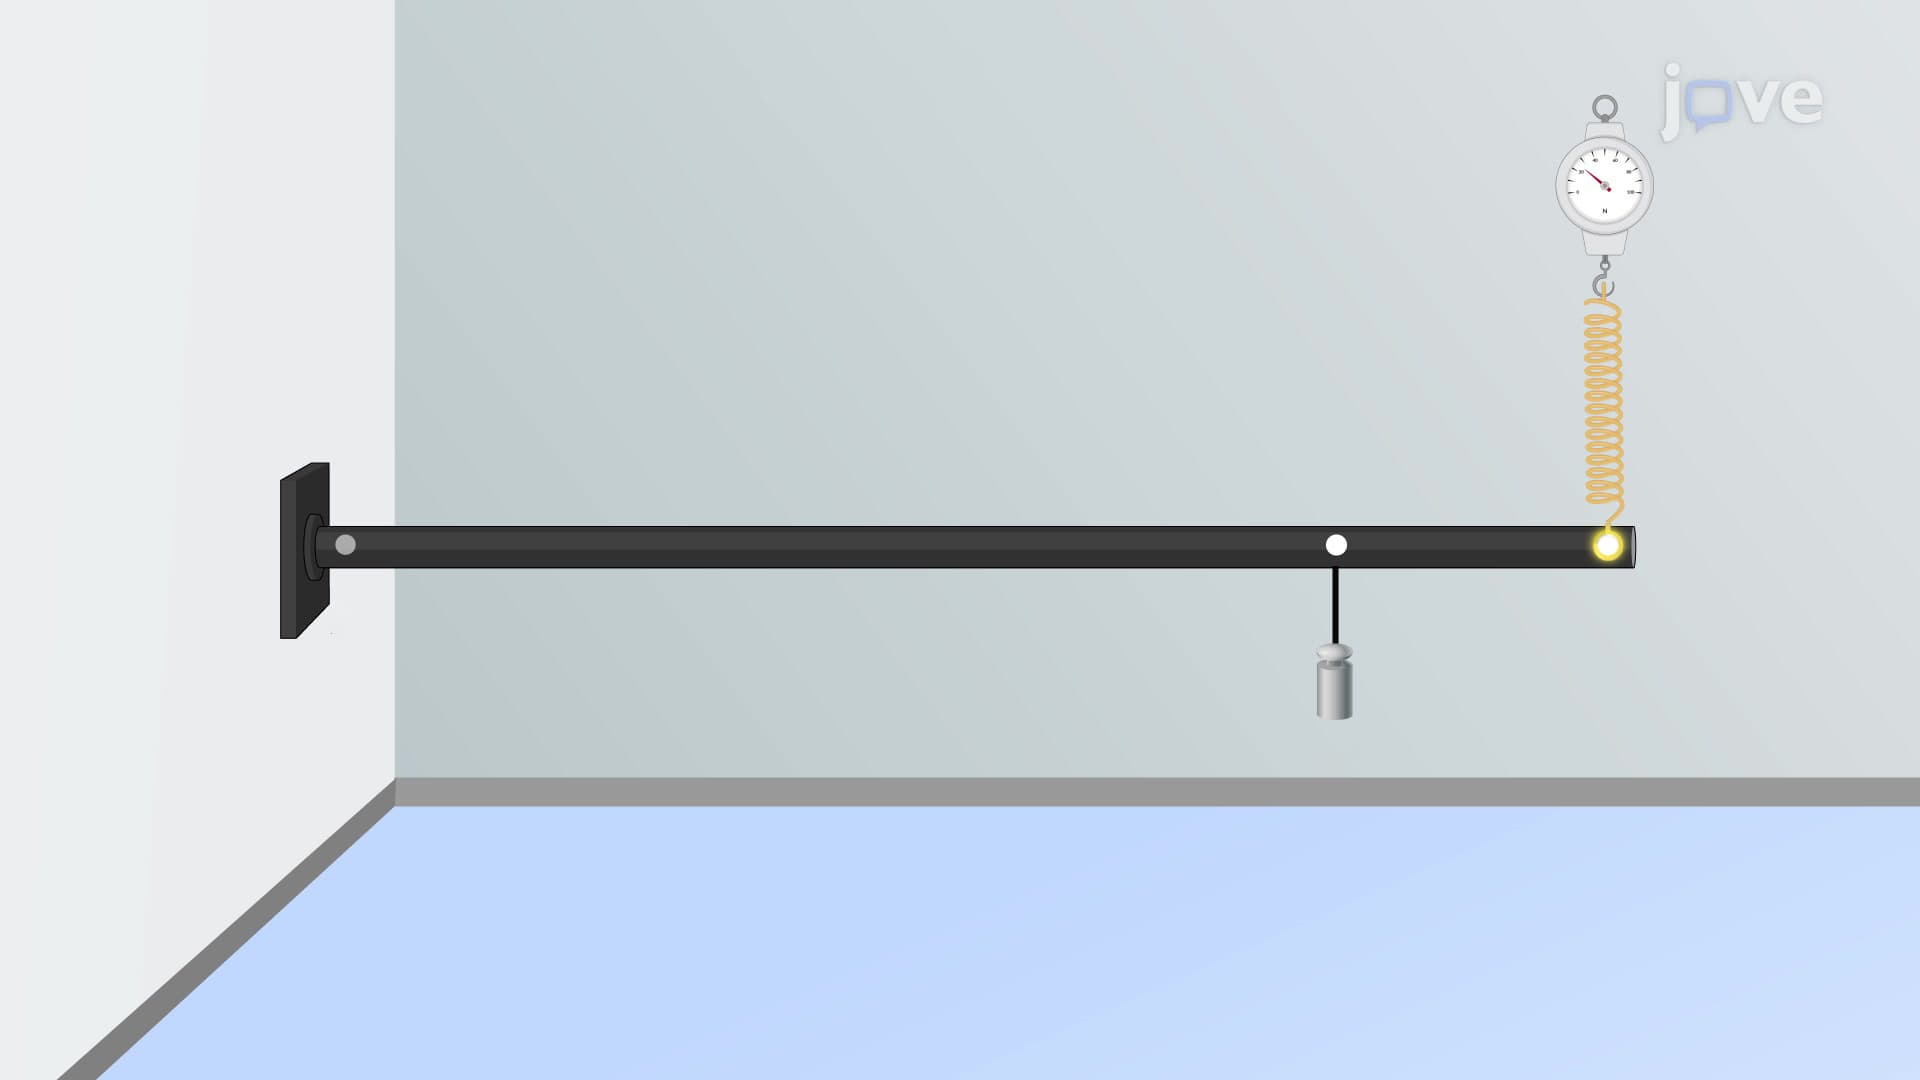
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?