Related Experiment Video
Updated: Jul 4, 2025
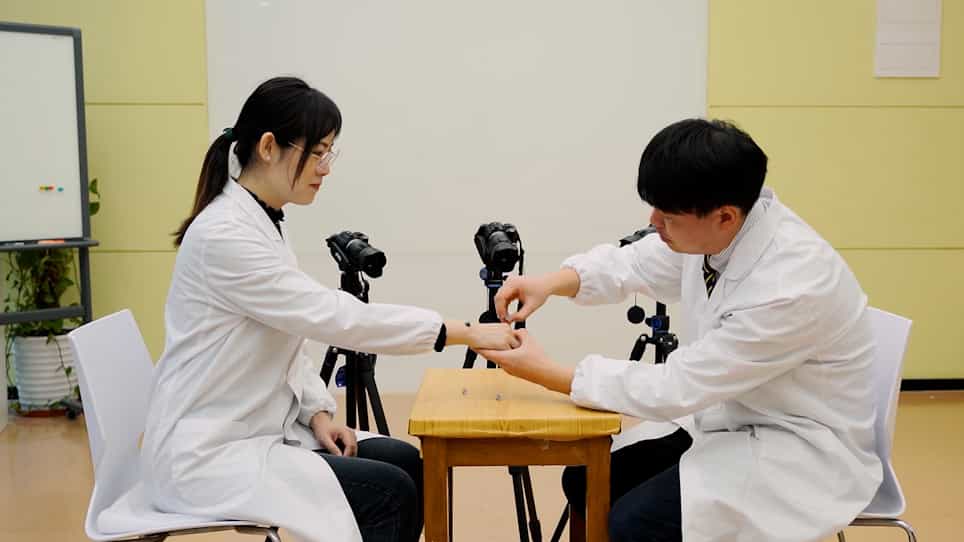

Three-Dimensional Finger Motion Tracking during Needling: A Solution for the Kinematic Analysis of Acupuncture Manipulation
Published on: October 28, 2021
A marker-based approach to determine the centers of rotation of finger joints
Martina Lapresa1, Eugenio Guglielmelli1, Loredana Zollo1
1Research Unit of Advanced Robotics and Human-Centred Technologies, Università Campus Bio-Medico di Roma, Via Alvaro del Portillo, 21, Roma, 00128, Italy.

Background And Objective:
The methods proposed in literature to estimate the position of hand joints Centers of Rotation (CoRs) typically require computationally non-trivial optimization routines and exploit a high number of markers to calculate CoRs positions from surface marker trajectories. Moreover, most of the existing works evaluated the accuracy only in simulation. This work proposes a new procedure, based on the Pratt circle fit, to estimate joints CoRs position in 2D through marker-based acquisitions.
Methods:
The advantage of the Pratt circle fit lies in its simplicity and computational speed, and in the possibility of exploiting a reduced markerset for calculating CoRs. By applying simplifying assumptions regarding the movement of the fingers (i.e., planar and decoupled flexion-extension movements of each joint occurring in the same flexion plane for all the joints of the finger), it is possible to determine the position of the CoR of each joint in 2D. For this reason, the estimation of the Carpo-MetaCarpal joint of the thumb was not included in this work, as it exhibits a more complex movement associated to the combination of a flexion-extension and adduction-abduction degree of freedom. The errors in estimating CoRs were evaluated by conducting experimental acquisitions on an anthropomorphic robotic hand and comparing the position of the estimated CoR with the real position of the CoR. The repeatability of the method and its capability to estimate anatomically plausible CoRs were evaluated through experimental acquisitions conducted on five healthy volunteers.
Results:
Errors in estimating finger joints CoRs were in the order of 0.70 mm and 0.18 mm respectively along the finger longitudinal direction (i.e., x coordinate) and thickness (i.e., y coordinate). Standard Deviations of CoRs positions were comparable to the ones obtained in literature (i.e., below 2 mm and 1 mm respectively for the x and y coordinates), thus demonstrating the repeatability of the method. The Anatomical Plausibility Rate of the proposed approach was between 80% and 100%.
Conclusions:
The performance of the Pratt-based CoRs estimation procedure proposed in this work was comparable to other existing methods, with the advantage of exploiting a simple fitting algorithm and a reduced markerset with respect to the state-of-the-art techniques.

Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:26
Rotational Motion about a Fixed Axis
 01:09
Bones of the Upper Limb: Radius
The radius has a nail-shaped head, and a...
 01:10
Mohr's Circle for Moments of Inertia