Related Experiment Video
Updated: Jul 3, 2025


Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
YOLOv7-TS: A Traffic Sign Detection Model Based on Sub-Pixel Convolution and Feature Fusion
Shan Zhao1, Yang Yuan1, Xuan Wu1
1School of Software, Henan Polytechnic University, Jiaozuo 454000, China.

Abstract:
In recent years, significant progress has been witnessed in the field of deep learning-based object detection. As a subtask in the field of object detection, traffic sign detection has great potential for development. However, the existing object detection methods for traffic sign detection in real-world scenes are plagued by issues such as the omission of small objects and low detection accuracies. To address these issues, a traffic sign detection model named YOLOv7-Traffic Sign (YOLOv7-TS) is proposed based on sub-pixel convolution and feature fusion. Firstly, the up-sampling capability of the sub-pixel convolution integrating channel dimension is harnessed and a Feature Map Extraction Module (FMEM) is devised to mitigate the channel information loss. Furthermore, a Multi-feature Interactive Fusion Network (MIFNet) is constructed to facilitate enhanced information interaction among all feature layers, improving the feature fusion effectiveness and strengthening the perception ability of small objects. Moreover, a Deep Feature Enhancement Module (DFEM) is established to accelerate the pooling process while enriching the highest-layer feature. YOLOv7-TS is evaluated on two traffic sign datasets, namely CCTSDB2021 and TT100K. Compared with YOLOv7, YOLOv7-TS, with a smaller number of parameters, achieves a significant enhancement of 3.63% and 2.68% in the mean Average Precision (mAP) for each respective dataset, proving the effectiveness of the proposed model.
Related Concept Videos
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:20
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:17
Convolution Properties II
The width property indicates that if the durations of input signals are T1 and T2, then the width of the output response equals the sum of both durations, irrespective of the shapes of the two functions. For instance, convolving two rectangular pulses with durations of 2 seconds and 1 second results in a function with a width of 3 seconds.
The area property asserts that the area under the...
 01:20
Convolution Properties I
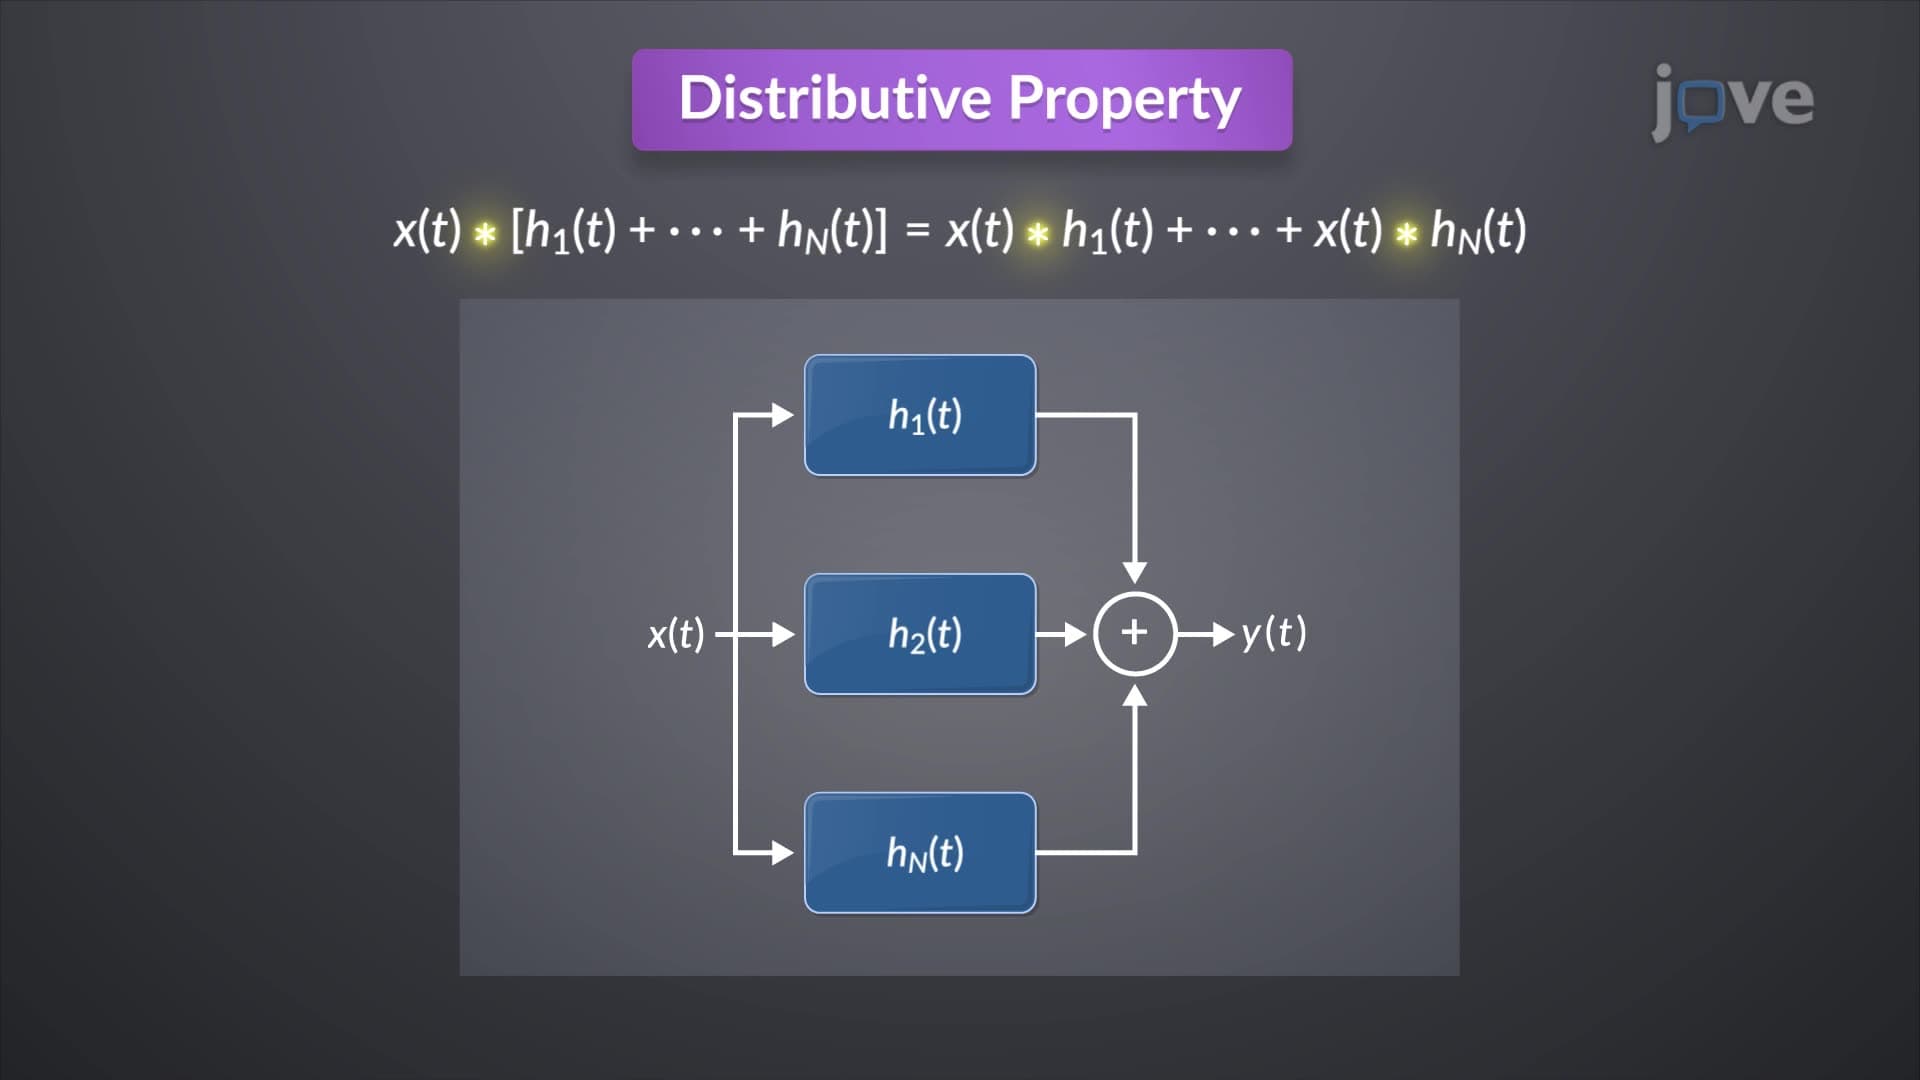
The commutative property reveals that the input and the impulse response of an LTI (Linear Time-Invariant) system can be interchanged without affecting the output: