Related Experiment Video
Updated: Jul 3, 2025
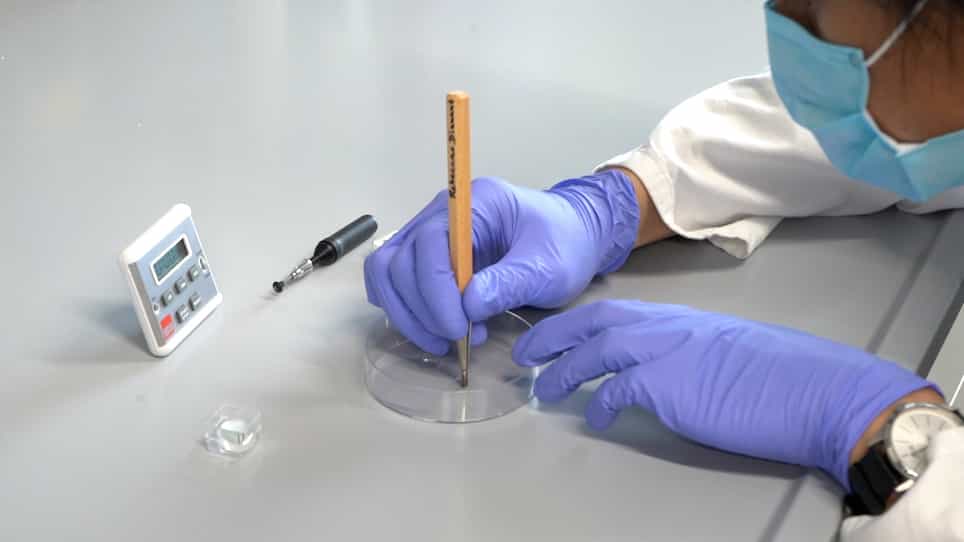

Control of Cell Adhesion using Hydrogel Patterning Techniques for Applications in Traction Force Microscopy
Published on: January 29, 2022
A fast continuous time approach for non-smooth convex optimization using Tikhonov regularization technique
1Faculty of Mathematics, University of Vienna, Oskar-Morgenstern-Platz 1, 1090 Vienna, Austria.

Abstract:
In this paper we would like to address the classical optimization problem of minimizing a proper, convex and lower semicontinuous function via the second order in time dynamics, combining viscous and Hessian-driven damping with a Tikhonov regularization term. In our analysis we heavily exploit the Moreau envelope of the objective function and its properties as well as Tikhonov regularization properties, which we extend to a nonsmooth case. We introduce the setting, which at the same time guarantees the fast convergence of the function (and Moreau envelope) values and strong convergence of the trajectories of the system to a minimal norm solution-the element of the minimal norm of all the minimizers of the objective. Moreover, we deduce the precise rates of convergence of the values for the particular choice of parameters. Various numerical examples are also included as an illustration of the theoretical results.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:11
Continuous -time Fourier Transform
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:11
Sampling Continuous Time Signal
In the...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...