Related Experiment Video
Updated: Jul 3, 2025
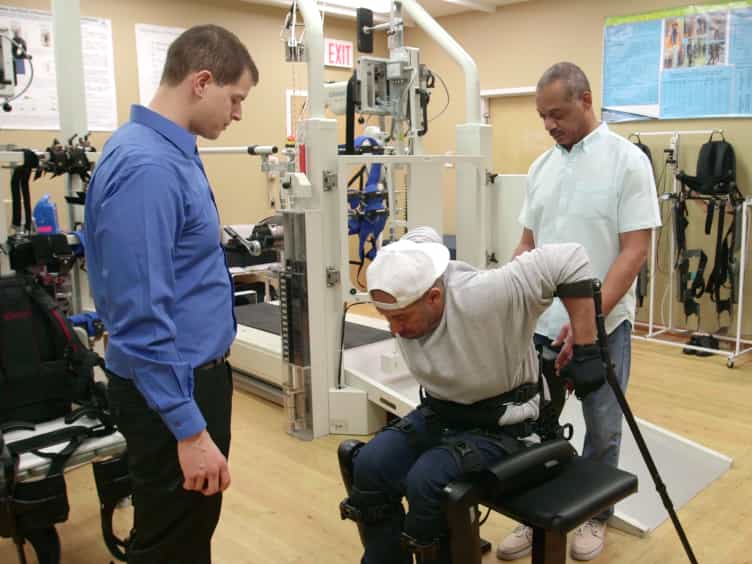

Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Perspectives of wheelchair users with chronic spinal cord injury following a walking program using a wearable robotic
Claude Vincent1,2, Frédéric S Dumont2, Manon Rogers2
1School of Rehabilitation Sciences, Faculty of Medicine, Université Laval, Québec, Canada.

Purpose:
To examine the perspectives of wheelchair users with spinal cord injury (WUSCI) regarding their participation in a 16-week walking program using a wearable robotic exoskeleton (WRE); and explore concerns and expectations regarding potential use of this device and intervention in the context of a home or community-based adapted physical activity program.
Method:
Semi-structured interviews were conducted using a narrative research, 3 weeks post-intervention. Thematic analysis resulted in 6 themes and 21 subthemes.
Results:
Seven men and 4 women aged between 32 and 72 years were interviewed; 8 of them had a complete SCI. After the walking program, WUSCI reported positive psychological aspects (having fun and motivation) and experiencing improvements in physical aspects (strength, endurance, balance and flexibility, blood circulation and intestinal transit). The structural aspects of the WRE device were acceptable in a lab with research personnel (appearance, size, weight, and comfort). Participants had concerns about safety on uneven surfaces, and possibility of falling. They expressed the desire to use the WRE for more life habits than just walking.
Conclusion:
This is the first study in which WUSCI report that the WRE should be implemented in initial rehabilitation. Lack of availability for community use after rehabilitation remains a concern.
More Related Videos
 05:54
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 06:44
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020