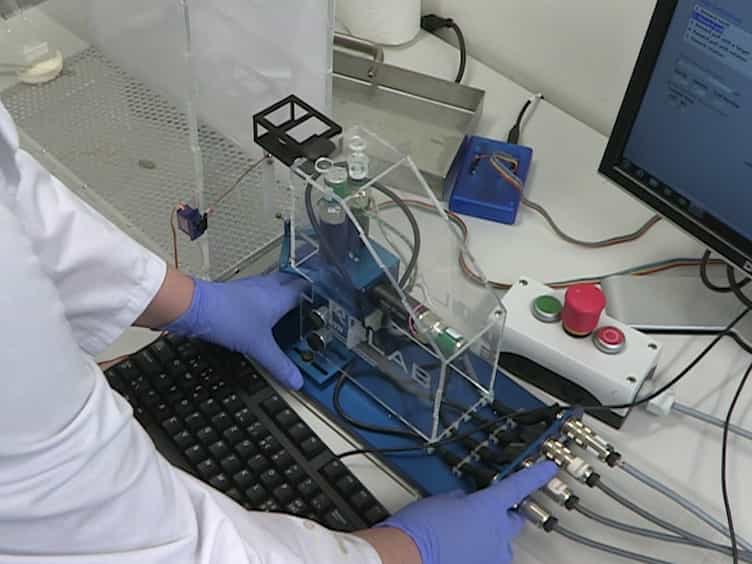
Related Experiment Video
Updated: Jul 2, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
A Kinetostatic Model for Concentric Push-Pull Robots
1EndoTheia, Inc., Nashville, TN.

Abstract:
Concentric push-pull robots (CPPR) operate through the mechanical interactions of concentrically nested, laser-cut tubes with offset stiffness centers. The distal tips of the tubes are attached to each other, and relative displacement of the tube bases generates bending in the CPPR. Previous CPPR kinematic models assumed two tubes, planar shapes, no torsion, and no external loads. In this paper, we develop a new, more general CPPR model accounting for any number of tubes, describing their variable-curvature 3D shape when actuated, including the effects of torsion and external loads. To accomplish this, we employ a modified Kirchhoff rod model for each tube (with offset stiffness center) and embed the constraints of concentricity. We use an energy method to determine robot shape as a function of actuation and external loading. We experimentally validate this kinetostatic model on prototype CPPRs with two tubes and three tubes and non-constant laser-cut patterns that create variable curvature and stiffness. Experimental results agree with the model, paving the way for use of this model in design optimization, planning, and control of CPPRs.

Related Concept Videos
 01:43
The Movement of Organelles and Vesicles
 01:05
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:14
Stability of structures
 01:23
Simplification of a Force and Couple System: II
 01:13
Kinetic Energy for a Rigid Body
 01:15
Kinematic Equations: Problem Solving