

Integrated Fault-Tolerant Control Design With Sampled-Output Measurements for Interval Type-2 Takagi-Sugeno Fuzzy

Abstract:
This article is concerned with the integrated design of fault estimation (FE) and fault-tolerant control (FTC) for uncertain nonlinear systems suffering from actuator faults and external disturbance. The uncertain nonlinear systems are characterized as the interval type-2 (IT2) Takagi-Sugeno (T-S) fuzzy model, and IT2 membership functions are employed to effectively handle uncertainties. A fuzzy observer, utilizing only sampled-output measurements, is applied to simultaneously estimate actuator faults and system states. Based on the estimation, the fault-tolerant controller is designed to ensure the system stability under a predefined H∞ performance. The sampling behavior complicates the system dynamics and makes the integrated FTC design more challenging. To confront this issue, the discontinuous Lyapunov functional technique is exploited to enhance stability results by considering the sampling characteristic, upon which FE and FTC units are co-designed in the linear matrix inequality (LMI) framework. To further relax stability criteria, the analysis process incorporates the bound information of membership functions through the membership-function-dependent (MFD) method. Additionally, the relationship of mismatched premise variables resulting from the sampling scheme is also taken into account. Moreover, considering the imperfect premise matching (IPM) framework, the proposed fault-tolerant controller provides greater flexibility in selecting the shapes of membership functions and number of fuzzy rules that can vary from the counterpart of the fuzzy system. Finally, the efficacy of the proposed FTC technique is validated through a detailed numerical example.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Control Systems
At the heart...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
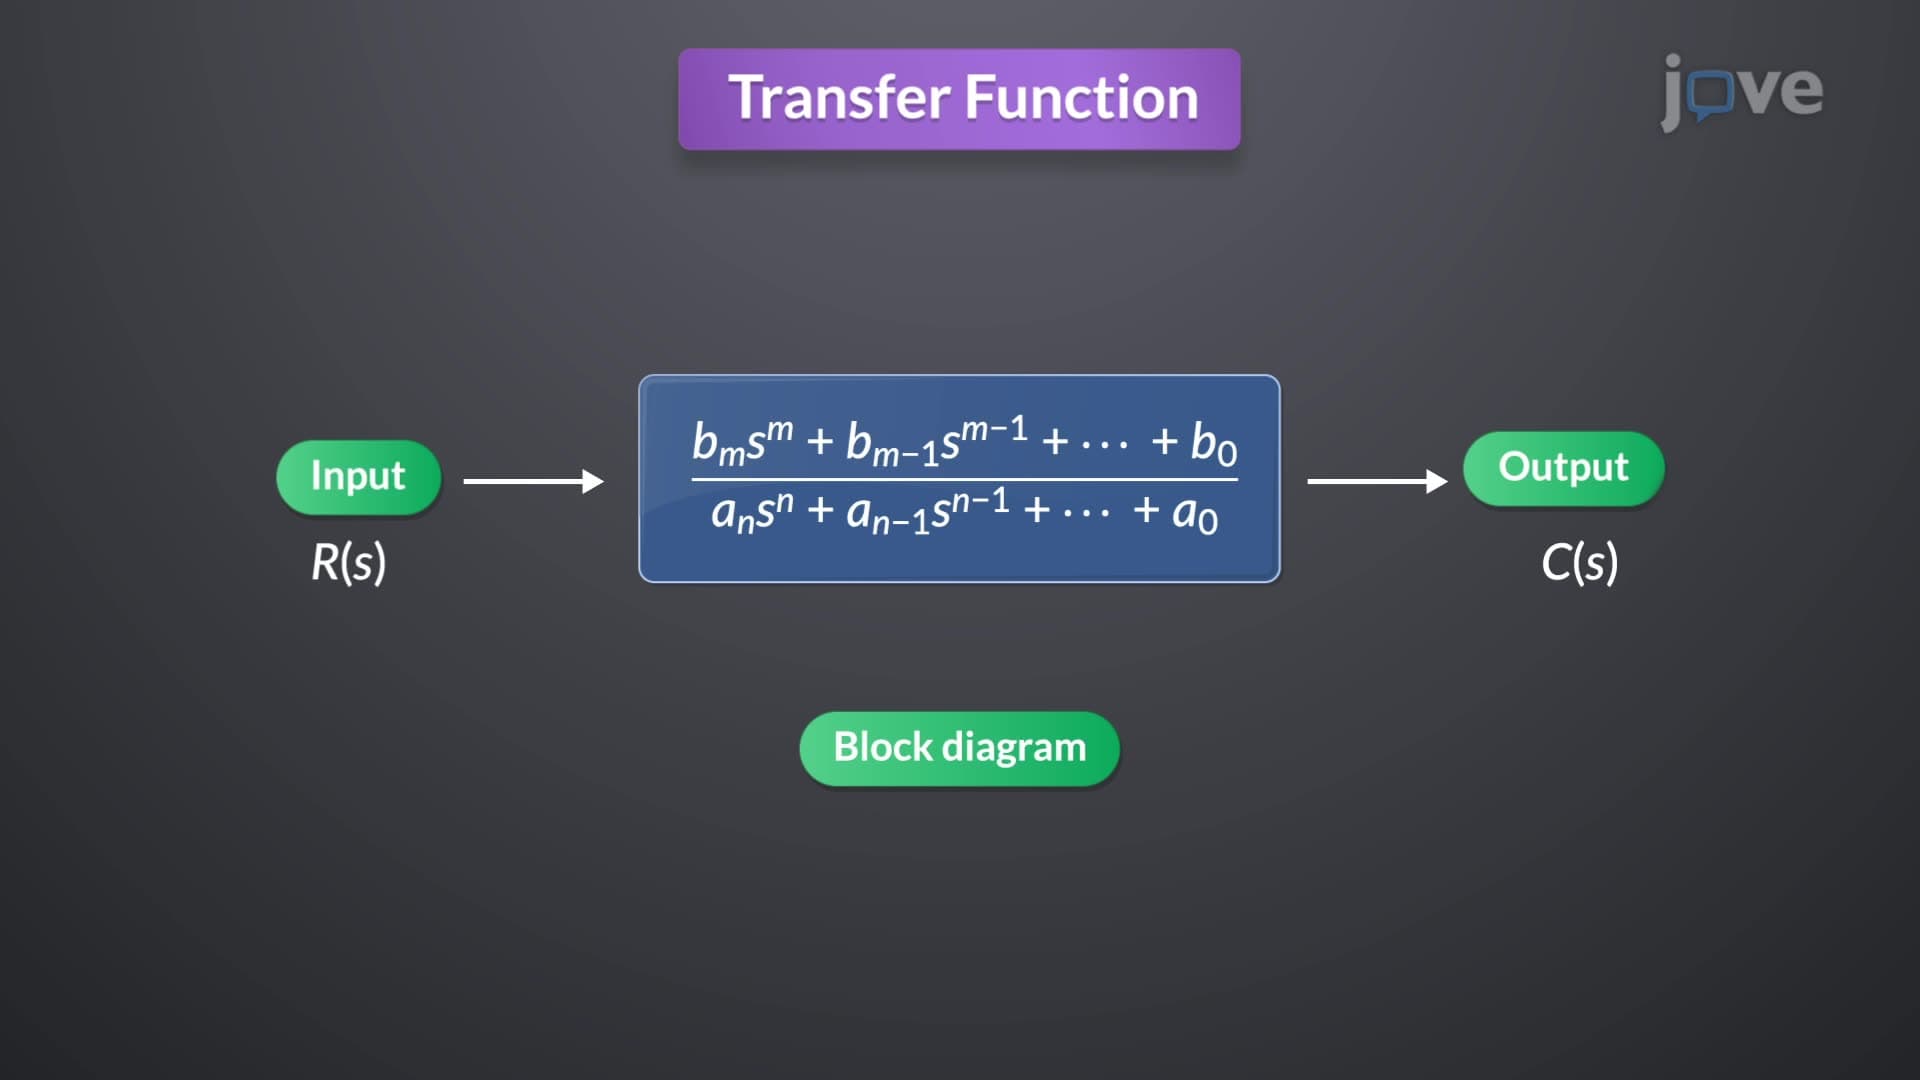
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...