Related Experiment Video
Updated: Jul 2, 2025

Generating Strictly Controlled Stimuli for Figure Recognition Experiments
Published on: March 18, 2019
Adversarial Robustness with Partial Isometry
Loïc Shi-Garrier1, Nidhal Carla Bouaynaya2, Daniel Delahaye1
1ENAC, Université de Toulouse, 31400 Toulouse, France.

Abstract:
Despite their remarkable performance, deep learning models still lack robustness guarantees, particularly in the presence of adversarial examples. This significant vulnerability raises concerns about their trustworthiness and hinders their deployment in critical domains that require certified levels of robustness. In this paper, we introduce an information geometric framework to establish precise robustness criteria for l2 white-box attacks in a multi-class classification setting. We endow the output space with the Fisher information metric and derive criteria on the input-output Jacobian to ensure robustness. We show that model robustness can be achieved by constraining the model to be partially isometric around the training points. We evaluate our approach using MNIST and CIFAR-10 datasets against adversarial attacks, revealing its substantial improvements over defensive distillation and Jacobian regularization for medium-sized perturbations and its superior robustness performance to adversarial training for large perturbations, all while maintaining the desired accuracy.
Related Concept Videos
 01:15
Routh-Hurwitz Criterion I
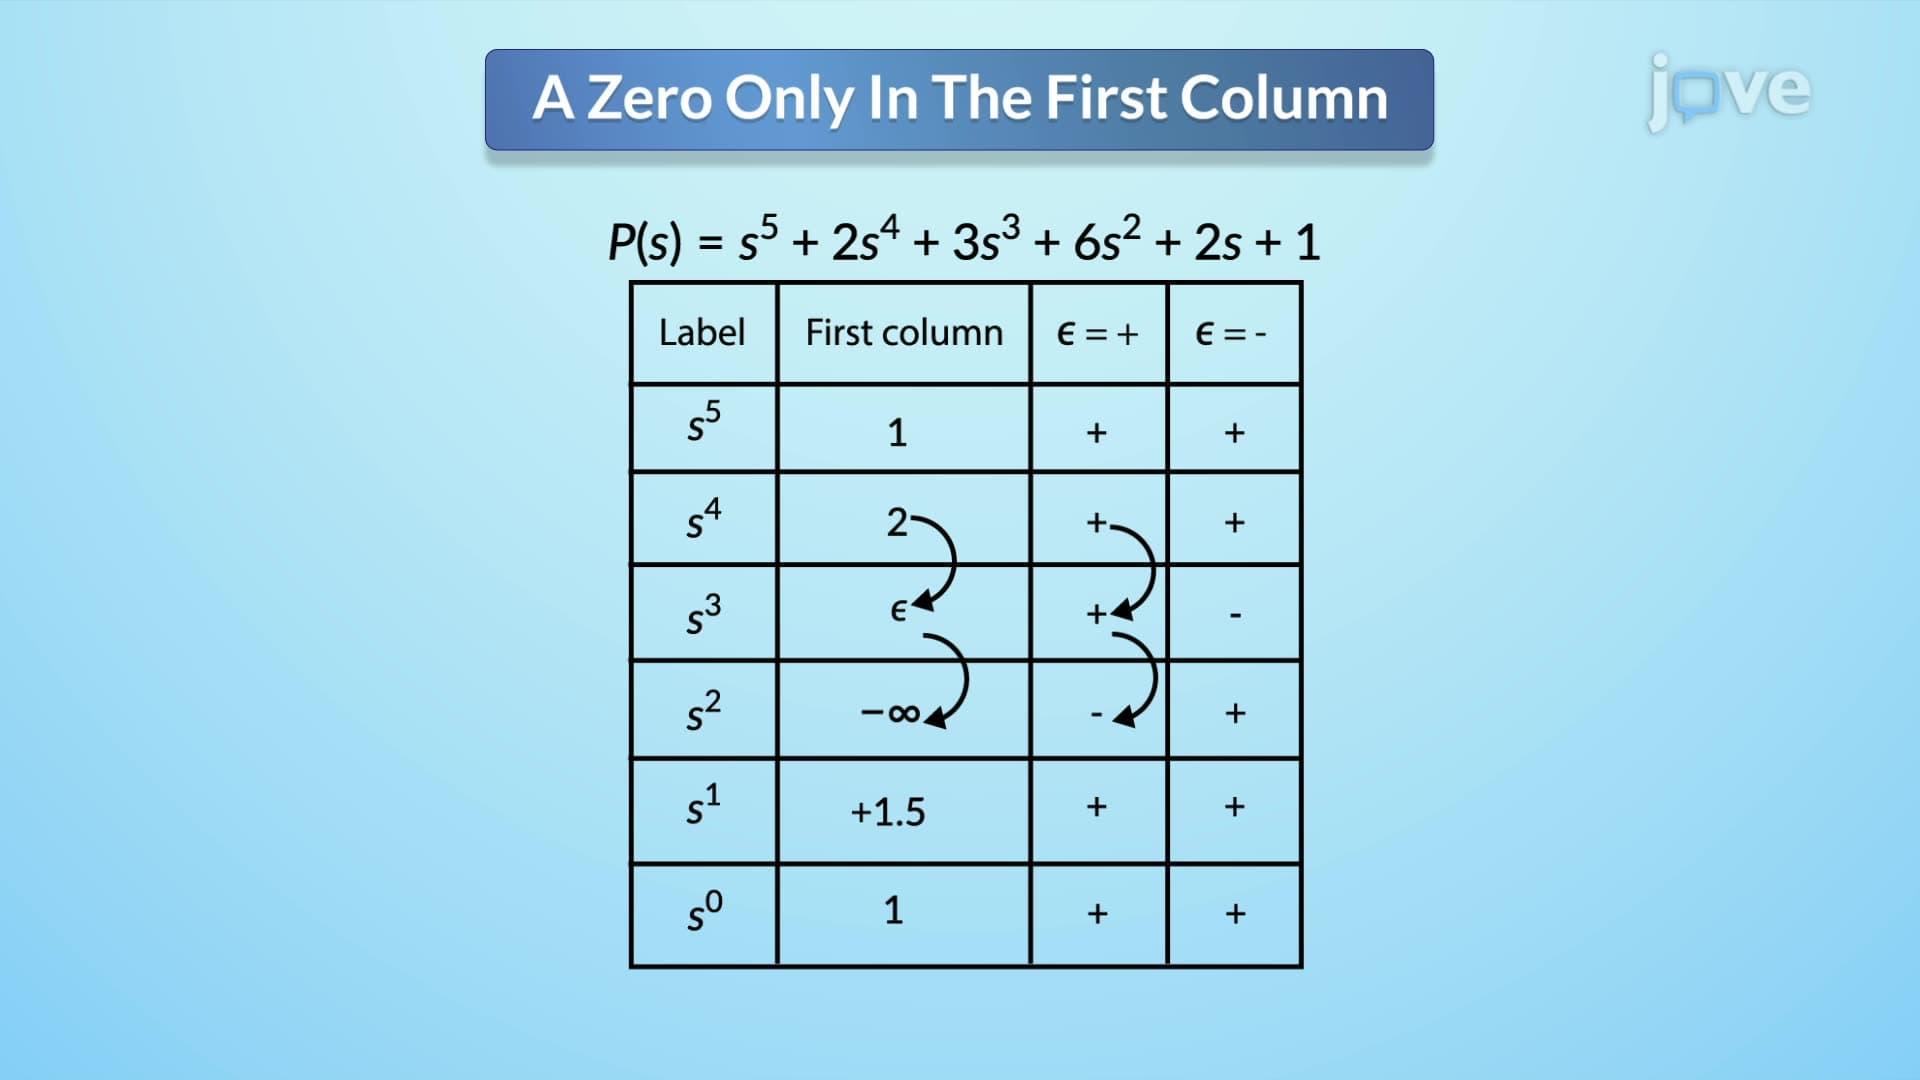
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:19
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:16
Perpendicular-Axis Theorem
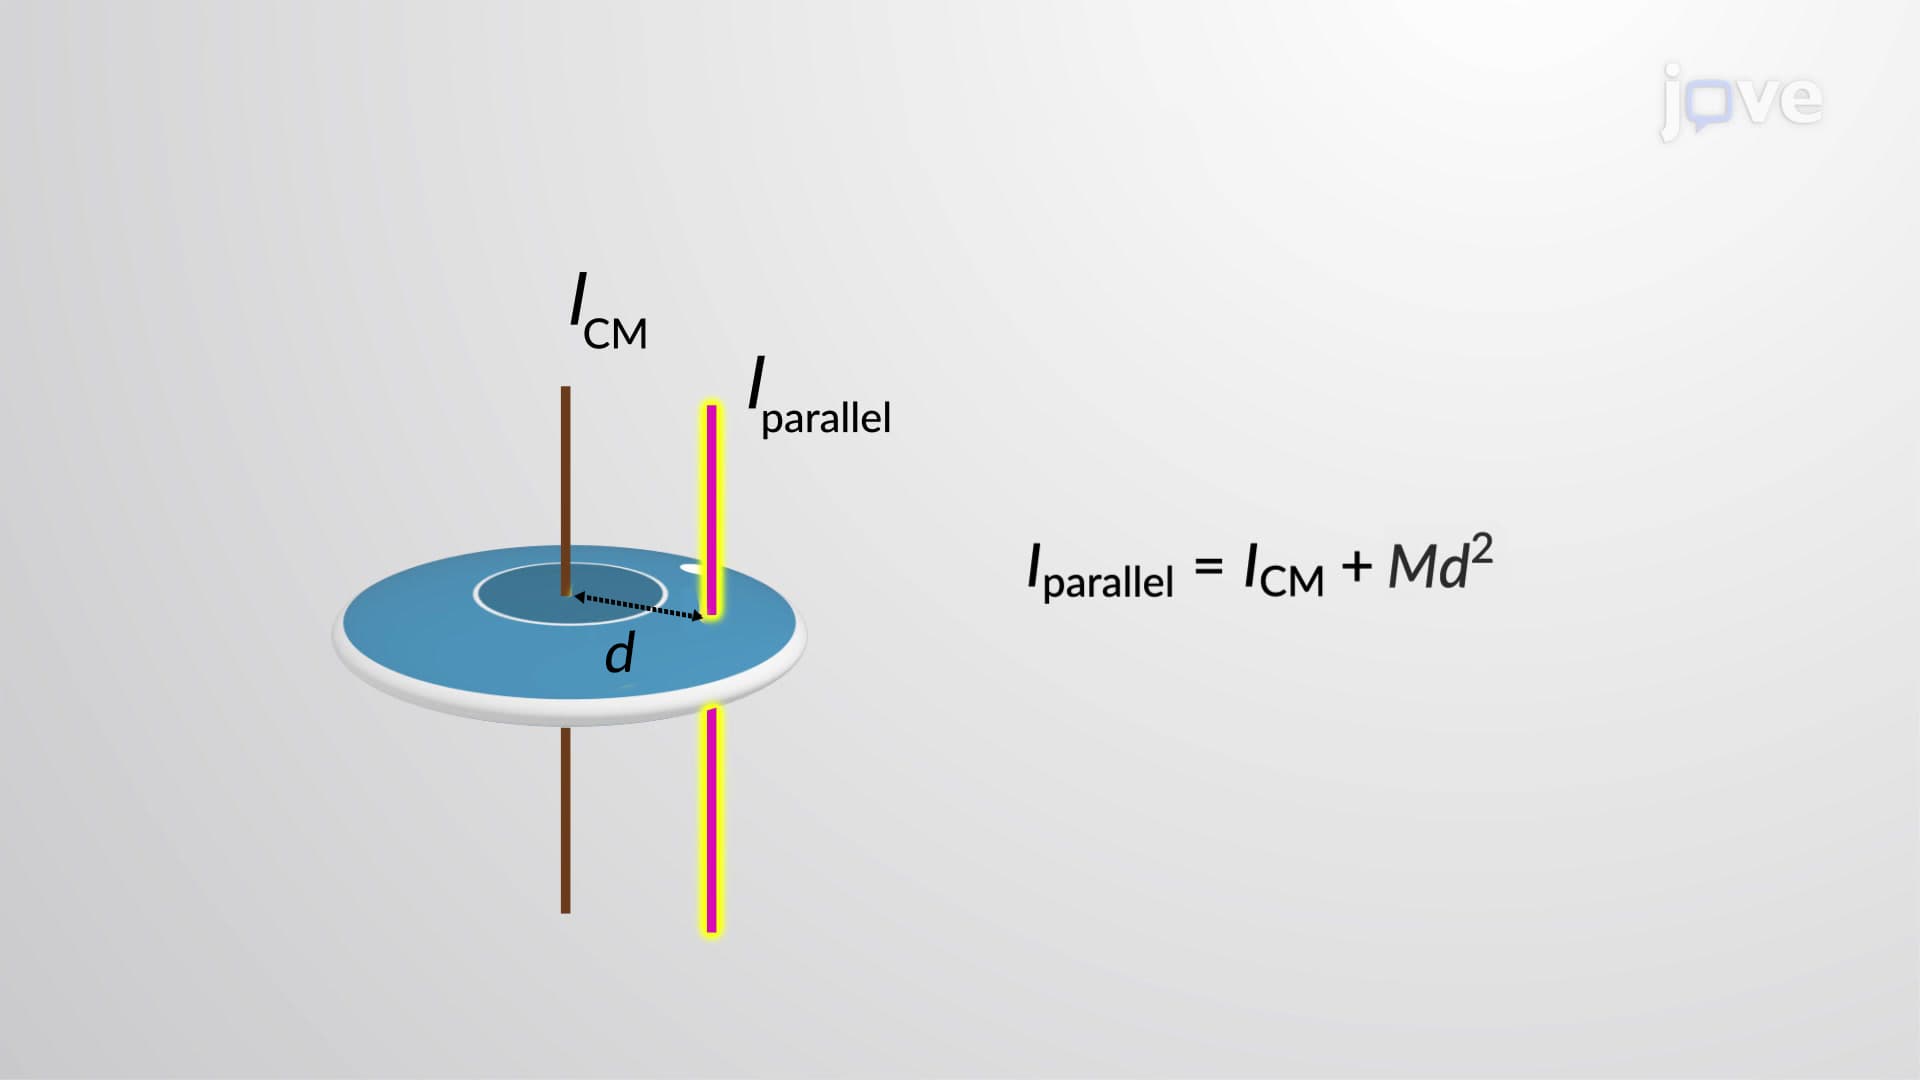
Consider a circular disc of mass M and radius R lying along an x-y plane. The origin lies at the center of the disc, and the z-axis is perpendicular to the disc's plane. All three axes coincide at the disc's center. The moment of inertia of this...
 01:06
Parallel-axis Theorem
 01:28
Accuracy, limits, and approximation
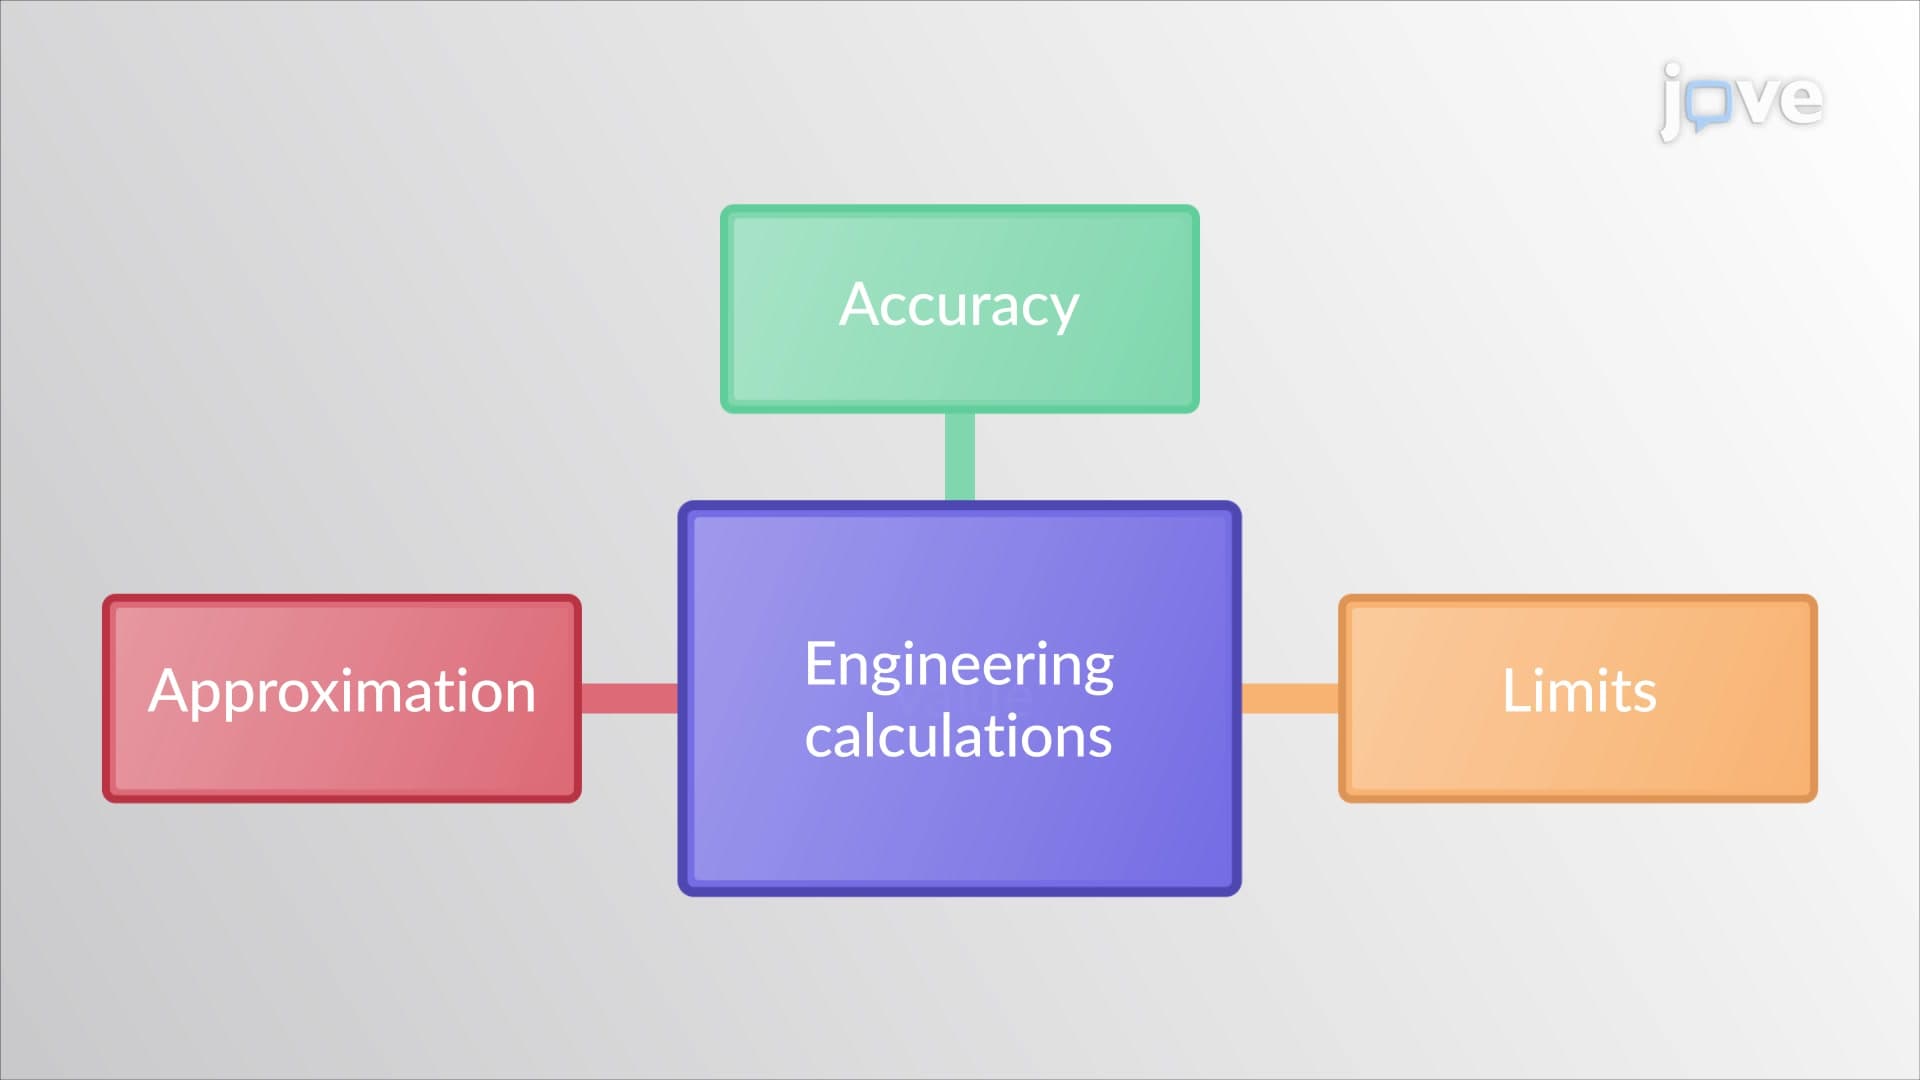
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...
 01:07
Unsymmetric Loading of Thin-Walled Members: Problem Solving
To compute the shear forces, find the shear flow at a specific distance from the endpoint using the vertical shear and the moment of inertia values. The total shear force on the flange is calculated by integrating the shear flow from one end of the flange to the other.
Next, calculate the moments of...