Related Experiment Video
Updated: Jul 2, 2025
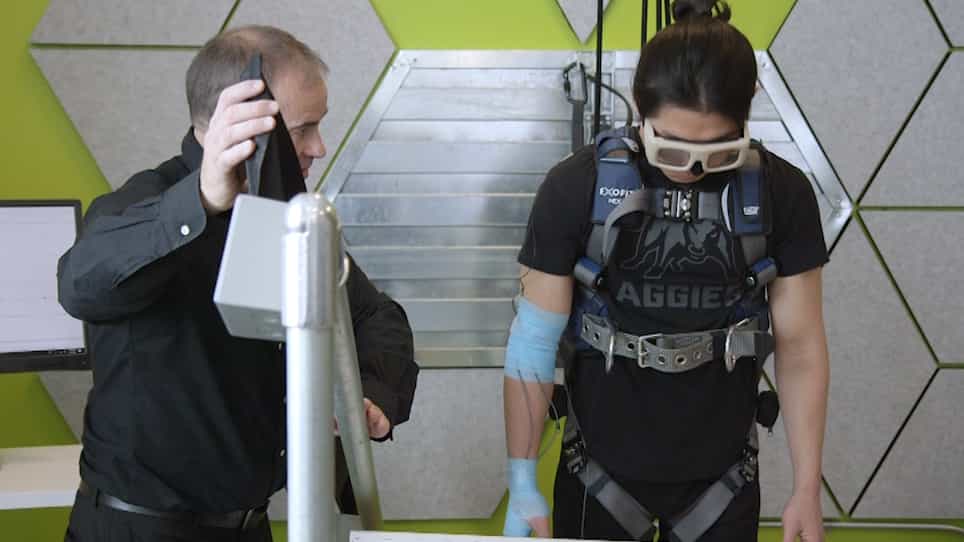
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Balancing Fuzzy Control Performance and Reachable-Set-Dependent Event-Triggered Communication

Abstract:
This work investigates the control design and reachable set estimation problem for T-S fuzzy systems under bounded external disturbances. By designing a fuzzy controller, the reachable set of the closed-loop fuzzy system can be bounded by an ellipsoid that is minimized via two optimization algorithms. When the fuzzy control scheme is implemented under an event-triggered framework, the limited information availability may degrade desired control performance due to only the triggered state being available for the fuzzy controller. To alleviate this problem, a novel reachable-set-dependent event-triggering condition is proposed such that satisfactory control performance can still be ensured by the above fuzzy controller. Meanwhile, the bounding ellipsoid of the reachable set is explicitly given, and a relationship is established between control performance and communication cost under the event-triggered scheme. In addition, under the condition that the reachable set remains within a specified safe area, the communication rate can be reduced while still achieving optimal control performance. The proposed strategies are verified via a simulation example.


Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:28
Load-frequency control