Related Experiment Video
Updated: May 13, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
The effects of swing assistance in a microprocessor-controlled transfemoral prosthesis on walking at varying speeds
Jantzen Lee1, Michael Goldfarb1
1Mechanical Engineering, Vanderbilt University, Nashville, TN, USA.

Abstract:
This article proposes, describes, and tests a swing-assist walking controller for a stance-controlled, swing-assisted knee prosthesis that aims to combine benefits of passive swing mechanics (e.g., quiet operation, biomimetic function, and low power requirements) with benefits of powered swing assistance (e.g., increased robustness of swing-phase motion and specifically increased toe clearance). A three-participant, multislope, multispeed treadmill walking study was performed using the swing-assist prosthesis and controller, as well as using the participants' prescribed microprocessor knee devices. The swing-assist device and approach were found to improve user minimum foot clearance during walking at slopes and speeds, and also to improve symmetry of knee motion. Hip power inputs from stance knee release to heel strike indicated that, on average, less hip power was required when using the swing-assist prosthesis, indicating that the observed benefits were likely the result of the knee device and its control methodology, rather than a result of increased hip joint effort.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 05:52
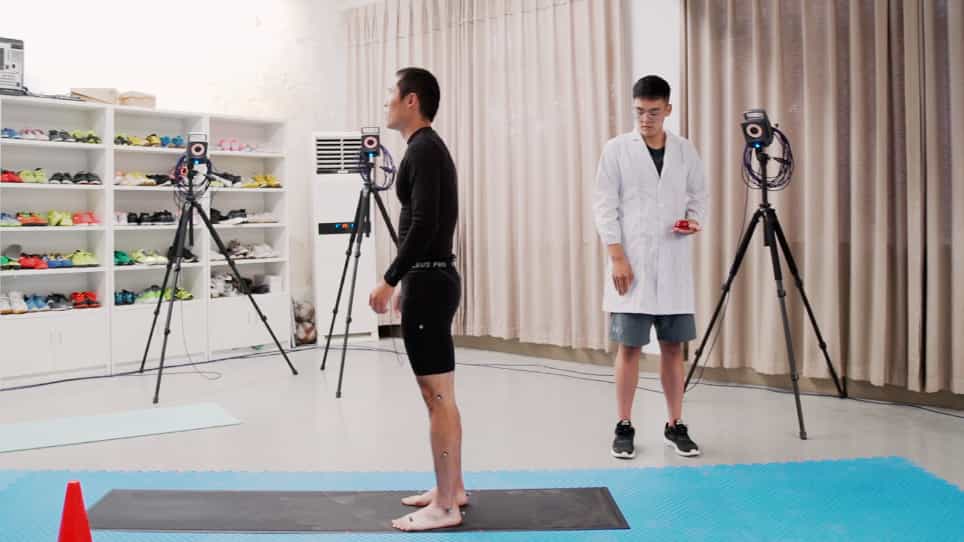
Lower-Limb Biomechanical Characteristics Associated with Unplanned Gait Termination Under Different Walking Speeds
Published on: August 25, 2020
Related Concept Videos
 01:22
Muscle Stimulation Frequency
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
 01:10
Relative Motion Analysis - Acceleration
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...