Related Experiment Video
Updated: Jun 30, 2025

Mimicking a Space Mission to Mars Using Hindlimb Unloading and Partial Weight Bearing in Rats
Published on: April 4, 2019
The effect of inherent and incidental constraints on bimanual force control in simulated Martian gravity
Yiyu Wang1, Osmar P Neto2, Madison Weinrich1
1Department of Kinesiology and Sport Management, Texas A&M University, TX, USA.

Abstract:
The ability to coordinate actions between the limbs is important for many operationally relevant tasks associated with space exploration. A future milestone in space exploration is sending humans to Mars. Therefore, an experiment was designed to examine the influence of inherent and incidental constraints on the stability characteristics associated with the bimanual control of force in simulated Martian gravity. A head-up tilt (HUT)/head-down tilt (HDT) paradigm was used to simulate gravity on Mars (22.3° HUT). Right limb dominant participants (N = 11) were required to rhythmically coordinate patterns of isometric forces in 1:1 in-phase and 1:2 multifrequency patterns by exerting force with their right and left limbs. Lissajous displays were provided to guide task performance. Participants performed 14 twenty-second practice trials at 90° HUT (Earth). Following a 30-min rest period, participants performed 2 test trials for each coordination pattern in both Earth and Mars conditions. Performance during the test trials were compared. Results indicated very effective temporal performance of the goal coordination tasks in both gravity conditions. However, results indicated differences associated with the production of force between Earth and Mars. In general, participants produced less force in simulated Martian gravity than in the Earth condition. In addition, force production was more harmonic in Martian gravity than Earth gravity for both limbs, indicating that less force distortions (adjustments, hesitations, and/or perturbations) occurred in the Mars condition than in the Earth condition. The force coherence analysis indicated significantly higher coherence in the 1:1 task than in the 1:2 task for all force frequency bands, with the highest level of coherence in the 1-4 Hz frequency band for both gravity conditions. High coherence in the 1-4 Hz frequency band is associated with a common neural drive that activates the two arms simultaneously and is consistent with the requirements of the two tasks. The results also support the notion that neural crosstalk stabilizes the performance of the 1:1 in-phase task. In addition, significantly higher coherence in the 8-12 Hz frequency bands were observed for the Earth condition than the Mars condition. Force coherence in the 8-12 Hz bands is associated with the processing of sensorimotor information, suggesting that participants were better at integrating visual, proprioceptive, and/or tactile feedback in Earth than for the Mars condition. Overall, the results indicate less neural interference in Martian gravity; however, participants appear to be more effective at using the Lissajous displays to guide performance under Earth's gravity.

Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
Comparison Between Electrical And Gravitational Forces
Since both are inverse square law forces, the distance gets canceled when the ratio of the two forces is considered. Instead, the ratio of the electrical and gravitational forces depends on...
 01:15
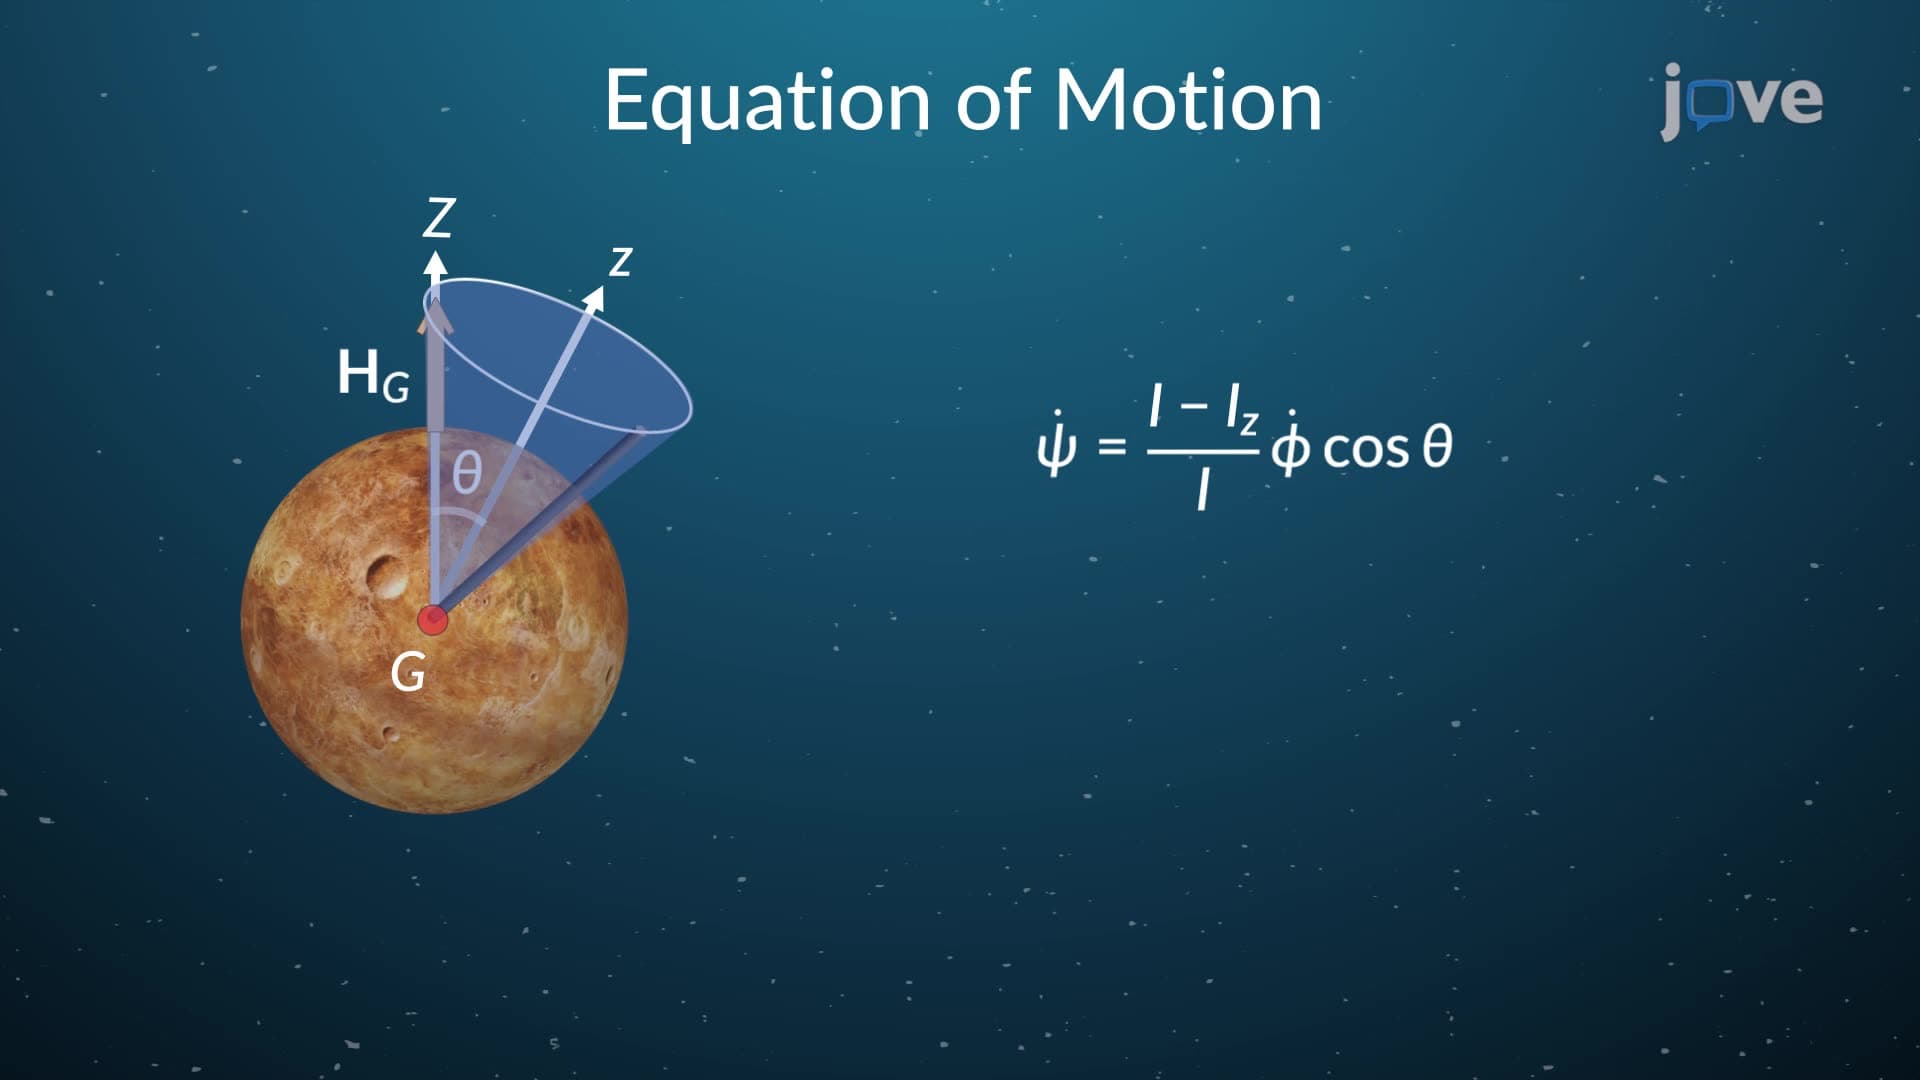
Torque Free Motion
 00:49
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:07
Conservation of Mass in Fixed, Nondeforming Control Volume
In the case of a sewer pipe, which can be modeled...