Related Experiment Video
Updated: Jul 1, 2026
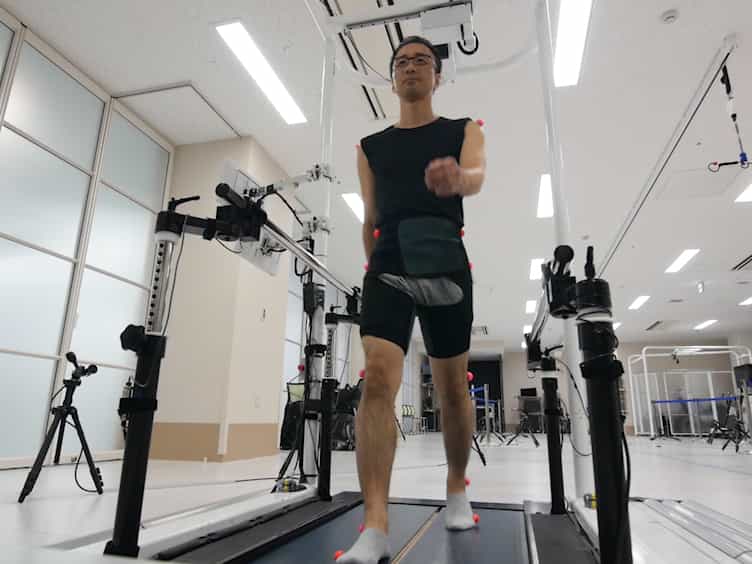

Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
Joint kinematics and SPM analysis of gait in children with and without Down syndrome
Matthew Beerse1, Kaylee Larsen1, Tasnuva Alam2
1Department of Health and Sport Science, University of Dayton, Dayton, OH, USA.

Background:
Individuals with Down syndrome (DS) walk with altered gait patterns compared to their typically developing (TD) peers. While walking at faster speeds and with external ankle load, preadolescents with DS demonstrate spatiotemporal and kinetic improvements. However, evidence of joint kinematic adjustments is unknown, which is imperative for targeted rehabilitation design.
Research Question:
How does increasing walking speed and adding ankle load affect the joint kinematics of children with and without DS during overground walking?
Methods:
In this cross-sectional observational study, thirteen children with DS aged 7-11 years and thirteen age- and sex-matched TD children completed overground walking trials. There were two speed conditions: normal speed and fast speed (as fast as possible without running). There were two load conditions: no load and ankle load (2% of body mass added bilaterally above the ankle). A motion capture system was used to register the ankle, knee, and hip joint angles in the sagittal plane. Peak flexion/extension angles, range of motion, and timing of peak angles were identified. In addition, statistical parametric mapping (SPM) was conducted to evaluate the trajectory of the ankle, knee, and hip joint angles across the entire gait cycle.
Results And Significance:
SPM analysis revealed the DS group walked with greater ankle, knee, and hip flexion compared to the TD group for most of the gait cycle, regardless of condition. Further, increasing walking speed led to improved ankle joint kinematics in both groups by shifting peak plantarflexion closer to toe-off. However, knee extension during stance was challenged in the DS group. Adding ankle load improved hip and knee kinematics in both groups but reduced peak plantarflexion around toe-off. The kinematic adjustments in the DS group suggest specific motor strategies to accommodate their neuromuscular deficits, which can provide a foundation to design targeted gait-based interventions for children with DS.
Related Concept Videos
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:10
Relative Motion Analysis - Acceleration
 01:21
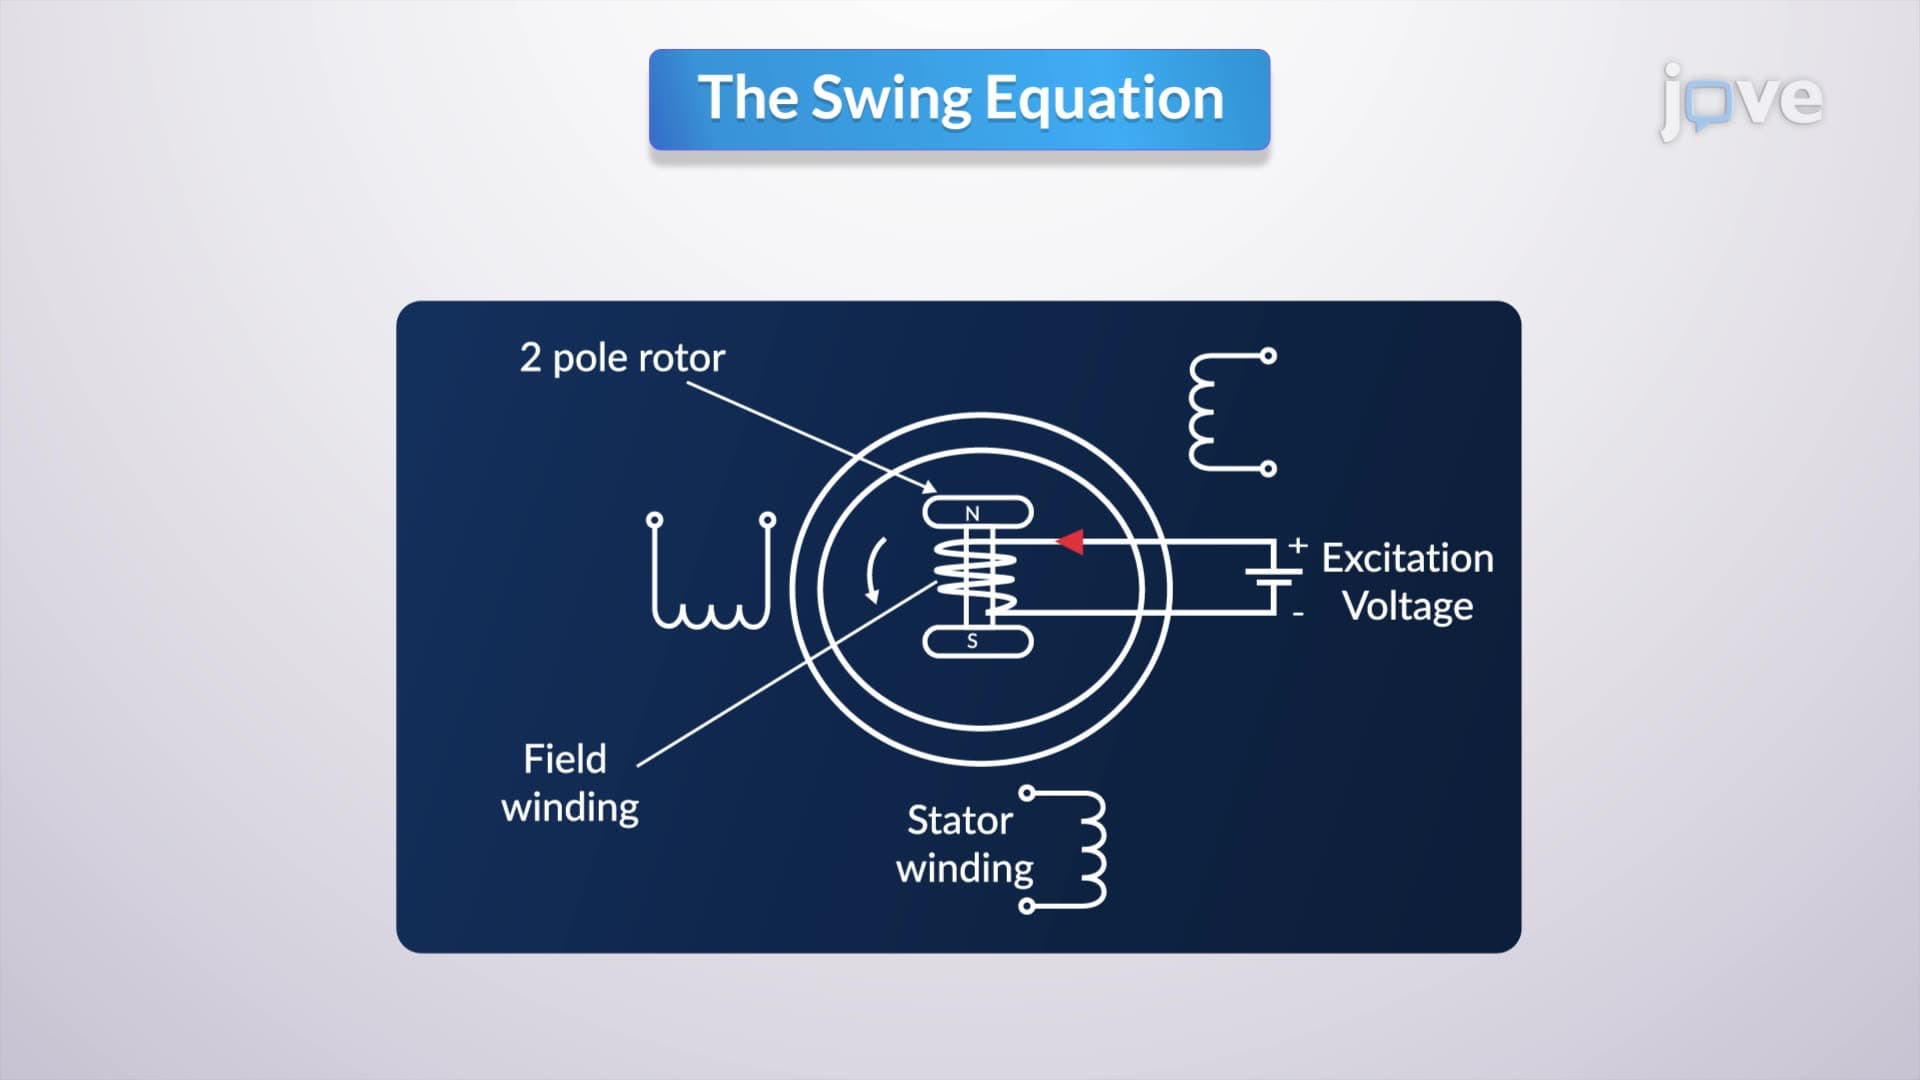
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...