Related Experiment Video
Updated: Jun 29, 2025

A Teleoperated Robotic System-Assisted Percutaneous Transiliac-Transsacral Screw Fixation Technique
Published on: January 6, 2023
Workspace and dexterity analysis of the hybrid mechanism master robot in Sinaflex robotic telesurgery system: An in
Mehrnaz Aghanouri1, Hamid Moradi1, Hossein A Alibeik2
1Department of Medical Physics and Biomedical Engineering, School of Medicine, Tehran University of Medical Sciences, Tehran, Iran.

Abstract:
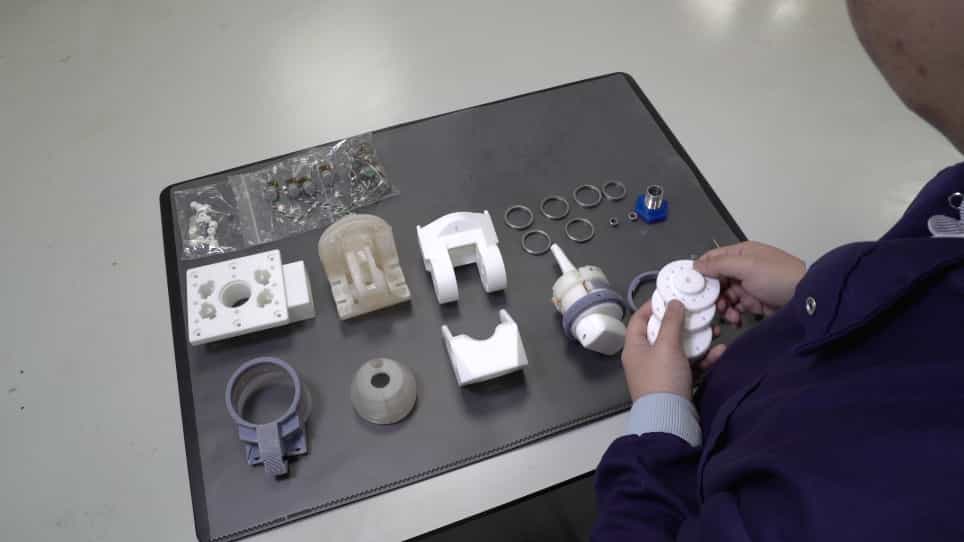
Sinaflex robotic telesurgery system has been introduced recently to provide ergonomic postures for the surgeon along with dexterous workspace for robotic telesurgery. The robot is described, and the forward and inverse kinematics are derived and validated by an experiment. The robot and operational workspaces and their dexterity are investigated and compared using the data collected during a dog vasectomy robotic telesurgery by Sinaflex. According to the simulation results, the workspace of the end effector is as large as 914.56 × 105 mm3, which can completely cover the ergonomic human hand workspace. The dexterity of the robot for the total and operational workspace is 0.4557 and 0.6565, respectively. In terms of the workspace size and the amount of dexterity, Sinaflex master robot can be considered a good choice to fulfil the requirements of the surgeon side robot in robotic telesurgery systems.

Related Concept Videos
 01:30
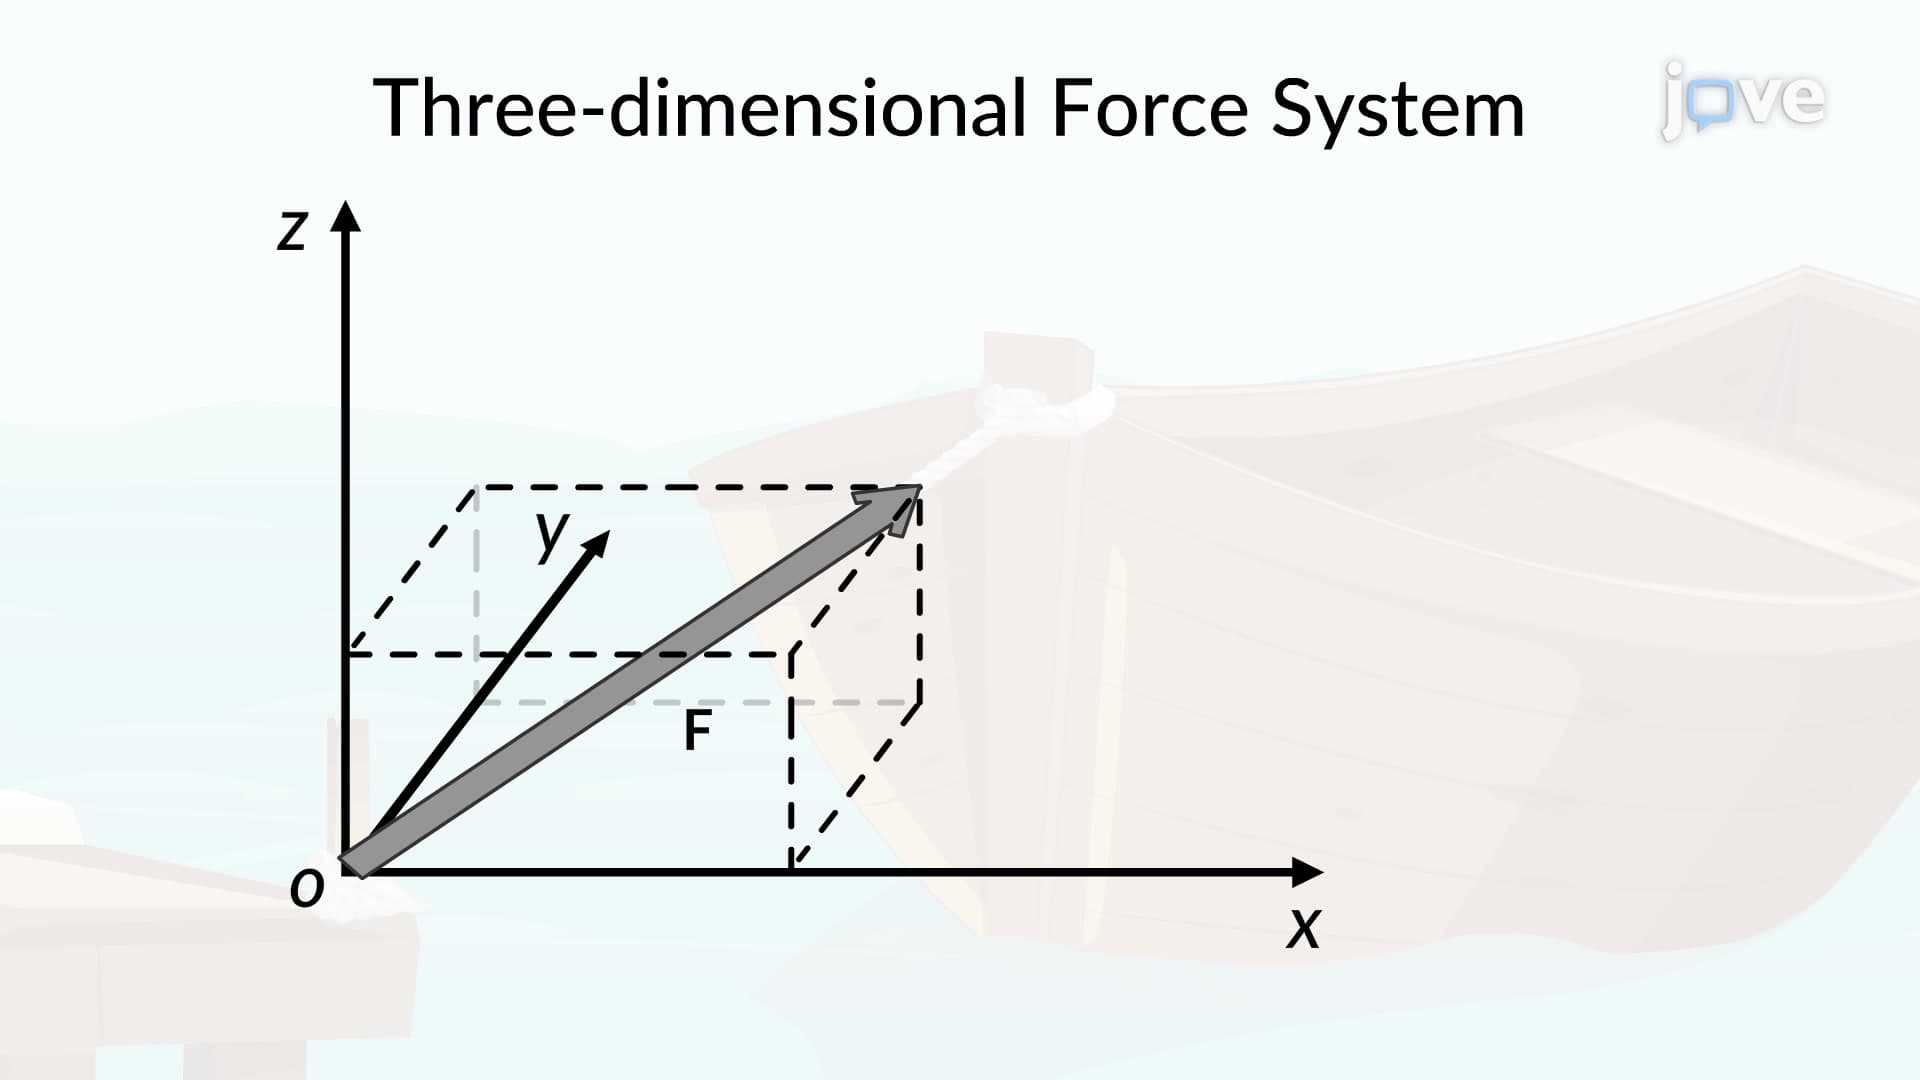
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:22
Mechanical Systems
 01:30
Machines: Problem Solving II
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
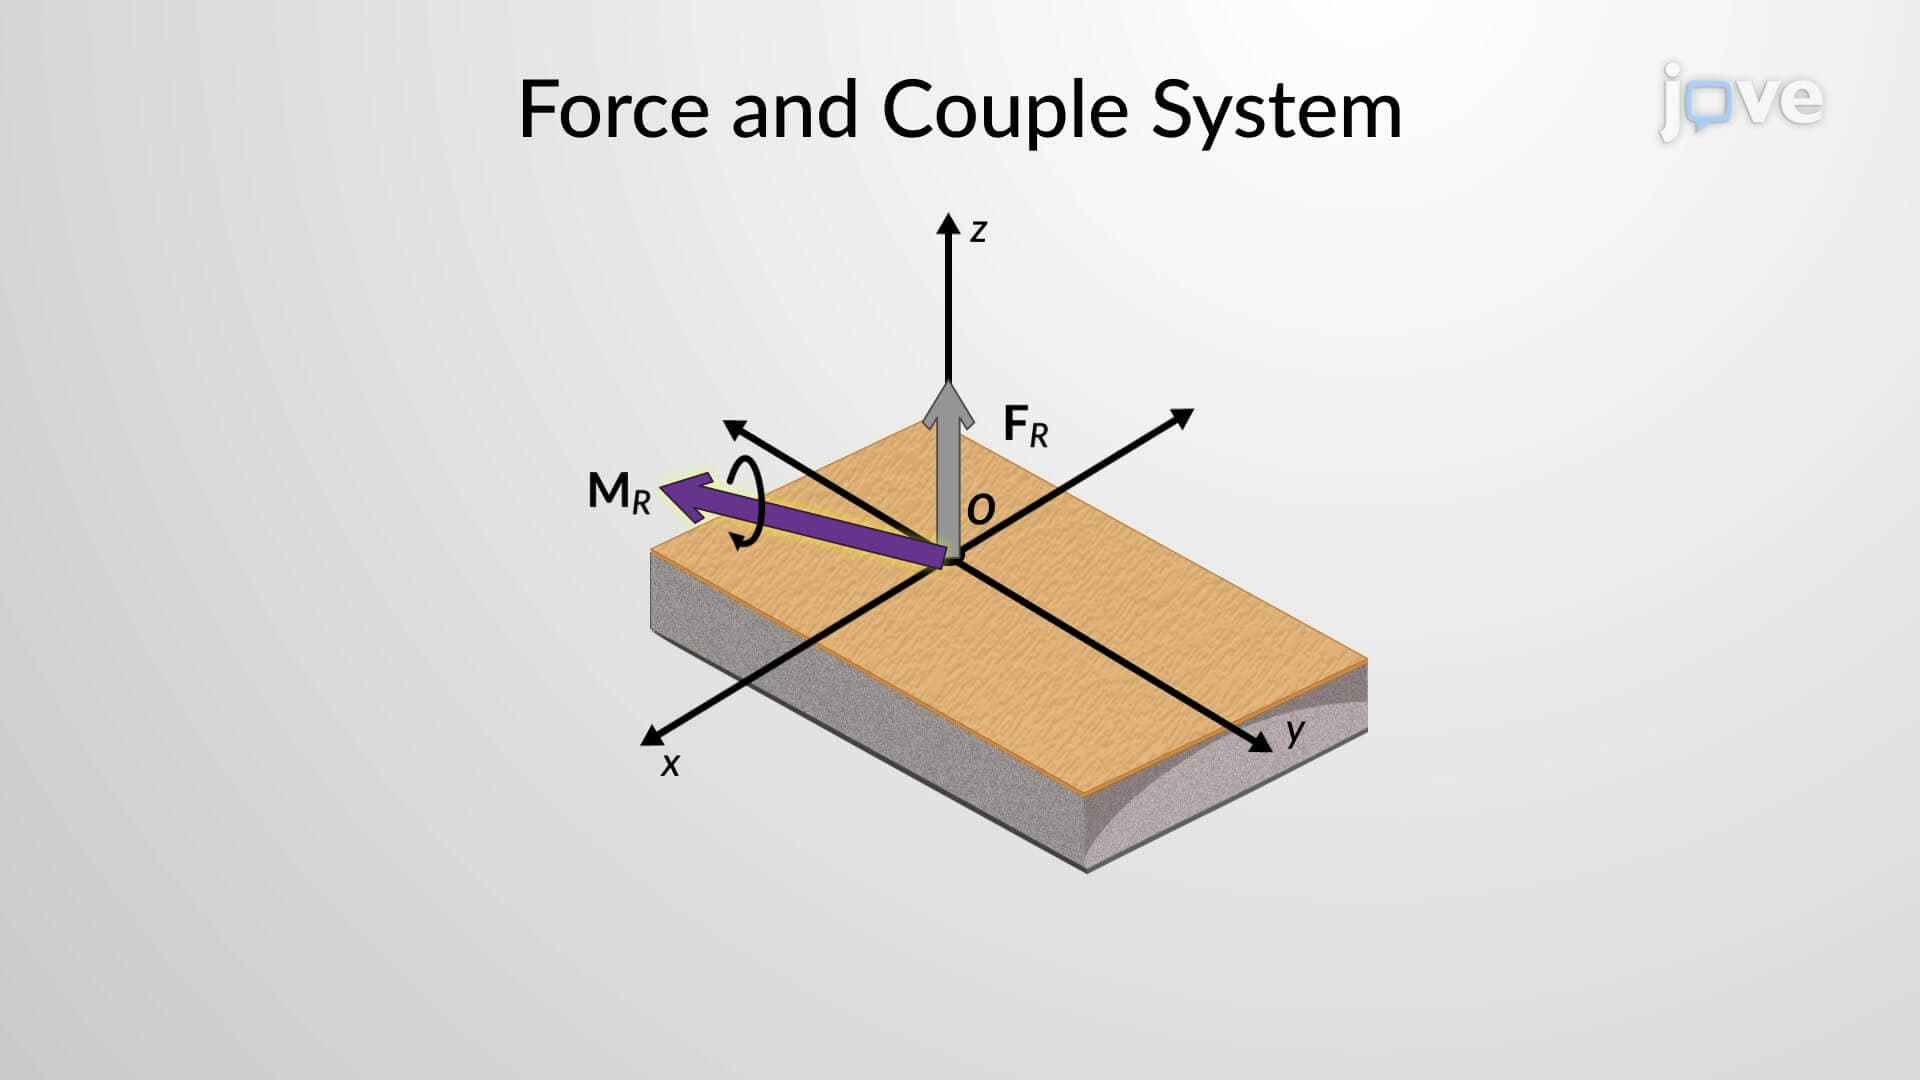
Simplification of a Force and Couple System: II
 01:30
Three-Dimensional Force System