Accurate drone corner position estimation in complex backgrounds with boundary classification
Related Experiment Video
Updated: Jun 28, 2025

Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
Yu-Shiuan Tsai1, Cheng-Sheng Lin1, Guan-Yi Li1
1Dept. of Computer Science and Engineering, National Taiwan Ocean University, Zhongzheng District, Keelung, Taiwan.

Abstract:
This study develops an efficient approach for precise channel frame detection in complex backgrounds, addressing the critical need for accurate drone navigation. Leveraging YOLACT and group regression, our method outperforms conventional techniques that rely solely on color information. We conducted extensive experiments involving channel frames placed at various angles and within intricate backgrounds, training the algorithm to effectively recognize them. The process involves initial edge image detection, noise reduction through binarization and erosion, segmentation of channel frame line segments using the Hough Transform algorithm, and subsequent classification via the K-means algorithm. Ultimately, we obtain the regression line segment through linear regression, enabling precise positioning by identifying intersection points. Experimental validations validate the robustness of our approach across diverse angles and challenging backgrounds, making significant advancements in UAV applications.
More Related Videos


Related Concept Videos
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:18
Boundary Layer Characteristics
 01:21
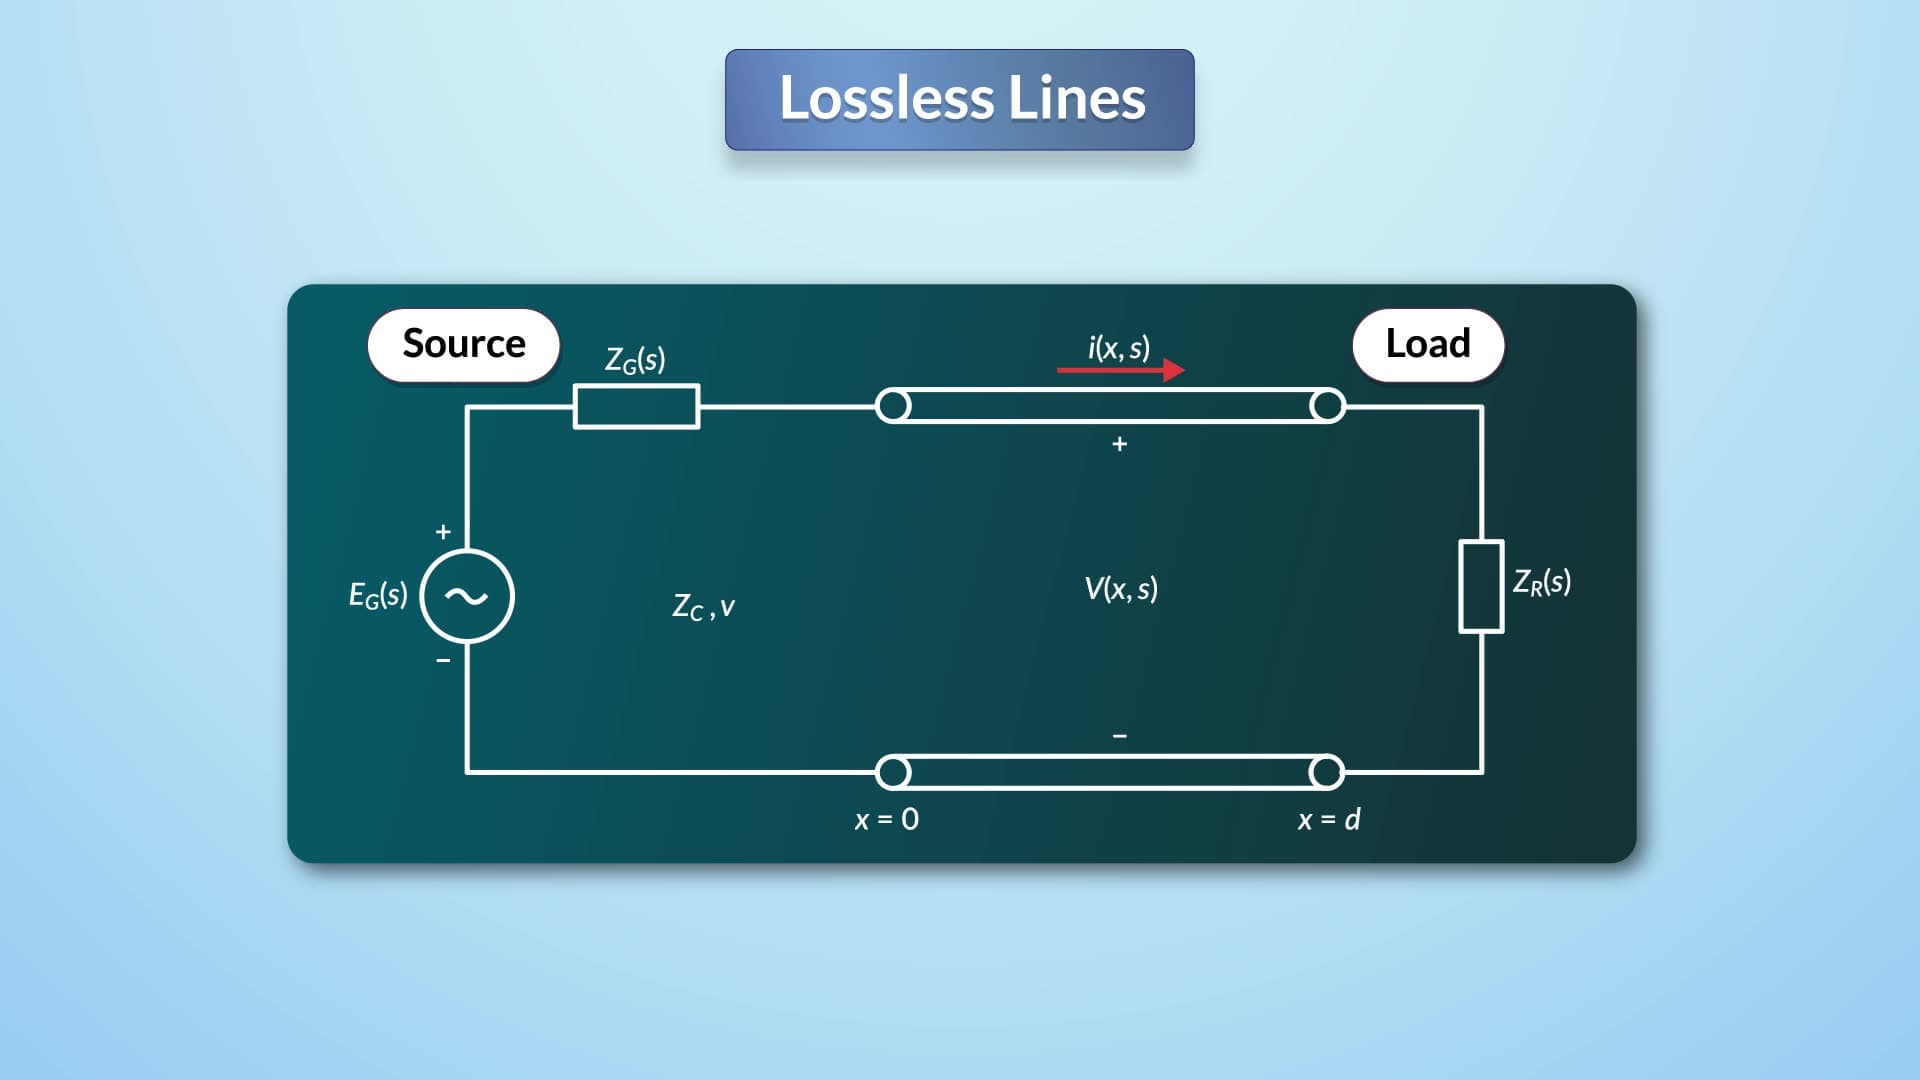
Boundary Conditions: Lossless Lines
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:29
Position Vectors
For instance, we want to locate a point P(x, y, z) relative to the origin of coordinates O. In that case, we can define a position...