Related Experiment Video
Updated: May 3, 2026
Simultaneous Eye Tracking and Single-Neuron Recordings in Human Epilepsy Patients
Published on: June 17, 2019
Goal-Guided Graph Attention Network with Interactive State Refinement for Multi-Agent Trajectory Prediction
Jianghang Wu1, Senyao Qiao1, Haocheng Li1
1College of Automotive Engineering, Jilin University, Changchun 130025, China.

Abstract:
The accurate prediction of the future trajectories of traffic participants is crucial for enhancing the safety and decision-making capabilities of autonomous vehicles. Modeling social interactions among agents and revealing the inherent relationships is crucial for accurate trajectory prediction. In this context, we propose a goal-guided and interaction-aware state refinement graph attention network (SRGAT) for multi-agent trajectory prediction. This model effectively integrates high-precision map data and dynamic traffic states and captures long-term temporal dependencies through the Transformer network. Based on these dependencies, it generates multiple potential goals and Points of Interest (POIs). Through its dual-branch, multimodal prediction approach, the model not only proposes various plausible future trajectories associated with these POIs, but also rigorously assesses the confidence levels of each trajectory. This goal-oriented strategy enables SRGAT to accurately predict the future movement trajectories of other vehicles in complex traffic scenarios. Tested on the Argoverse and nuScenes datasets, SRGAT surpasses existing algorithms in key performance metrics by adeptly integrating past trajectories and current context. This goal-guided approach not only enhances long-term prediction accuracy, but also ensures its reliability, demonstrating a significant advancement in trajectory forecasting.
Related Concept Videos
 01:10
Vector Algebra: Graphical Method
We use the laws of geometry to construct resultant vectors, followed by trigonometry to find vector magnitudes and directions. For a geometric construction of the sum of two vectors in a plane, we follow the parallelogram rule. Suppose two vectors are at arbitrary positions. Translate either one of...
 01:07
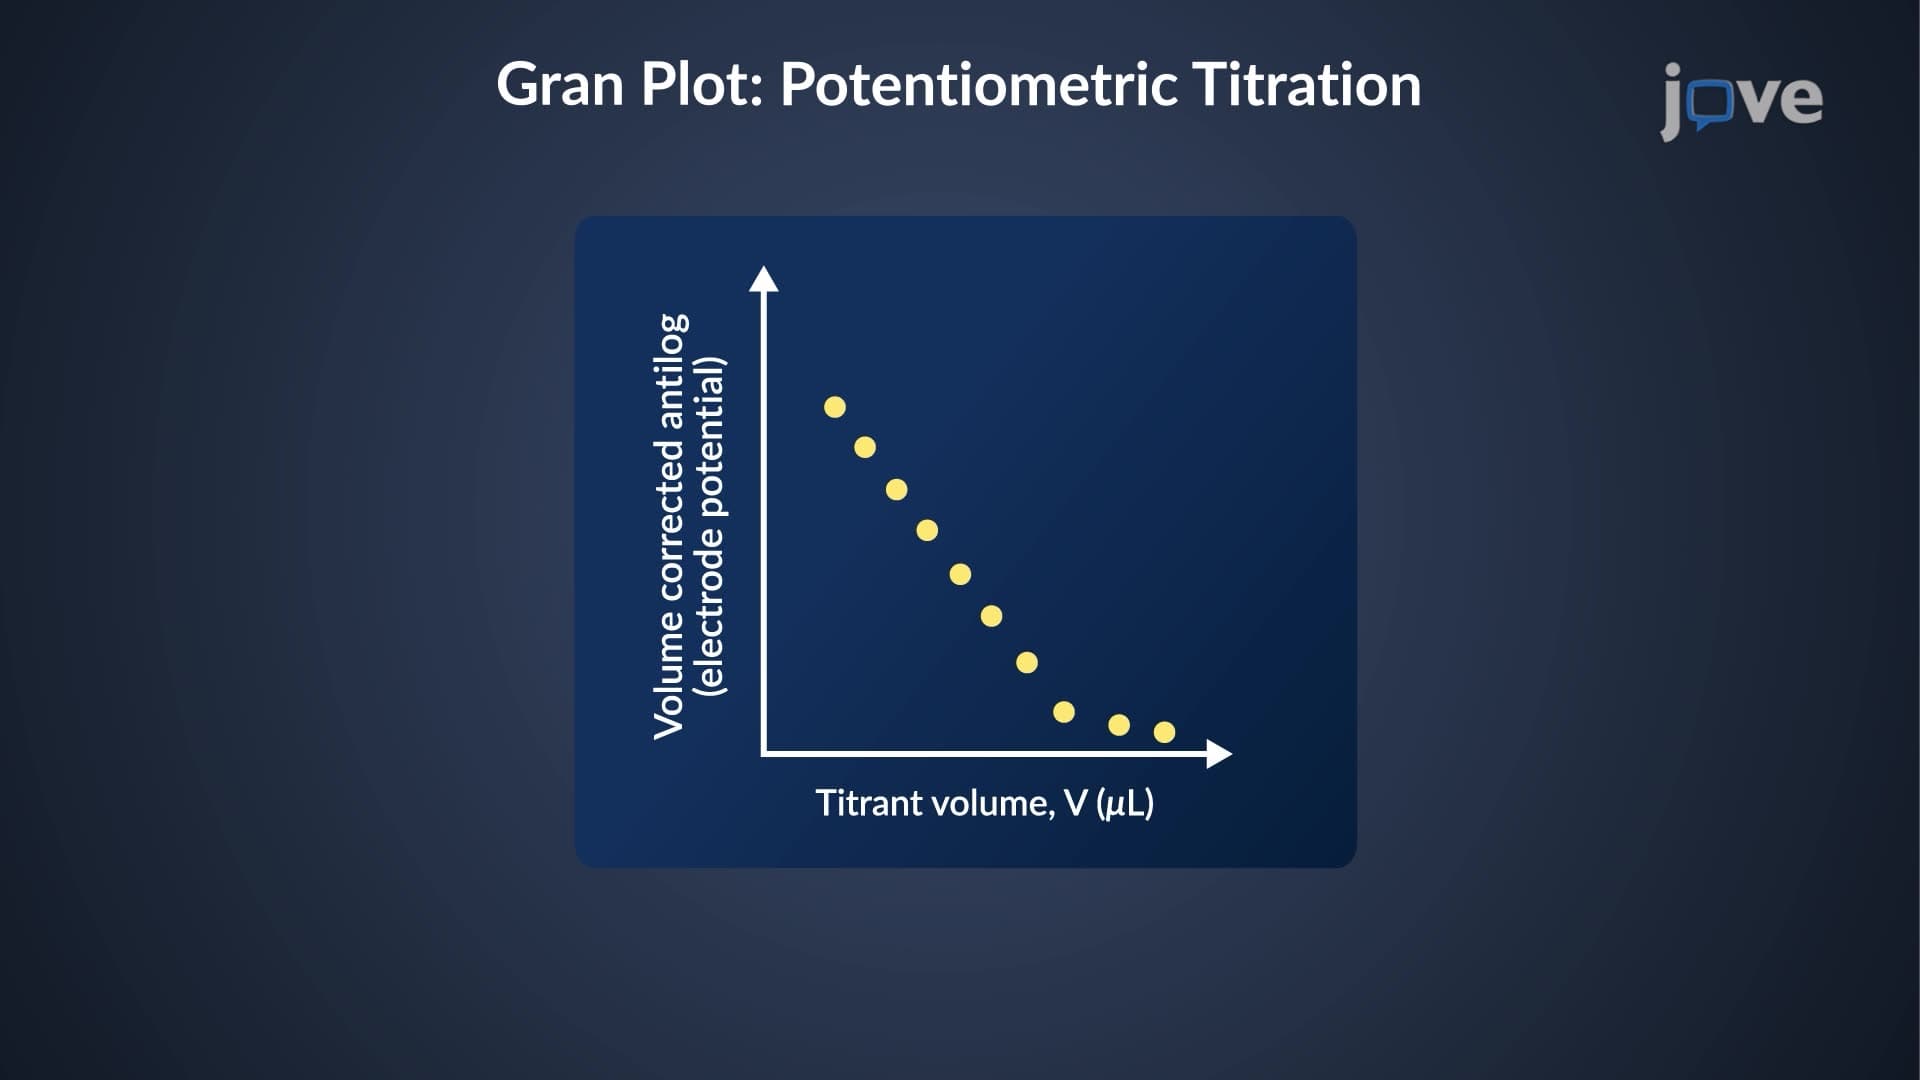
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:18
Signal Flow Graphs
In a signal-flow graph, branches denote the system's transfer functions, while nodes represent the signals. The direction of signal flow is indicated by arrows, with the corresponding...
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...