Related Experiment Video
Updated: Jun 28, 2025


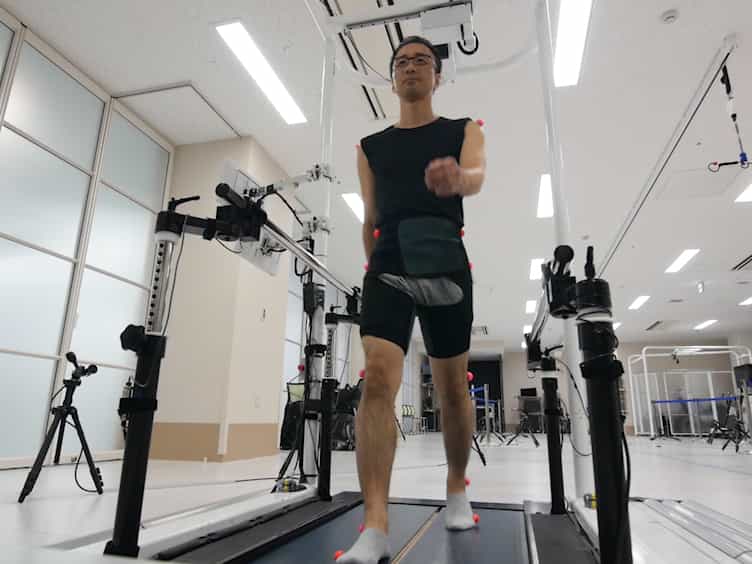
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Controlling flat-foot limit cycle walkers with compliant joints based on local stability variation
Yan Huang1,2,3, Yue Gao4,5, Qiang Huang1,2,3
1School of Mechatronical Engineering, Beijing Institute of Technology, Beijing, 100081, China.

Abstract:
This study investigates local stability of a four-link limit cycle walking biped with flat feet and compliant ankle joints. Local stability represents the behavior along the solution trajectory between Poincare sections, which can provide detailed information about the evolution of disturbances. The effects of ankle stiffness and foot structure on local stability are studied. In addition, we apply a control strategy based on local stability analysis to the limit cycle walker. Control is applied only in the phases with poor local stability. Simulation results show that the energy consumption is reduced without sacrificing disturbance rejection ability. This study may be helpful in motion control of limit cycle bipedal walking robots with flat feet and ankle stiffness and understanding of human walking principles.

Related Concept Videos
 01:27
Movement Joints in Buildings
The simplest type of movement joints, working joints, are...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Rolling Resistance: Problem Solving
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:16
Eccentric Axial Loading in a Plane of Symmetry