Related Experiment Video
Updated: Jun 28, 2025
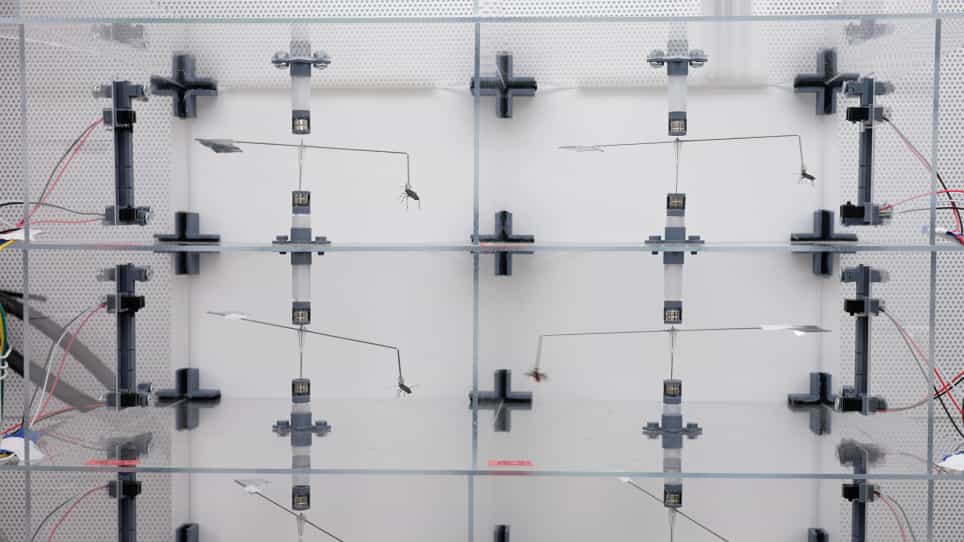

Building an Enhanced Flight Mill for the Study of Tethered Insect Flight
Published on: March 10, 2021
Joint extension speed dictates bio-inspired morphing trajectories for optimal longitudinal flight dynamics
1Department of Mechanical and Aerospace Engineering, University of California , Davis, CA 95616, USA.

Abstract:
Avian wing morphing allows dynamic, active control of complex flight manoeuvres. Previous linear time-invariant (LTI) models have quantified the effect of varying fixed wing configurations but the time-dependent effects of morphing between different configurations is not well understood. To fill this gap, I implemented a linear parameter-varying (LPV) model for morphing wing gull flight. This approach models the wing joint angles as scheduled parameters and accounts for nonlinear kinematic and gravitational effects while interpolating between LTI models at discrete trim points. With the resulting model, I investigated the longitudinal response associated with various joint extension trajectories. By optimizing the extension trajectory for four independent objectives (speed and pitch angle overshoot, speed rise time and pitch angle settling time), I found that the extension trajectory inherent to the gull wing does not guarantee an optimal response but may provide a sufficient response with a simpler mechanical implementation. Furthermore, the results indicated that gulls likely require extension speed feedback. This morphing LPV model provides insights into underlying control mechanisms, which may allow for avian-like flight in future highly manoeuvrable uncrewed aerial vehicles.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:16
Eccentric Axial Loading in a Plane of Symmetry
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...