Untethered soft actuators for soft standalone robotics

Yeongju Jung1, Kangkyu Kwon1, Jinwoo Lee2

  • 1Applied Nano and Thermal Science Lab, Department of Mechanical Engineering, Seoul National University, 1 Gwanak-ro, Gwanak-gu, Seoul, 08826, South Korea.

Nature Communications
|April 25, 2024
PubMed

Related Concept Videos

Torque Free Motion01:15

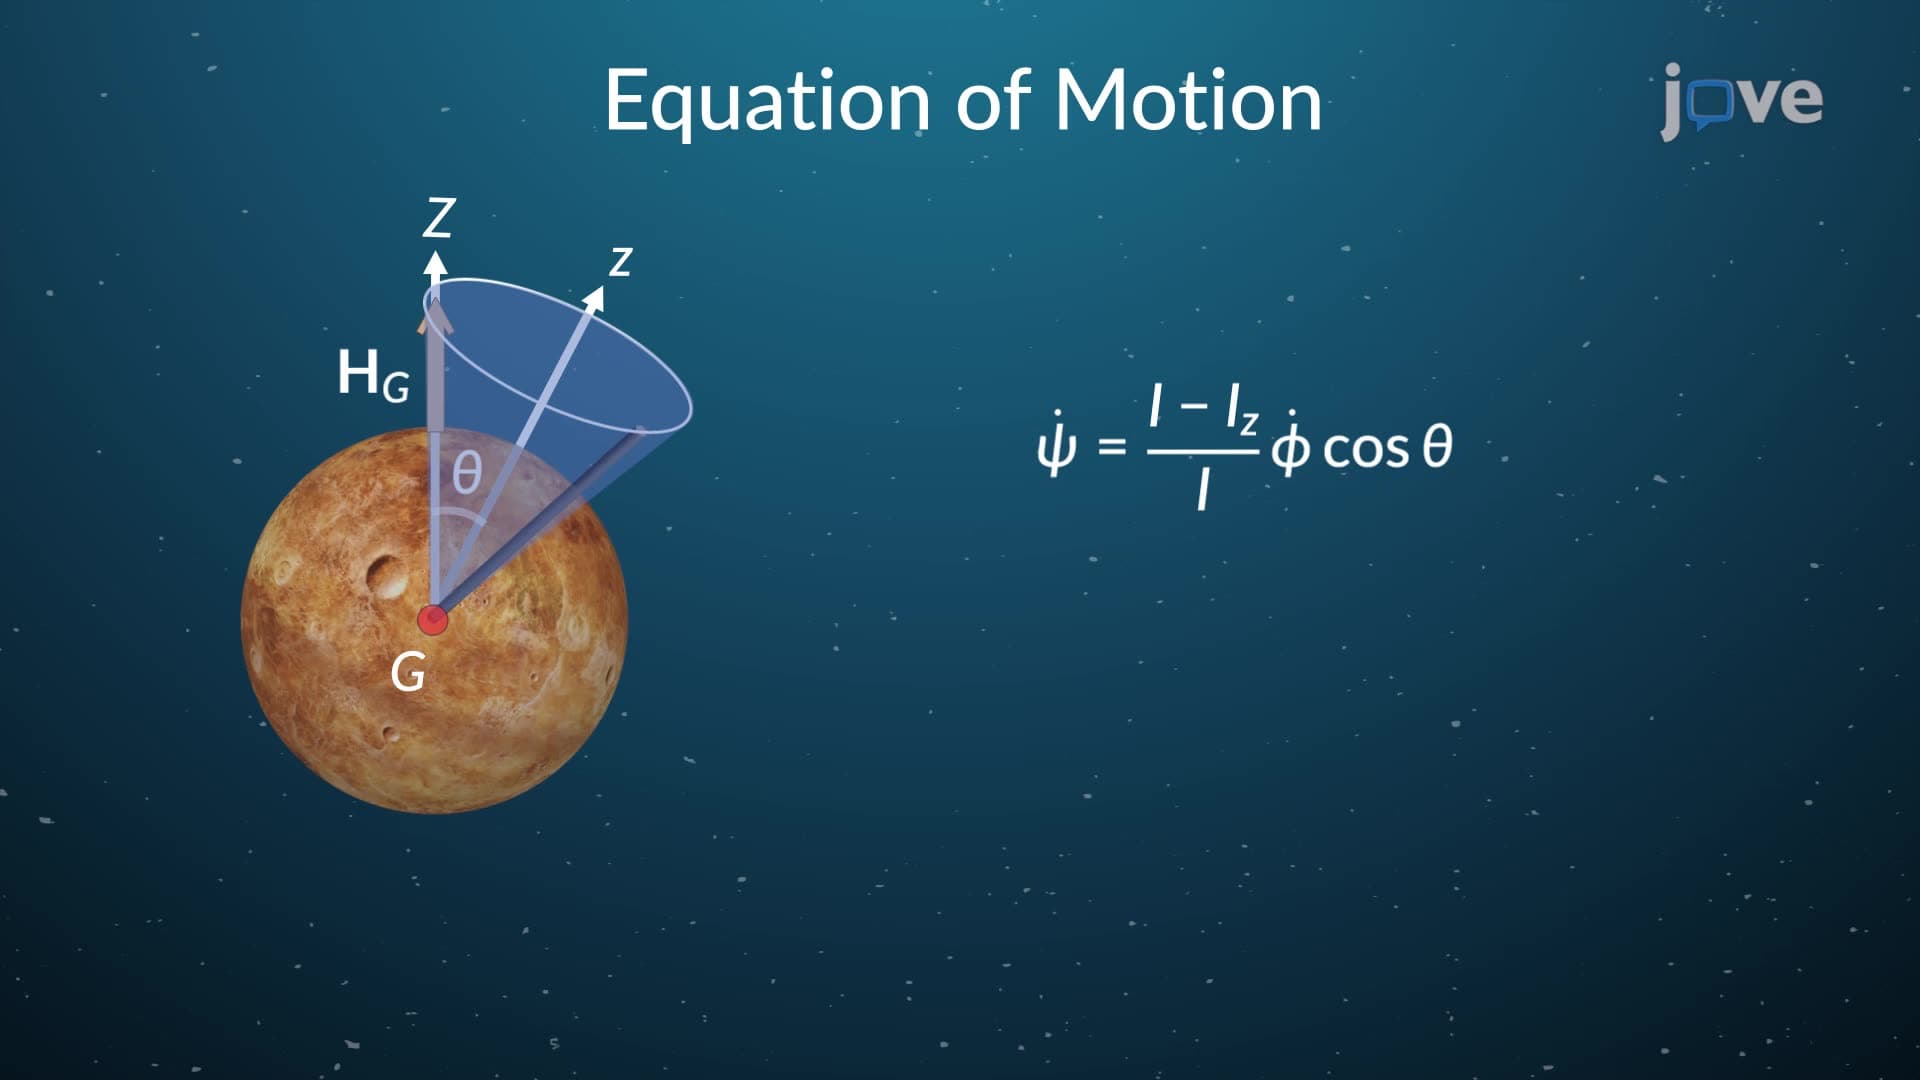
Torque Free Motion

The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
480
Mechanical Systems01:22

Mechanical Systems

Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
191
One-Degree-of-Freedom System01:24

One-Degree-of-Freedom System

In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
487
Virtual Work for a System of Connected Rigid Bodies01:06

Virtual Work for a System of Connected Rigid Bodies

Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
381
Stability of structures01:14

Stability of structures

In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
162
Support Reactions in Three Dimensions01:27

Support Reactions in Three Dimensions

Support reactions in three dimensions help maintain the stability and equilibrium of various structures and systems. These reactions prevent the system from translating and rotating, ensuring the design can withstand external forces and perform its intended function efficiently and safely. Some of the supports providing support reactions in three dimensions are discussed below:
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
961