Related Experiment Video
Updated: Jun 27, 2025
Optimizing Magnetic Force Microscopy Resolution and Sensitivity to Visualize Nanoscale Magnetic Domains
Published on: July 20, 2022
Cramér-Rao Lower Bound for Magnetic Field Localization around Elementary Structures
Armin Dammann1, Benjamin Siebler1, Stephan Sand1
1German Aerospace Center (DLR), Oberpfaffenhofen, 82234 Wessling, Germany.

Abstract:
The determination of a mobile terminal's position with high accuracy and ubiquitous coverage is still challenging. Global satellite navigation systems (GNSSs) provide sufficient accuracy in areas with a clear view to the sky. For GNSS-denied environments like indoors, complementary positioning technologies are required. A promising approach is to use the Earth's magnetic field for positioning. In open areas, the Earth's magnetic field is almost homogeneous, which makes it possible to determine the orientation of a mobile device using a compass. In more complex environments like indoors, ferromagnetic materials cause distortions of the Earth's magnetic field. A compass usually fails in such areas. However, these magnetic distortions are location dependent and therefore can be used for positioning. In this paper, we investigate the influence of elementary structures, in particular a sphere and a cylinder, on the achievable accuracy of magnetic positioning methods. In a first step, we analytically calculate the magnetic field around a sphere and a cylinder in an outer homogeneous magnetic field. Assuming a noisy magnetic field sensor, we investigate the achievable positioning accuracy when observing these resulting fields. For our analysis, we calculate the Cramér-Rao lower bound, which is a fundamental lower bound on the variance of an unbiased estimator. The results of our investigations show the dependency of the positioning error variance on the magnetic sensor properties, in particular the sensor noise variance and the material properties, i.e., the relative permeability of the sphere with respect to the cylinder and the location of the sensor relative to the sphere with respect to the cylinder. The insights provided in this work make it possible to evaluate experimental results from a theoretical perspective.
Related Concept Videos
 01:16
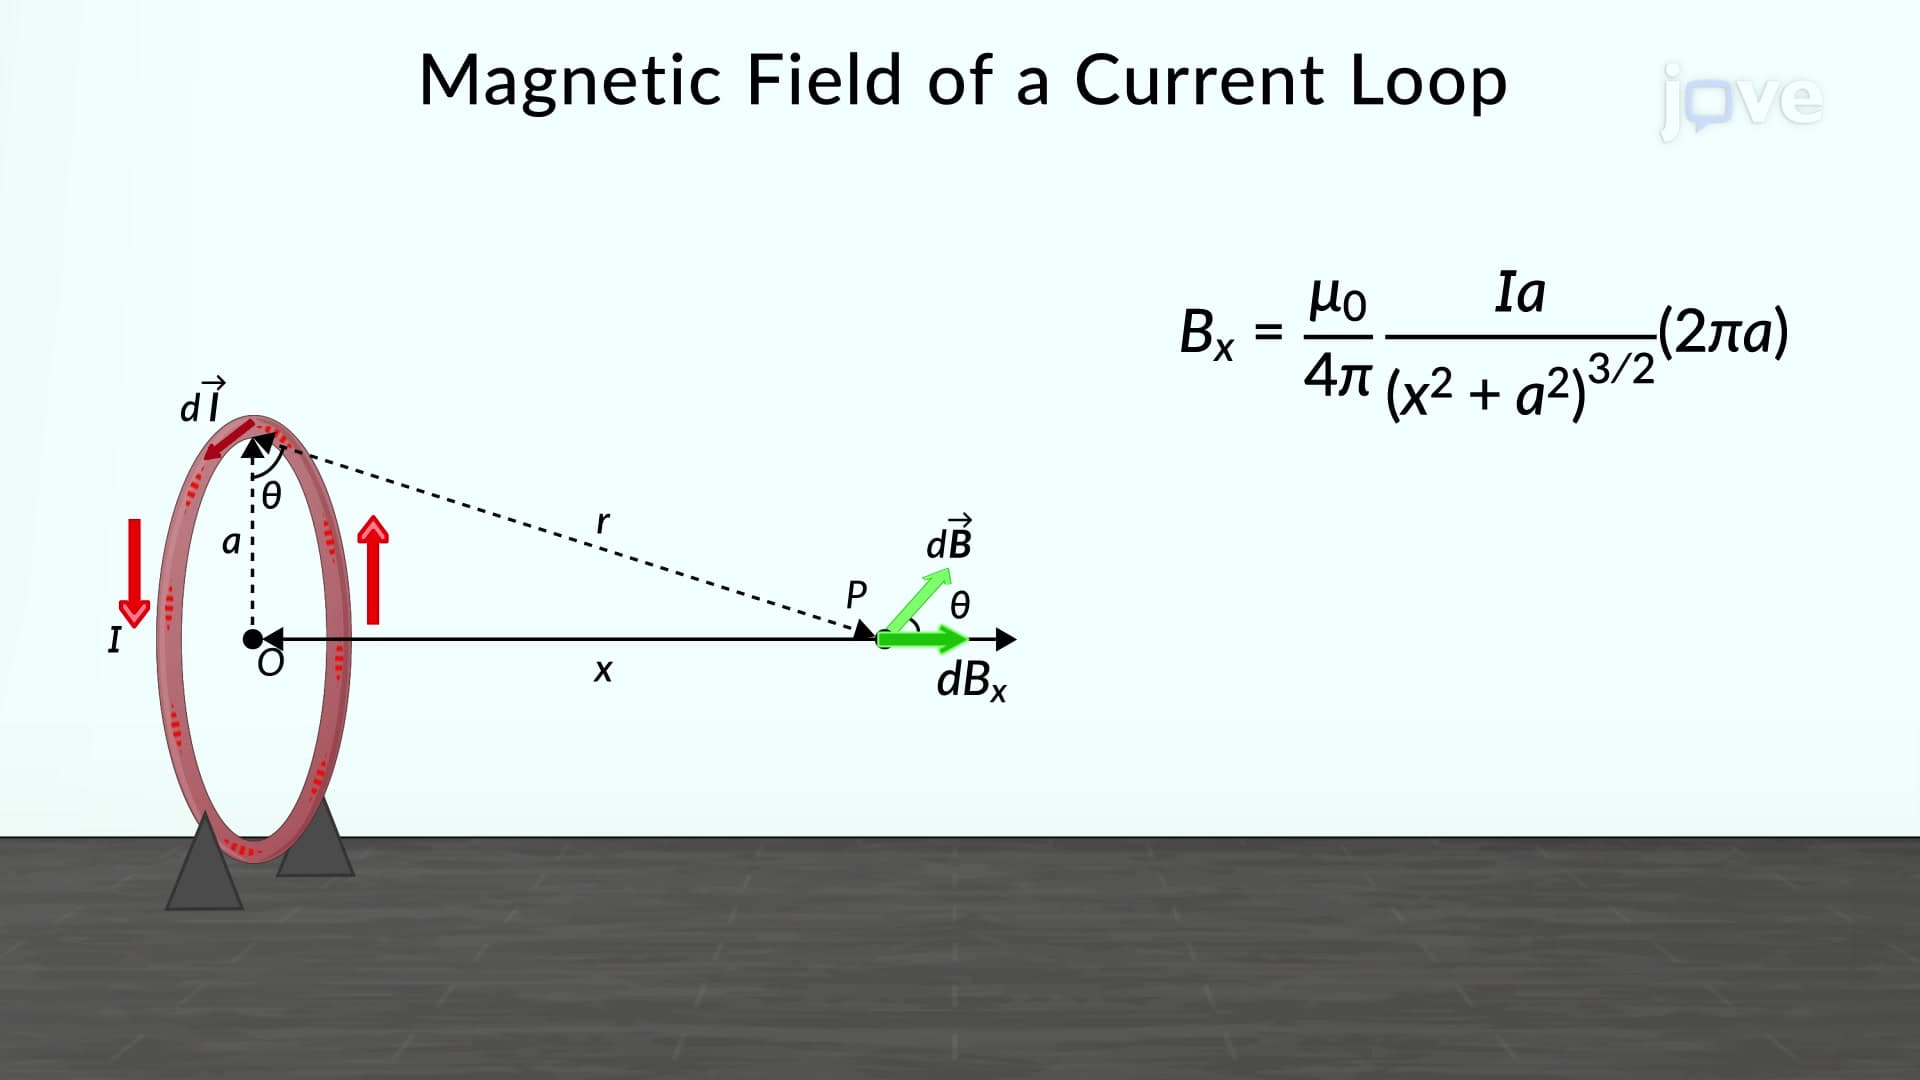
Magnetic Field Of A Current Loop
 01:23
Magnetic Field due to Moving Charges
Consider a point charge moving with a constant velocity. Like the electric field, the magnetic field at any point is directly proportional to the magnitude of the charge and inversely proportional to the square of the distance between the source point and the field point. However, unlike the electric field, the magnetic field is always perpendicular to the plane containing the line...
 01:14
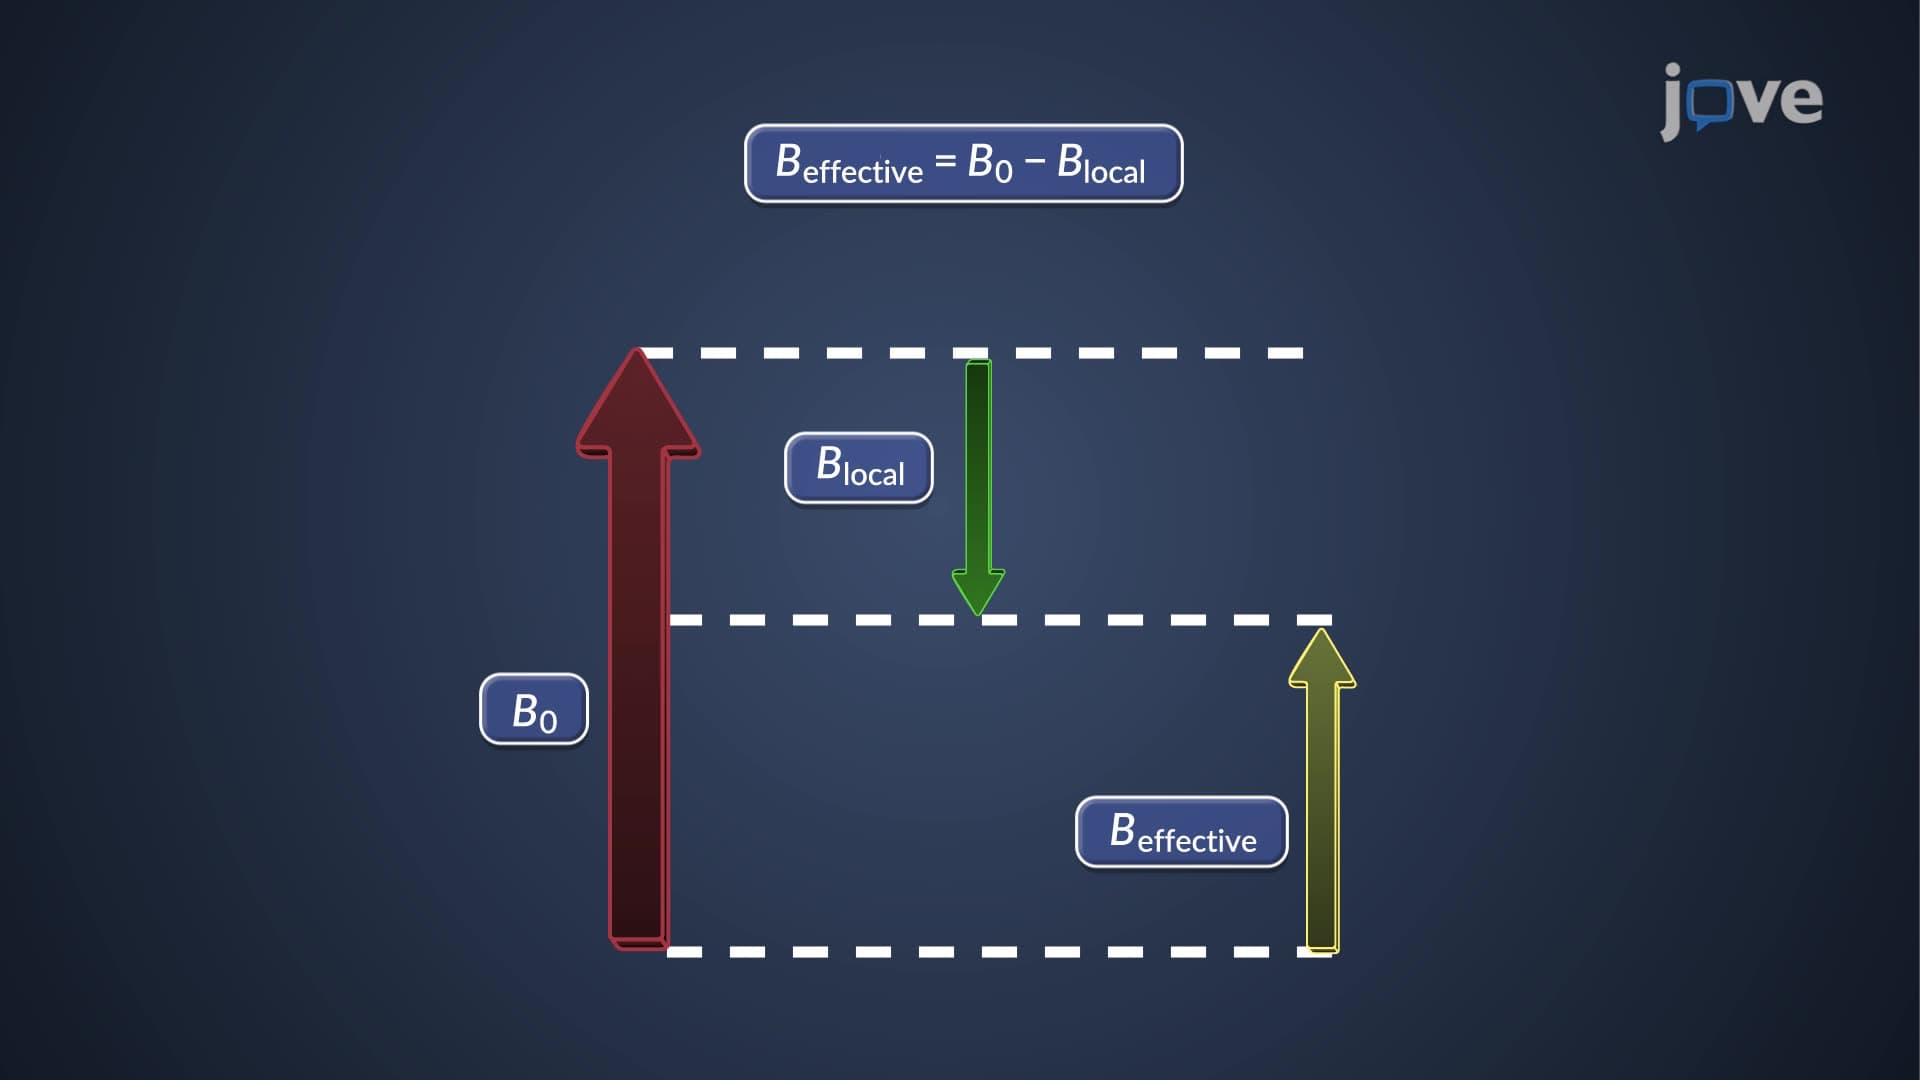
Diamagnetic Shielding of Nuclei: Local Diamagnetic Current
 01:13
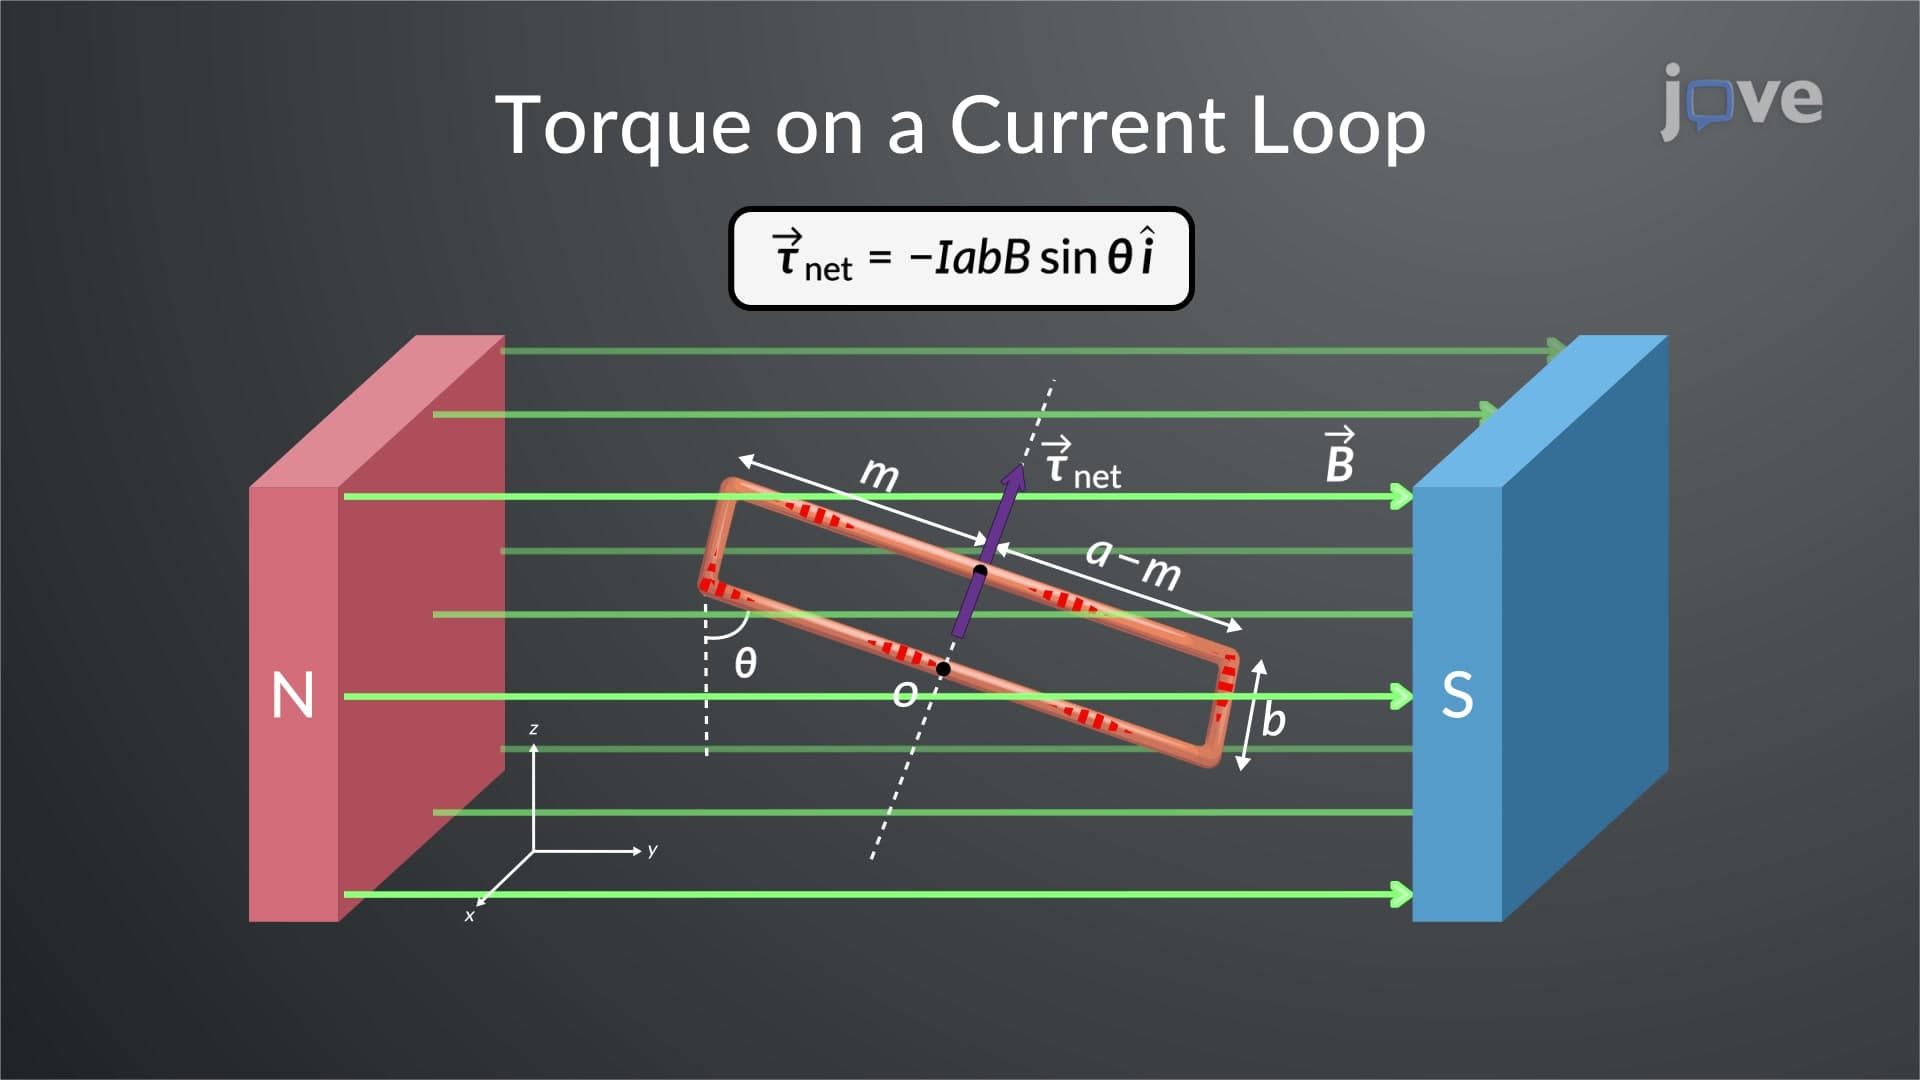
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:24
Potential Due to a Magnetized Object
The vector...
 01:28
Magnetic Field Due To A Thin Straight Wire