Related Experiment Video
Updated: Jun 27, 2025


Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Exploring Human-Exoskeleton Interaction Dynamics: An In-Depth Analysis of Knee Flexion-Extension Performance across
Denis Mosconi1,2, Yecid Moreno2, Adriano Siqueira2,3
1Industry Department, Federal Institute of São Paulo, Catanduva 15808-305, Brazil.

Abstract:
Knee rehabilitation therapy after trauma or neuromotor diseases is fundamental to restore the joint functions as best as possible, exoskeleton robots being an important resource in this context, since they optimize therapy by applying tailored forces to assist or resist movements, contributing to improved patient outcomes and treatment efficiency. One of the points that must be taken into account when using robots in rehabilitation is their interaction with the patient, which must be safe for both and guarantee the effectiveness of the treatment. Therefore, the objective of this study was to assess the interaction between humans and an exoskeleton during the execution of knee flexion-extension movements under various configurations of robot assistance and resistance. The evaluation encompassed considerations of myoelectric activity, muscle recruitment, robot torque, and performed movement. To achieve this, an experimental protocol was implemented, involving an individual wearing the exoskeleton and executing knee flexion-extension motions while seated, with the robot configured in five distinct modes: passive (P), assistance on flexion (FA), assistance on extension (EA), assistance on flexion and extension (CA), and resistance on flexion and extension (CR). Results revealed distinctive patterns of movement and muscle recruitment for each mode, highlighting the complex interplay between human and robot; for example, the largest RMS tracking errors were for the EA mode (13.72 degrees) while the smallest for the CR mode (4.47 degrees), a non-obvious result; in addition, myoelectric activity was demonstrated to be greater for the completely assisted mode than without the robot (the maximum activation levels for the vastus medialis and vastus lateralis muscles were more than double those when the user had assistance from the robot). Tracking errors, muscle activations, and torque values varied across modes, emphasizing the need for careful consideration in configuring exoskeleton assistance and resistance to ensure effective and safe rehabilitation. Understanding these human-robot interactions is essential for developing precise rehabilitation programs, optimizing treatment effectiveness, and enhancing patient safety.


Related Concept Videos
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:16
Bones of the Lower Limb: Femur and Patella
 01:23
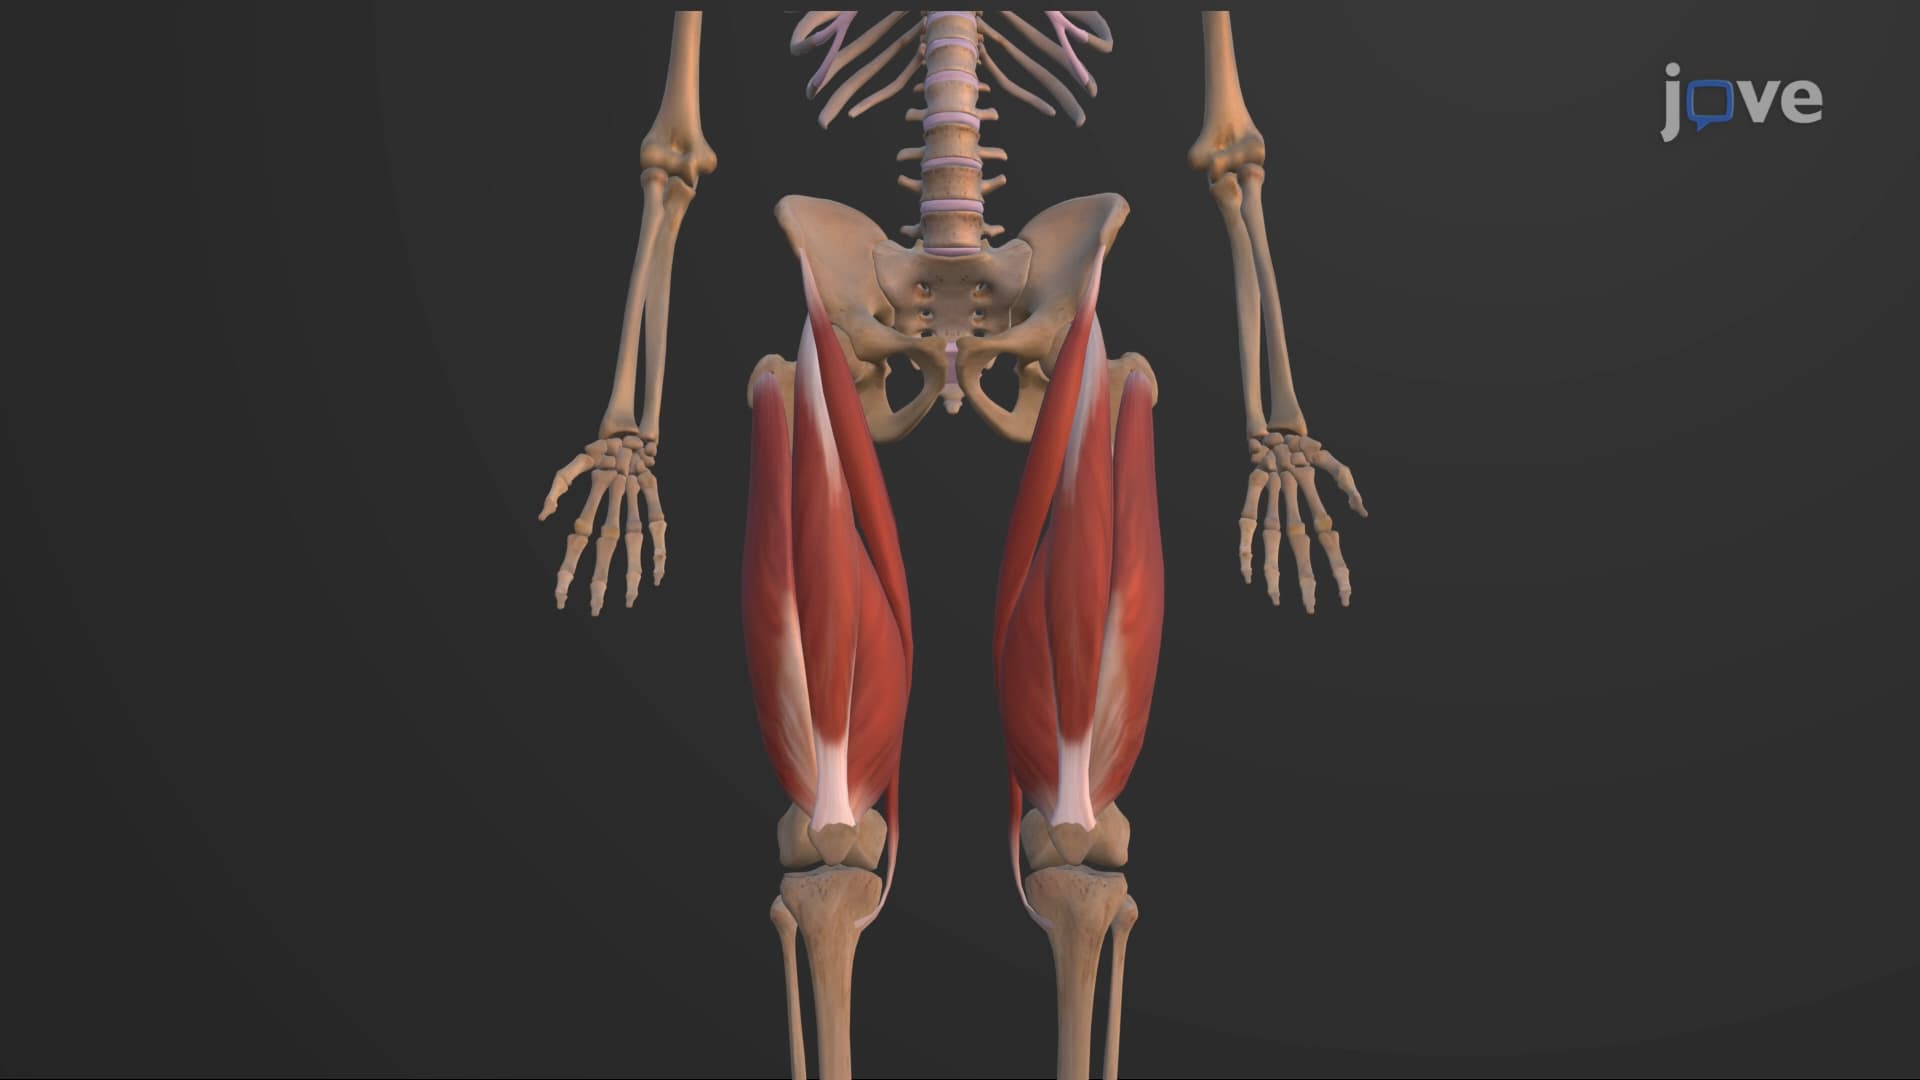
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...