Related Experiment Video
Updated: Jun 27, 2025


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
Implementing Gait Kinematic Trajectory Forecasting Models on an Embedded System
Madina Shayne1, Leonardo A Molina2, Bin Hu3
1Department of Mechanical and Manufacturing Engineering, University of Calgary, 2500 University Drive NW, Calgary, AB T2N 1N4, Canada.

Abstract:
Smart algorithms for gait kinematic motion prediction in wearable assistive devices including prostheses, bionics, and exoskeletons can ensure safer and more effective device functionality. Although embedded systems can support the use of smart algorithms, there are important limitations associated with computational load. This poses a tangible barrier for models with increased complexity that demand substantial computational resources for superior performance. Forecasting through Recurrent Topology (FReT) represents a computationally lightweight time-series data forecasting algorithm with the ability to update and adapt to the input data structure that can predict complex dynamics. Here, we deployed FReT on an embedded system and evaluated its accuracy, computational time, and precision to forecast gait kinematics from lower-limb motion sensor data from fifteen subjects. FReT was compared to pretrained hyperparameter-optimized NNET and deep-NNET (D-NNET) model architectures, both with static model weight parameters and iteratively updated model weight parameters to enable adaptability to evolving data structures. We found that FReT was not only more accurate than all the network models, reducing the normalized root-mean-square error by almost half on average, but that it also provided the best balance between accuracy, computational time, and precision when considering the combination of these performance variables. The proposed FReT framework on an embedded system, with its improved performance, represents an important step towards the development of new sensor-aided technologies for assistive ambulatory devices.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
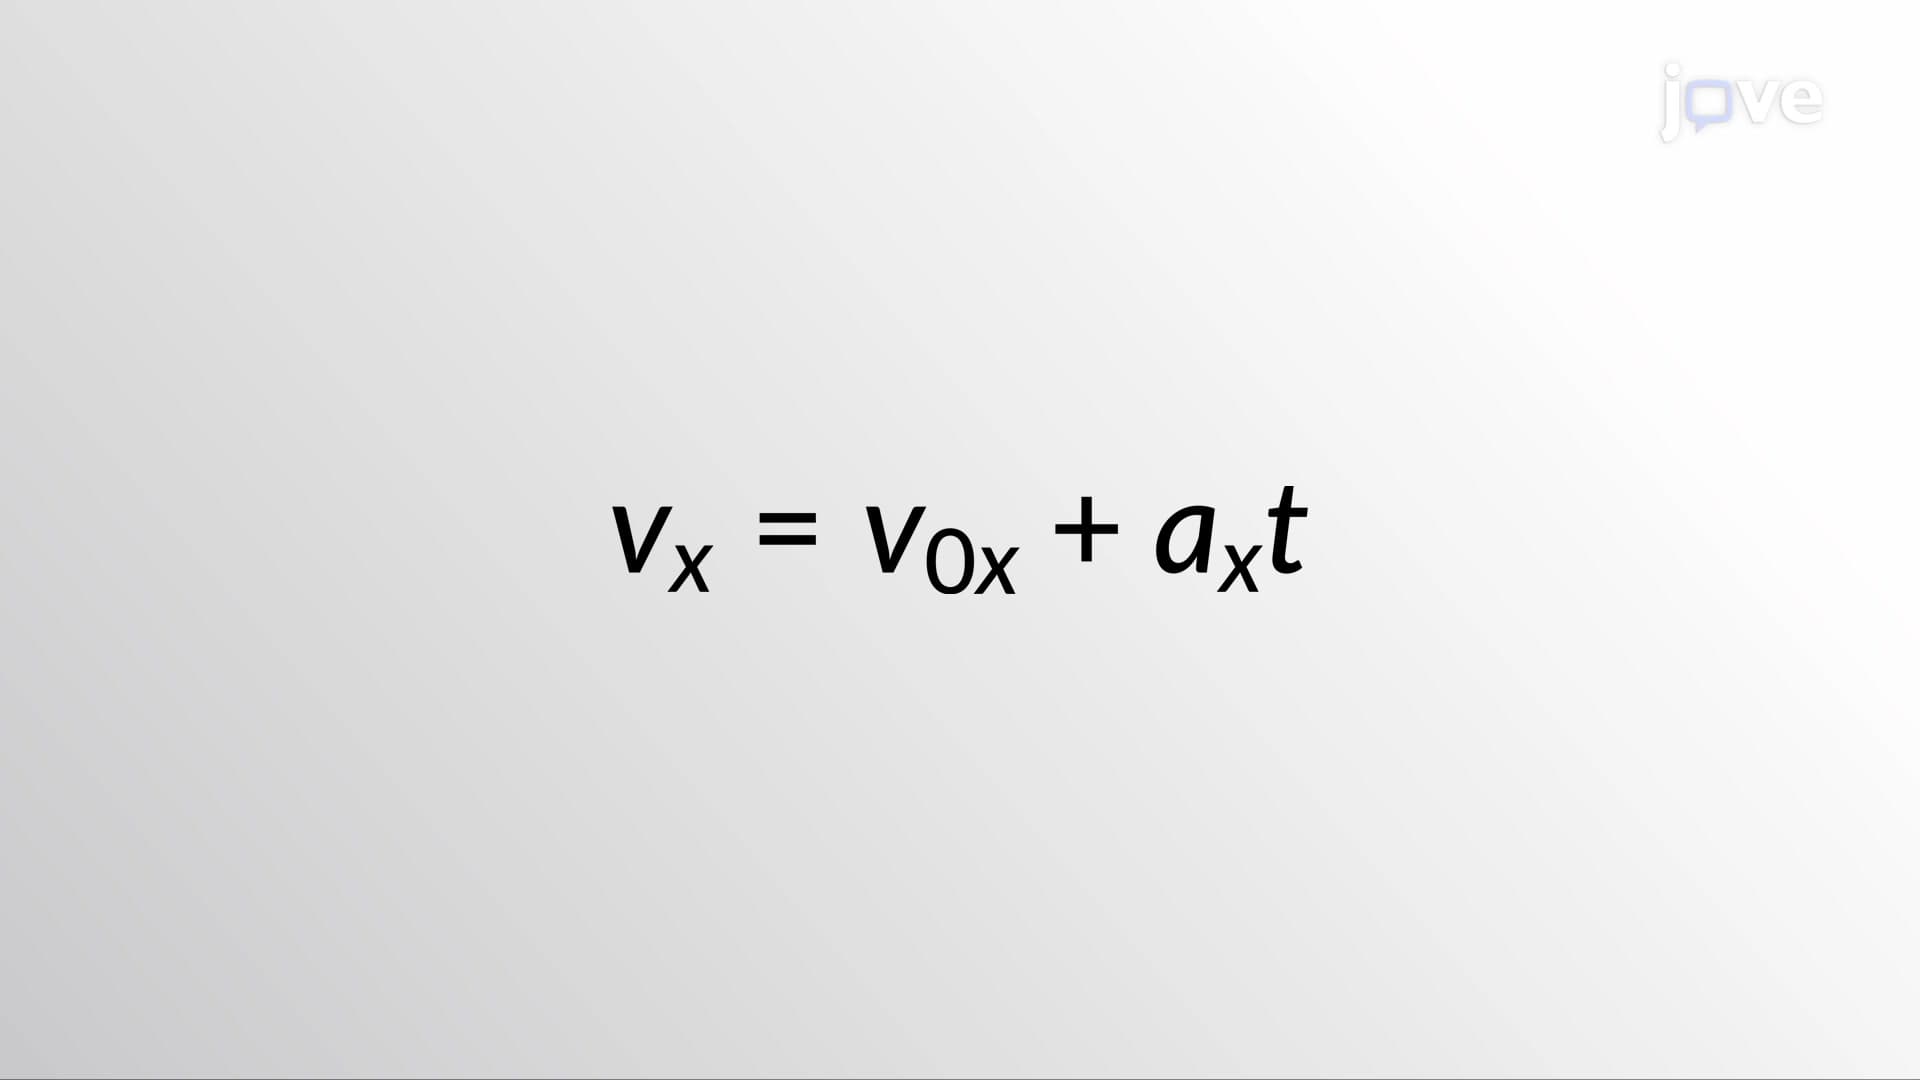 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...