Related Experiment Video
Updated: Jul 6, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Generalizability of foot placement control strategies during unperturbed and perturbed gait
Chang Liu1, Francisco J Valero-Cuevas1,2,3, James M Finley1,2,3
1Department of Biomedical Engineering, University of Southern California, Los Angeles, CA, USA.

Abstract:
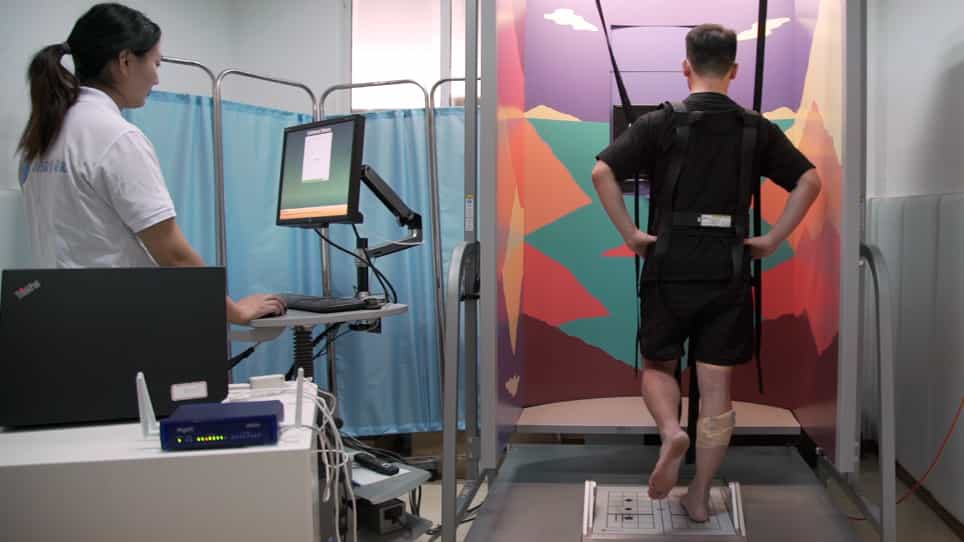
Control of foot placement is an essential strategy for maintaining balance during walking. During unperturbed, steady-state walking, foot placement can be accurately described as a linear function of the body's centre of mass (CoM) state at midstance. However, it is uncertain if this mapping from CoM state to foot placement generalizes to larger perturbations that could potentially cause falls. Recovery from these perturbations may require reactive control strategies not observed during unperturbed walking. Here, we used unpredictable changes in treadmill belt speed to assess the generalizability of foot placement mappings identified during unperturbed walking. We found that foot placement mappings generalized poorly from unperturbed to perturbed walking and differed for forward perturbation versus backward perturbation. We also used the singular value decomposition of the mapping matrix to reveal that people were more sensitive to backward versus forward perturbations. Together, these results indicate that a single linear mapping cannot describe the foot placement control during both forward and backward losses of balance induced by treadmill belt speed perturbations. Better characterization of human balance control strategies could improve our understanding of why different neuromotor disorders result in heightened fall risk and inform the design of controllers for balance-assisting devices.
More Related Videos
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...