A Segmented Iterative Learning Scheme-Based Distributed Fault Estimation for Switched Interconnected Nonlinear Systems


Abstract:
In this article, a distributed fault estimation (DFE) approach for switched interconnected nonlinear systems (SINSs) with time delays and external disturbances is proposed using a novel segmented iterative learning scheme (SILS). First, through the utilization of interrelated information among subsystems, a distributed iterative learning observer is developed to enhance the accuracy of fault estimation results, which can realize the fault estimation of all subsystems under time delays and external disturbances. Simultaneously, to facilitate rapid fault information tracking and significantly reduce sensitivity to interference, a new SILS-based fault estimation law is constructed by combining the idea of segmented design with the method of variable gain. Then, an assessment of the convergence of the established fault estimation methodology is conducted, and the configurations of observer gain matrices and iterative learning gain matrices are duly accomplished. Finally, simulation results are showcased to demonstrate the superiority and feasibility of the developed fault estimation approach.


Related Concept Videos
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:24
Bus Impedance Matrix
In the first circuit, all machine voltage sources are short-circuited, leaving only the prefault voltage source at the fault location. The positive-sequence bus impedance matrix can be determined by solving the nodal equations,...
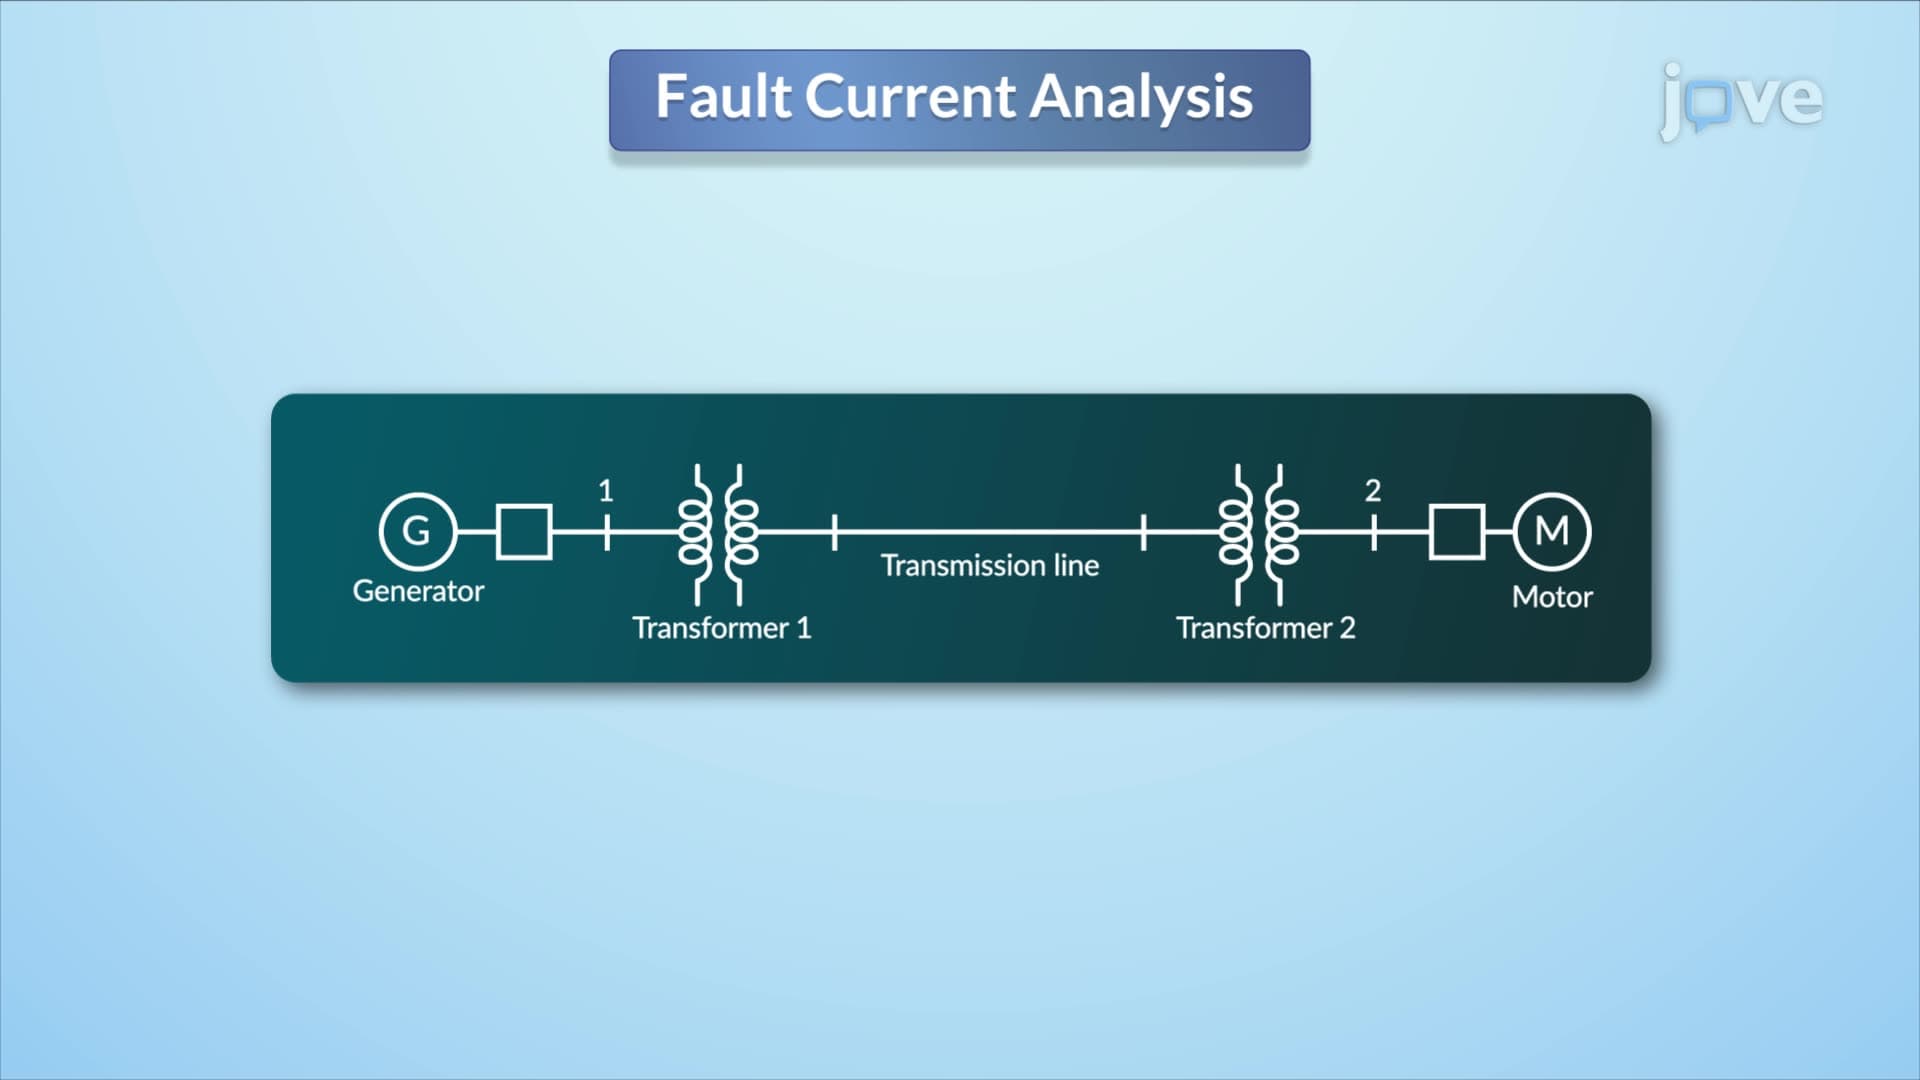 01:21
Power System Three-Phase Short Circuits
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:18
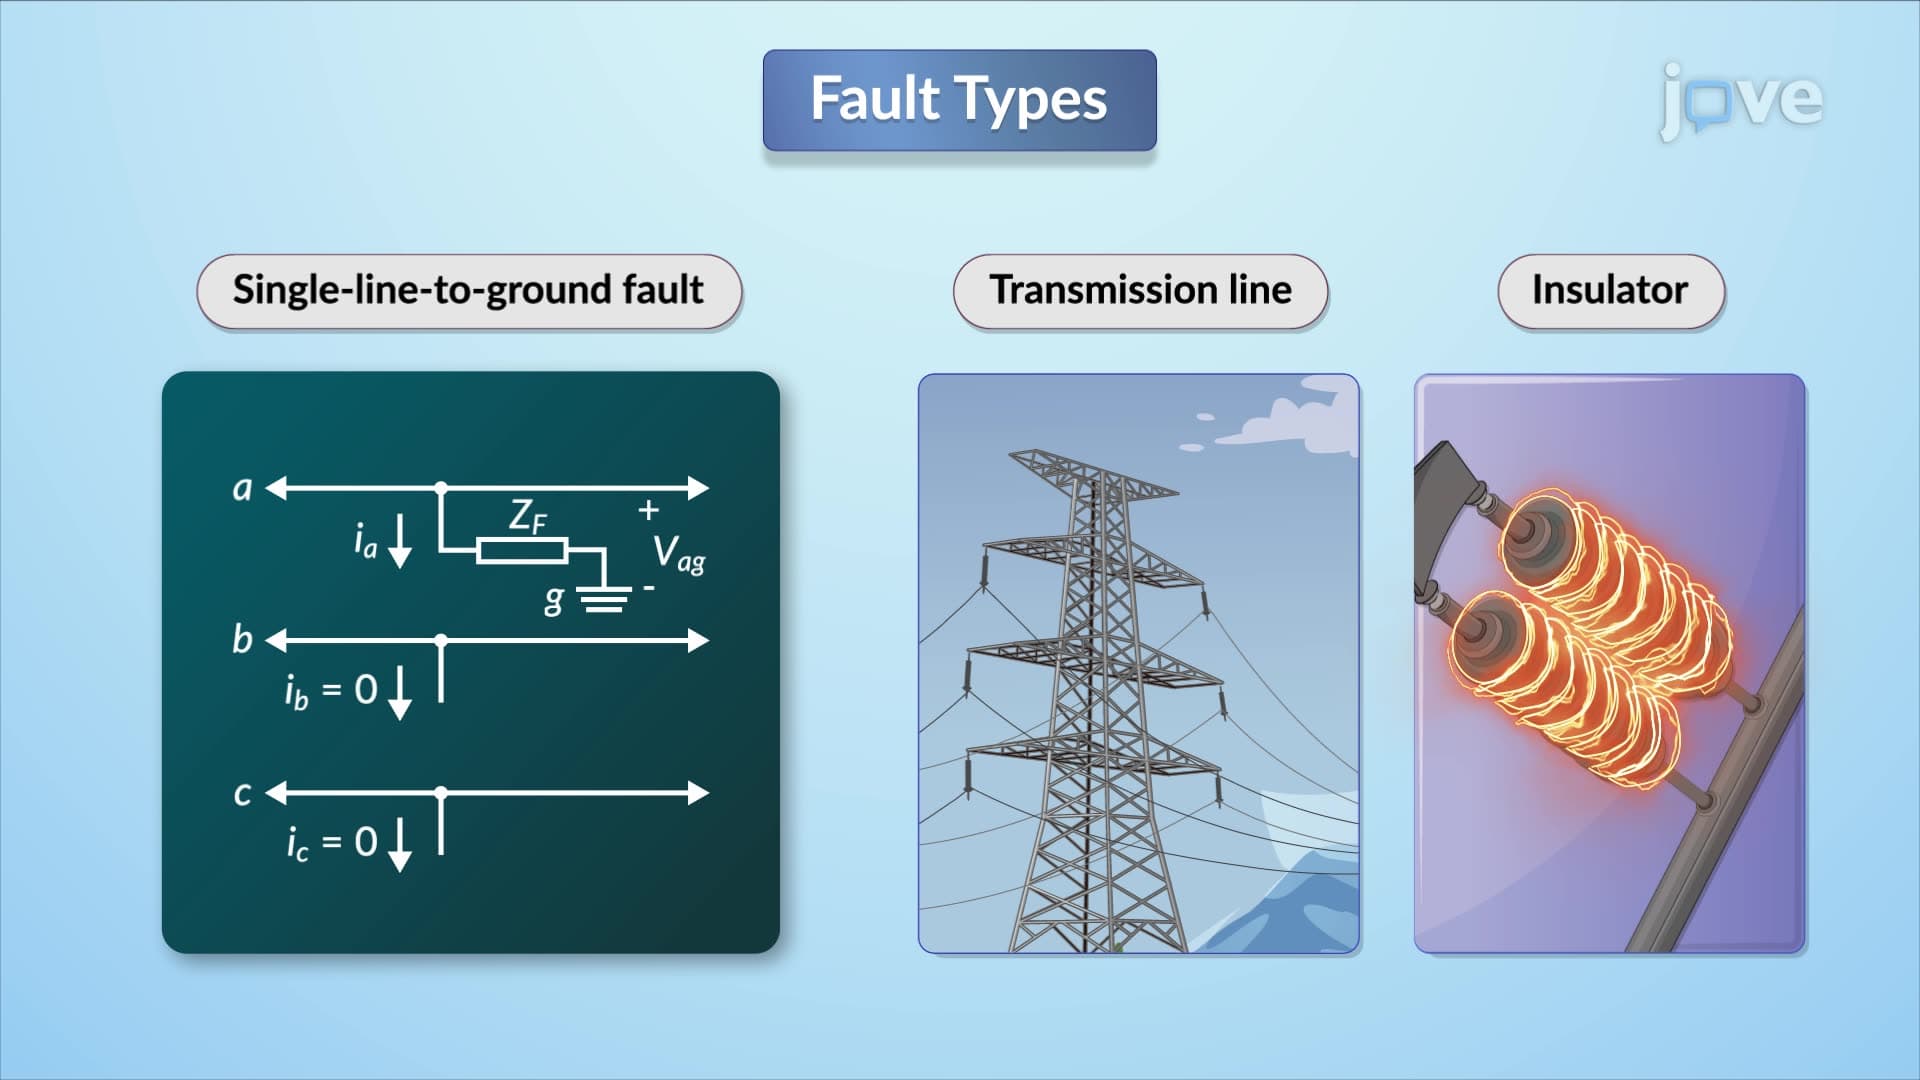
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...