Related Experiment Video
Updated: Jun 26, 2025
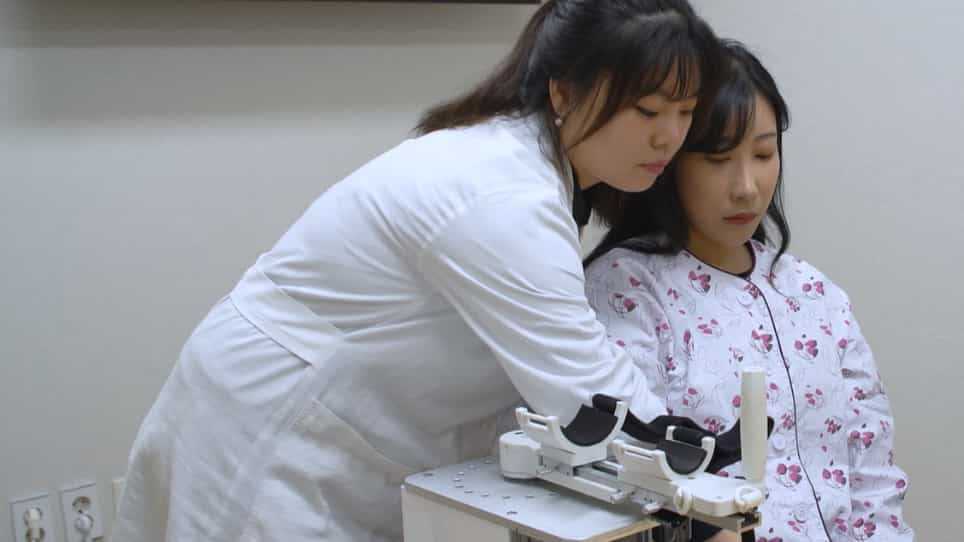

Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
An Operating Stiffness Controller for the Medical Continuum Robot Based on Impedance Control
Jinyu Duan1, Kai Zhang1, Kun Qian2
1Key Laboratory of Mechanism Theory and Equipment Design of Ministry of Education, School of Mechanical Engineering, Tianjin University, Tianjin 300072, China.

Abstract:
Continuum manipulators can conform to curvilinear paths and manipulate objects in complex environments, which makes it emerging to be applied in minimally invasive surgery (MIS). However, different and controllable operating stiffness of the continuum manipulator is required during different stages of surgery to achieve safe access or stable and precise operation. This work proposes an operating stiffness controller (OSC) for the typical tendon-driven continuum manipulator based on the variable impedance control method with Lagrangian dynamic modeling. This controller can adjust the operating stiffness by modifying the driving forces along the driving tendons of the continuum manipulator without changing its material or structure. The proposed OSC converts the damping and stiffness matrices of the impedance control into variable parameters. This merit allows it to dynamically adjust the operating stiffness of the continuum manipulator according to the desired constant or time-varying stiffness. Furthermore, the OSC stability can be proven based on a Lyapunov function, and its stiffness control performances have been analyzed and evaluated in both simulations and experiments. The OSC controller generated average relevant error values of 7.82% and 3.09% for the operating stiffness control experiments with constant and time-varying desired stiffness, respectively. These experimental results indicate that the OSC has high accuracy, stability, and strong robustness in the operating stiffness control tasks.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:19
PID Controller
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...