Related Experiment Video
Updated: Jun 26, 2025
Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Evaluating the safety and efficiency impacts of forced lane change with negative gaps based on empirical vehicle
Kequan Chen1, Zhibin Li1, Pan Liu1
1School of Transportation, Southeast University, Southeast University Road #2, Nanjing 211189, China.

Abstract:
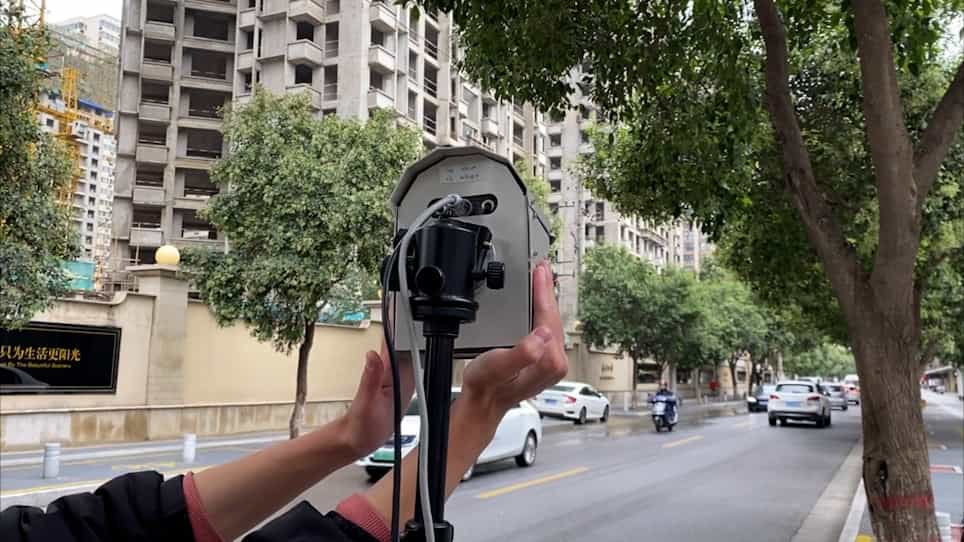
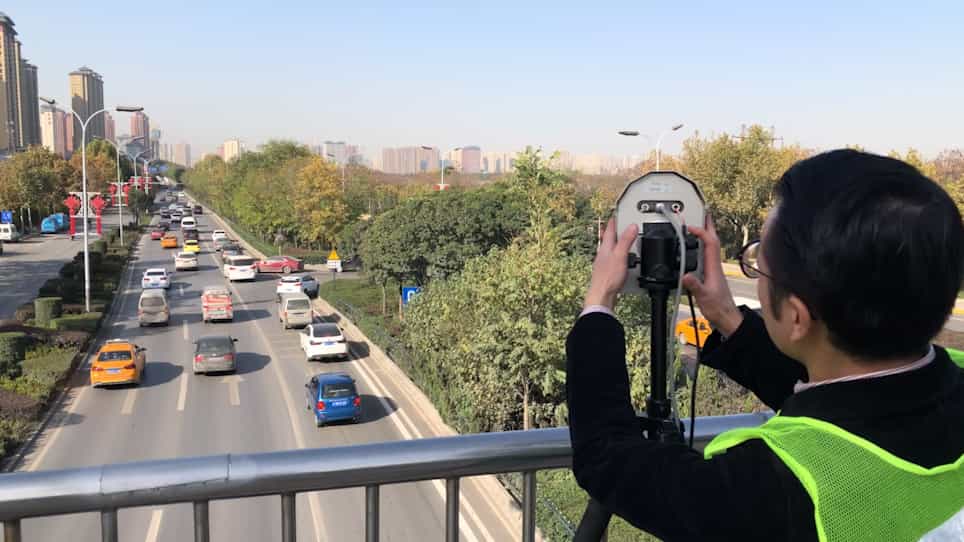
A lane-changing (LC) maneuver may cause the follower in the target lane (new follower) to decelerate and give up space, potentially affecting crash risk and traffic flow efficiency. In congested flow, a more aggressive LC maneuver occurs where the lane changer is partially next to the new follower and creates negative gaps, namely negative gap forced LC (NGFLC). Although NGFLC forms the foundation of sideswipe crashes, little has been done to address its impacts and the contributing factors. To tackle this issue, a total of 15,810 LC trajectory samples are extracted from three drone videos at different locations. These samples are categorized into NGFLC and normal LC groups for comparative analysis. Five commonly used conflict indicators are extended into two-dimensional to evaluate the crash risk of LC maneuver. The change of time gaps during LC maneuver are examined to quantify the impact of LC on traffic flow efficiency. We find that NGFLCs significantly increase crash risk, reflected by the number of hazardous LC events and potential crash areas compared to normal LC. Additionally, results reveal that both the lane changer and the new follower tend to maintain a larger time gap after NGFLCs. Factors including time headway, relative speed, and historical gaps in the target lane significantly affect NGFLC incidence. Once the movement of the leader in the original lane is taken into account, the prediction accuracy improves from 81% to 91%. The transferability tests indicate that the findings about the negative impact of NGFLC and the accuracy of its prediction model are consistent across different locations. These findings hold implications for driving assistance systems to better predict and mitigate NGFLCs.
Related Concept Videos
 01:41
Social Traps
 01:17
Dynamics Of Circular Motion: Applications
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:17
Rolling Resistance: Problem Solving
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:27
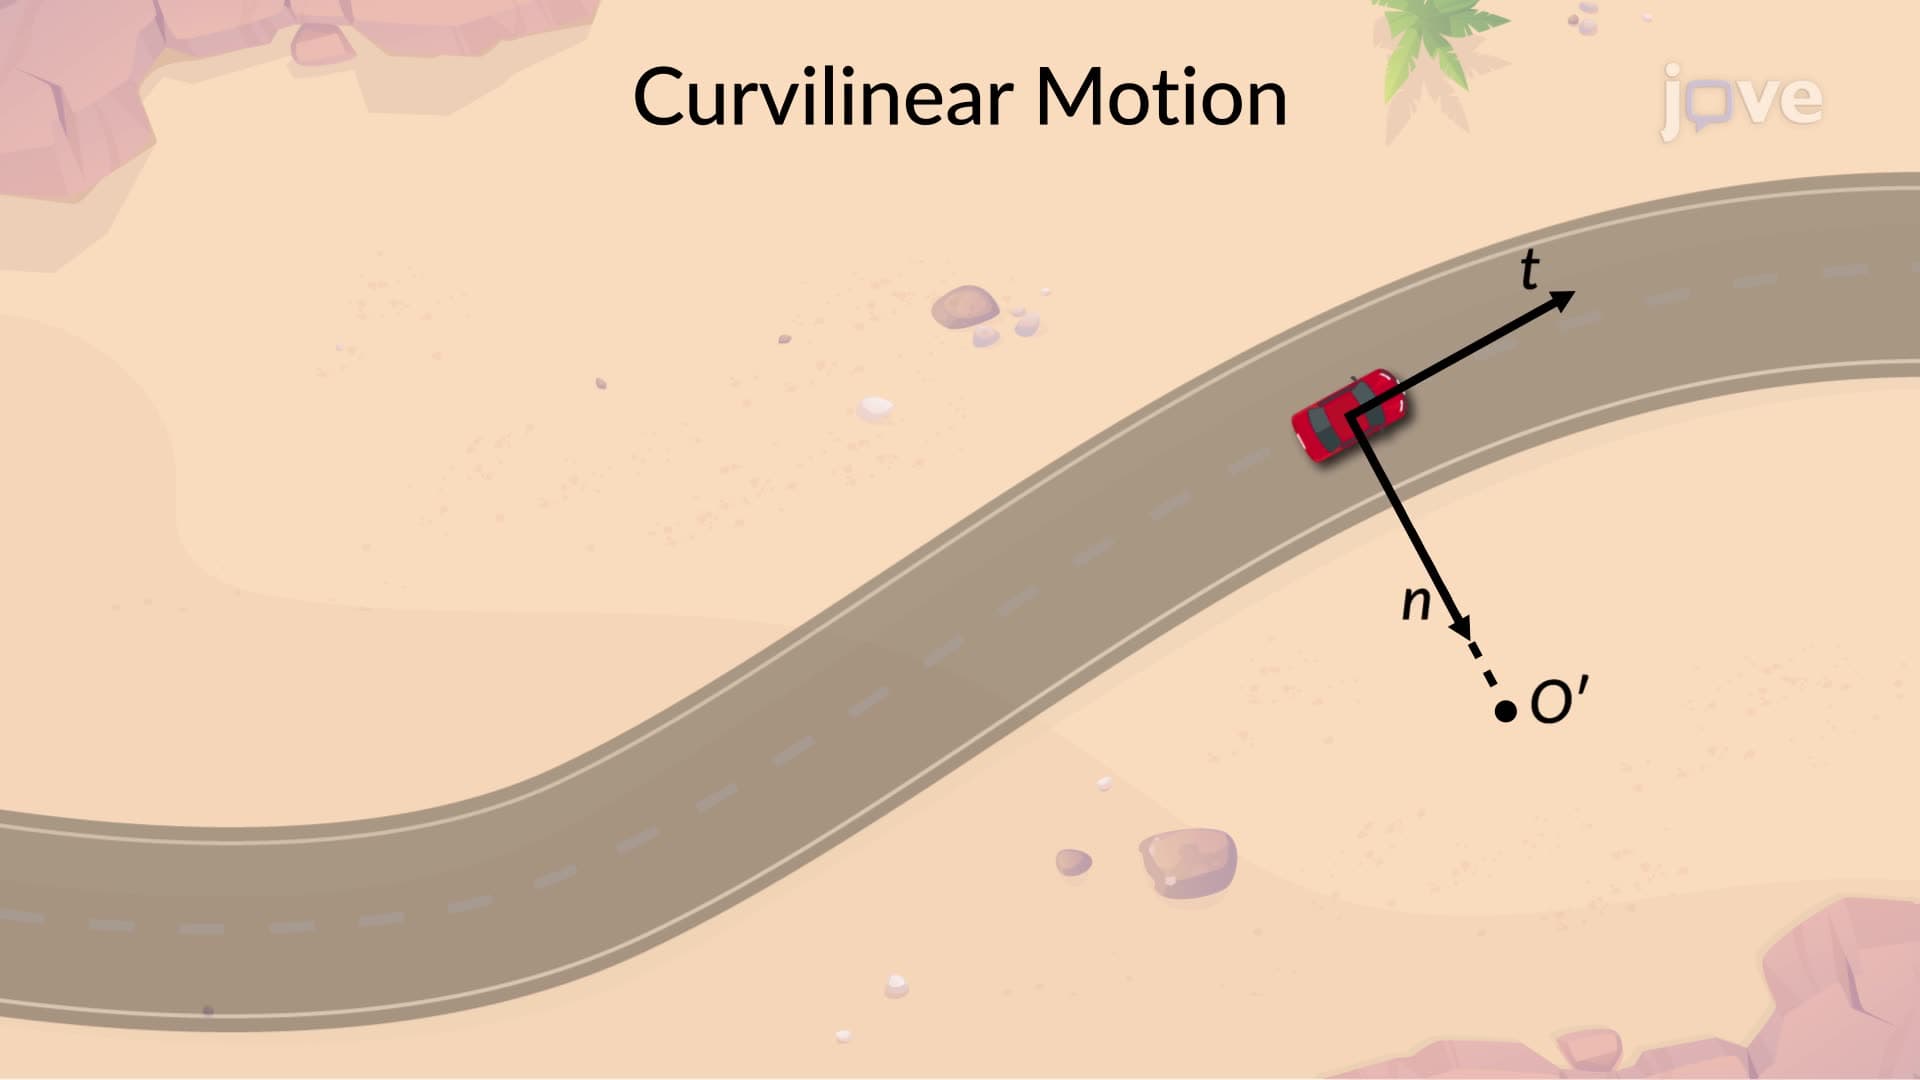
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...