Coupling magnetic torque and force for colloidal microbot assembly and manipulation
Related Experiment Video
Updated: Jun 26, 2025
High-Speed Magnetic Tweezers for Nanomechanical Measurements on Force-Sensitive Elements
Published on: May 12, 2023
Coy J Zimmermann1, Andrew J Petruska2, Keith B Neeves3
1Department of Chemical and Biological Engineering, Colorado School of Mines, Golden, CO, USA.

Abstract:
For targeted transport in the body, biomedical microbots (μbots) must move effectively in three-dimensional (3D) microenvironments. Swimming μbots translate via asymmetric or screw-like motions while rolling ones use friction with available surfaces to generate propulsive forces. We have previously shown that planar rotating magnetic fields assemble μm-scale superparamagnetic beads into circular μbots that roll along surfaces. In this, gravity is required to pull μbots near the surface; however, this is not necessarily practical in complex geometries. Here we show that rotating magnetic fields, in tandem with directional magnetic gradient forces, can be used to roll μbots on surfaces regardless of orientation. Simplifying implementation, we use a spinning permanent magnet to generate differing ratios of rotating and gradient fields, optimizing control for different environments. This use of a single magnetic actuator sidesteps the need for complex electromagnet or tandem field setups, removes requisite gravitational load forces, and enables μbot targeting in complex 3D biomimetic microenvironments.
Related Concept Videos
 01:18
Magnetic Force
The magnetic force acting on a moving charge...
 01:13
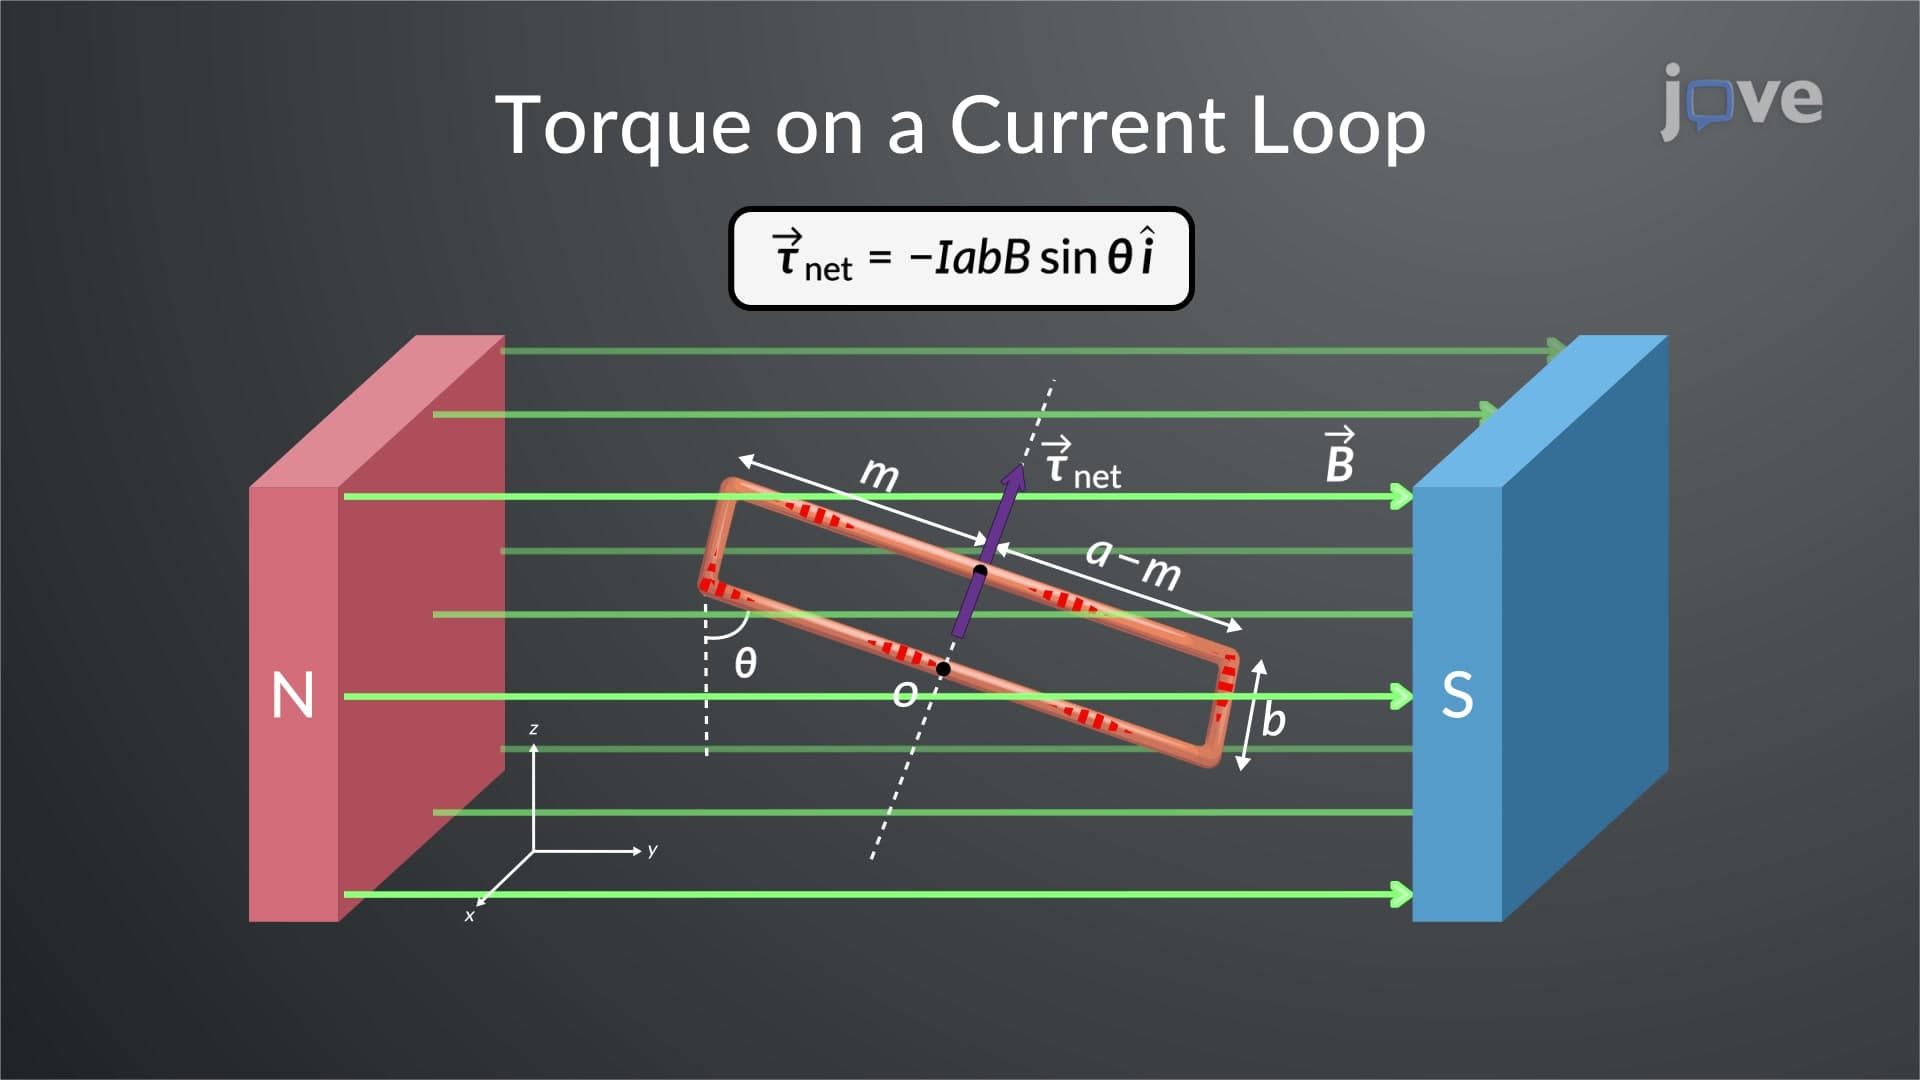
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:23
Simplification of a Force and Couple System: II
 01:24
Potential Due to a Magnetized Object
The vector...
 01:17
Force On A Current Loop In A Magnetic Field
 01:24
Bearings: Problem Solving