Related Experiment Video
Updated: Jun 25, 2025

Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
Depth Control of an Underwater Sensor Platform: Comparison between Variable Buoyancy and Propeller Actuated Devices
João Falcão Carneiro1,2, João Bravo Pinto2, Fernando Gomes de Almeida1,2
1Instituto de Ciência e Inovação em Engenharia Mecânica e Engenharia Industrial, Faculdade de Engenharia, Universidade do Porto, Rua Dr. Roberto Frias, s/n, 4200-465 Porto, Portugal.

Abstract:
Underwater long-endurance platforms are crucial for continuous oceanic observation, allowing for sustained data collection from a multitude of sensors deployed across diverse underwater environments. They extend mission durations, reduce maintenance needs, and significantly improve the efficiency and cost-effectiveness of oceanographic research endeavors. This paper investigates the closed-loop depth control of actuation systems employed in underwater vehicles, focusing on the energy consumption of two different mechanisms: variable buoyancy and propeller actuated devices. Using a prototype previously developed by the authors, this paper presents a detailed model of the vehicle using both actuation solutions. The proposed model, although being a linear-based one, accounts for several nonlinearities that are present such as saturations, sensor quantization, and the actuator brake model. Also, it allows a simple estimation of the energy consumption of both actuation solutions. Based on the developed models, this study then explores the intricate interplay between energy consumption and control accuracy. To this end, several PID-based controllers are developed and tested in simulation. These controllers are used to evaluate the dynamic response and power requirements of variable buoyancy systems and propeller actuated devices under various operational conditions. Our findings contribute to the optimization of closed-loop depth control strategies, offering insights into the trade-offs between energy efficiency and system effectiveness in diverse underwater applications.
Related Concept Videos
 00:59
Buoyancy
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
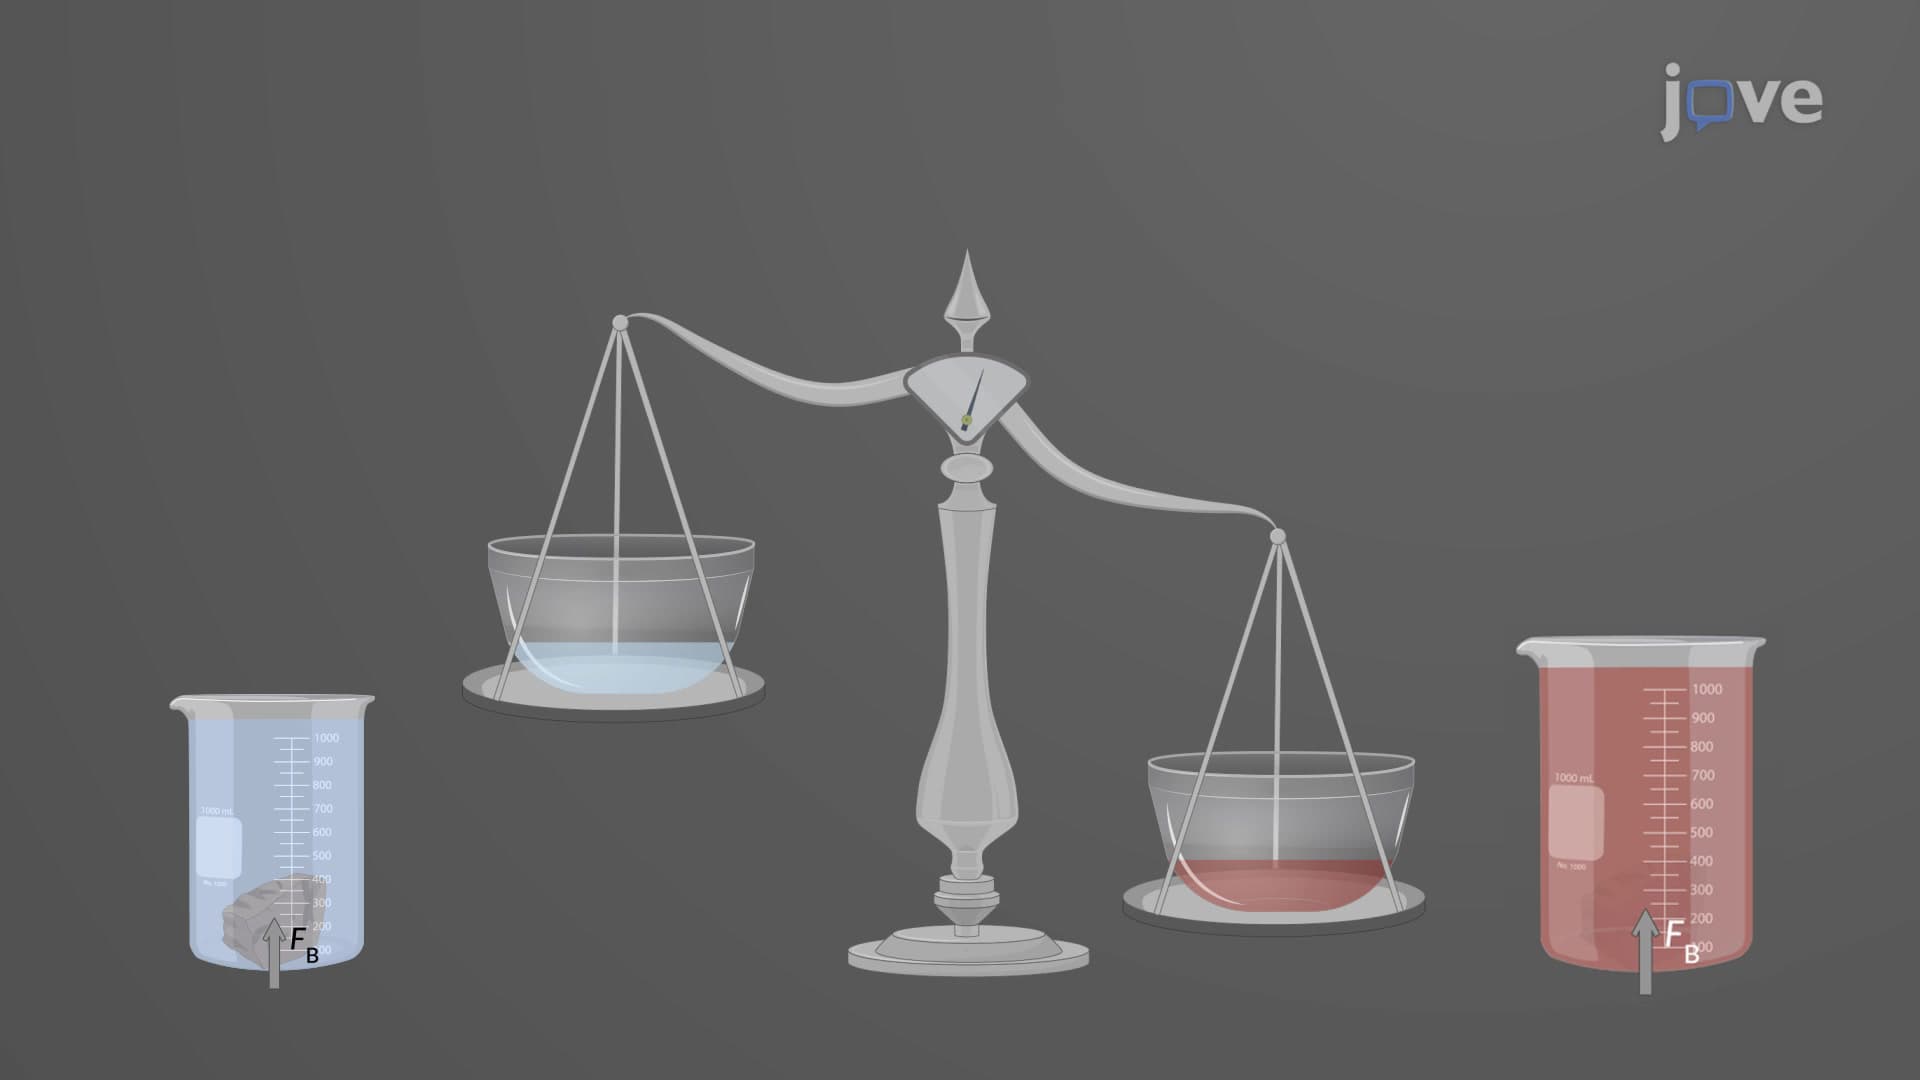 01:05
Density and Archimedes' Principle
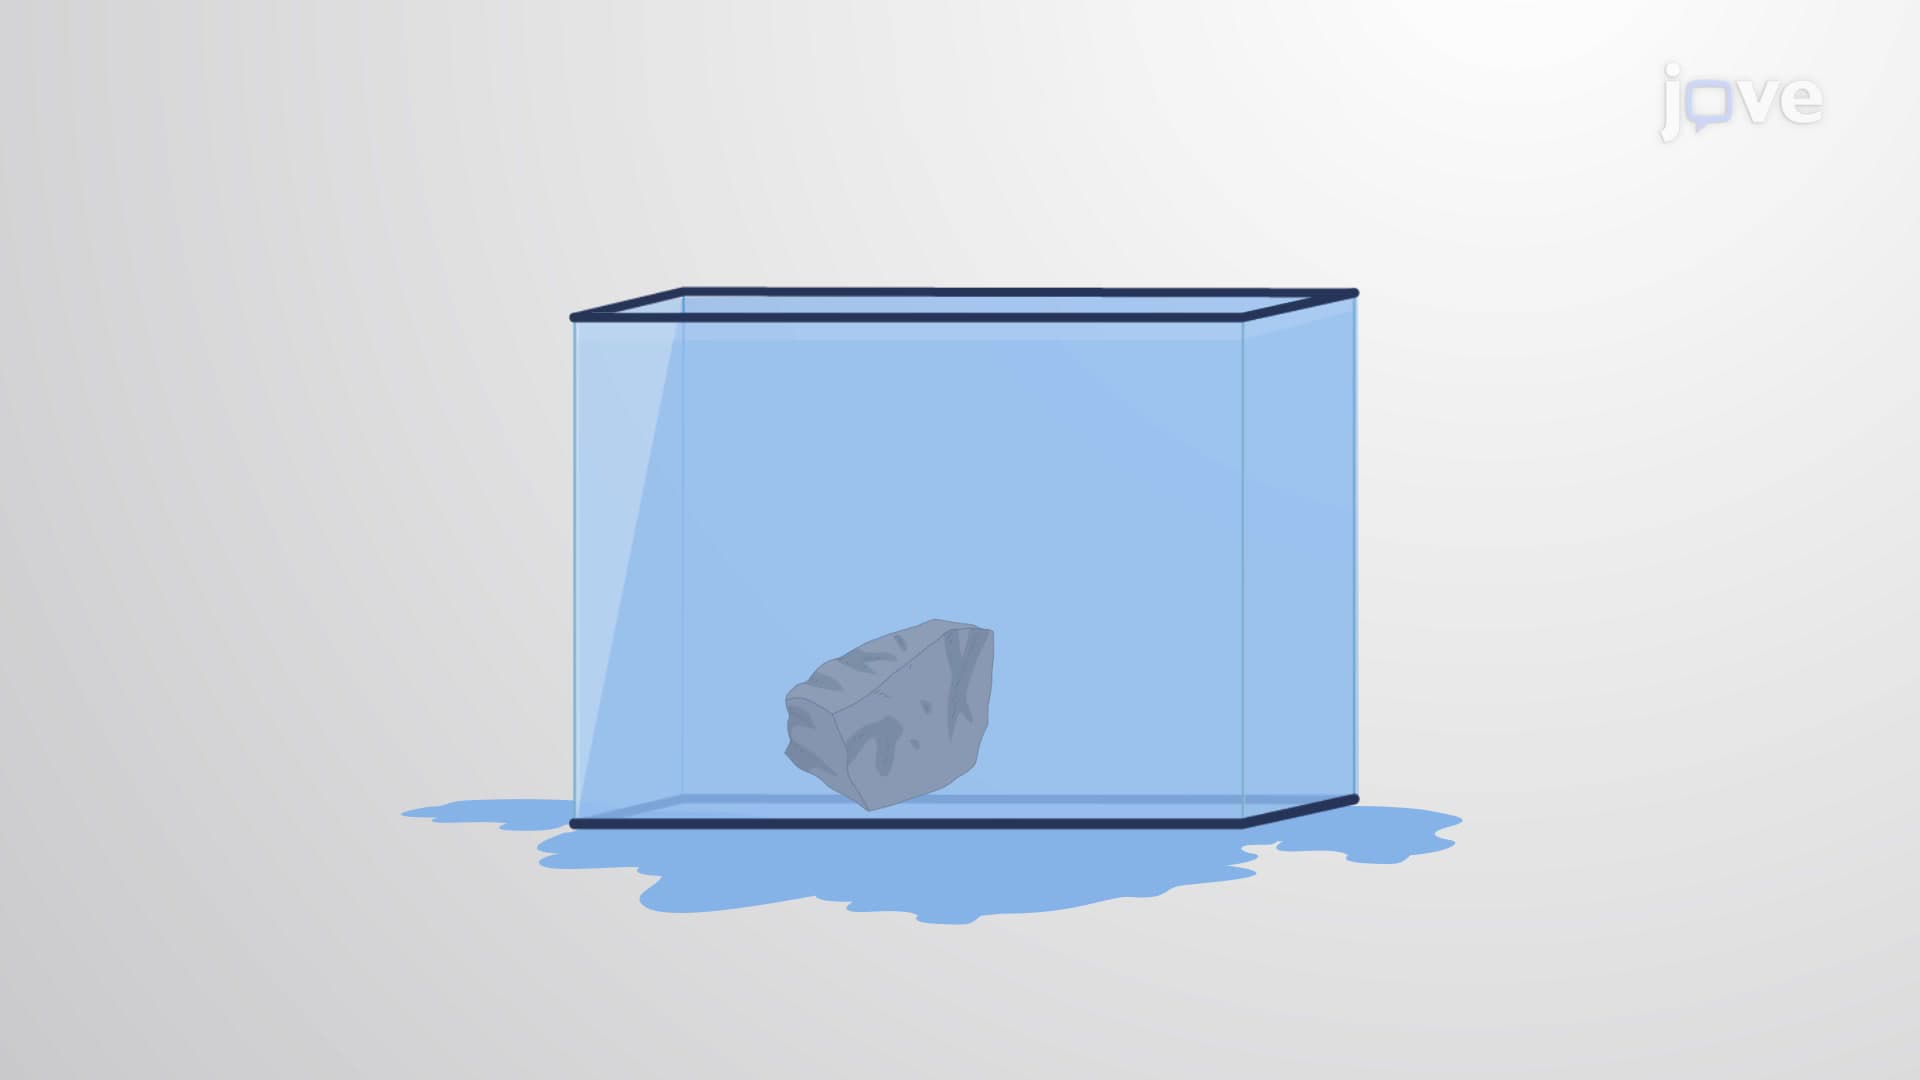 01:13
Archimedes' Principle
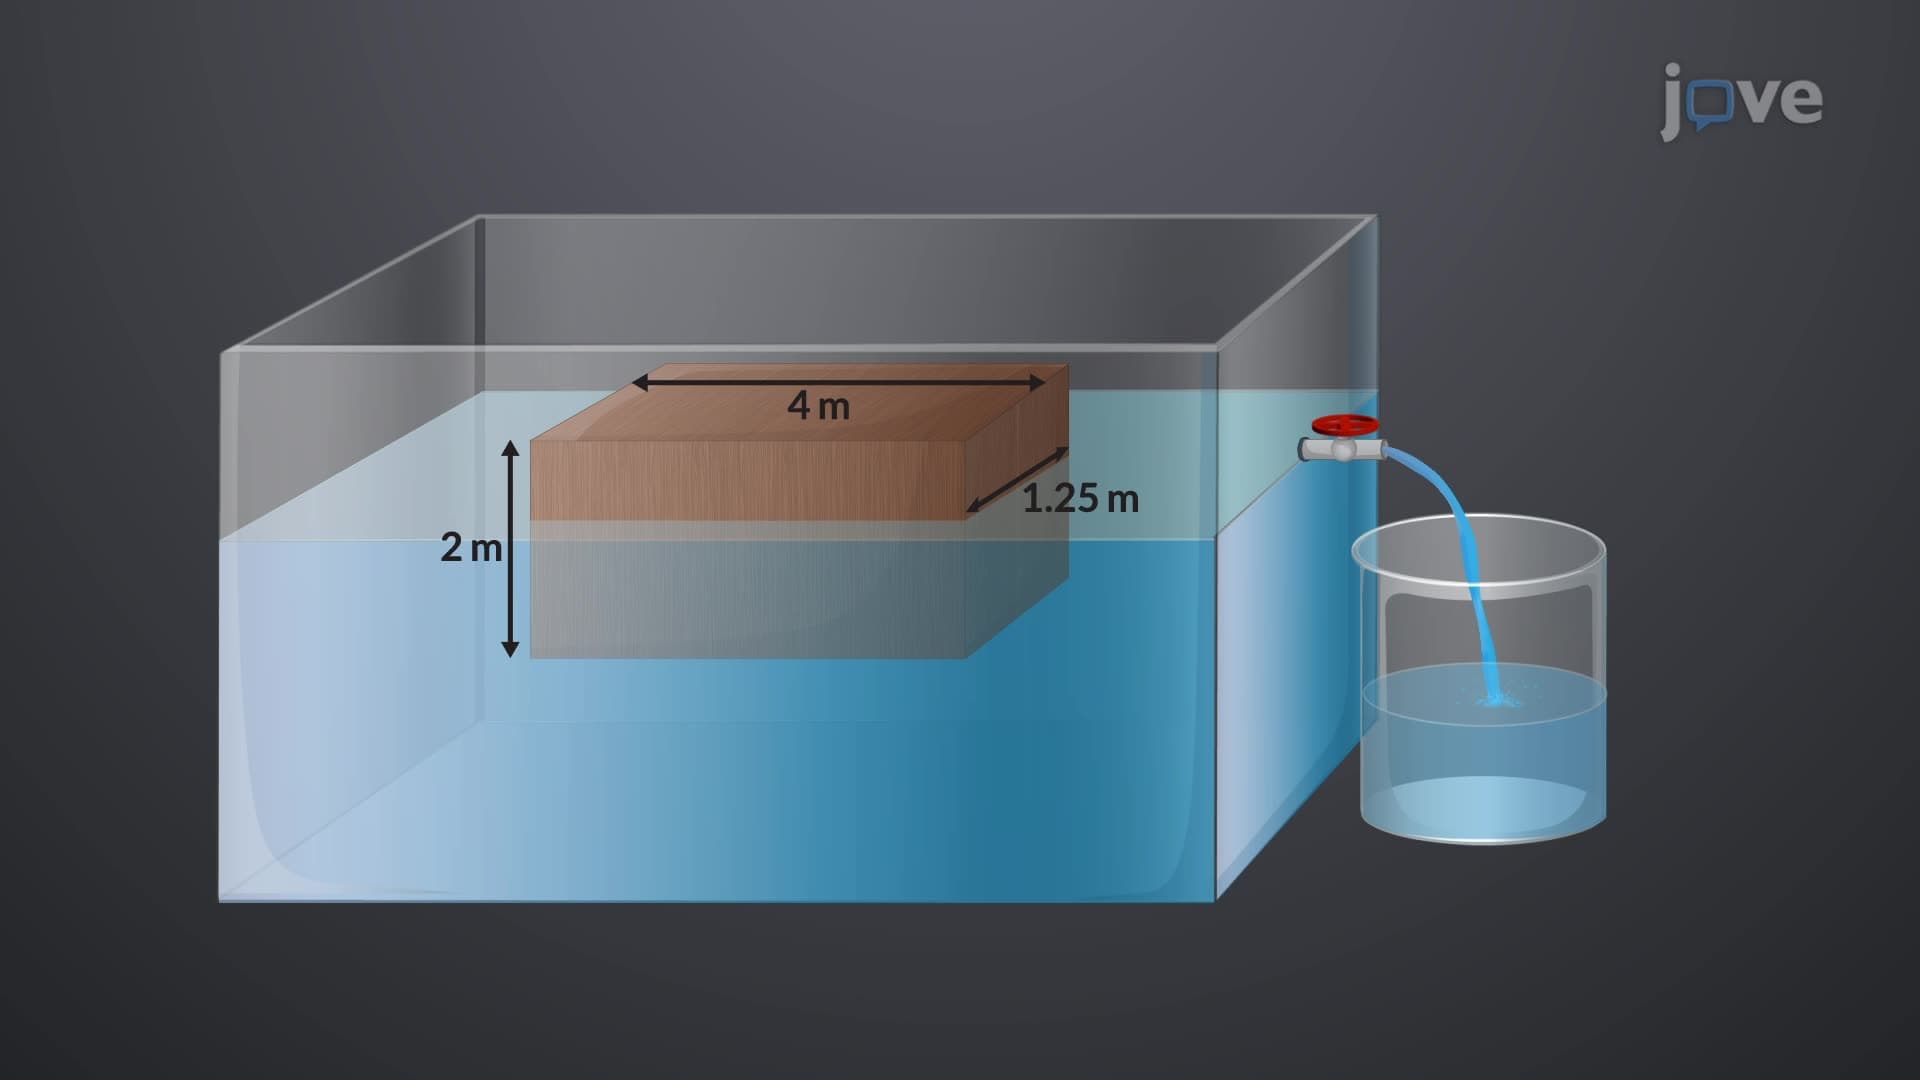 01:11
Design Example: Application of Archimedes' Principle
The volume of seawater displaced by the block is determined by first calculating the block's weight. This is done by multiplying the...
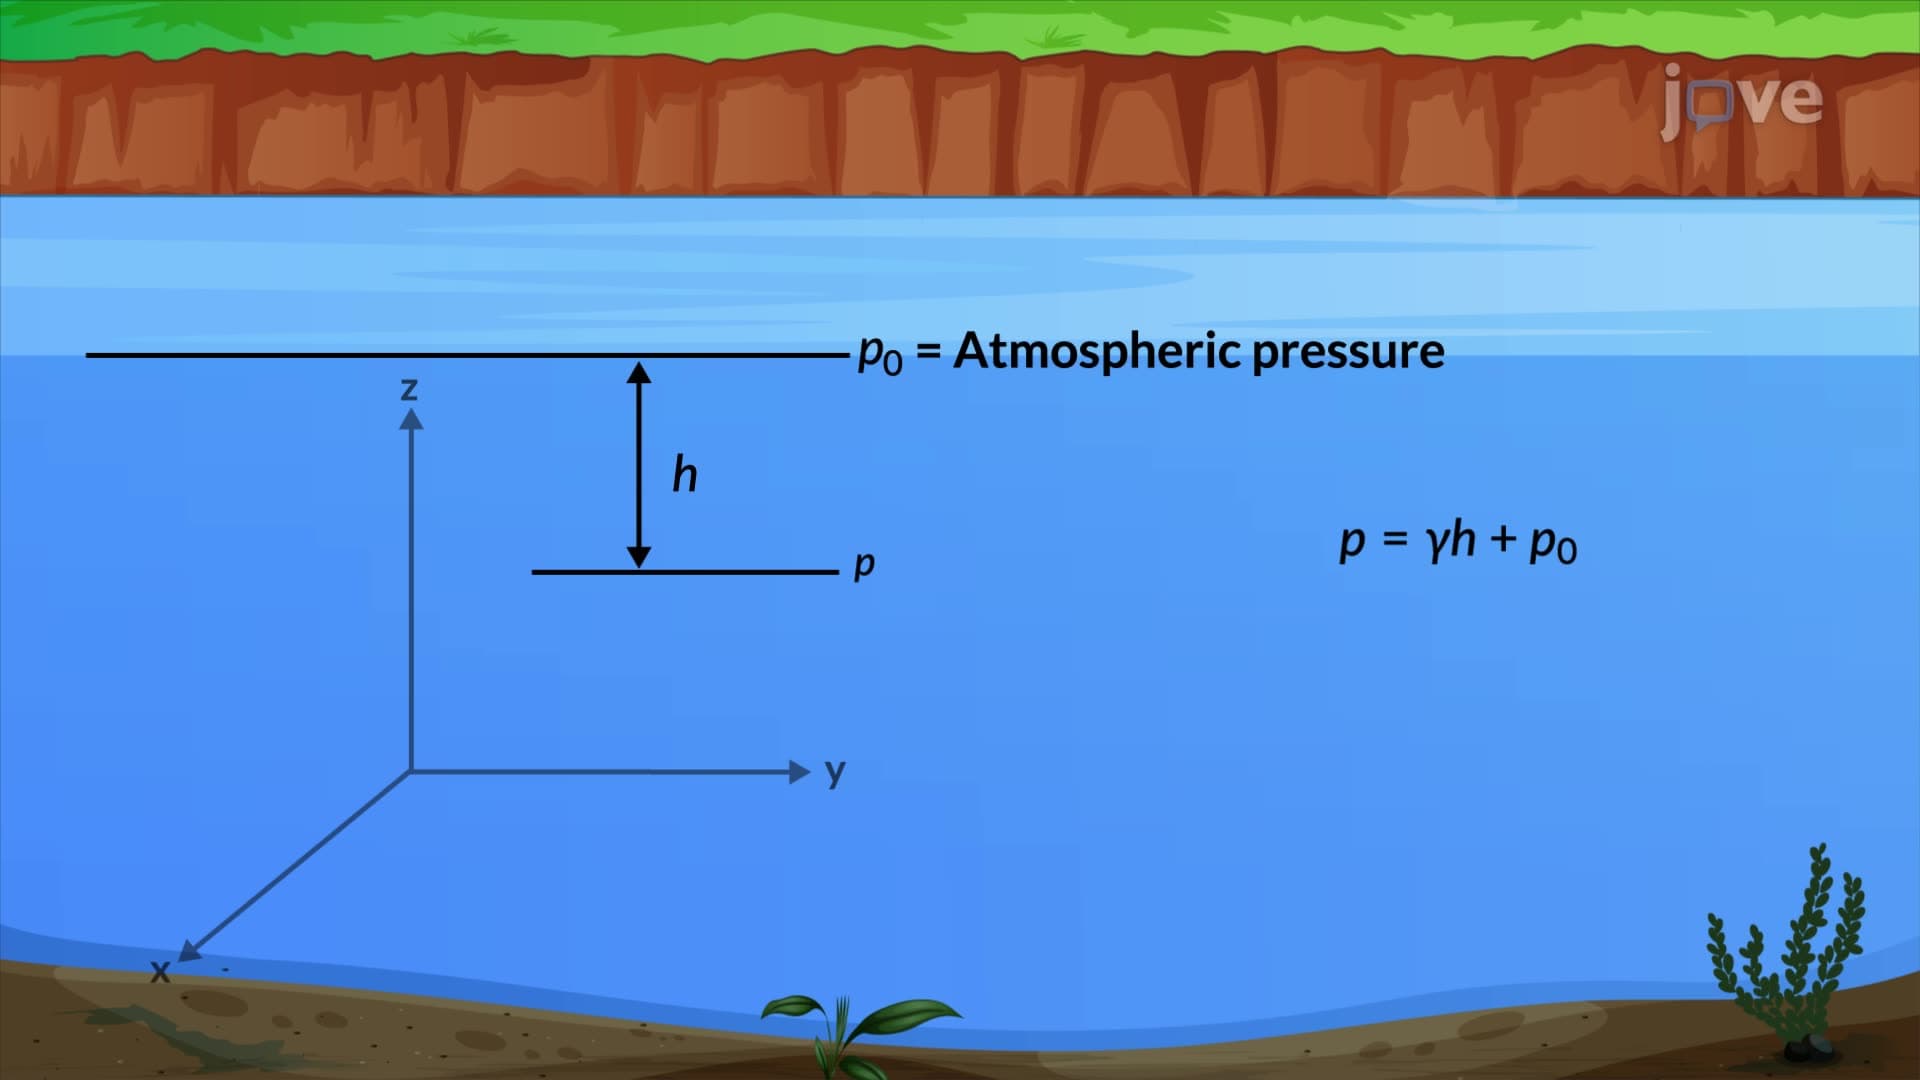 01:11
Pressure Variation in a Fluid at Rest
When measuring pressure at two different levels within the fluid, the difference in...