Related Experiment Video
Updated: Jun 24, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Calculating torque, back-EMF, inductance, and unbalanced magnetic force for a hybrid electrical vehicle by in-wheel
Alireza Hosseinpour1, Akbar Rahideh2, Ahmed Abbas3
1Department of Electrical Engineering, Universityof Zabol, Zabol, Iran. a.hoseinpour@uoz.ac.ir.

Abstract:
To use a Hybrid Excitation Synchronous Machine (HESM) in a hybrid electrical vehicle (HEV), its performance indicators such as back-EMF, inductance and unbalanced magnetic force should be computed preferably by an analytical method. First, the back-EMF is calculated by considering alternate-teeth and all-teeth non-overlapping and overlapping windings. The effects of three types of magnetization patterns including the radial, parallel and Halbach magnetizations on the back-EMF waveform have also been investigated. Then, the self-inductance of the stator and rotor windings, the mutual inductance between the stator and rotor windings, and the mutual inductance between the stator phases are computed. Next, the components of the unbalanced magnetic force (UMF) in the direction of the x and y axes and its amplitude are computed. Moreover, the effects of the magnetization patterns on those magnetic pulls are investigated. To minimize the UMFs, symmetry must be implemented in the excitation sources; therefore, first the stator winding then the permanent magnet and rotor winding are modified in such a way that the UMFs are reduced. Increasing the temperature leads to a weakening of the magnet's residual flux density, which strongly affects the performance characteristics of the electric machine such as Back-EMF and UMF. Finally, the ratio of the permanent magnet flux to the rotor flux is determined in such a way that the average torque is maximized. In this section, the effects of three magnetization patterns will be investigated.
More Related Videos
 08:55
Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:24
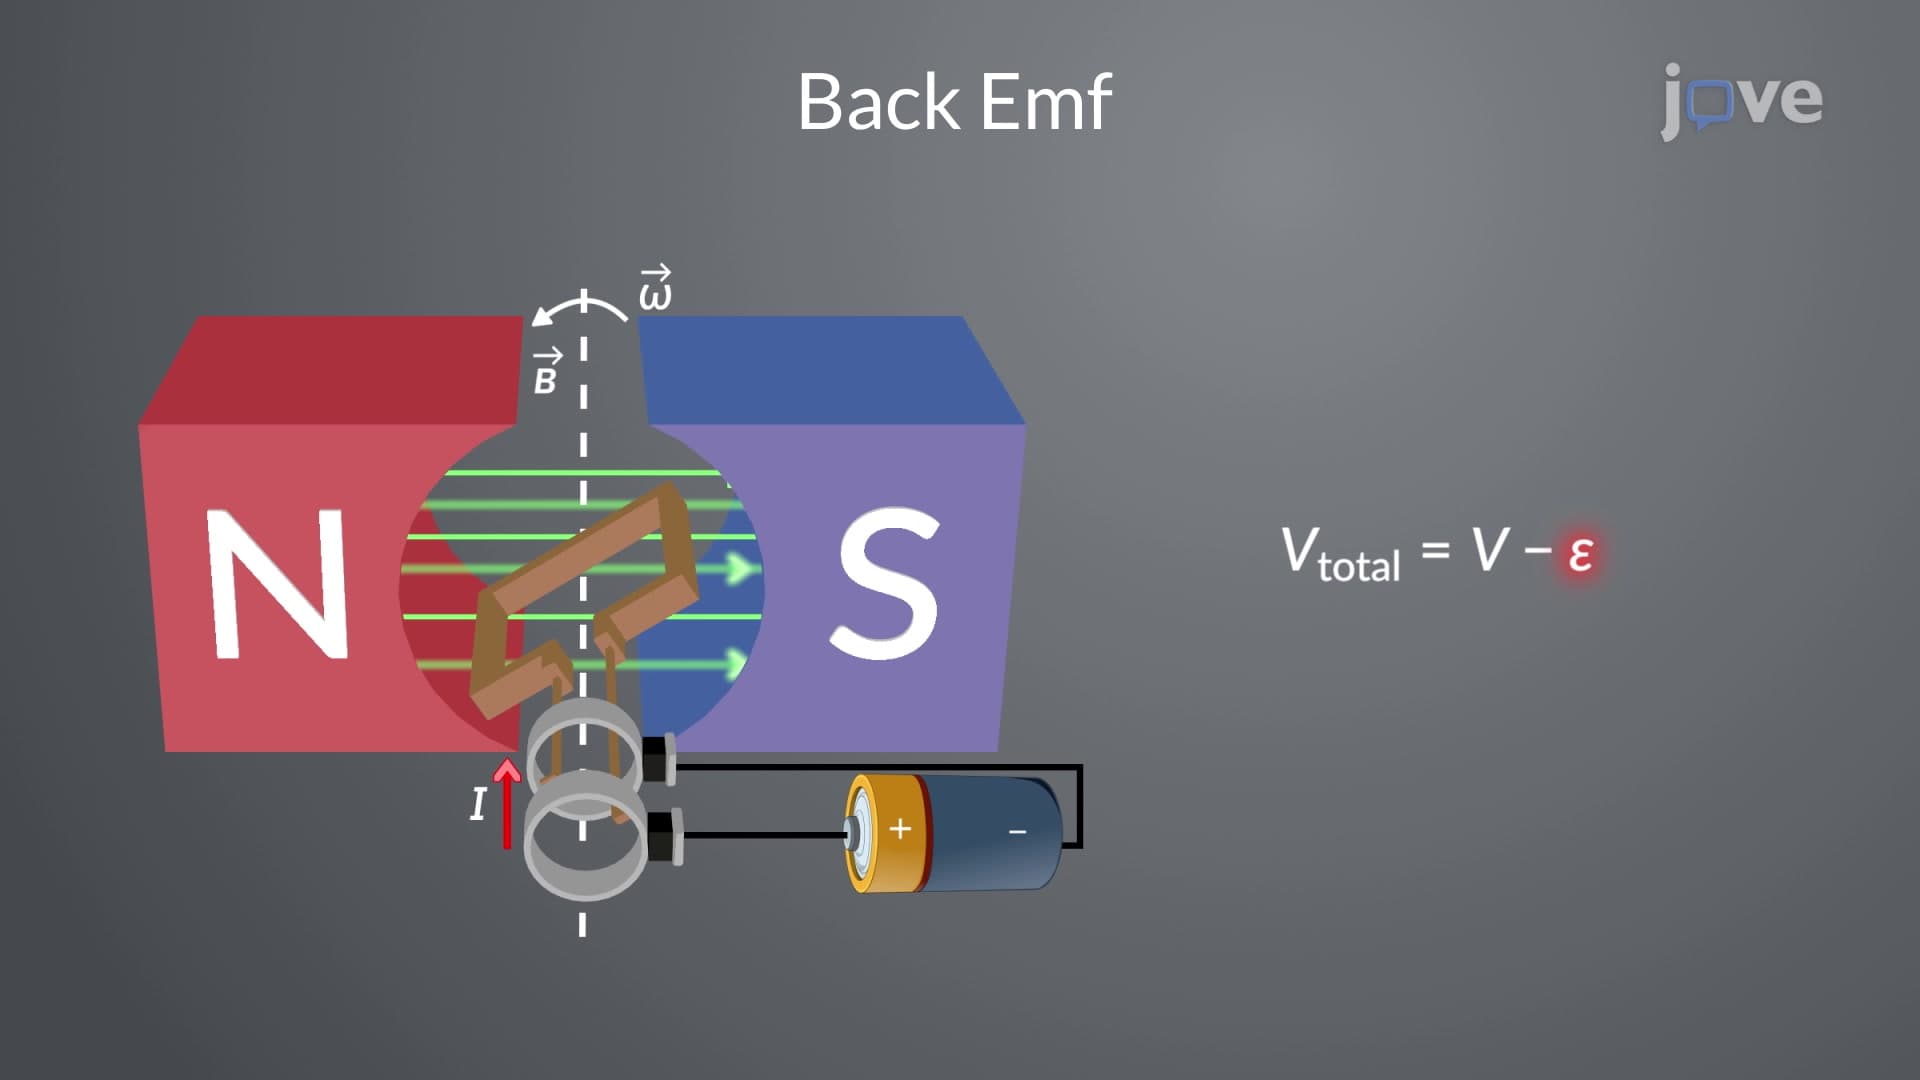
Back EMF
 01:29
Calculation of Self-inductance
Since the effect of the induced electric field and the back EMF generated depends on the rate of change of current and the self-inductance, the inductance...
 01:17
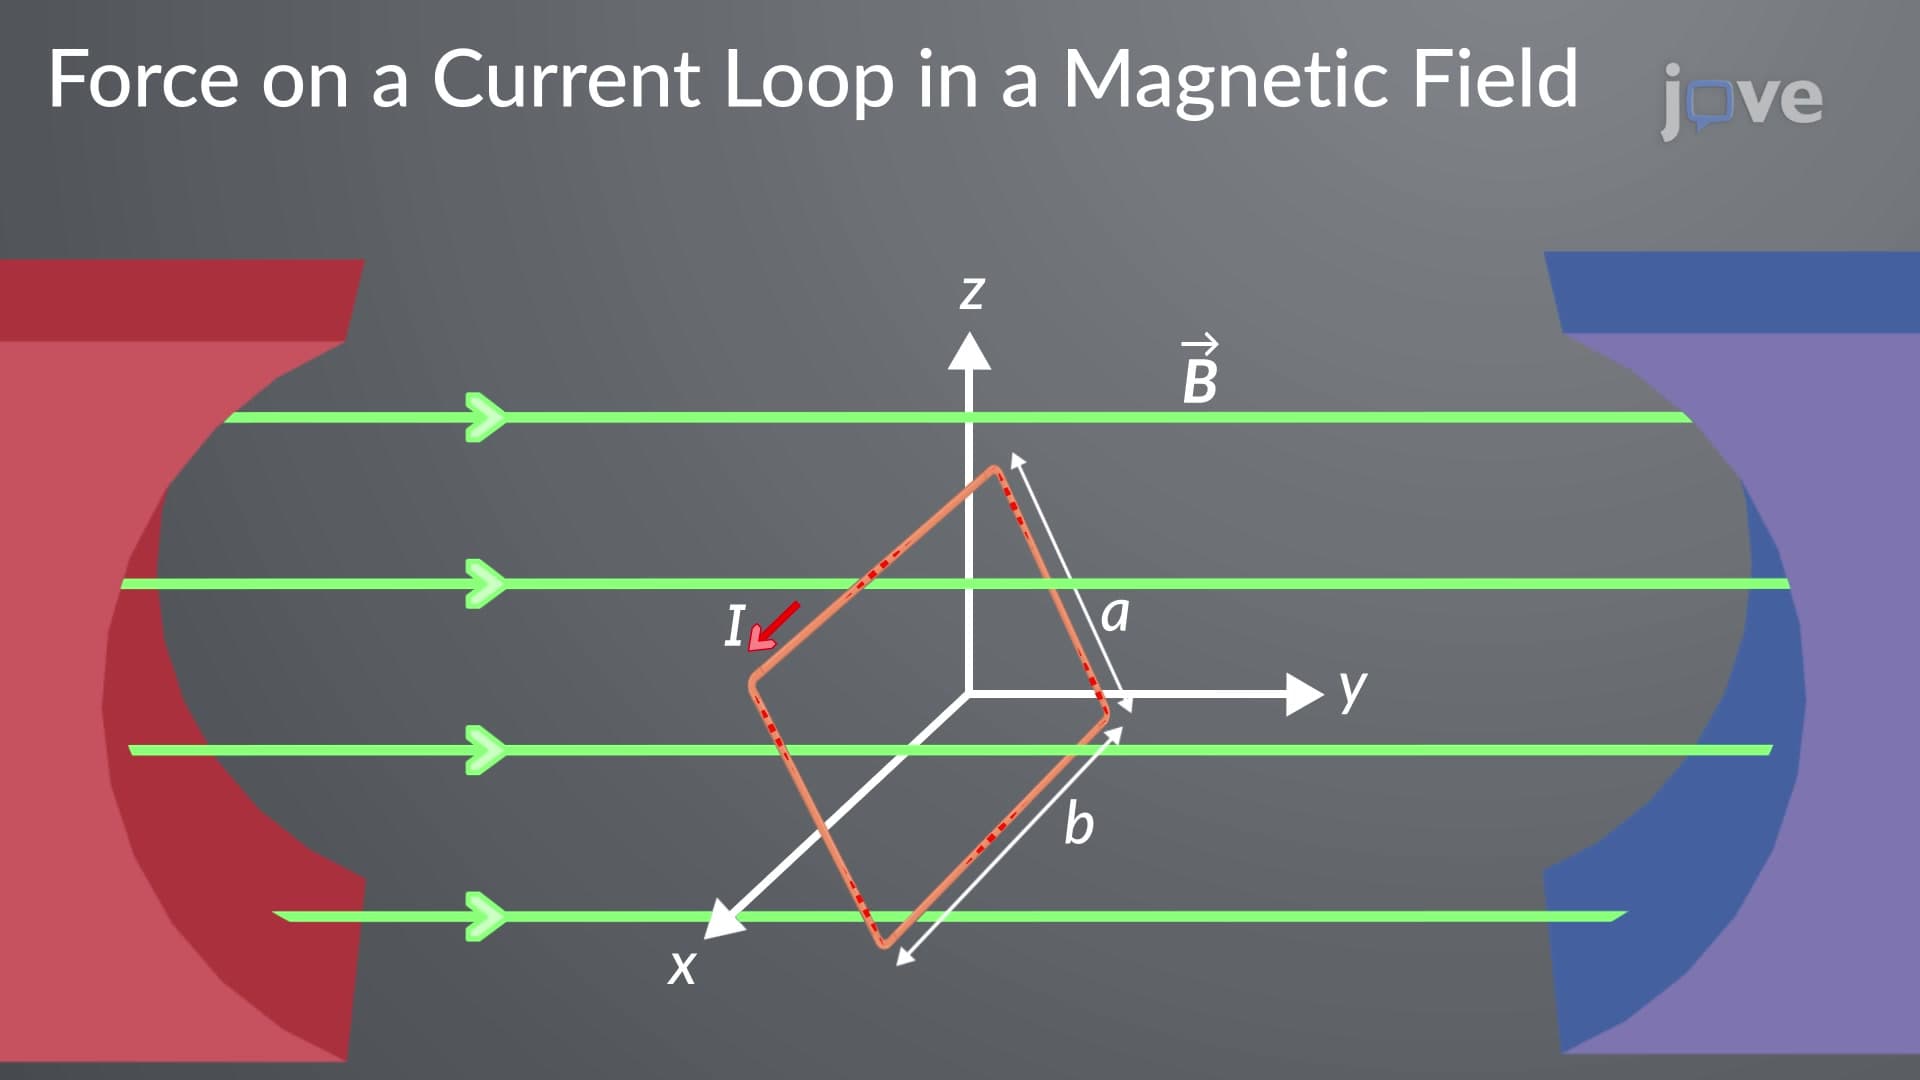
Force On A Current Loop In A Magnetic Field
 01:13
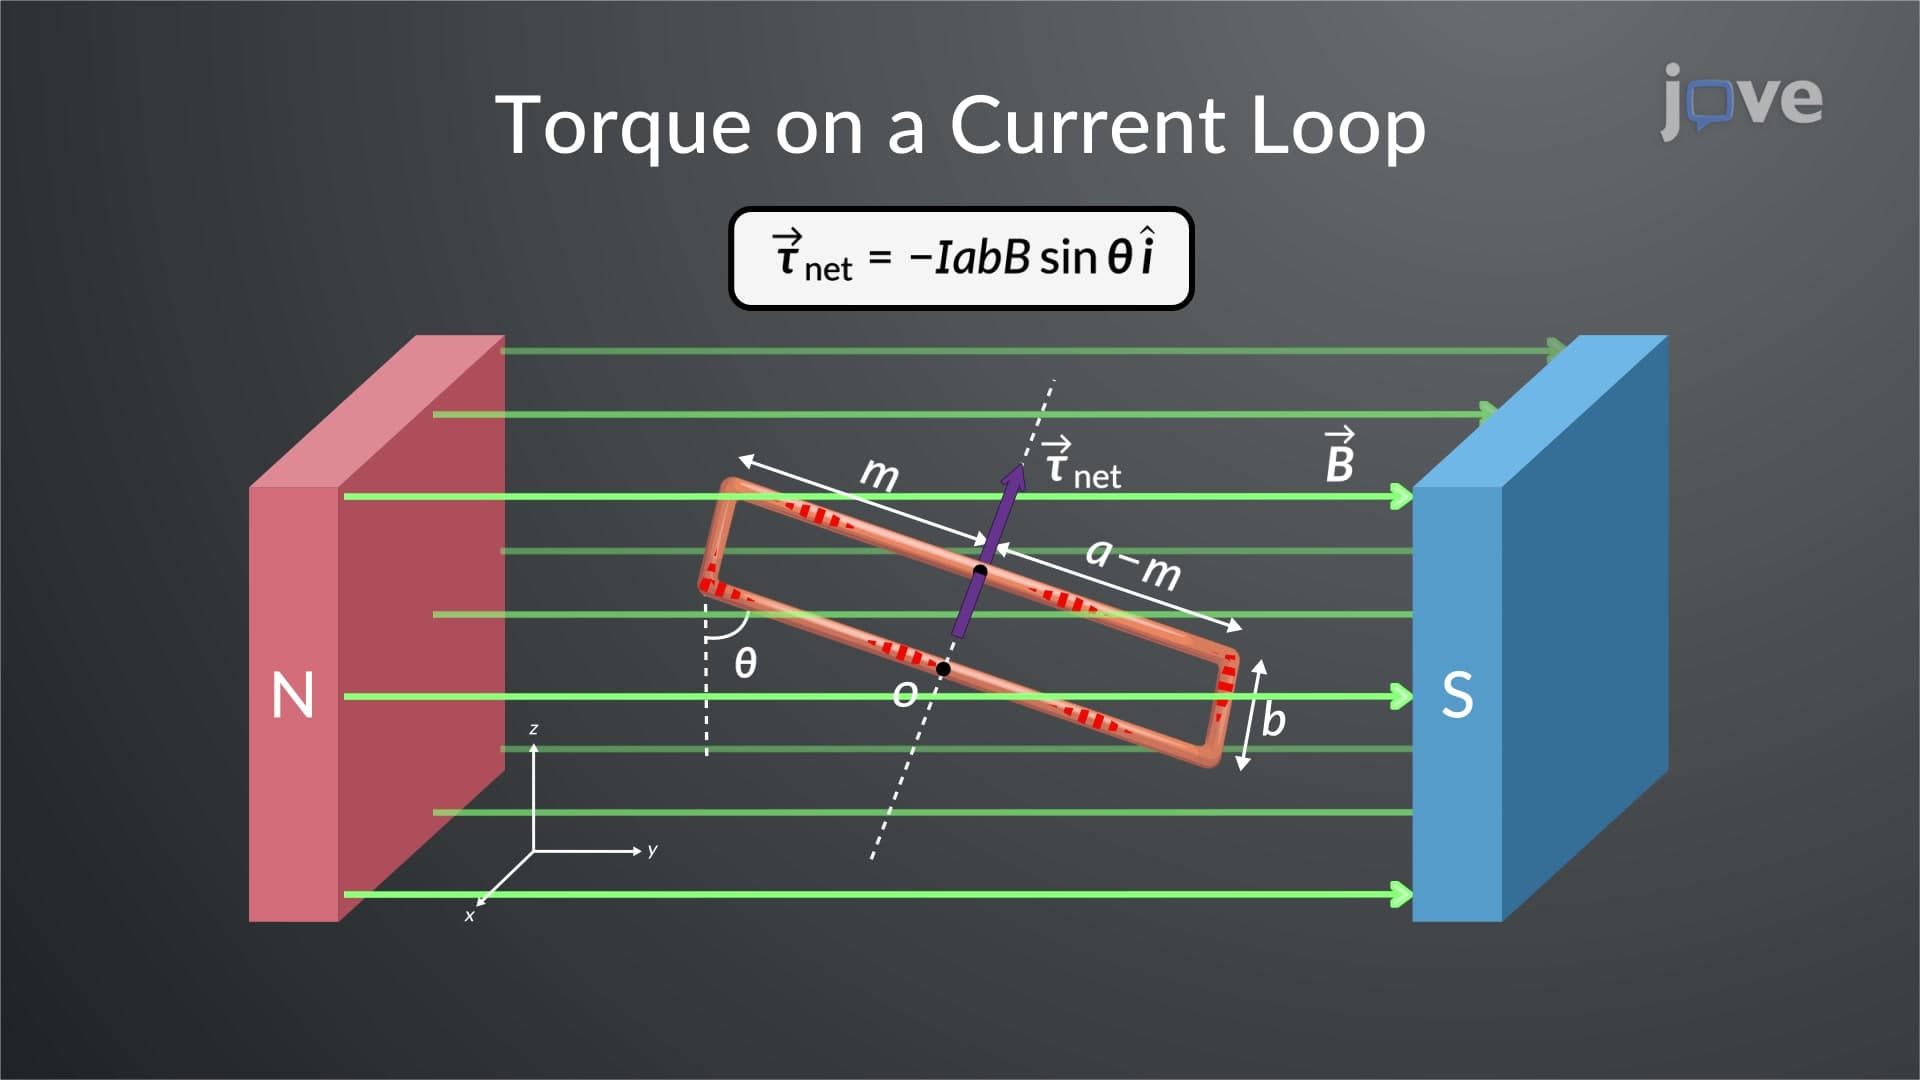
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
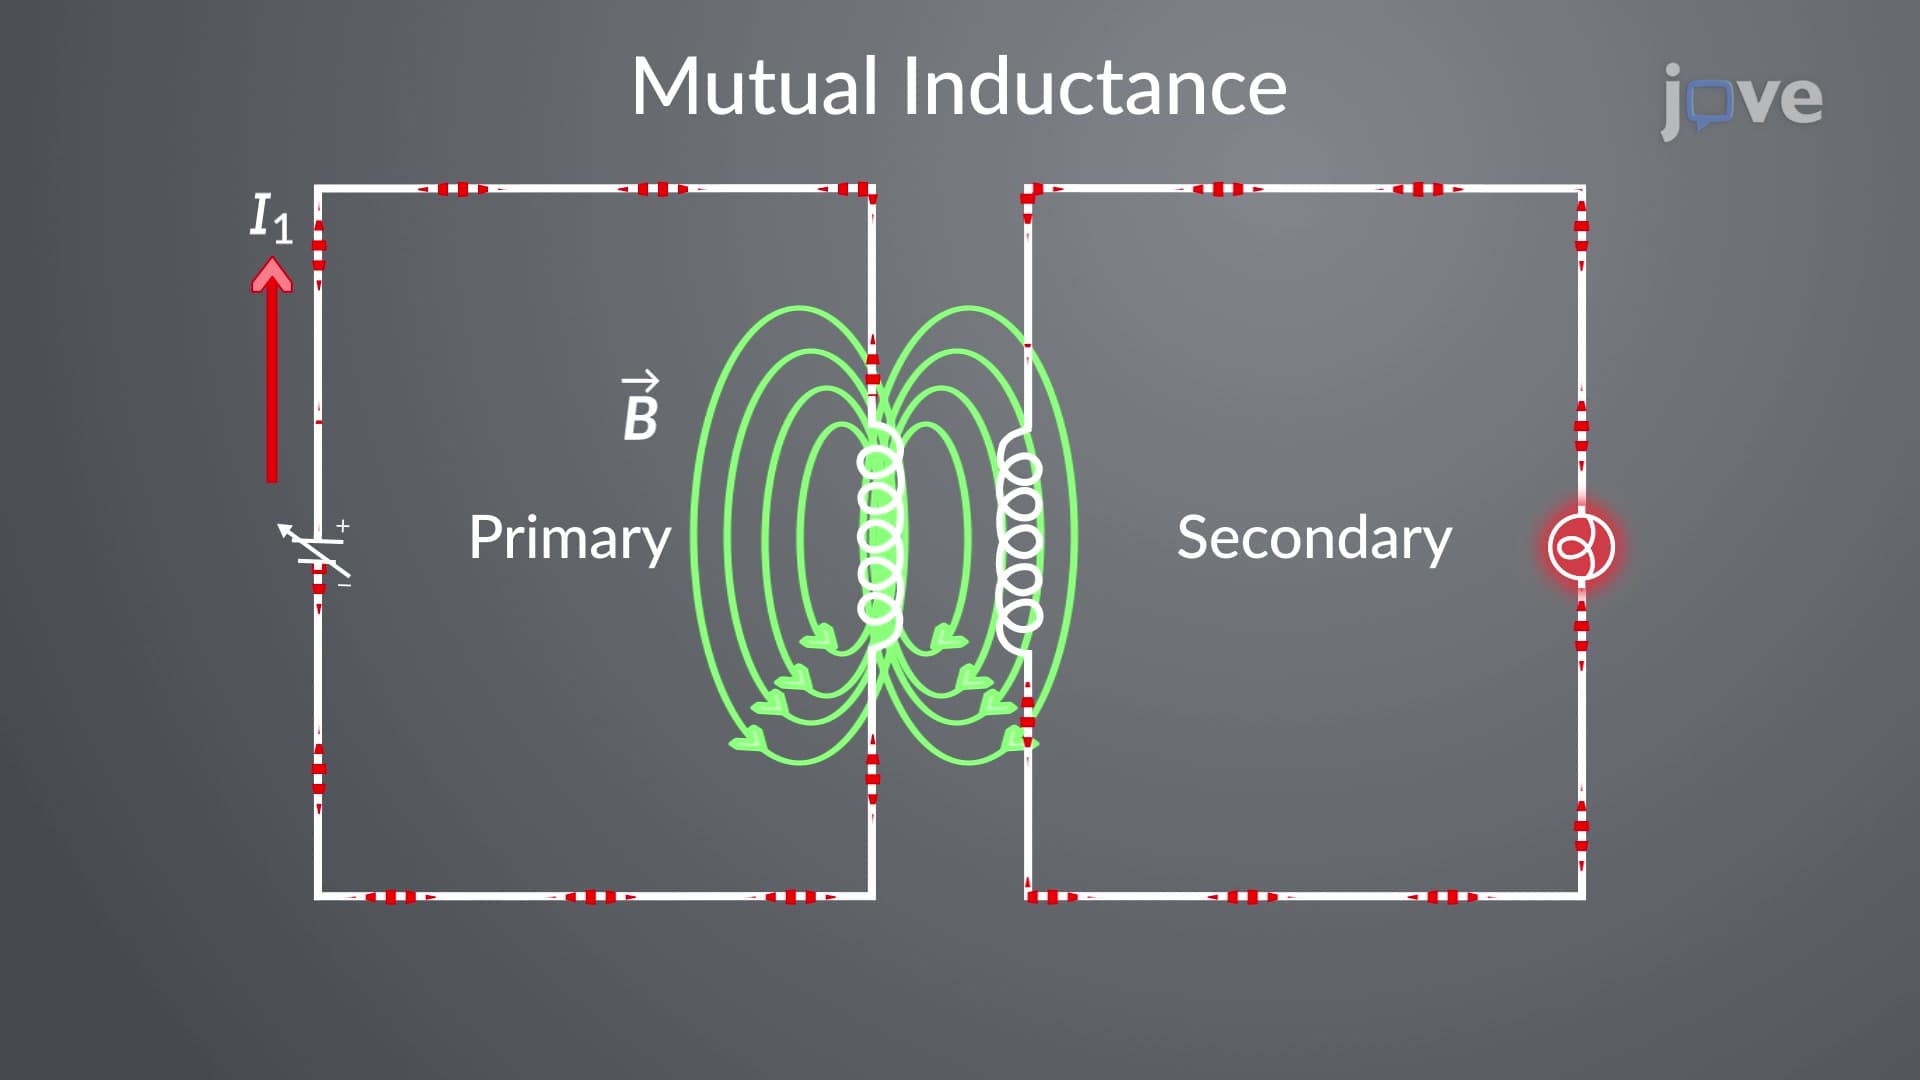 01:24
Mutual Inductance
When two circuits carrying time-varying currents are close to one another, the magnetic flux through each circuit varies because of the changing current in the other circuit. Consequently, an emf is induced in each circuit by the changing current in the other. Therefore, this type of emf is called...