Tunable linear feedback control of urban drainage systems using models defined purely from data
Related Experiment Video
Updated: Jun 23, 2025
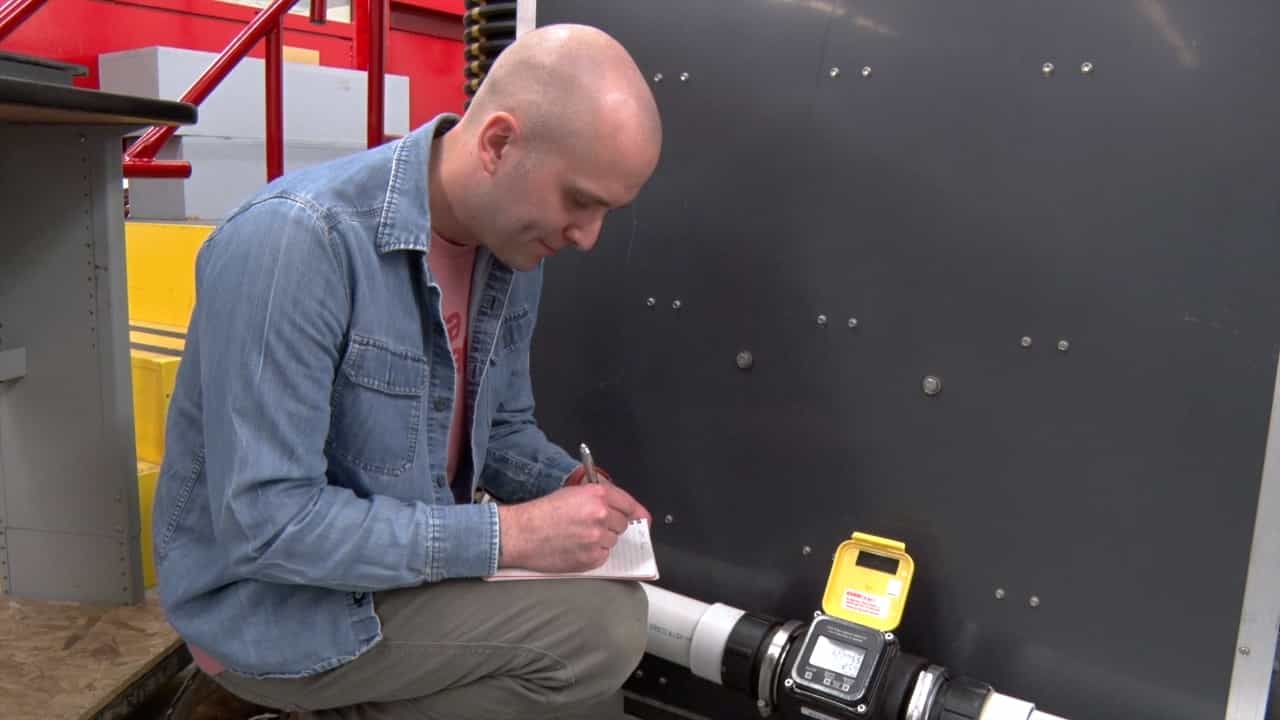
Parameterizing V-notch Weir Equations for Flow Monitoring in a Drainage Control Structure
Published on: April 25, 2025
Travis Adrian Dantzer1, Branko Kerkez2
1University of Michigan Civil and Environmental Engineering, 2350 Hayward St, Ann Arbor, MI 48109, USA

Abstract:
Real-time and model-predictive control promises to make urban drainage systems (UDS) adaptive, coordinated, and dynamically optimal. Though early implementations are promising, existing control algorithms have drawbacks in computational expense, trust, system-level coordination, and labor cost. Linear feedback control has distinct advantages in computational expense, interpretation, and coordination. However, current methods for building linear feedback controllers require calibrated software models. Here we present an automated method for generating tunable linear feedback controllers that require only system response data. The controller design consists of three main steps: (1) estimating the network connectivity using tools for causal inference, (2) identifying a linear, time-invariant (LTI) dynamical system which approximates the network, and (3) designing and tuning a feedback controller based on the LTI urban drainage system approximation. The flooding safety, erosion prevention, and water treatment performance of the method are evaluated across 190 design storms on a separated sewer model. Strong results suggest that the system knowledge required for generating effective, safe, and tunable controllers for UDS is surprisingly basic. This method allows near-turnkey synthesis of controllers solely from sensor data or reduction of process-based models.
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:14
Conservation of Mass in Moving, Nondeforming Control Volume
In the context of a detention basin, the conservation of mass states that the total mass of water entering the basin must equal the mass leaving the basin plus any accumulation of...
 01:30
Typical Model Studies
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
 01:17
Design Example: Analyzing Capacity Contours for Flood Risk Assessment