Related Experiment Video
Updated: Jun 23, 2025
Experimental Investigation of Secondary Flow Structures Downstream of a Model Type IV Stent Failure in a 180° Curved Artery Test Section
Published on: July 19, 2016
Controlled Differential Equations on Long Sequences via Non-standard Wavelets
Sourav Pal1, Zhanpeng Zeng1, Sathya N Ravi2
1University of Wisconsin-Madison.

Abstract:
Neural Controlled Differential equations (NCDE) are a powerful mechanism to model the dynamics in temporal sequences, e.g., applications involving physiological measures, where apart from the initial condition, the dynamics also depend on subsequent measures or even a different "control" sequence. But NCDEs do not scale well to longer sequences. Existing strategies adapt rough path theory, and instead model the dynamics over summaries known as log signatures. While rigorous and elegant, invertibility of these summaries is difficult, and limits the scope of problems where these ideas can offer strong benefits (reconstruction, generative modeling). For tasks where it is sensible to assume that the (long) sequences in the training data are a fixed length of temporal measurements - this assumption holds in most experiments tackled in the literature - we describe an efficient simplification. First, we recast the regression/classification task as an integral transform. We then show how restricting the class of operators (permissible in the integral transform), allows the use of a known algorithm that leverages non-standard Wavelets to decompose the operator. Thereby, our task (learning the operator) radically simplifies. A neural variant of this idea yields consistent improvements across a wide gamut of use cases tackled in existing works. We also describe a novel application on modeling tasks involving coupled differential equations.
Related Concept Videos
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:24
Difference Equation Solution using z-Transform
The z-transform facilitates handling delayed signals by shifting the signal in the z-domain, which corresponds to delaying the signal in the time domain, and advancing signals by similarly shifting in the...
 01:16
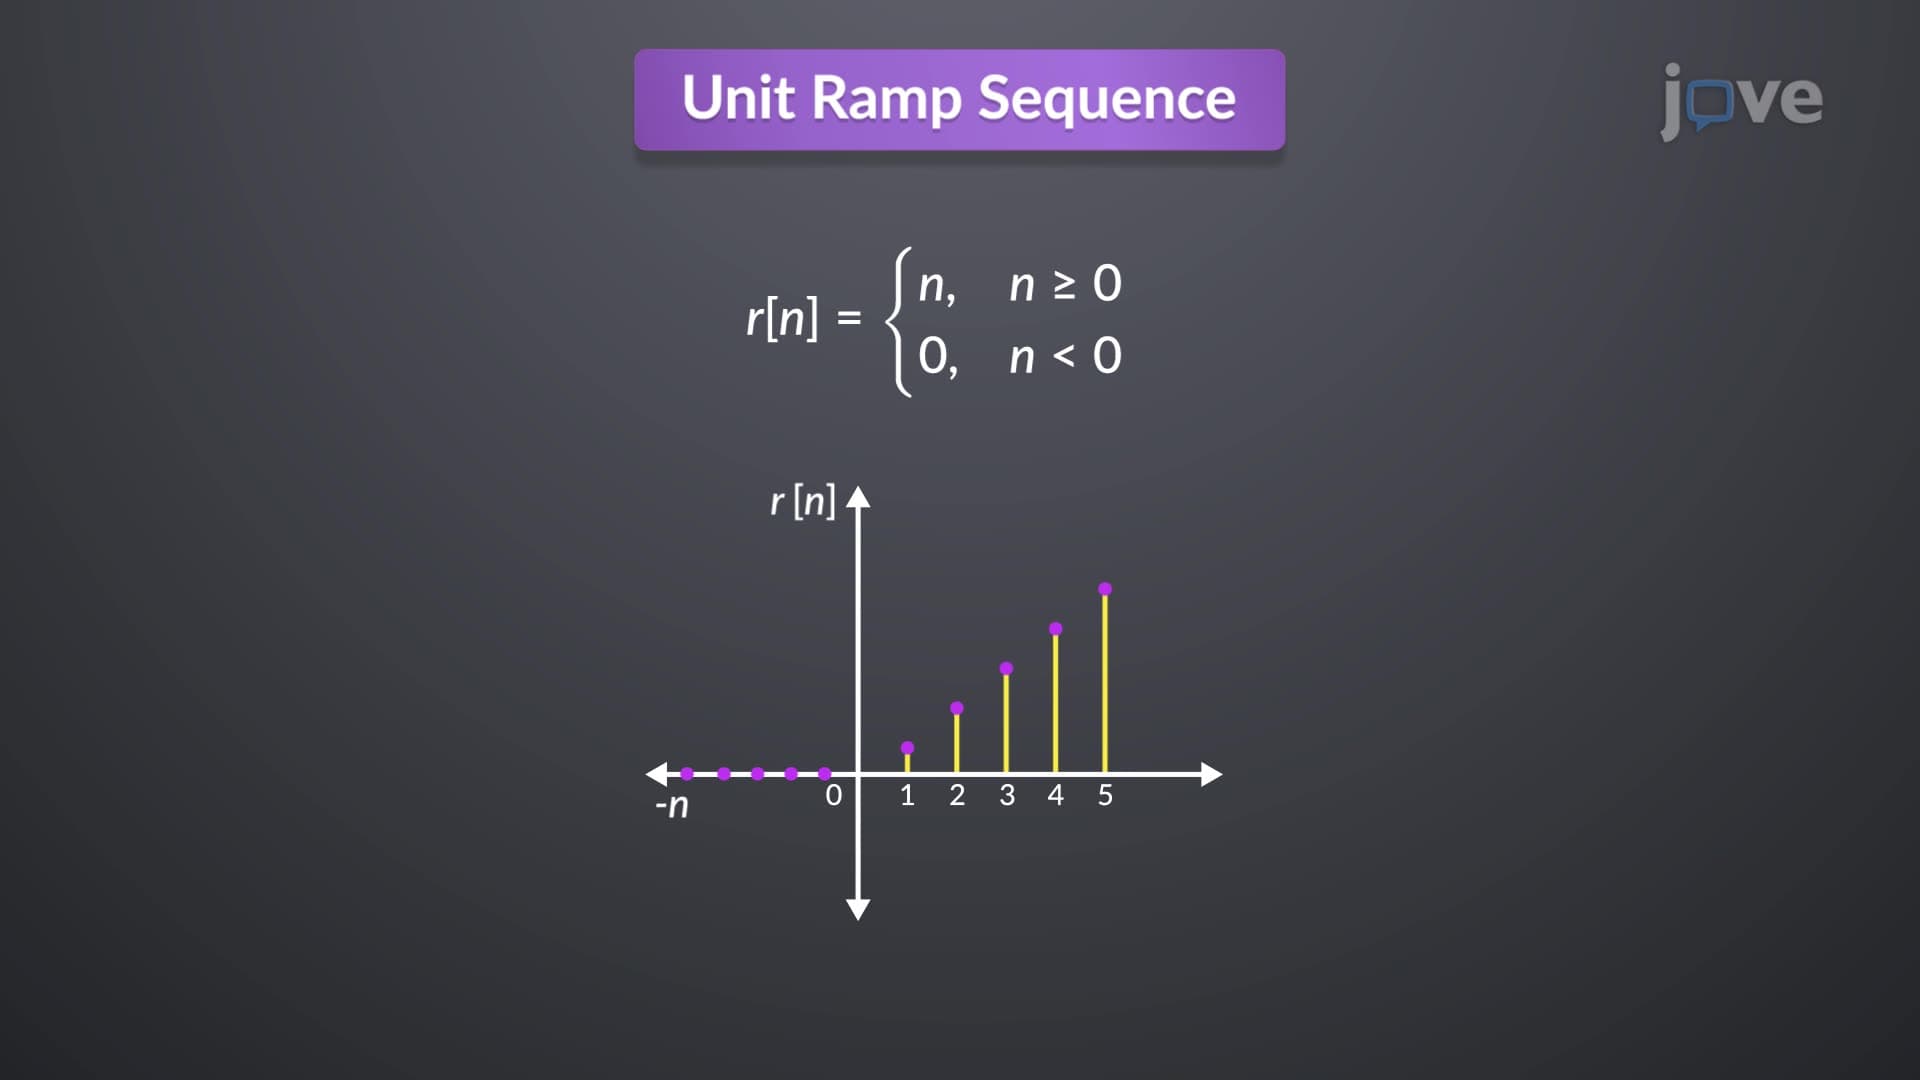
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...
 01:18
Second Order systems II
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....