Semi-Supervised Coupled Thin-Plate Spline Model for Rotation Correction and Beyond
Related Experiment Video
Updated: Jun 23, 2025
Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019

Abstract:
Thin-plate spline (TPS) is a principal warp that allows for representing elastic, nonlinear transformation with control point motions. With the increase of control points, the warp becomes increasingly flexible but usually encounters a bottleneck caused by undesired issues, e.g., content distortion. In this paper, we explore generic applications of TPS in single-image-based warping tasks, such as rotation correction, rectangling, and portrait correction. To break this bottleneck, we propose the coupled thin-plate spline model (CoupledTPS), which iteratively couples multiple TPS with limited control points into a more flexible and powerful transformation. Concretely, we first design an iterative search to predict new control points according to the current latent condition. Then, we present the warping flow as a bridge for the coupling of different TPS transformations, effectively eliminating interpolation errors caused by multiple warps. Besides, in light of the laborious annotation cost, we develop a semi-supervised learning scheme to improve warping quality by exploiting unlabeled data. It is formulated through dual transformation between the searched control points of unlabeled data and its graphic augmentation, yielding an implicit correction consistency constraint. Finally, we collect massive unlabeled data to exhibit the benefit of our semi-supervised scheme in rotation correction. Extensive experiments demonstrate the superiority and universality of CoupledTPS over the existing State-of-the-Art (SoTA) solutions for rotation correction and beyond.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
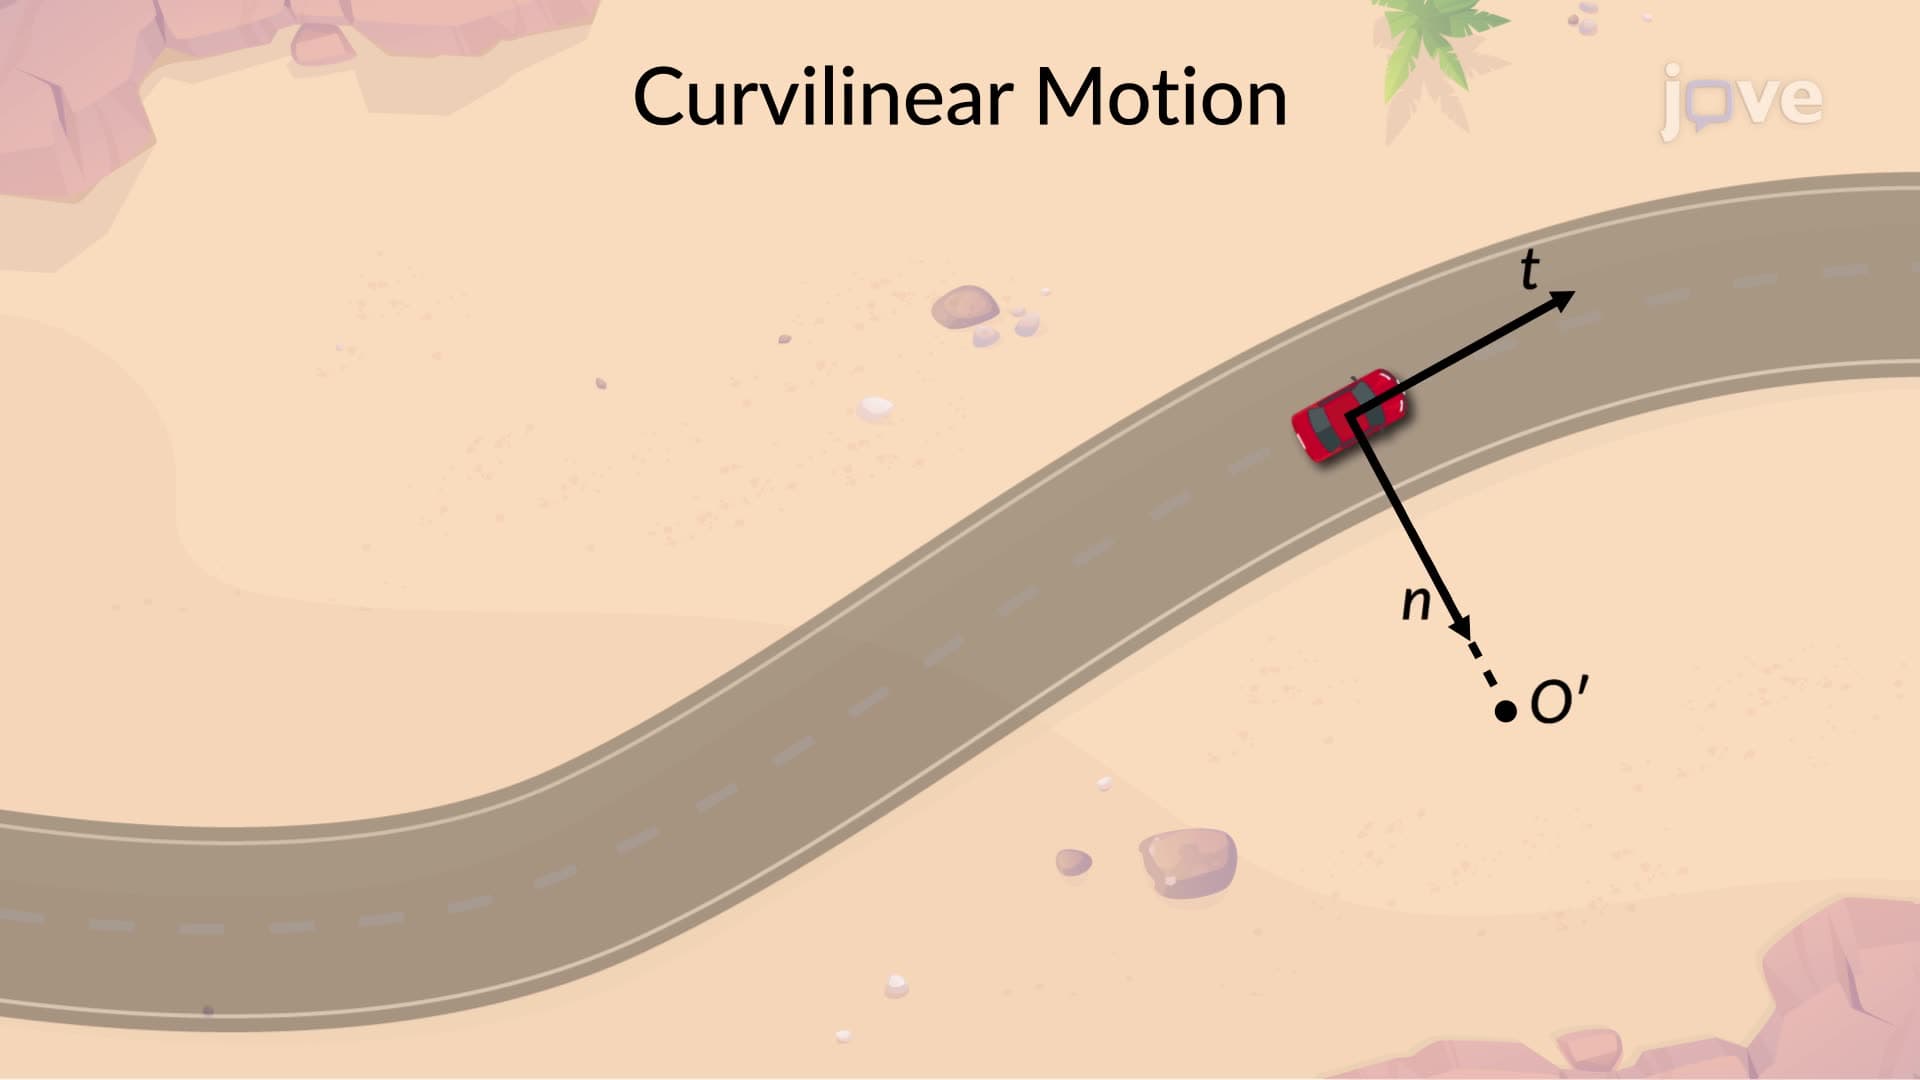
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...