Contribution of external reference frame to tactile localization
Related Experiment Video
Updated: Jun 23, 2025
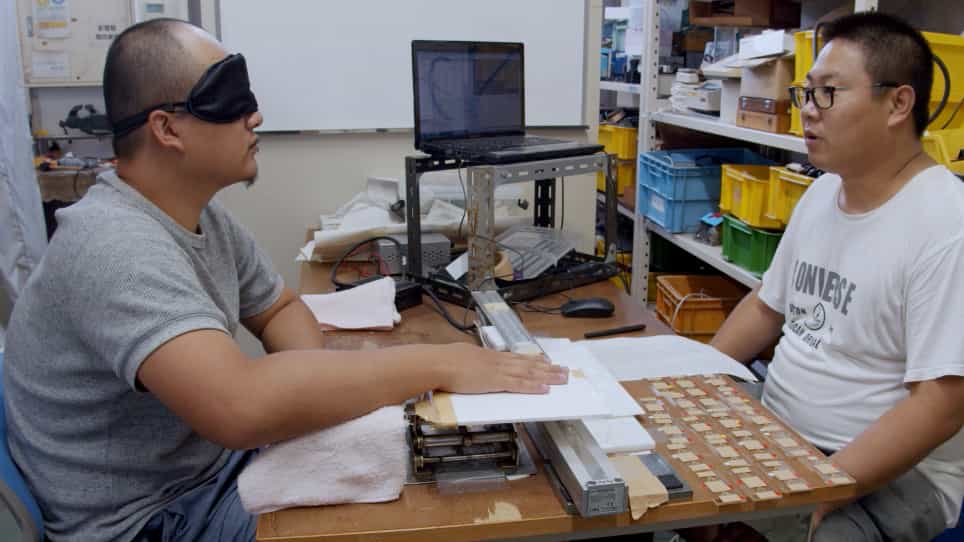
Tactile Semiautomatic Passive-Finger Angle Stimulator TSPAS
Published on: July 30, 2020
Shunsuke Otsuka1, Han Gao2, Koichi Hiraoka3
1College of Health and Human Sciences, Osaka Prefecture University, Habikino city, Japan.

Abstract:
The purpose of the present study was to elucidate whether an external reference frame contributes to tactile localization in blindfolded healthy humans. In a session, the right forearm was passively moved until the elbow finally reached to the target angle, and participants reached the left index finger to the right middle fingertip. The locus of the right middle fingertip indicated by the participants deviated in the direction of the elbow extension when vibration was provided to the biceps brachii muscle during the passive movement. This finding indicates that proprioception contributes to the identification of the spatial coordinate of the specific body part in an external reference frame. In another session, the tactile stimulus was provided to the dorsal of the right hand during the passive movement, and the participants reached the left index finger to the spatial locus at which the tactile stimulus was provided. Vibration to the biceps brachii muscle did not change the perceived locus of the tactile stimulus indicated by the left index finger. This finding indicates that an external reference frame does not contribute to tactile localization during the passive movement. Humans may estimate the spatial coordinate of the tactile stimulus based on the time between the movement onset and the time at which the tactile stimulus is provided.

Related Concept Videos
 01:27
Non-inertial Frames of Reference
 01:03
Inertial Frames of Reference
 01:33
Somatosensation
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:15
Depth Perception and Spatial Vision
 01:15
Equilibrium and Balance